相关实验视频
Updated: Jun 13, 2025
09:36

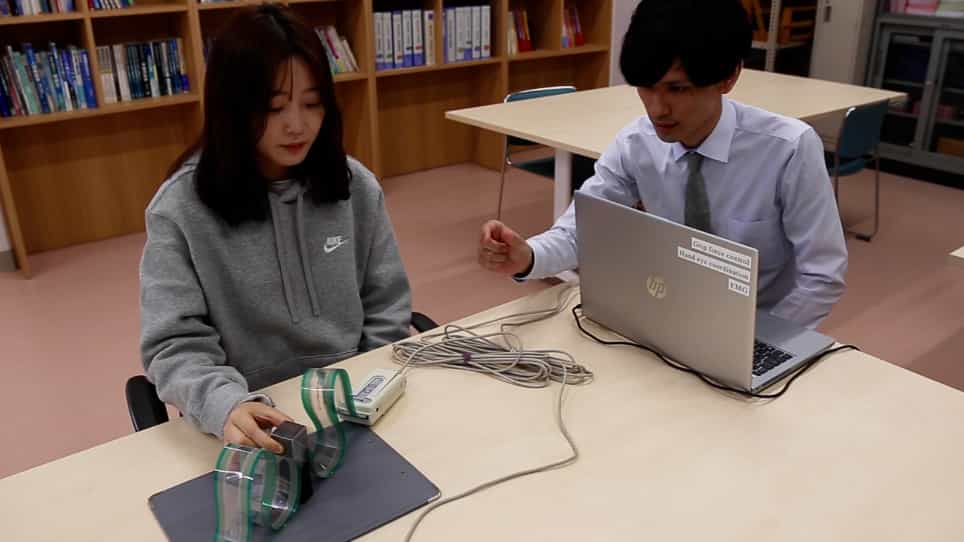
Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
3.2K
在四个运动状态下对赤裸足迹线性测量的稳定性进行了初步研究
1School of Criminal Investigation, People's Public Security University of China, Beijing, China; Department of Forensic Science, Zhejiang Police College, Hangzhou, China.
Science & justice : journal of the Forensic Science Society
|September 14, 2024

概括
裸足迹测量随着运动而变化. 长度在站立和移动状态之间有显著差异,但在不同的步行速度之间没有,为法医分析提供了见解.
科学领域:
- 法医科学 法医科学 法医科学
- 生物力学 生物力学
- 人类测量学 人类测量学.
背景情况:
- 犯罪现场的赤裸足迹对于识别至关重要.
- 足迹测量可以通过运动改变,影响准确性.
- 以前的研究忽视了速度对动态足迹分析的影响.
研究的目的:
- 在不同运动状态中调查赤裸足迹线性测量的稳定性和可变性.
- 分析速度如何影响步行和慢跑过程中的足迹尺寸.
- 为解释在法医调查中发现的赤裸足迹提供参考.
主要方法:
- 从四个州的80名成年人收集了尘埃足迹:站立,正常行走,快速行走和慢跑.
- 使用Reel方法测量了七个线性参数 (A1-A5长度,MPJ宽度,Calc宽度).
- 使用单向重复测量ANOVA来分析测量变化.
主要成果:
- 在站立状态和所有动态状态之间发现了长度测量 (A1-A5) 的显著差异.
- 在三个动态状态 (正常行走,快速行走,慢跑) 中没有观察到显著的长度变化.
- 宽度测量 (MPJ宽度,Calc宽度) 在四个运动状态中没有显著差异.
结论:
- 足迹长度对从静态到动态状态的过渡非常敏感.
- 步行或慢跑的速度不会显著改变足迹长度的测量.
- 足迹宽度在不同的运动状态中保持稳定,这表明其在法医识别中的可靠性.
更多相关视频

相关概念视频
 01:28
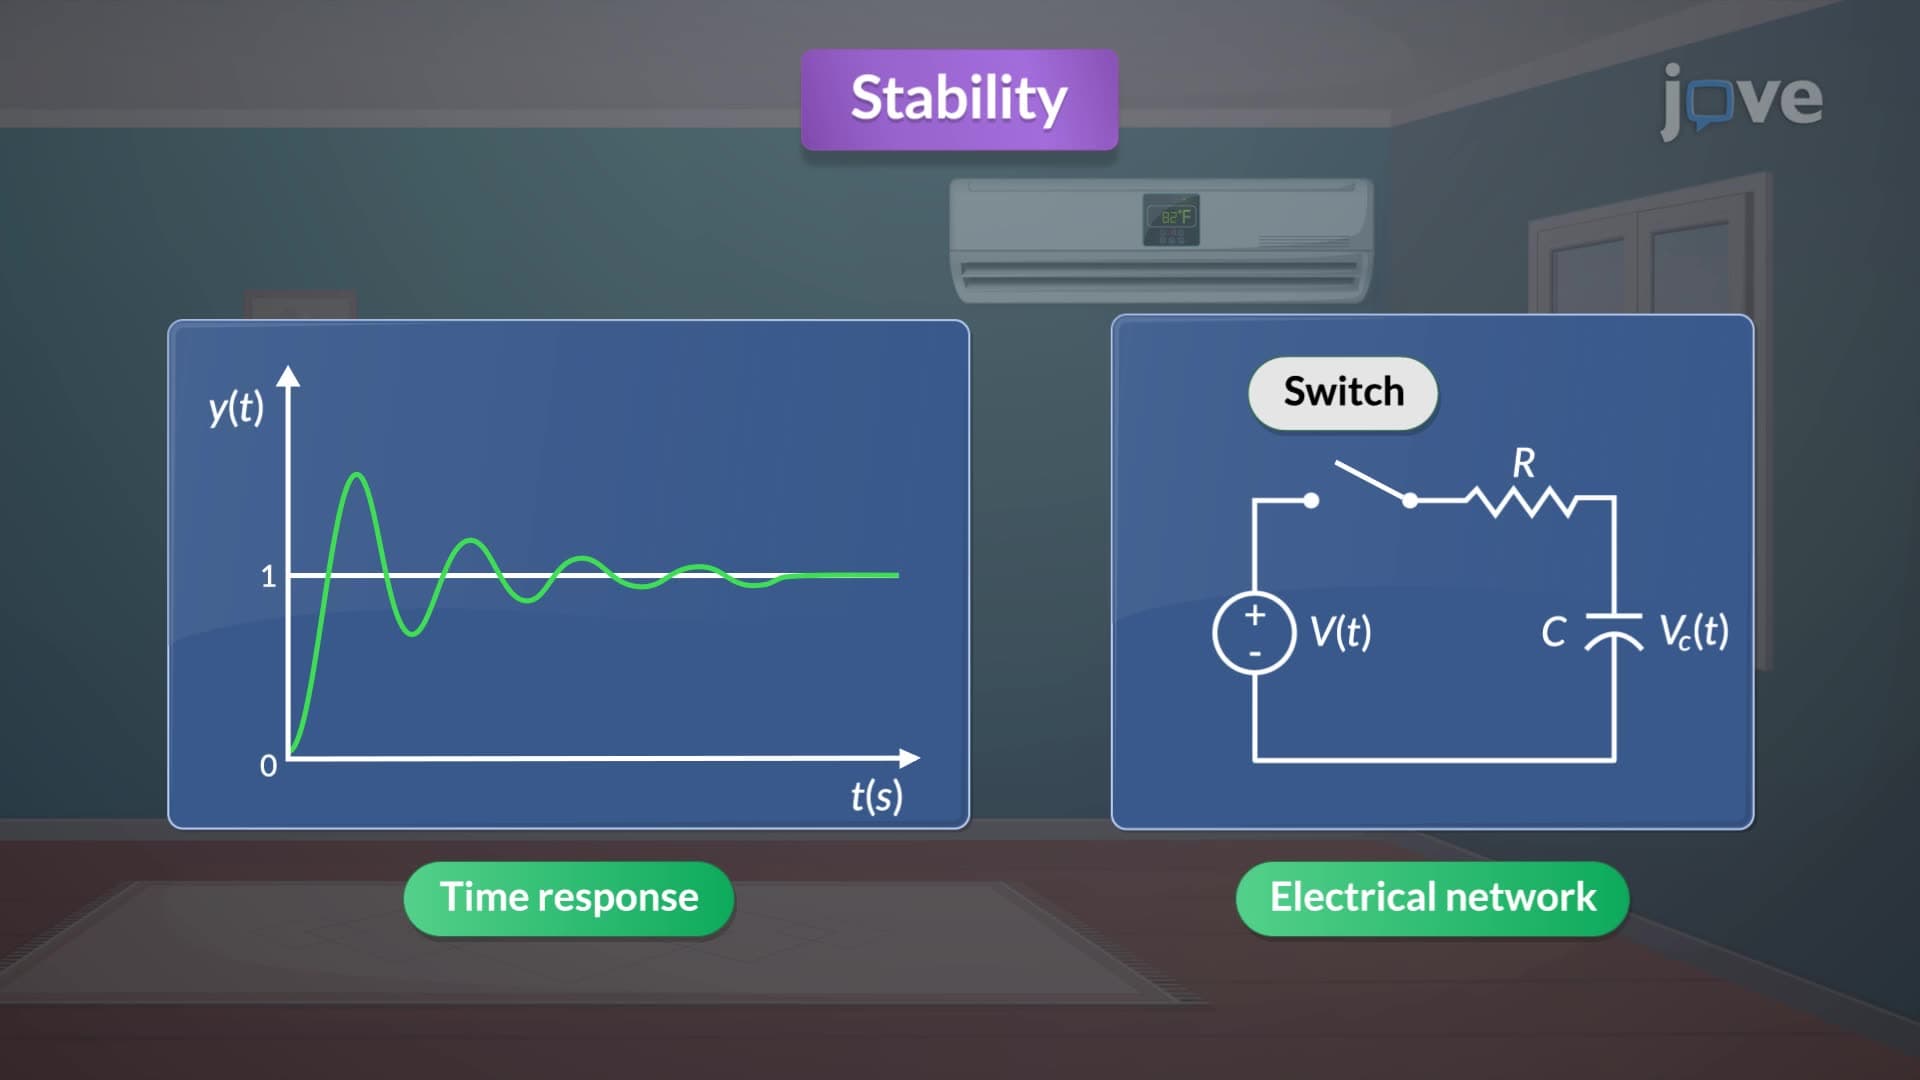
Stability
97
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
97
 01:21
Linear Approximation in Time Domain
70
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
70
 01:24
Pole and System Stability
259
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
259
 01:30
Equations of Equilibrium in Three Dimensions
1.1K
When analyzing structures or systems at rest, it is necessary to ensure they are in equilibrium. This is where the vector and scalar equations of equilibrium come into play. These equations are crucial in ensuring a structure is stable and will not collapse or fall apart. The vector and scalar equations of equilibrium provide a framework for analyzing the forces acting on a body.
According to the vector equations of equilibrium, the vector sum of all the external forces acting on a body must...
According to the vector equations of equilibrium, the vector sum of all the external forces acting on a body must...
1.1K
 01:24
Absolute Motion Analysis- General Plane Motion
218
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
218
 01:23
Stability of Equilibrium Configuration
442
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
442