
具有单项系数的顺序分数微分方程的边界问题
1School of Mathematics and Statistics, Heze University, Heze City, Shandong Province, 274000, PR China.
Heliyon
|September 16, 2024

概括
本研究研究了序列分数次序微分方程的非线性边界值问题. 我们为这些复杂的数学模型建立存在条件并分析Ulam-Hyers稳定性.
科学领域:
- 数学 数学 是一个数学.
- 应用数学 应用数学 应用数学
- 微分方程 微分方程 微分方程
背景情况:
- 分数阶微分方程越来越多地用于模拟复杂的现象.
- 非线性边界值问题带来了重大的分析挑战.
研究的目的:
- 分析具有单项系数的序列分数顺序微分方程.
- 为解决这些非线性边界问题建立存在标准.
- 为了研究溶液的乌兰-海尔斯稳定性.
主要方法:
- 将微分方程问题转换为等效积分方程.
- 收缩映射原理的应用.
- 使用克拉斯诺塞尔斯基的固定点定理.
主要成果:
- 解决方案的两个不同的存在条件被推导出来.
- 解决方案的Ulam-Hyers稳定性得到了成功的调查.
- 一个实践示例证明了理论发现的适用性.
结论:
- 该研究提供了一个严格的数学框架,用于分析特定类的分数次序微分方程.
- 已确定的存在和稳定性结果有助于对这些模型的理论理解.
- 展示的插图证实了开发的方法的实际相关性.
相关概念视频
 01:19
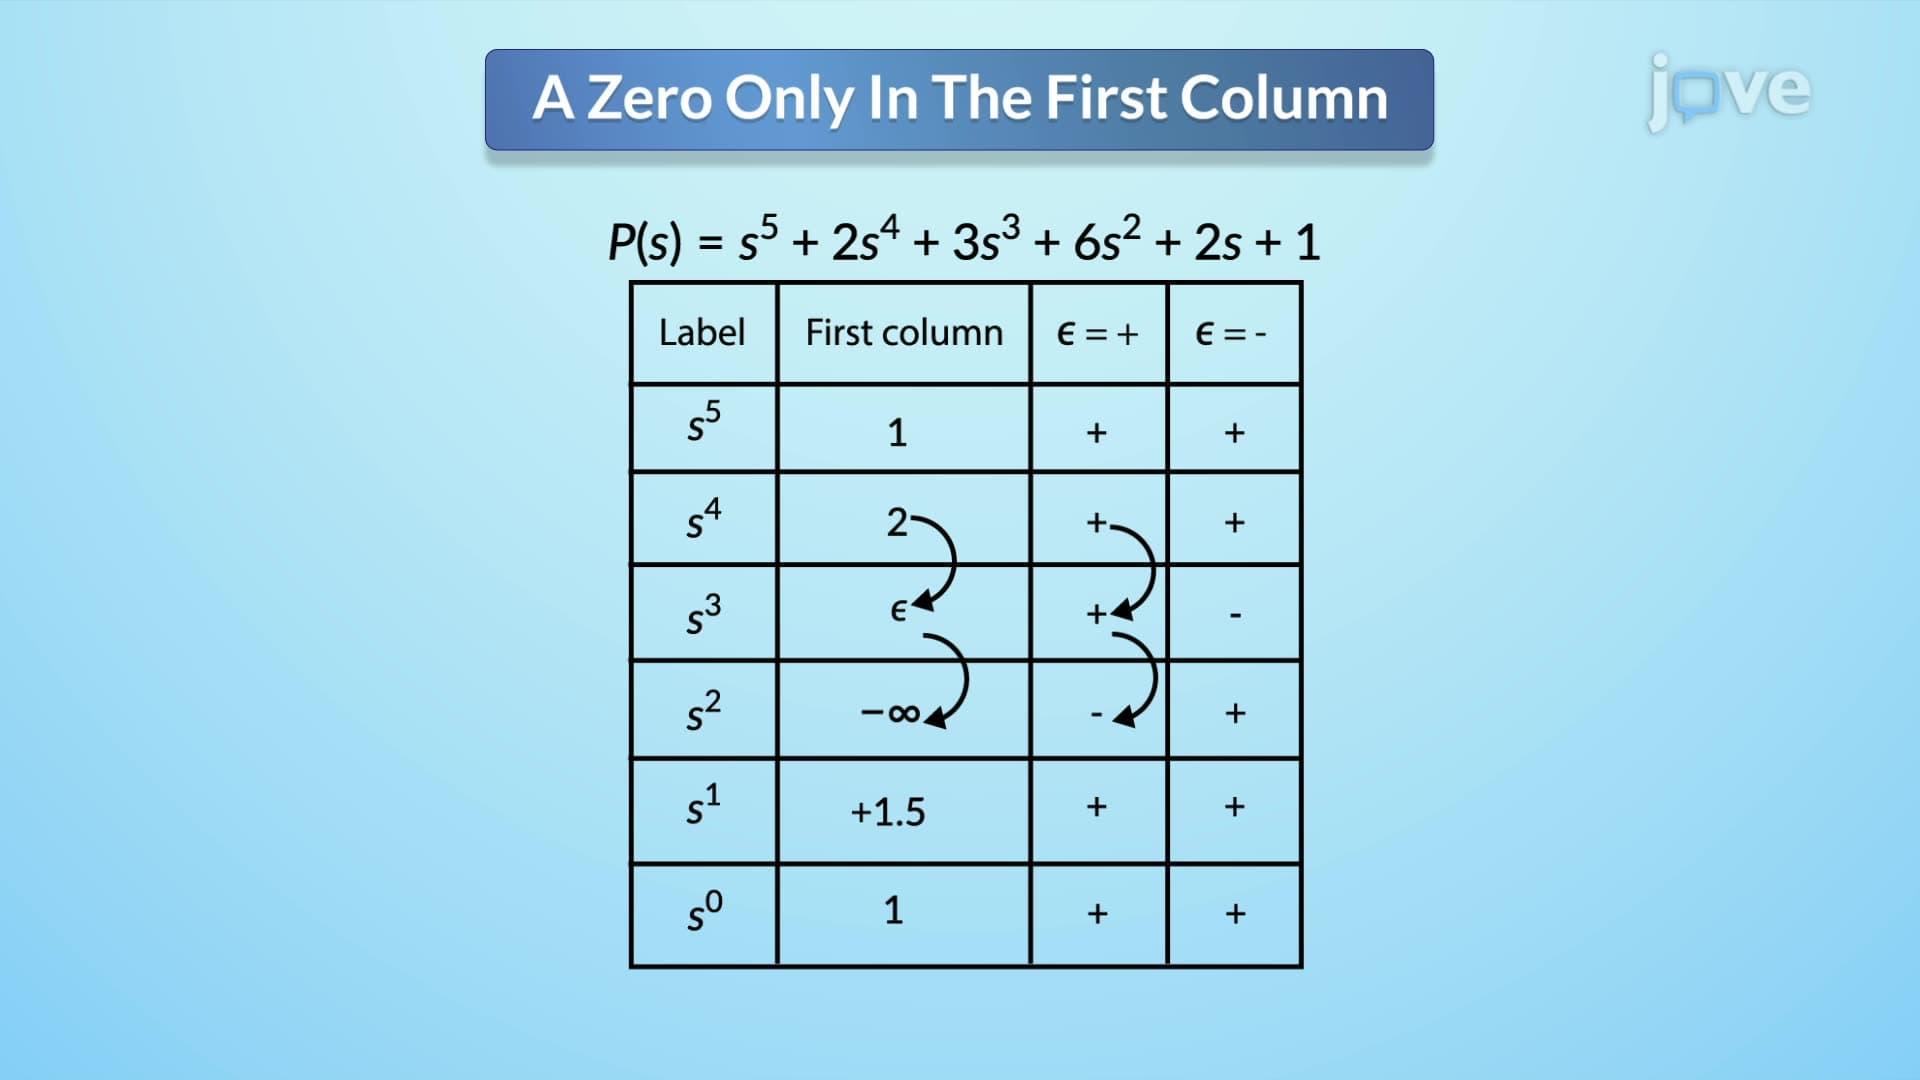
Routh-Hurwitz Criterion II
203
In the application of the Routh-Hurwitz criterion, two specific scenarios can arise that complicate stability analysis.
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
203
 01:26
Transmission-Line Differential Equations
244
Transmission lines are essential components of electrical power systems. They are characterized by the distributed nature of resistance (R), inductance (L), and capacitance (C) per unit length. To analyze these lines, differential equations are employed to model the variations in voltage and current along the line.
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
244
 01:21
Linear Approximation in Time Domain
70
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
70
 01:24
Difference Equation Solution using z-Transform
270
The z-transform is a powerful tool for analyzing practical discrete-time systems, often represented by linear difference equations. Solving a higher-order difference equation requires knowledge of the input signal and the initial conditions up to one term less than the order of the equation.
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
270
 01:26
Linear Approximation in Frequency Domain
88
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
88
 01:18
Second Order systems II
93
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
93