相关实验视频
Updated: Jun 12, 2025

07:09

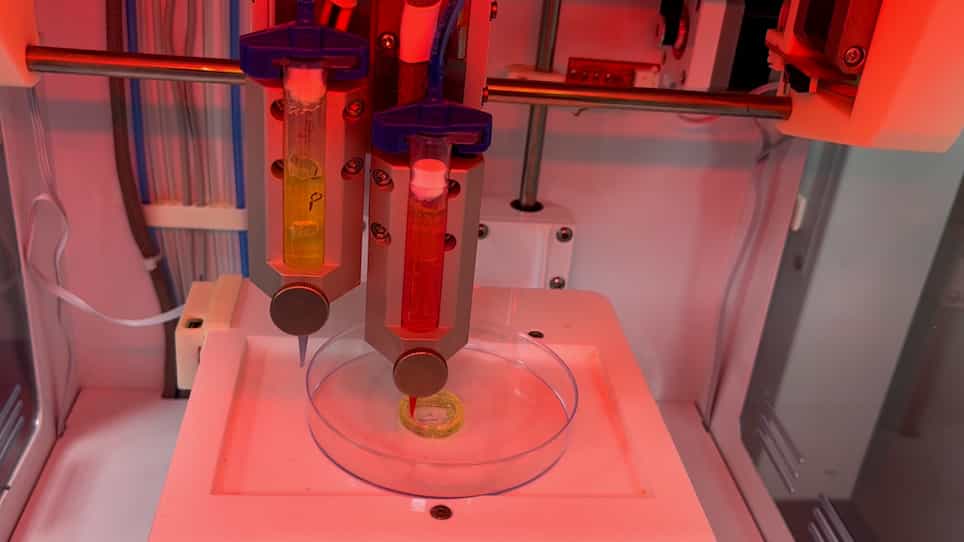
Fabrication of Soft Pneumatic Network Actuators with Oblique Chambers
Published on: August 17, 2018
9.0K
使用多层型软气动执行器的软硬混合动力反转和镜连接:设计,表征和其作为软硬混合动力抓手的应用
Peter Seungjune Lee1, Cameron Sjaarda1, Run Ze Gao1
1Department of Mechanical and Mechatronics Engineering, University of Waterloo, Waterloo, Canada.
Soft robotics
|September 20, 2024

概括
本研究介绍了使用多层形软气动执行器 (MBSPA) 的软硬混合动力 (SRH) 机器人系统. 这些系统提高了实用的软机器人应用的耐用性和性能.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 材料科学 材料科学 材料科学
- 机械工程 机械工程
背景情况:
- 软机器人提供了先进的功能,但面临着实际的整合挑战.
- 现有的软气动执行器 (SPA) 在有效载荷,耐用性和环境弹性方面存在局限性.
- 软机器人的广泛应用受到设计和集成复杂性的阻碍.
研究的目的:
- 开发和评估使用多层形软气动执行器 (MBSPAs) 的软硬混合动力 (SRH) 机器人系统.
- 克服软气动执行器 (SPA) 的常见局限性,包括有限的有效载荷容量和脆弱性.
- 为了提高软机器人组件的性能,耐用性和环境弹性,用于现实世界的应用.
主要方法:
- 开发了一种独特的SRH旋转关节,使用单个热塑性聚氨-MBSPA和刚性部件.
- 实施有限元法 (FEM) 建模用于执行器性能估计和设计.
- 执行器性能的表征,包括排位,频率响应,耐用性 (25,000 个周期),输出力,刚性和功率密度.
主要成果:
- 拟议的SRH系统证明了更好的排位效率,力输出和对外部负载的弹性.
- 刚性元件封装和保护MBSPA,稳定运动并增强耐用性和可重复性.
- 通过FEM建模,使用有限的材料数据,绕过试验和错误,促进了MBSPA设计.
- 一个概念验证的三点抓手在处理各种大小和形状的物体方面表现出了多功能性.
结论:
- 开发的SRH系统为推进软机器人技术向实际,现实应用提供了坚实的基础.
- 这种混合方法解决了传统SPA的关键局限性,为更安全,更有效的自动化系统铺平了道路,特别是在农业中.
- 这项研究强调了先进机器人系统与人类工作流程无整合的潜力.

相关概念视频
 01:27
Support Reactions in Three Dimensions
938
Support reactions in three dimensions help maintain the stability and equilibrium of various structures and systems. These reactions prevent the system from translating and rotating, ensuring the design can withstand external forces and perform its intended function efficiently and safely. Some of the supports providing support reactions in three dimensions are discussed below:
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
938
 01:22
Mechanical Systems
178
Mechanical systems are analogous to to electrical networks where springs and masses play similar roles to inductors and capacitors, respectively. A viscous damper in mechanical systems functions similarly to a resistor in electrical networks, dissipating energy. The forces acting on a mass in such systems include an applied force in the direction of motion, counteracted by forces from the spring, a viscous damper, and the mass's acceleration. This interplay of forces is mathematically...
178
 01:19
Members Made of Elastoplastic Material
94
The behavior of elastoplastic materials under bending stresses, particularly in structural members with rectangular cross-sections, is crucial for predicting material responses and understanding failure modes. Initially, when a bending moment is applied, the stress distribution across the section follows Hooke's Law and is linear and elastic. This distribution means the stress increases from the neutral axis to the maximum at the outer fibers, up to the elastic limit.
As the bending moment...
As the bending moment...
94
 01:20
Plastic Deformation in Circular Shafts
181
When materials are subjected to forces that surpass their yield strength, they undergo a process known as plastic deformation. This results in a permanent alteration or strain in their structure. This concept can be specifically applied to circular shafts, where the deformation leads to a change in its shape. The precise evaluation of this plastic deformation requires understanding the stress distribution within the circular shaft, which is achieved by calculating the maximum shearing stress in...
181
 01:24
Circular Shafts - Elastoplastic Materials
100
The study of solid circular shafts under stress shows that within the elastic limit, stress increases directly to the distance from the shaft's center. This relationship holds until the shaft reaches a critical point of stress, beyond which it begins to yield, marking the transition from elastic to plastic deformation. At this crucial juncture, the maximum torque the shaft can endure without permanent deformation is determined, signifying the limit of its elastic behavior.
As torque on the...
As torque on the...
100
 01:06
Virtual Work for a System of Connected Rigid Bodies
371
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
371