用肌肉控制的鸟类运动物理模拟解决了接地运行悖论
Pasha A van Bijlert1,2, A J van Soest3, Anne S Schulp1,2
1Department of Earth Sciences, Faculty of Geosciences, Utrecht University, Vening Meinesz Building A, Princetonlaan 8A, 3584 CB Utrecht, Netherlands.
Science advances
|September 25, 2024

概括
鸟类的跑步方式与人类不同,它们更喜欢"接地跑步"的风格. 这项研究表明,这种看似昂贵的步态实际上是鸟类的最佳状态,因为它们具有独特的解剖学,可能是从恐龙进化而来的.
科学领域:
- 生物力学 生物力学
- 古生物学的古生物学
- 进化生物学 进化生物学
背景情况:
- 鸟类在中等速度时表现出一种独特的跑步方式,称为"接地跑",其中至少有一只脚与地面保持接触.
- 这种鸟类的跑步方式具有悖论性,因为与其他步态相比,它需要更高的能源成本,但鸟类更喜欢它.
- 了解鸟类运动的进化和生物力学基础对于破译灭绝物种的功能形态至关重要.
研究的目的:
- 为了解决为什么鸟类更喜欢能源昂贵的接地跑的悖论.
- 从能量和肌肉激发的角度来看,确定接地跑步是否是鸟类的最佳步态.
- 为了研究鸟类在非鸟类恐龙中接地运行的进化起源.
主要方法:
- 使用以 (Dromaius novaehollandiae) 为模型生物的预测步态模拟被采用.
- 虚拟实验分离了姿势和肌弹性的影响,以分离生物力学因素.
- 模拟分析了能量和肌肉刺激,以评估步态的最佳性.
主要成果:
- 据证明,接地跑步是鸟类的最佳步态,考虑到能量和肌肉刺激.
- 鸟类的体型规划,防止近垂直的腿部姿势,使人像跑步不可能.
- 在肌肉在缩姿势中产生峰值力量的解剖限制下,接地跑步是最佳的,这对于鸟类来说是典型的.
结论:
- 鸟类接地跑是一种能量和生物机械最佳步态,解决了其明显高成本的悖论.
- 鸟类独特的解剖学需要这种跑步风格,使得类似人类的步态不可行.
- 共同的解剖学特征表明,接地跑步行为可能是在非鸟类恐龙中演变的.
相关概念视频
 01:21
Rigid Body Equilibrium Problems - II
7.0K
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
7.0K
 00:49
Rigid Body Equilibrium Problems - I
4.4K
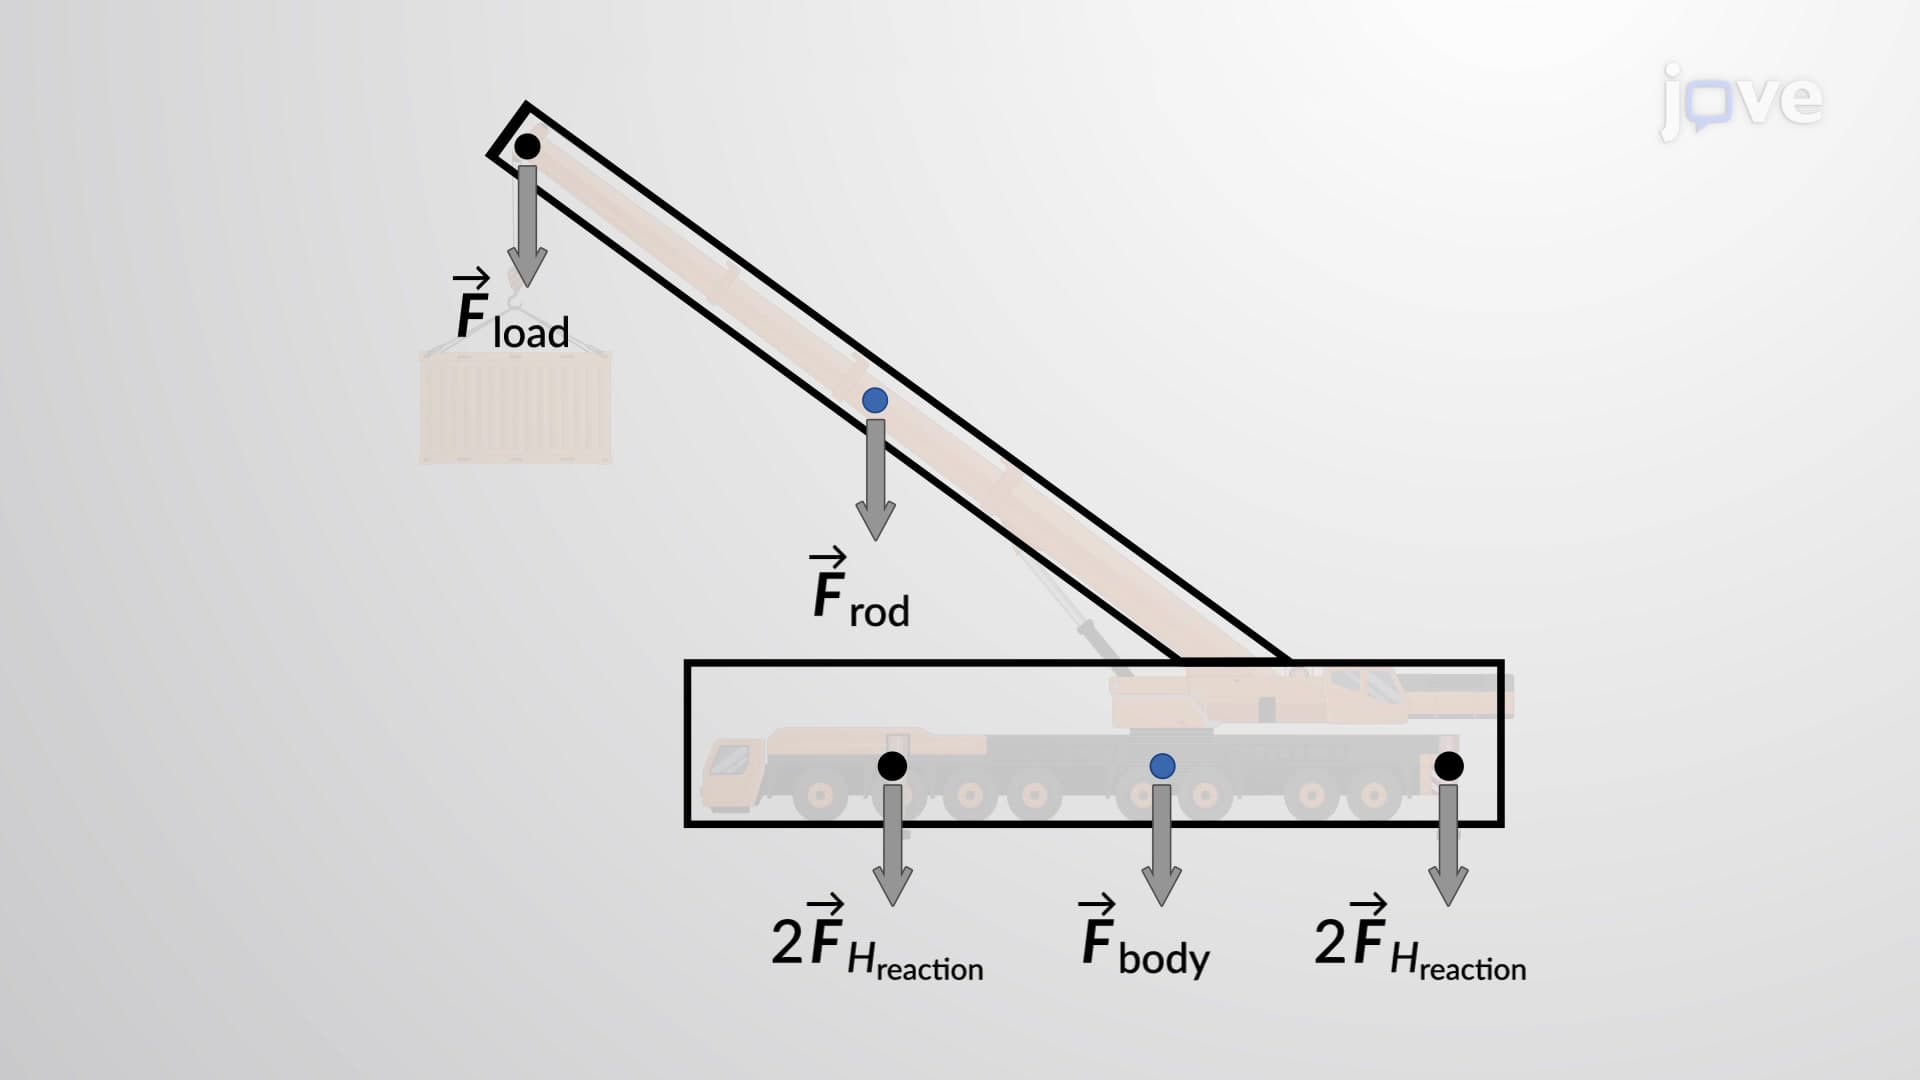
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
4.4K
 01:17
Kinematic Equations - II
9.4K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.4K
 01:15
Kinematic Equations: Problem Solving
12.0K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
12.0K
 01:18
Kinematic Equations - III
7.6K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.6K
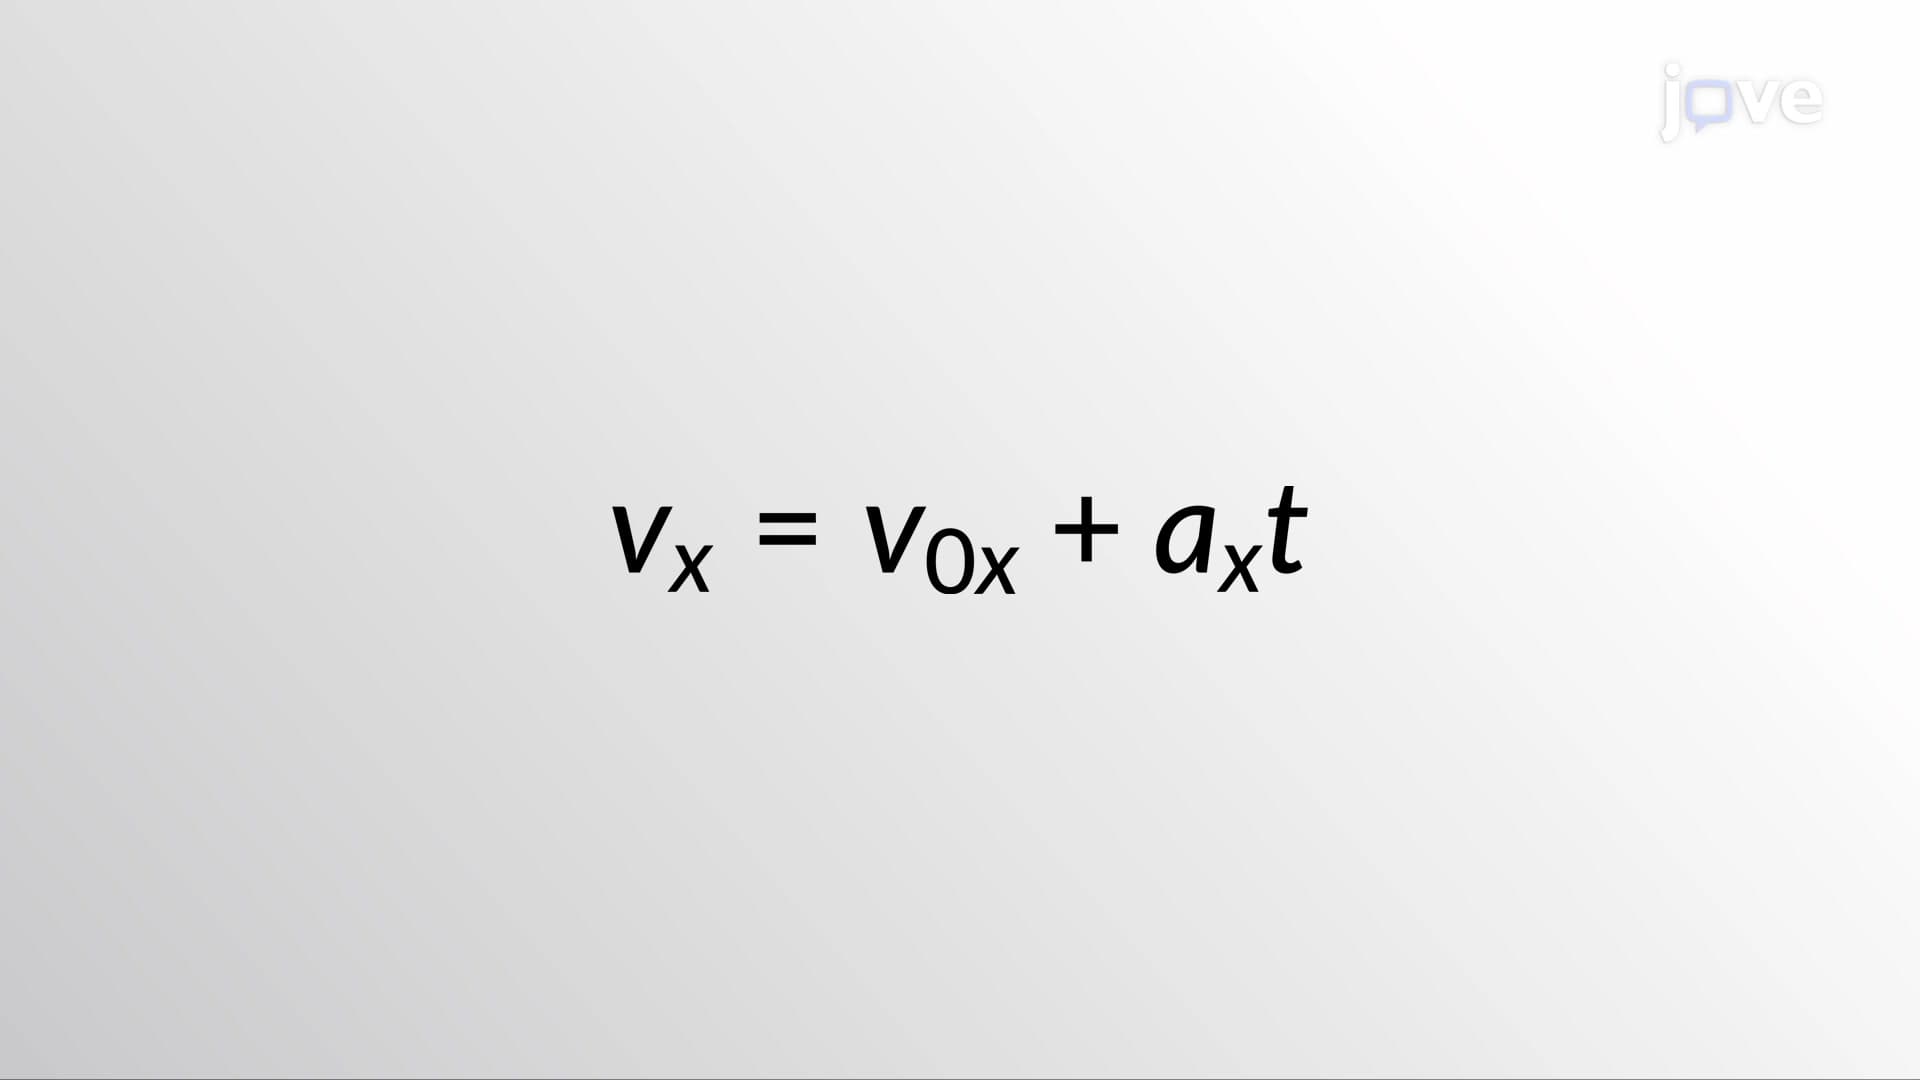 01:26
Kinematic Equations - I
10.5K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.5K