
基于运动的假肢控制与角度轨迹越来越接近自然的手臂协调
Effie Segas1, Vincent Leconte1, Emilie Doat1
1University of Bordeaux, CNRS, INCIA, UMR, 5287 Bordeaux, France.
Biomimetics (Basel, Switzerland)
|September 27, 2024

概括
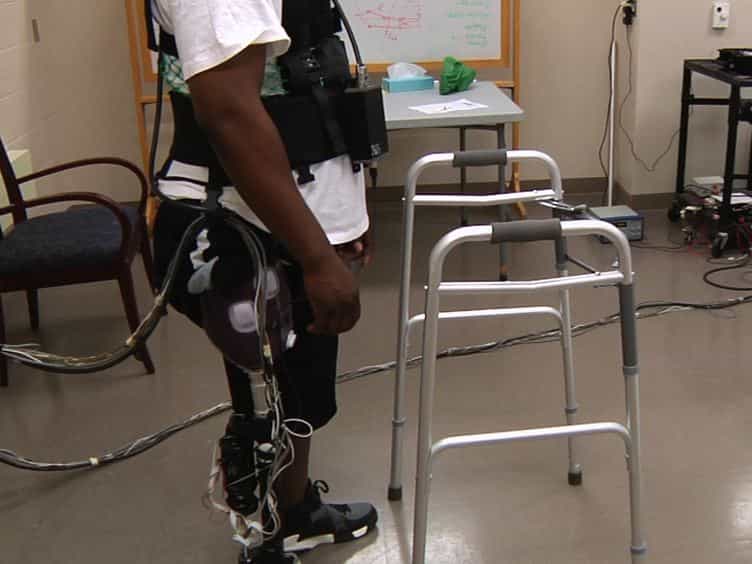
跨部假肢的新型肌电动手控制器提供了更流,更直观的物体抓取. 这些先进的控制适应用户的运动,改善假肢功能,而不会增加截肢者的工作负担.
科学领域:
- 生物医学工程 生物医学工程
- 神经科学是一个神经科学.
- 康复机器人 康复机器人
背景情况:
- 传统的肌电跨关节假肢缺乏对多个自由度的直观控制.
- 之前的人工神经网络 (ANN) 方法使自然手臂的性能能够抓住物体,但导致了不切实际的,突然的假肢运动.
研究的目的:
- 开发和评估新型肌电控制方法,用于消除突然运动的跨部假肢.
- 评估基于角轨迹的新控制器的性能,可用性和工作量,对有和没有肢体损失的参与者进行评估.
主要方法:
- 实施了新的控制算法,使用基于茎移动速度和配置差异的角度轨迹.
- 测试了线下和线上与参与者在循环中的控制,与自然控制条件进行比较.
- 评估的性能指标包括移动时间,物体到达和定位准确性.
主要成果:
- 新的控制器使得参与者,包括那些经过关节失去四肢的人,能够在没有事先训练的情况下有效地触及和定位物体.
- 观察到运动时间略有增加,但对上肢残疾的参与者来说,可用性和工作负载并没有降低.
- 在线和离线测试表明了流,有效的假肢手控制的潜力.
结论:
- 开发的基于角轨迹的肌电控制系统为跨部假肢提供了显著的改进,提供了更流,更直观的操作.
- 这些发现表明,对于上肢损失的个人来说,其具有很高的潜在可接受性和有效性,为更实用的假肢解决方案铺平了道路.

相关概念视频
 01:24
One-Degree-of-Freedom System
466
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
466
 01:11
Angular Momentum about an Arbitrary Axis
193
Imagine a rigid body with a mass denoted as 'm', which has its center of mass at point G and is rotating around an inertial reference frame. The angular momentum at an arbitrary point P can be calculated by taking the cross product of the position vector and linear momentum vector for each individual mass element.
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into...
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into...
193
 01:37
Rotation with Constant Angular Acceleration - I
6.7K
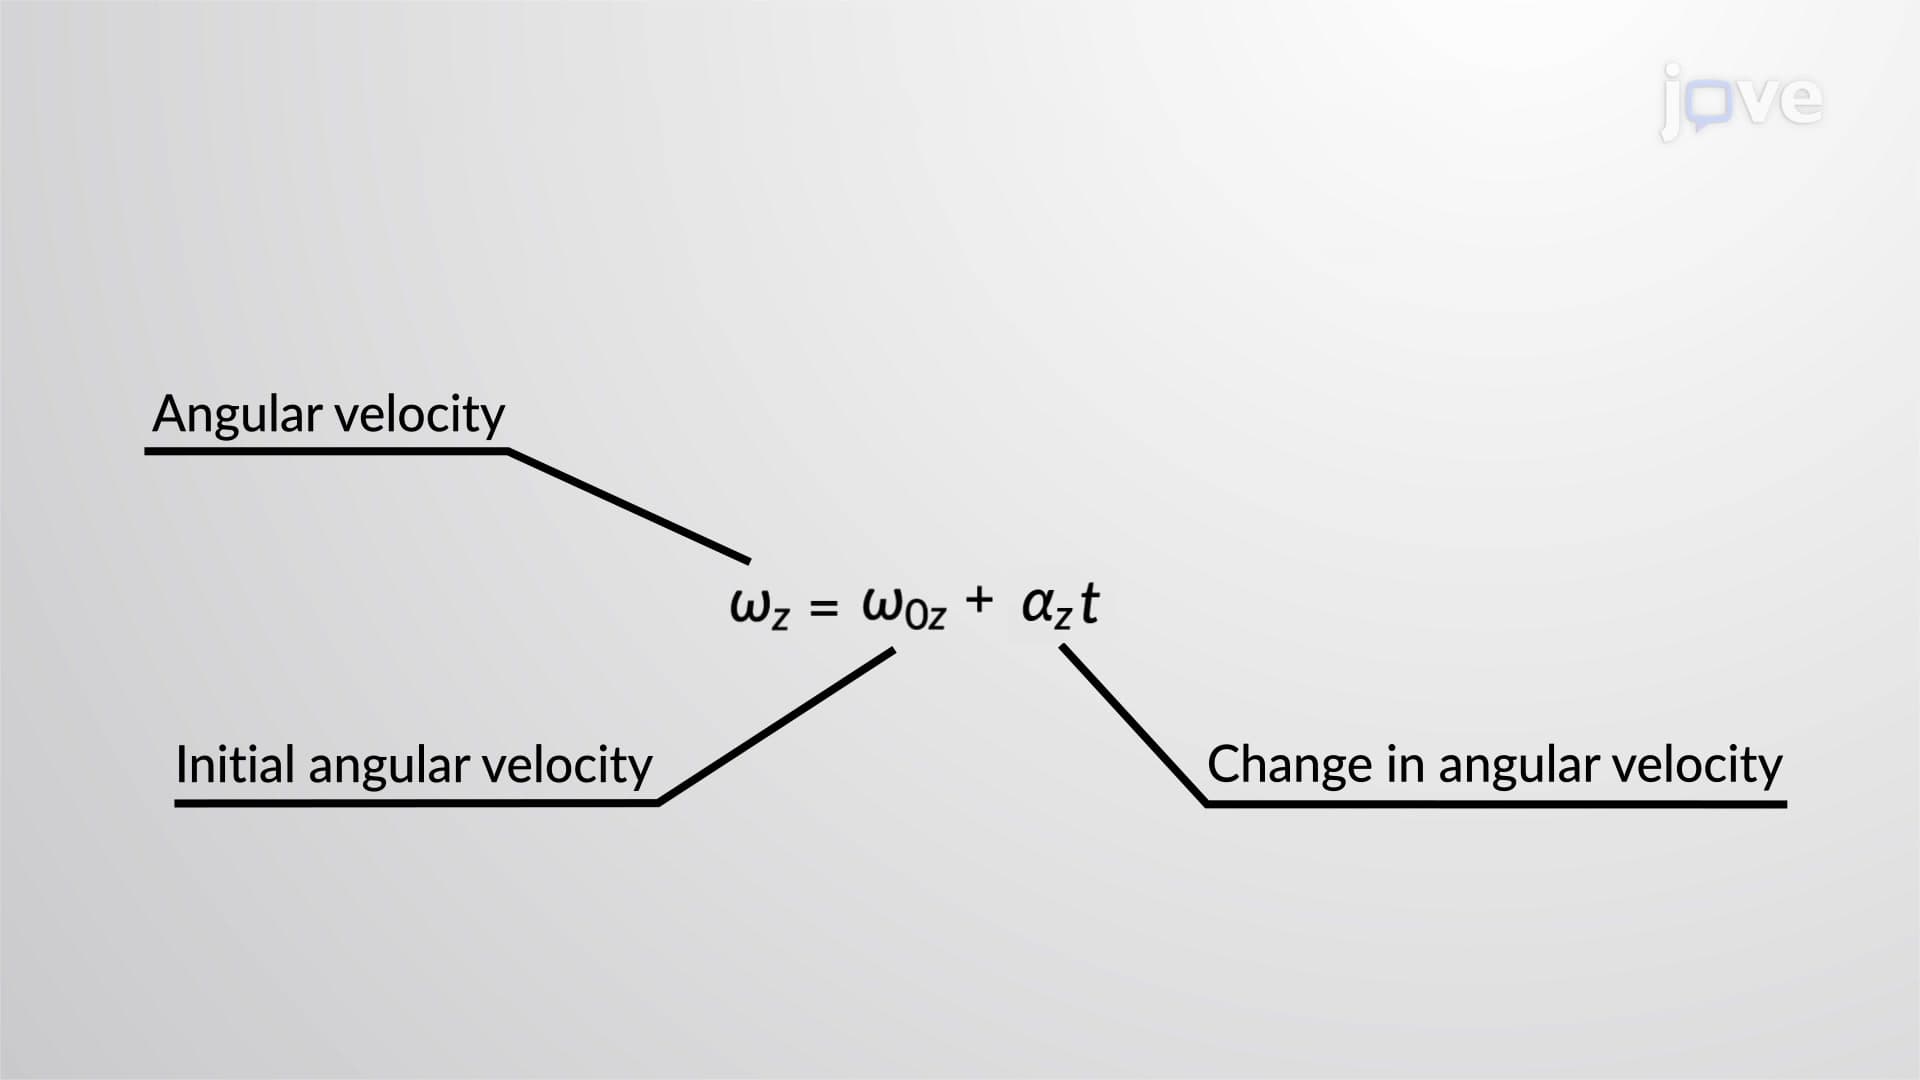
If angular acceleration is constant, then we can simplify equations of rotational kinematics, similar to the equations of linear kinematics. This simplified set of equations can be used to describe many applications in physics and engineering where the angular acceleration of a system is constant.
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
6.7K
 01:16
Rotation with Constant Angular Acceleration - II
6.0K
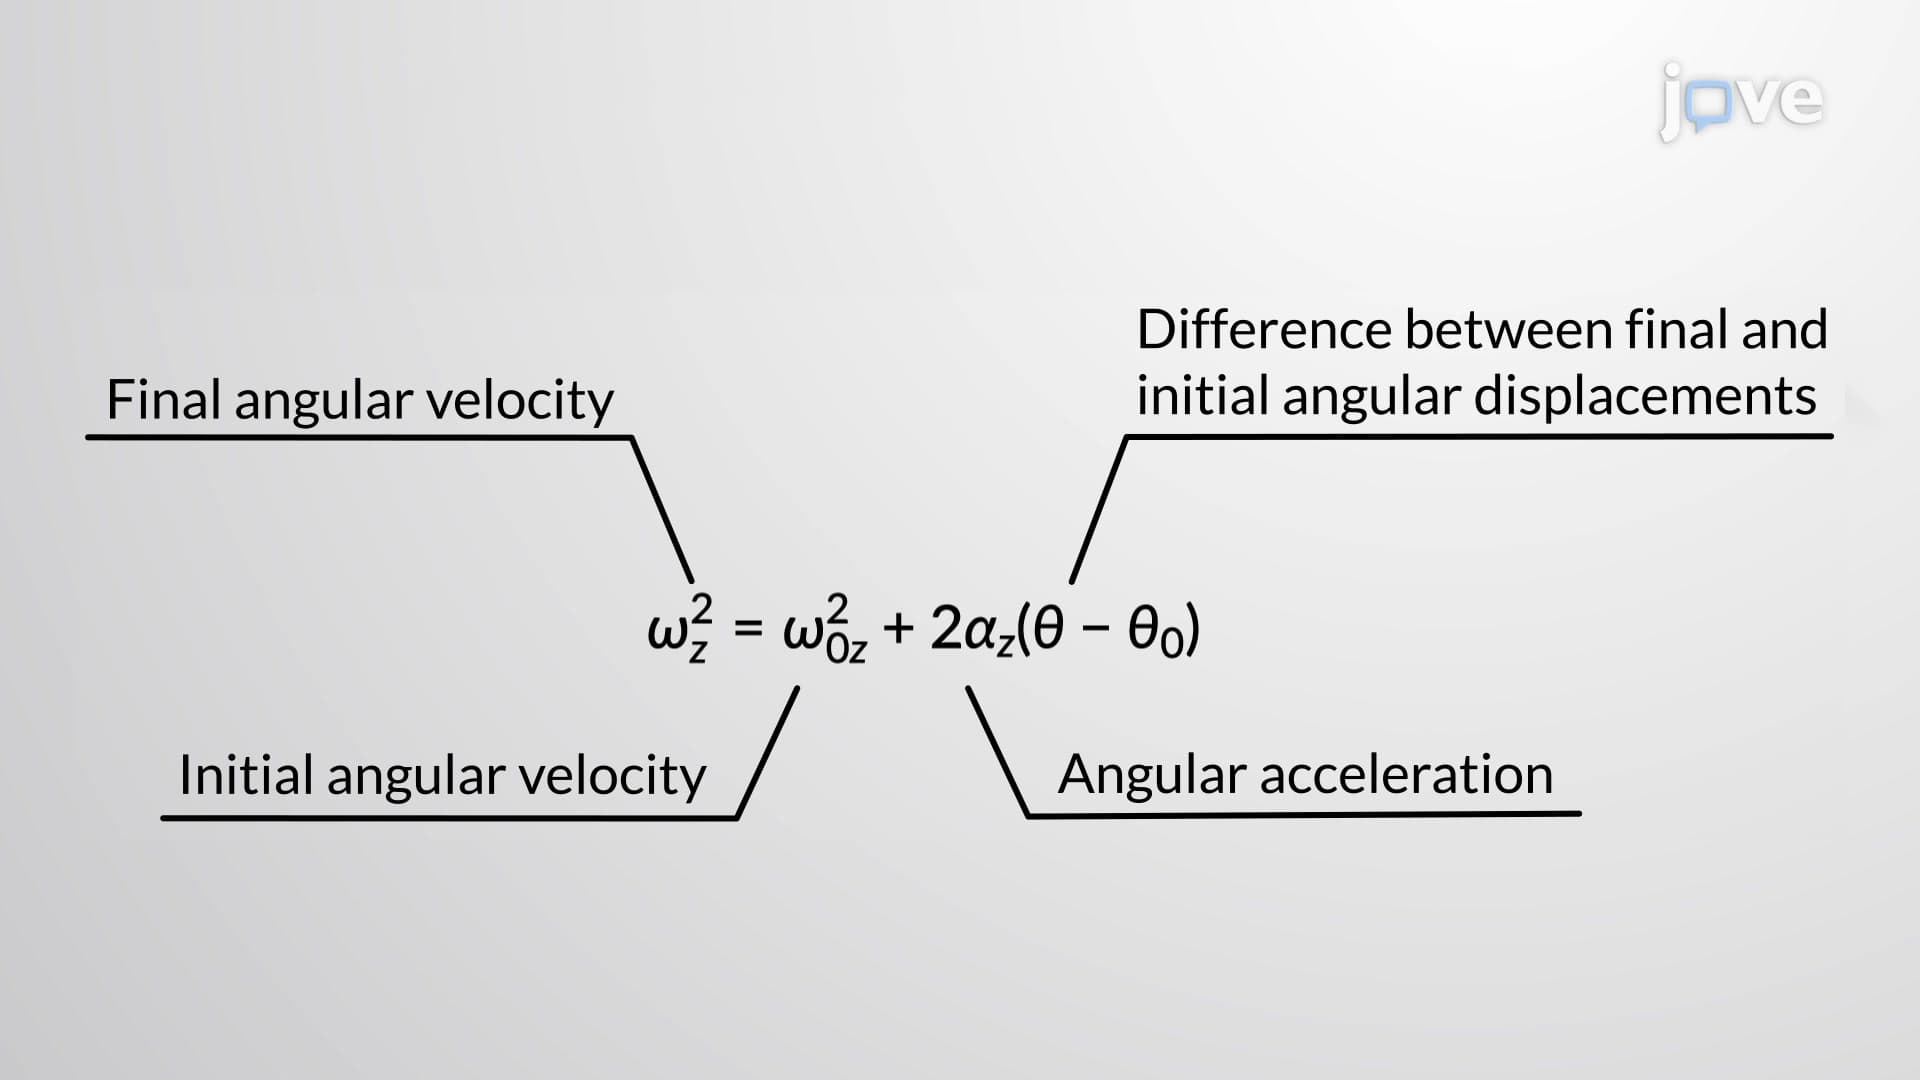
Kinematics is the description of motion. The kinematics of rotational motion discusses the relationships between rotation angle, angular velocity, angular acceleration, and time. One can describe many things with great precision using kinematics, but kinematics does not consider causes. For example, a large angular acceleration describes a very rapid change in angular velocity without any consideration of its cause. Thus, rotational kinematics does not represent the laws of nature.
The first...
The first...
6.0K
 01:24
Muscle Coordination and Action
1.4K
Muscle coordination is a complex and finely tuned process essential for smooth and purposeful movements like flexion, extension, adduction, abduction, and rotation. The human body orchestrates the actions of various muscles working in concert, each with a specific role. Four functional types describe how muscles work together: agonist, antagonist, synergist, and fixator.
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
1.4K
 01:09
Angular Momentum and Principle Axes of Inertia
202
The concept of angular momentum for a solid structure is illustrated as the cumulative result of the cross-product of the position vector of the mass element and the cross-product of the body's angular velocity with the position vector.
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
202