基于深度增强学习的稳定跳跃控制,用于灵感来自虫的机器人
Qijie Zhou1,2, Gangyang Li1,2, Rui Tang1,2
1Intelligent Robotics Institute, School of Mechatronical Engineering, Beijing Institute of Technology, Beijing 100081, China.
Biomimetics (Basel, Switzerland)
|September 27, 2024

概括
本研究介绍了一种稳定的跳跃控制算法,用于使用深度强化学习的虫灵感机器人. 这种新的方法提高了跳跃的准确性和稳定性,使能耗高效的机动.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
- 生物机械工程 生物机械工程
背景情况:
- 生物启发的跳跃机器人提供了先进的移动性,但在跳跃时难以保持姿势稳定.
- 快速的姿势变化大大降低了机器人跳跃运动的准确性和稳定性.
研究的目的:
- 开发一个稳定的跳跃控制算法,用于使用深度强化学习的虫灵感机器人.
- 为了提高腿类机器人跳跃运动的稳定性和准确性.
主要方法:
- 采用了与演员和批评者网络的深度强化学习框架.
- 该算法将机器人的观测结果直接映射到联合扭矩,并将探索的率术语纳入.
- 设计了一个带有阶段激励机制的动态奖励功能,以提高稳定性和准确性.
主要成果:
- 这种以虫为灵感的机器人表现出平滑,非翻转的跳跃,目标距离准确度的误差不到3%.
- 跳跃机车与步行相同的距离相比,消耗的能量减少了44.6%.
- 拟议的算法显示了比经典方法更快的融合和更好的性能.
结论:
- 深度强化学习为稳定和准确的机器人跳跃提供了一种有效的方法.
- 开发的算法显著提高了跳跃机器人的能效和运动能力.
- 这项研究为更灵活,更有效的生物灵感机器人铺平了道路,这些机器人能够跨越复杂的地形.
相关概念视频
 01:16
Hydraulic Jump: Problem Solving
55
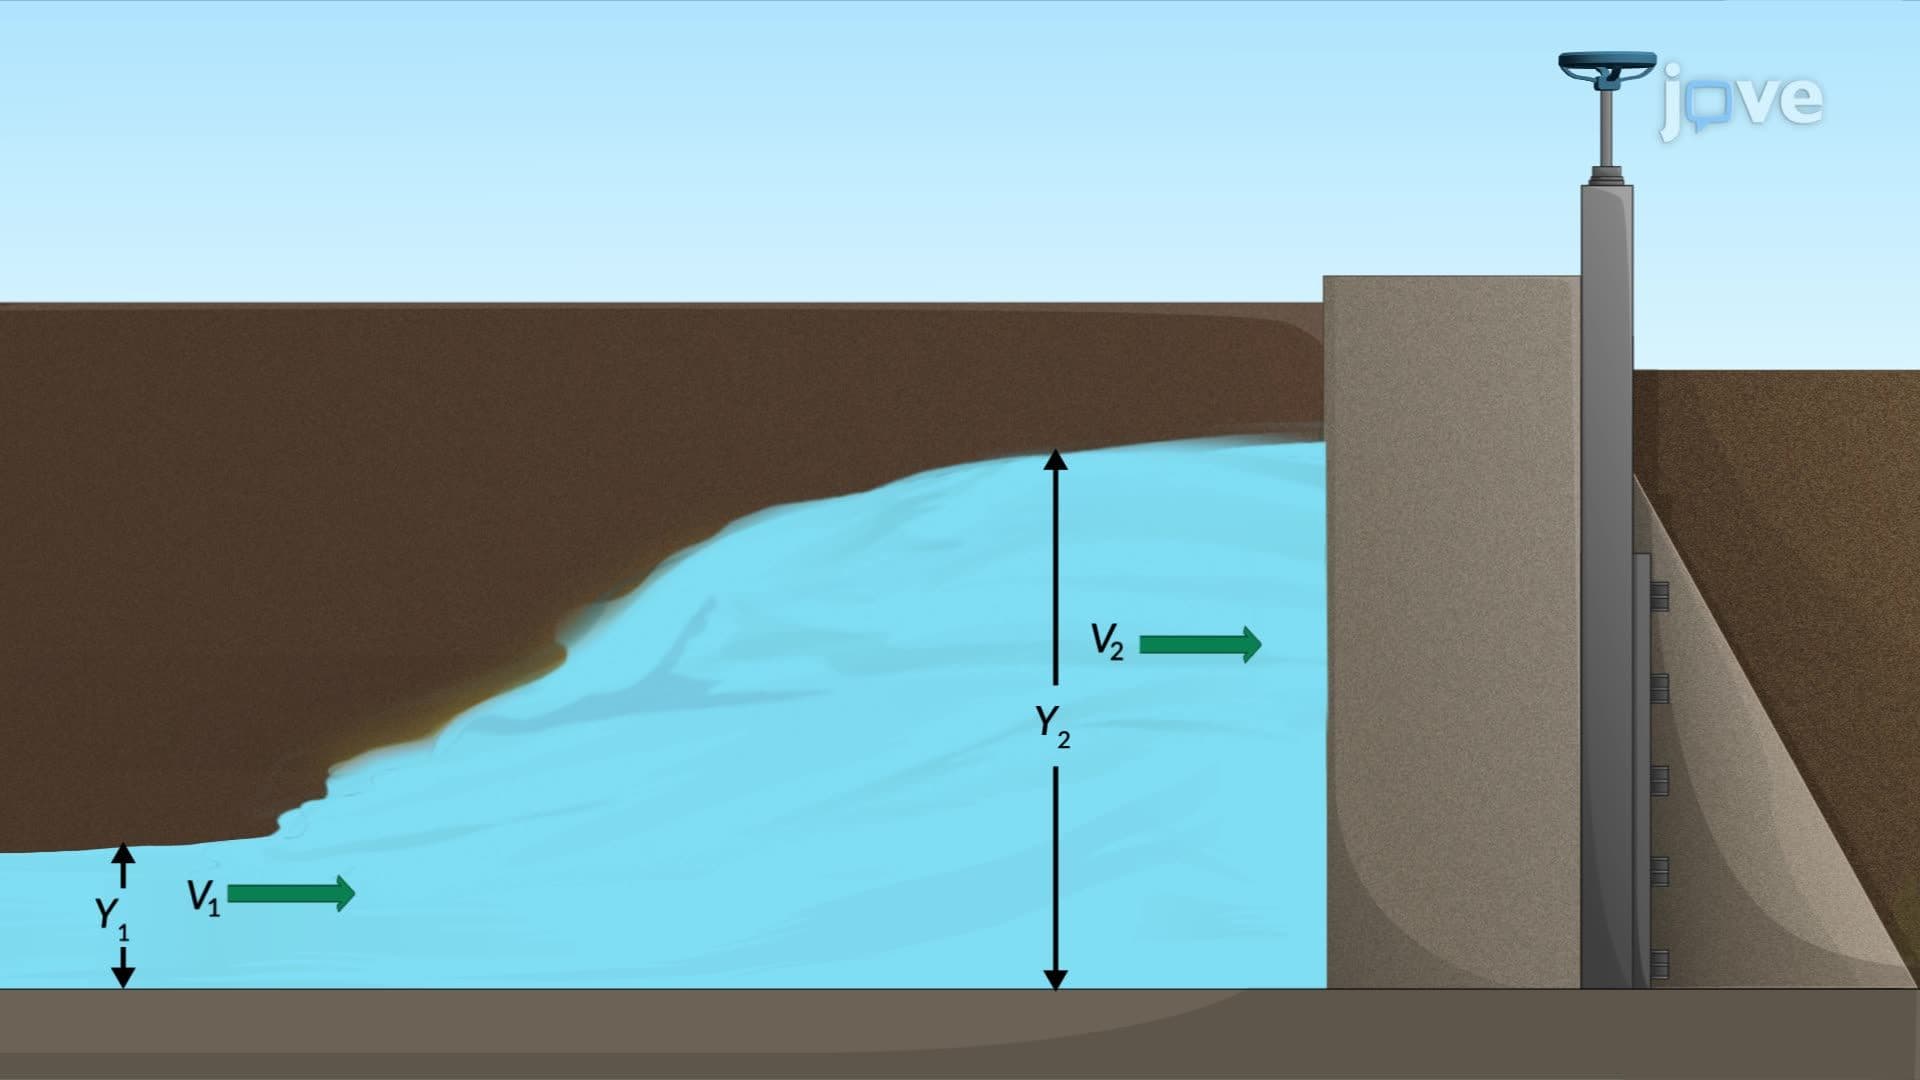
To analyze a hydraulic jump in a rectangular channel with a flow speed of 6 meters per second, follow these steps:Calculate Effective Upstream Velocity:When the downstream gate closes, a hydraulic jump forms, traveling upstream at 2 meters per second. This wave speed combines with the initial channel flow velocity, creating an effective upstream velocity.Identify Flow Velocities Before and After the Hydraulic Jump:Upstream of the hydraulic jump, the effective flow velocity includes both the...
55
 01:23
Reinforcement
186
Positive and negative reinforcement are key concepts in operant conditioning, a learning process where the consequences of a behavior affect the likelihood of that behavior being repeated.
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example:
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example:
186
 01:17
Rolling Resistance: Problem Solving
302
Rolling resistance, also known as rolling friction, is the force that resists the motion of a rolling object, such as a wheel, tire, or ball, when it moves over a surface. It is caused by the deformation of the object and the surface in contact with each other, as well as other factors like internal friction, hysteresis, and energy losses within the materials. Rolling resistance opposes the object's motion, requiring additional energy to overcome it and maintain movement. In practical...
302
 01:12
Observational Learning
149
Albert Bandura's observational learning, also known as imitation or modeling, occurs when a person observes and imitates another's behavior. It is a quicker process than operant conditioning. A well-known example is the Bobo doll study, where children who saw an adult acting aggressively towards the doll were more likely to act aggressively when left alone, compared to those who observed a nonaggressive adult. Many psychologists view observational learning as a form of latent learning...
149
 01:17
Open and closed-loop control systems
678
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
678
 01:14
Avoidance Learning and Learned Helplessness
1.7K
Avoidance learning and learned helplessness are critical concepts in understanding behavioral responses to negative stimuli.
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
1.7K