
空间冗余执行并行机制中的反向动力学公式的比较,受两个点接触高动力学对的约束
Chen Cheng1, Xiaojing Yuan1, Yenan Li1
1Laboratory of Mechatronics, Xi'an College of Technology, Xi'an 710025, China.
Biomimetics (Basel, Switzerland)
|September 27, 2024

概括
这项研究模拟了一个空间冗余激活并行机制 (RAPM),灵感来自人类的. 不同的动态建模方法揭示了更高的动力学对 (HKP) 约束如何影响机制行为和计算效率.
科学领域:
- 机器人和生物力学
- 机械工程 机械工程
- 运动学和动力学.
背景情况:
- 设计了一种新的空间冗余激活并行机制 (RAPM),灵感来自人类的.
- 该机制的终端效应器模仿下,有六个动力链代表肌和关节作为更高的动力对 (HKP) 约束.
研究的目的:
- 描述设计RAPM的受约束运动.
- 使用多种建模方法探索RAPM的刚体逆动力学.
- 为了比较由此产生的动态模型,并分析HKP约束的影响.
主要方法:
- 使用牛顿-欧勒定律,拉格朗日方程和虚拟工作原理,制定了五种动态模型.
- 分析了RAPM的逆动力学,考虑了来自HKPs的约束力和球形关节的反应力.
- 对不同模型的计算成本进行了比较,包括使用非冗余执行对应器的动态模型的模型.
主要成果:
- 牛顿-欧勒模型准确地表示来自HKPs的约束力,显示反应力对动力链数的依赖性.
- 拉格朗奇和虚拟工作模型忽略了约束和反应力,从而减少了方程和未知数.
- 基于非冗余执行对应的模型显示,计算成本显著降低 (16.7%和36.63%).
结论:
- 选择动态建模方法显著影响最终的模型结构和约束力表示.
- 在RAPM中的HKP约束引入复杂性并改变与非冗余执行机制相比的模型结构.
- 该研究强调了模型忠实性,计算效率和明确包含约束力之间的权衡.

相关概念视频
 01:22
Mechanical Systems
178
Mechanical systems are analogous to to electrical networks where springs and masses play similar roles to inductors and capacitors, respectively. A viscous damper in mechanical systems functions similarly to a resistor in electrical networks, dissipating energy. The forces acting on a mass in such systems include an applied force in the direction of motion, counteracted by forces from the spring, a viscous damper, and the mass's acceleration. This interplay of forces is mathematically...
178
 01:23
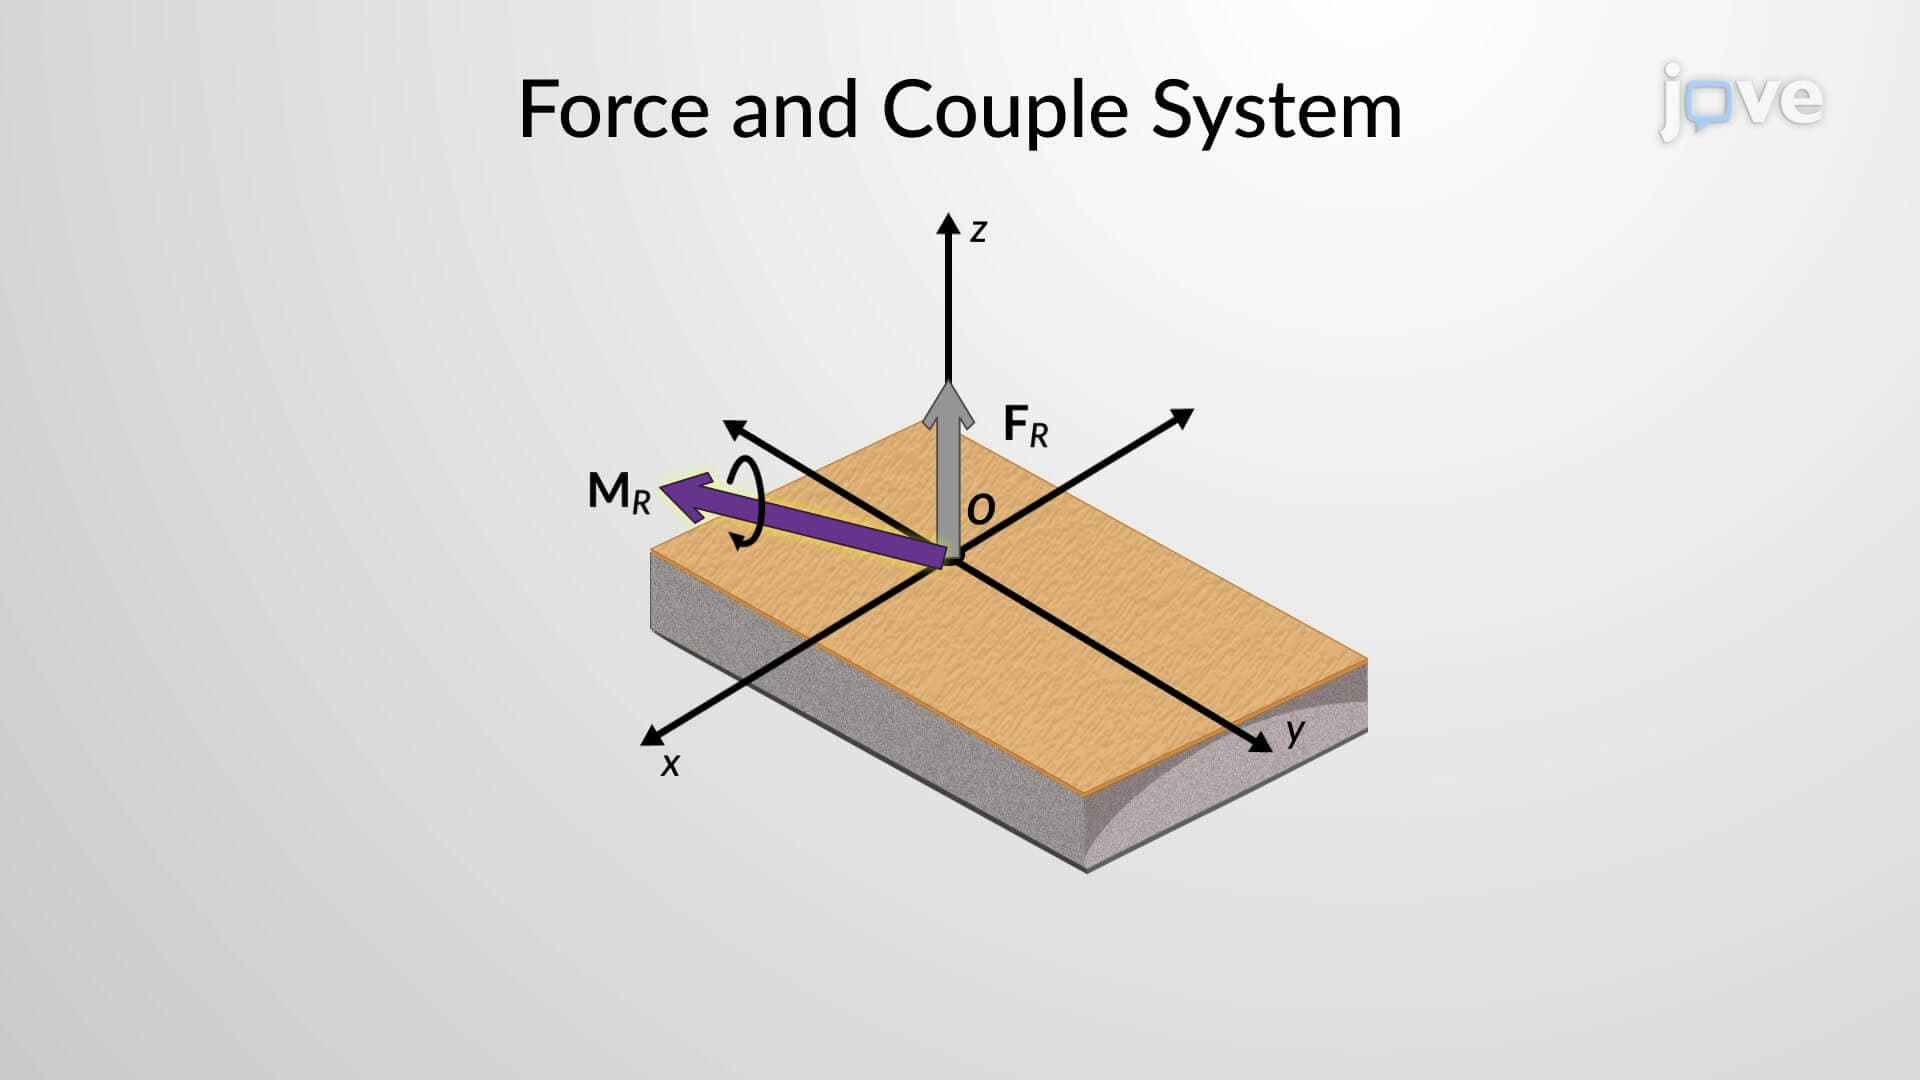
Simplification of a Force and Couple System: II
273
In a three-dimensional system, multiple forces can act on an object. These forces can be combined into a single equivalent force, known as the resultant force. Similarly, the moments generated by these forces can be combined into a single equivalent moment, the resultant couple moment. In certain situations, these two entities may not be mutually perpendicular, meaning they do not have a 90-degree angle between them. This unique condition requires a deeper understanding of the interplay between...
273
 01:17
Kinematic Equations - II
9.4K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.4K
 01:10
Relative Motion Analysis - Acceleration
341
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
341
 01:18
Kinematic Equations - III
7.6K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.6K
 01:24
Relative Motion Analysis - Velocity
343
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
343