
非线性振荡动态系统的分支图:一维,二维和三维的简要回顾
Wieslaw Marszalek1, Maciej Walczak1
1Department of Computer Science, Opole University of Technology, 45-758 Opole, Poland.
Entropy (Basel, Switzerland)
|September 27, 2024

概括
本研究探讨了非线性动态系统的1D,2D和3D分支图,使用混乱的0-1测试来分析电弧和细胞质系统. 这项研究比较了分类混乱和周期性行为的各种方法.
科学领域:
- 非线性动力学是一种非线性动力学.
- 混沌理论 混沌理论
- 时间序列分析时间序列分析
背景情况:
- 非线性动态系统表现出复杂的行为,包括周期性和混乱的反应.
- 描述这些行为对于理解诸如电弧和细胞质信号传递等系统至关重要.
- 分析动态系统的传统方法可能很复杂,需要详细的模型.
研究的目的:
- 研究和比较非线性动态系统的1D,2D和3D分叉图.
- 评估 0-1 混沌测试和其他分类系统行为方法的有效性.
- 为时间序列分析提供图表技术的全面审查.
主要方法:
- 利用 0-1 混沌测试生成 K 值,区分周期性 (K ≈0) 和混乱 (K ≈1) 反应.
- 采用样本 (SaEn) 分析来进一步描述系统动态.
- 构建并比较电弧和细胞质系统的1D,2D和3D分叉图.
主要成果:
- 证明了 0-1 测试中的 K 值在识别不同维度图的周期和混乱模式中的实用性.
- 展示了样本的应用在可视化复杂的动态,特别是在3D分叉图.
- 通过不同的方法生成的图表进行了比较分析,突出了它们的相似性和差异.
结论:
- 1D,2D和3D分叉图,特别是那些来自0-1测试的图,是对非线性系统行为进行分类的有效工具.
- 该研究提供了各种时间序列分类分析方法的宝贵比较概述.
- 了解不同图形类型的优缺点有助于为模拟和未知系统选择合适的分析技术.
相关概念视频
 01:23
Root Loci for Positive-Feedback Systems
106
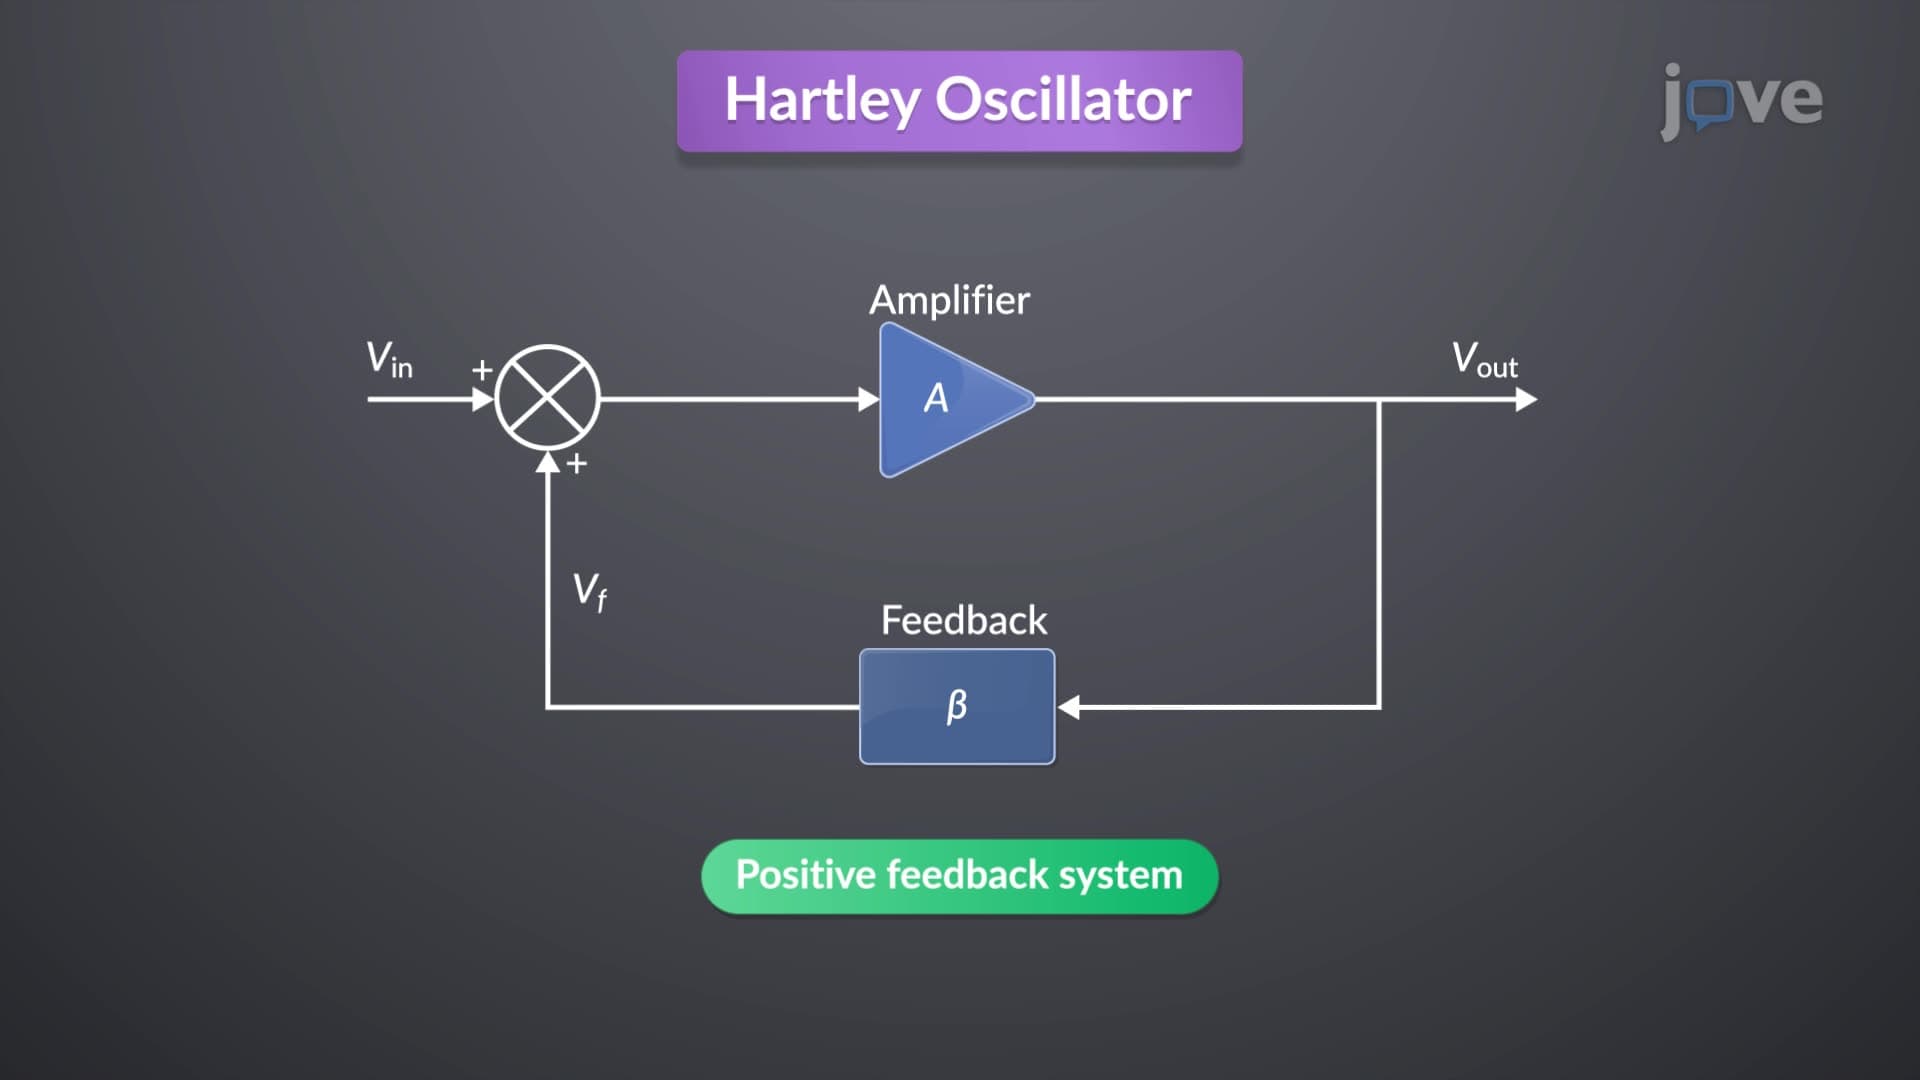
The Hartley oscillator is a positive feedback system that sustains oscillations by feeding the output back to the input in phase, thereby reinforcing the signal. Positive feedback systems can be viewed as negative feedback systems with inverted feedback signals. In these systems, the root locus encompasses all points on the s-plane where the angle of the system transfer function equals 360 degrees.
The construction rules for the root locus in positive feedback systems are similar to those in...
The construction rules for the root locus in positive feedback systems are similar to those in...
106
 01:23
Transfer function and Bode Plots-II
302
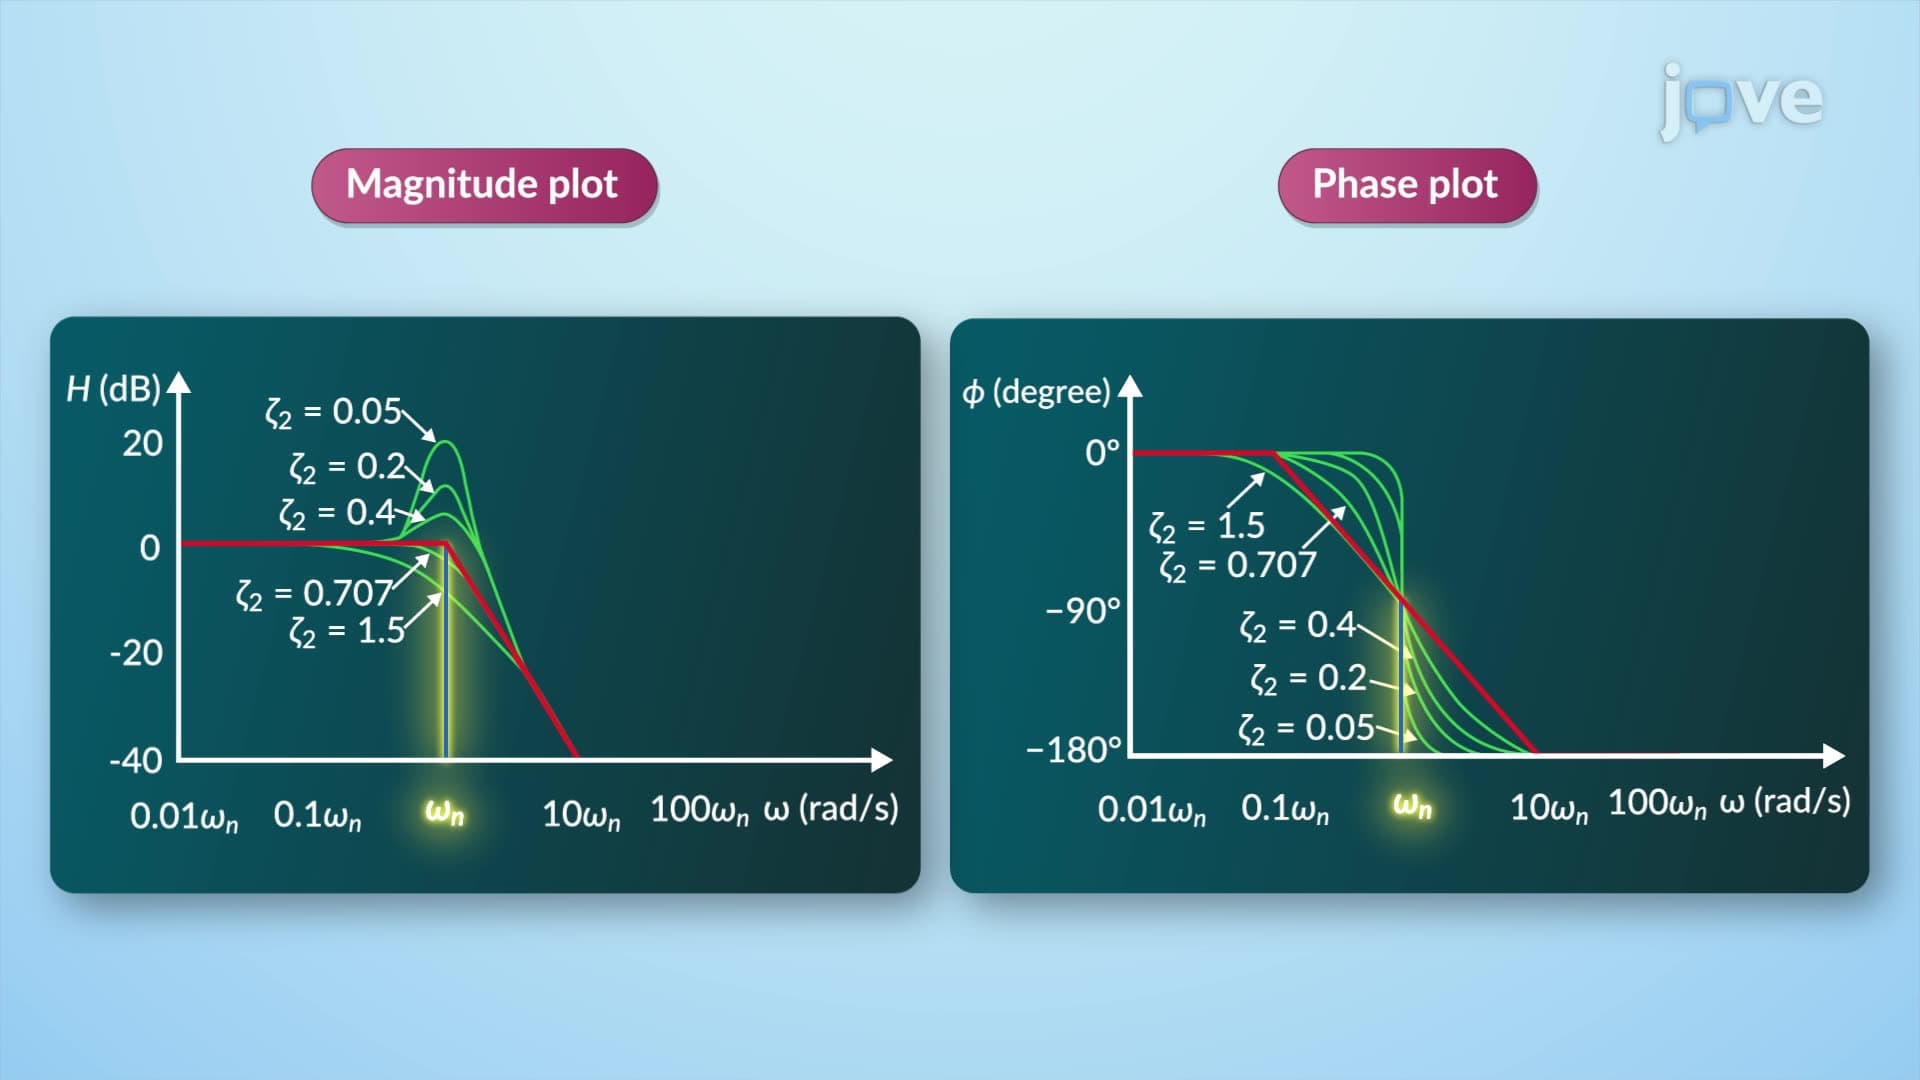
In the standard form, the transfer function is shown in constant gain, poles/zeros at origin, simple poles/zeros, and quadratic poles/zeros; each contributing uniquely to the system's overall response. The term represents the magnitude of the simple zero:
302
 01:24
BIBO stability of continuous and discrete -time systems
361
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
361
 01:24
Pole and System Stability
258
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
258
 01:20
Relation between Mathematical Equations and Block Diagrams
173
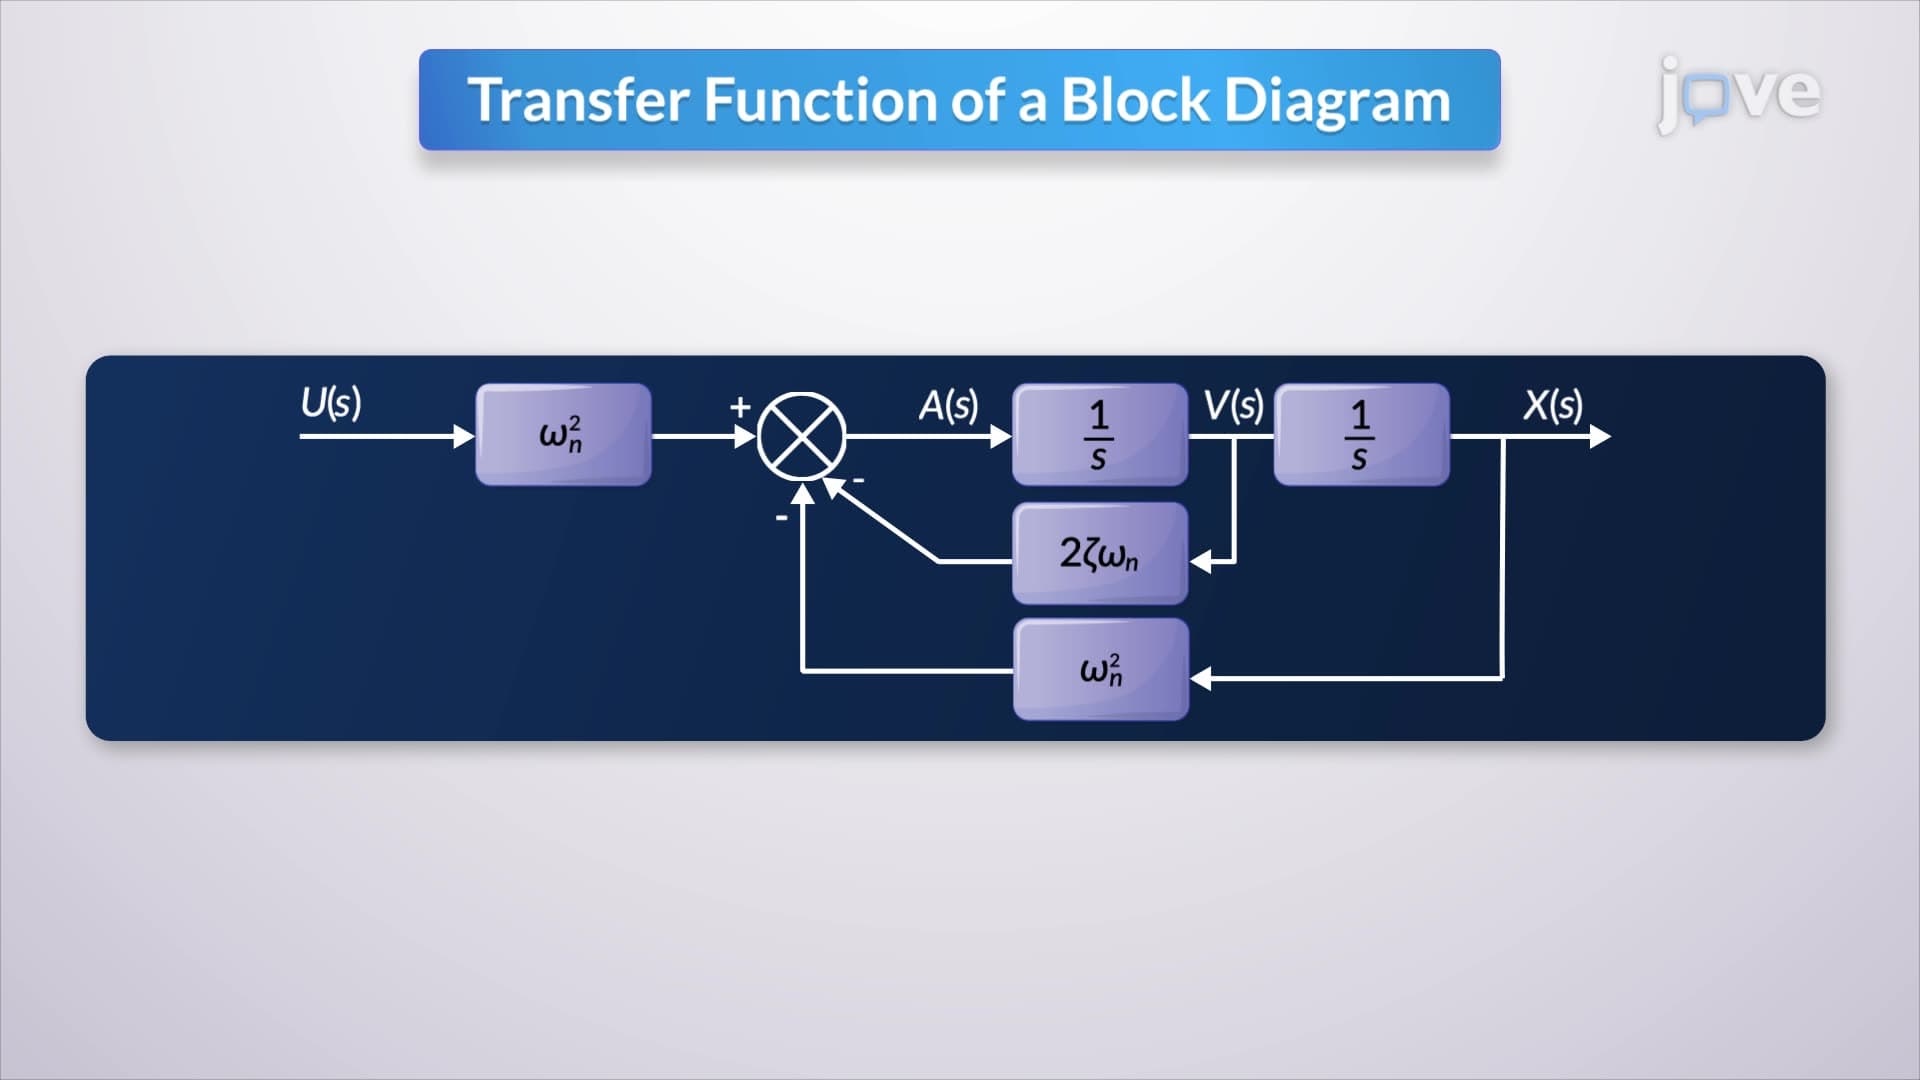
In a spring-mass-damper system, the second-order differential equation describes the dynamic behavior of the system. When transformed into the Laplace domain under zero initial conditions, this equation can be effectively analyzed and manipulated. The transformation into the Laplace domain converts differential equations into algebraic equations, simplifying the process of isolating the output.
173
 01:18
Second Order systems II
93
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
93