相关实验视频
Updated: Jun 11, 2025
05:42

Dynamic Navigation for Dental Implant Placement
Published on: September 13, 2022
3.7K
数字双胞胎导航和剪刀机切割的运动规划方法
Bing Miao1, Shirong Ge1,2, Yunwang Li1,2,3
1School of Mechanical and Electrical Engineering, China University of Mining and Technology (Beijing), Beijing 100083, China.
Sensors (Basel, Switzerland)
|September 28, 2024

概括
本研究介绍了一种数字双胞胎系统,用于自主剪刀导航切割,增强煤矿采矿智能. 在这种先进的数字双胞胎环境中,DQN-NAF算法在运动规划方面表现出了卓越的优势.
科学领域:
- 采矿工程 采矿工程 采矿工程
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
背景情况:
- 煤矿面临的挑战是,自主运营需要增强的智能.
- 剪刀导航切割对于高效和安全的采矿至关重要.
- 数字双胞胎技术为优化采矿过程提供了潜力.
研究的目的:
- 提出和开发一个剪刀数字双导航切割运动规划系统.
- 为了实现自主导出,学习和优化剪刀切割路径.
- 评估用于剪切运动规划的深度强化学习算法.
主要方法:
- 建立了一个基于数字双胞胎理论的剪刀数字双胞胎导航切割运动规划系统.
- 集成的物理感知,综合数据和数字模型融合分析层.
- 在数字双胞胎环境中利用深度强化学习算法 (DQN-NAF和DDPG).
主要成果:
- 开发的系统支持关键功能:剪刀切割数字双子,动态导航地图数字双子,强化学习环境构建和运动规划.
- 对比分析显示,DQN-NAF算法在剪切运动规划任务中表现优于DDPG.
- DQN-NAF算法证明了性能和稳定性的提高.
结论:
- 拟议的剪刀数字双胞胎系统有效地支持自主导航切割运动规划.
- 深度强化学习,特别是DQN-NAF,是优化剪刀机操作的可行和有效方法.
- 这项研究通过数字双胞胎和人工智能集成来推进智能煤矿开采.

相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
217
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
217
 01:22
Planar Rigid-Body Motion
413
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
413
 01:23
Curvilinear Motion: Rectangular Components
426
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
426
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
390
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
390
 01:27
Curvilinear Motion: Normal and Tangential Components
387
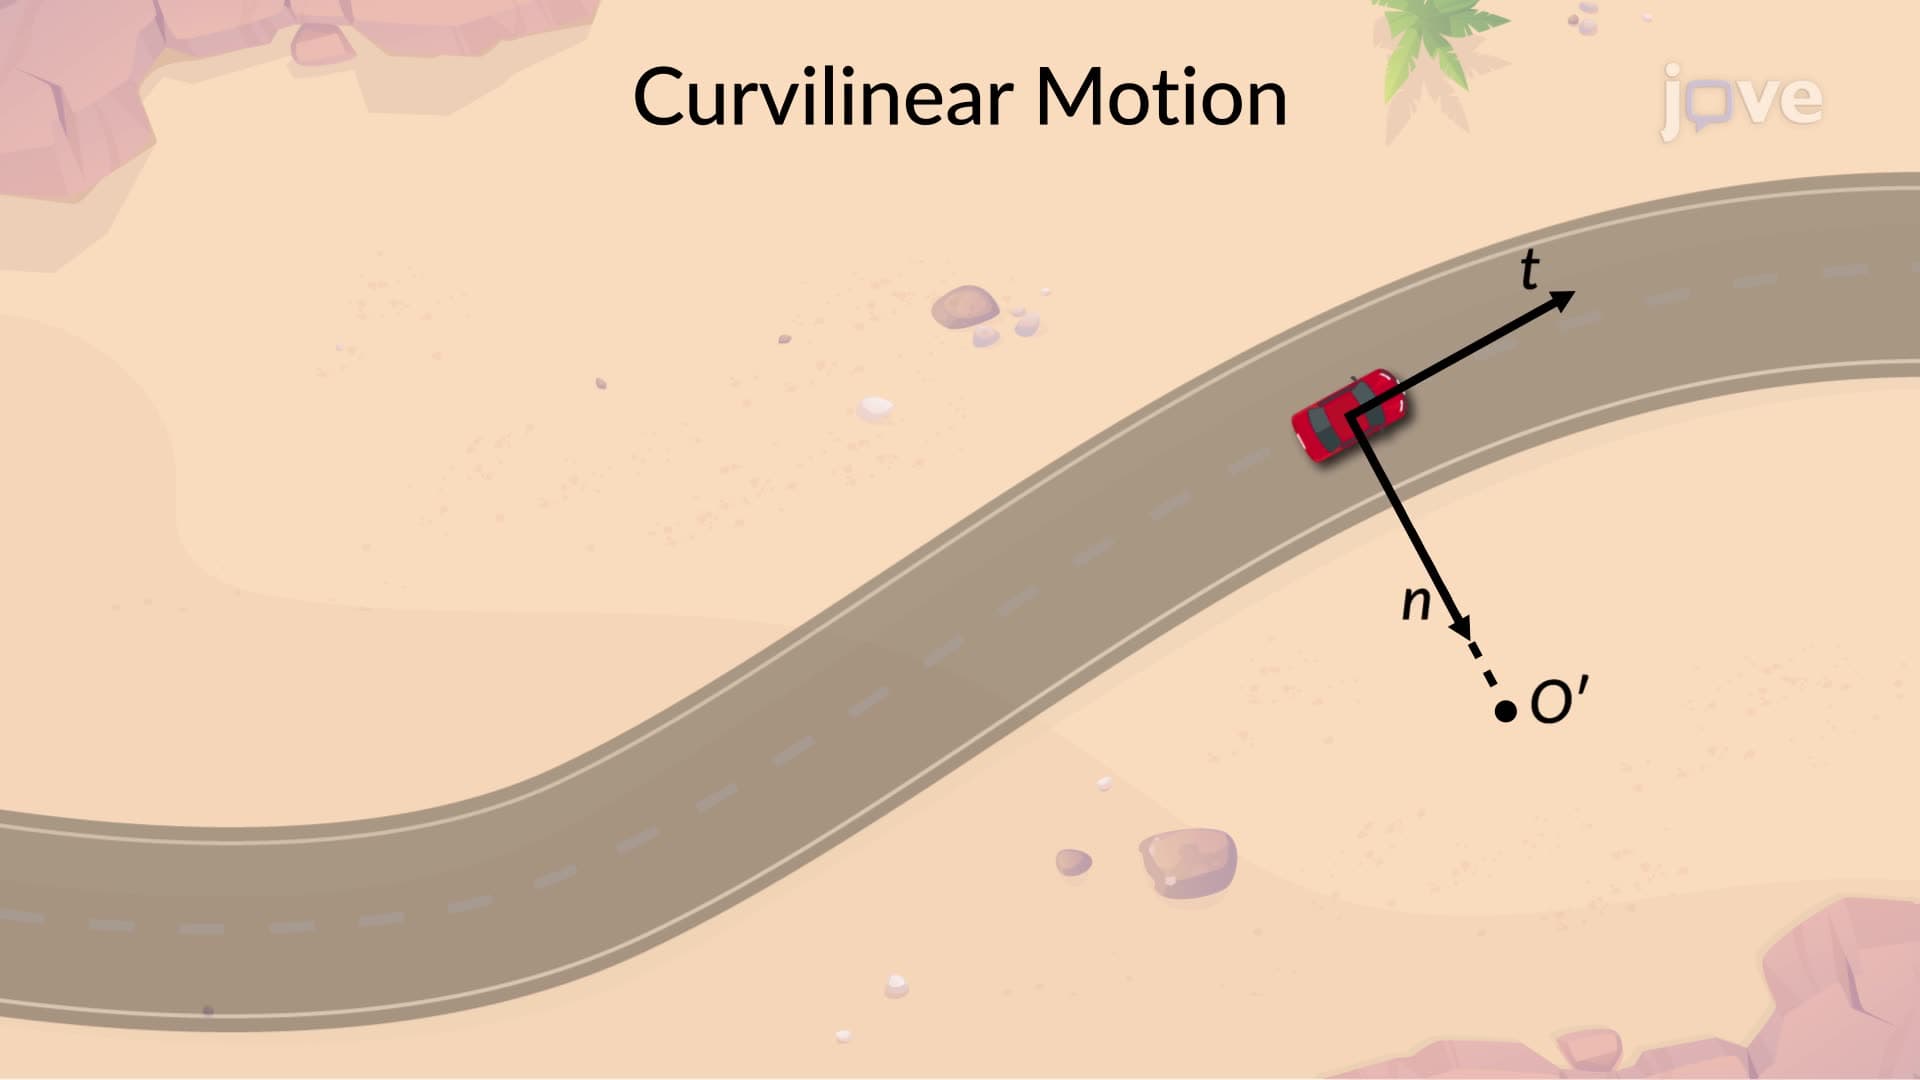
When a car traverses a curved road, its motion can be elucidated by breaking it down into tangential and normal components. The car-centric coordinates attached to the vehicle move with it.
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
387
 01:24
Relative Motion Analysis - Velocity
342
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
342