

个性化的前方碰撞预警模型,从人类偏好中学习
Ning Xie1, Rongjie Yu1, Weili Sun2
1College of Transportation Engineering, Tongji University, Shanghai, 201804, China; The Key Laboratory of Road and Traffic Engineering, Ministry of Education, 4800 Cao'an Road, 201804 Shanghai, China.
Accident; analysis and prevention
|September 29, 2024

概括
个性化前方碰撞预警 (FCW) 模型通过适应驾驶员个人的风险偏好来提高车辆安全. 这提高了警报同步和驾驶员的信心,降低了碰撞风险.
科学领域:
- 汽车安全 汽车安全
- 人与计算机的交互
- 机器学习 机器学习
背景情况:
- 背后撞车是最常见的车辆碰撞.
- 现有的前方碰撞预警系统 (FCW) 的响应率很低,这限制了它们的有效性.
- 需要对FCW系统进行个性化,以增强驾驶员的信心和安全.
研究的目的:
- 开发个性化的FCW模型,与个体驾驶员的风险偏好保持一致.
- 提高FCW系统与驾驶员行为的响应率和同步.
- 提高司机对自动化安全系统的信心.
主要方法:
- 开发了一个警告反指数,以量化驾驶员风险感知和FCW模型之间的差异.
- 个人驾驶员的风险感知偏好使用奖励模型进行了表征.
- 一个基准FCW模型使用近接政策优化 (PPO) 算法进行了微调,以个性化奖励模型为指导.
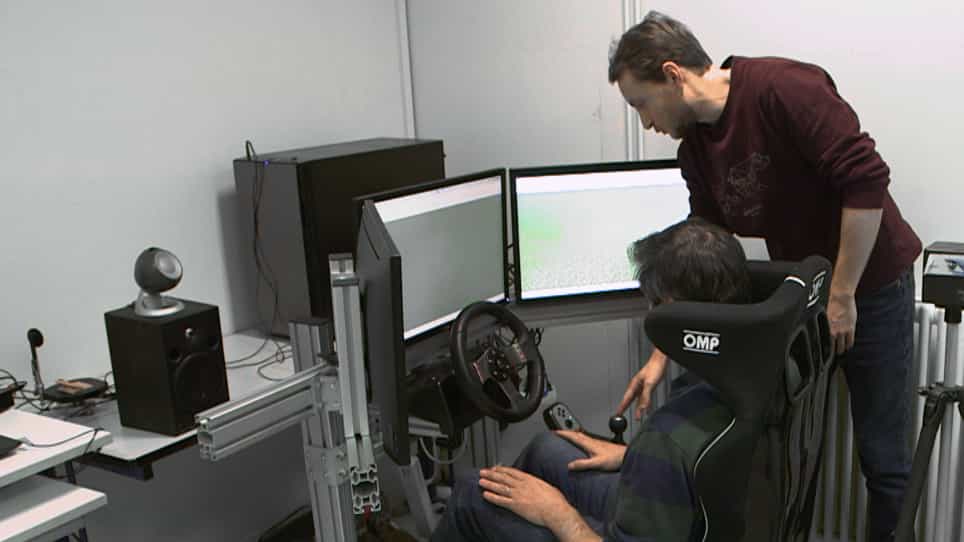
- 经验分析使用了来自74名司机的95,814个警告片段.
主要成果:
- 由个性化模型生成的伪警告结果的精度从53.5%增加到78.2%.
- FCW警告和驾驶员车行为之间的平均时间差距从2.4秒减少到1.6秒.
- 在个性化的FCW模型和个体驾驶员的风险感知之间实现了更高的同步水平.
结论:
- 个性化的FCW模型显著提高了警告的准确性和及时性.
- 加强FCW系统与驾驶员之间的同步,提高了驾驶员的信心和系统的有效性.
- 这种方法为开发更有效,更值得信赖的车辆安全系统提供了一个有希望的方向.

相关概念视频
 01:19
Types of Collisions - II
7.3K
When two or more objects collide with each other, they can stick together to form one single composite object (after collision). The total mass of the object after the collision is the sum of the masses of the original objects, and it moves with a velocity dictated by the conservation of momentum. Although the system's total momentum remains constant, the kinetic energy decreases, and thus such a collision is an inelastic collision. Most of the collisions between objects in daily life are...
7.3K
 01:04
Types Of Collisions - I
6.8K
When two objects come in direct contact with each other, it is called a collision. During a collision, two or more objects exert forces on each other in a relatively short amount of time. A collision can be categorized as either an elastic or inelastic collision. If two or more objects approach each other, collide and then bounce off, moving away from each other with the same relative speed at which they approached each other, the total kinetic energy of the system is said to be conserved. This...
6.8K
 01:27
Associative Learning
308
Associative learning is a fundamental concept in behavioral psychology, wherein a connection is established between two stimuli or events, leading to a learned response. This process is critical in understanding how behaviors are acquired and modified. Conditioning, the mechanism through which associations are formed, can be divided into two main types: classical conditioning and operant conditioning, each elucidating different aspects of associative learning.
Classical conditioning, also known...
Classical conditioning, also known...
308
 01:22
Controller Configurations
88
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
88
 01:06
Collisions in Multiple Dimensions: Problem Solving
3.7K
In multiple dimensions, the conservation of momentum applies in each direction independently. Hence, to solve collisions in multiple dimensions, we should write down the momentum conservation in each direction separately. To help understand collisions in multiple dimensions, consider an example.
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
3.7K
 01:26
PD Controller: Design
194
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
194