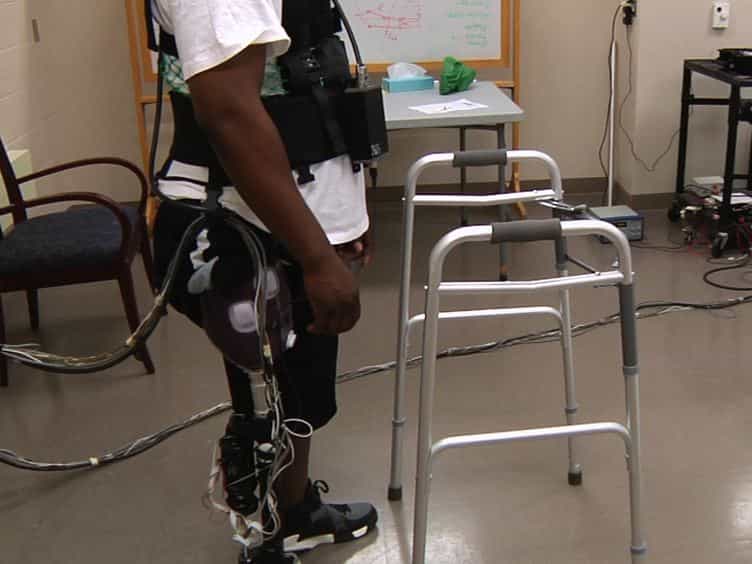
走向一种统一的方法,以持续可变的阻抗控制动力假肢的步行速度和倾斜度
Albert J Lee1, Curt A Laubscher1, T Kevin Best1
1Department of Robotics, University of Michigan, Ann Arbor, MI 48109.
IEEE International Conference on Robotics and Automation : ICRA : [proceedings]. IEEE International Conference on Robotics and Automation
|September 30, 2024

概括
本研究介绍了动力假肢的统一阻抗控制模型,通过使用单一连续模型来简化动力假肢的控制,无论是立场还是摆动阶段. 这种方法可以改善各种行走条件下的假肢控制.
科学领域:
- 生物医学工程 生物医学工程
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
背景情况:
- 由于其仿生特性,阻抗控制是动力假肢的首选.
- 当前的方法通常使用单独的模型来定位和摇摆阶段,需要复杂的切换逻辑.
研究的目的:
- 为动力假肢开发一个统一的阻抗控制模型,涵盖整个步行周期.
- 通过在单一连续模型下整合姿势和摆动阶段来改善假肢控制.
主要方法:
- 建议在整个步行周期中使用光滑阻抗参数轨迹的新型控制器.
- 介绍了一个在阻抗参数中表示任务间关系的基本模型.
- 富里埃数列模型阻抗参数的加权和,通过凸式优化优化系数.
主要成果:
- 统一模型成功地复制了有能力的关节扭矩和动力学.
- 实验表明,与混合阻抗动力模型相比,其性能具有竞争力.
- 控制器在不同的步行速度和斜率上有效.
结论:
- 一个更简单,统一的阻抗控制模型可以实现有效的假肢控制.
- 这种方法消除了对独立立场和摆动阶段模型的需求,简化了假肢设计.
- 拟议的方法为先进的假肢控制提供了一个有希望的方向.

相关概念视频
 01:24
PI Controller: Design
219
Proportional Integral (PI) controllers are a fundamental component in modern control systems, widely used to enhance performance and mitigate steady-state errors. They are particularly effective in applications such as automatic brightness adjustment on smartphones, where they excel at mitigating steady-state errors for step-function inputs. Unlike PD controllers, which require time-varying errors to function optimally, PI controllers leverage their integral component to address residual...
219
 01:26
PD Controller: Design
194
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
194
 01:21
Impedance Combination
405
Consider a string of christmas lights, each bulb symbolizing an impedance element. In this series configuration, the flow of electric current remains uniform across every component. This behavior aligns with Kirchhoff's Voltage Law (KVL), which asserts that the total impedance in such a setup equals the sum of individual impedances—akin to resistors in series. It follows that the voltage from the power source is distributed proportionally among these components, adhering to the...
405