

多重和无旋转的惯性数据集
Zeev Yampolsky1, Yair Stolero2, Nitsan Pri-Hadash2
1The Hatter Department of Marine Technologies, Charney School of Marine Sciences, University of Haifa, Haifa, 3103301, Israel. zyampols@campus.haifa.ac.il.

研究人员为无陀螺惯性导航系统 (GFINS) 和多个惯性测量单元 (MIMU) 创建了新的数据集. 这些数据支持机器人和自主系统的导航技术创新.
科学领域:
- 机器人技术和自主系统
- 导航和传感器融合技术
- 数据科学和机器学习
背景情况:
- 惯性导航系统 (INS) 对于使用加速度计和陀螺仪确定位置,速度和方向至关重要.
- 现有的INS研究越来越多地整合了数据驱动的方法,以提高准确性和效率.
- 对于专业架构的公开数据集存在重大差距,例如无陀螺INS (GFINS) 和多个惯性测量单位 (MIMU).
研究的目的:
- 为了解决GFINS和MIMU数据集的缺乏.
- 为研究新型INS架构的研究人员提供全面的资源.
- 促进先进导航算法的开发和评估.
主要方法:
- 设计并记录了新的GFINS和MIMU数据集.
- 使用了54个惯性传感器,分为9个惯性测量单位.
- 配置了三种不同的传感器,安装在移动机器人,乘用车和转盘上.
主要成果:
- 收集了45小时的惯性数据与相应的地面真理轨迹.
- 该数据集使各种MIMU和GFINS配置的定义和评估成为可能.
- 数据通过figshare存储库免费访问,以鼓励进一步的研究.
结论:
- 新创建的GFINS和MIMU数据集填补了研究界的一个关键缺口.
- 该资源将加速数据驱动INS的创新,特别是无陀螺和多传感器系统.
- 这一数据集的可用性促进了可复制的研究和下一代自主平台的开发.
更多相关视频
 06:36
Author Spotlight: Insights into the Analysis of Human Interaction with 3D Virtual Objects
Published on: October 18, 2024
 11:25
Simultaneous Scalp Electroencephalography EEG, Electromyography EMG, and Whole-body Segmental Inertial Recording for Multi-modal Neural Decoding
Published on: July 26, 2013
相关概念视频
 01:02
Gyroscope
 01:03
Inertial Frames of Reference
 01:24
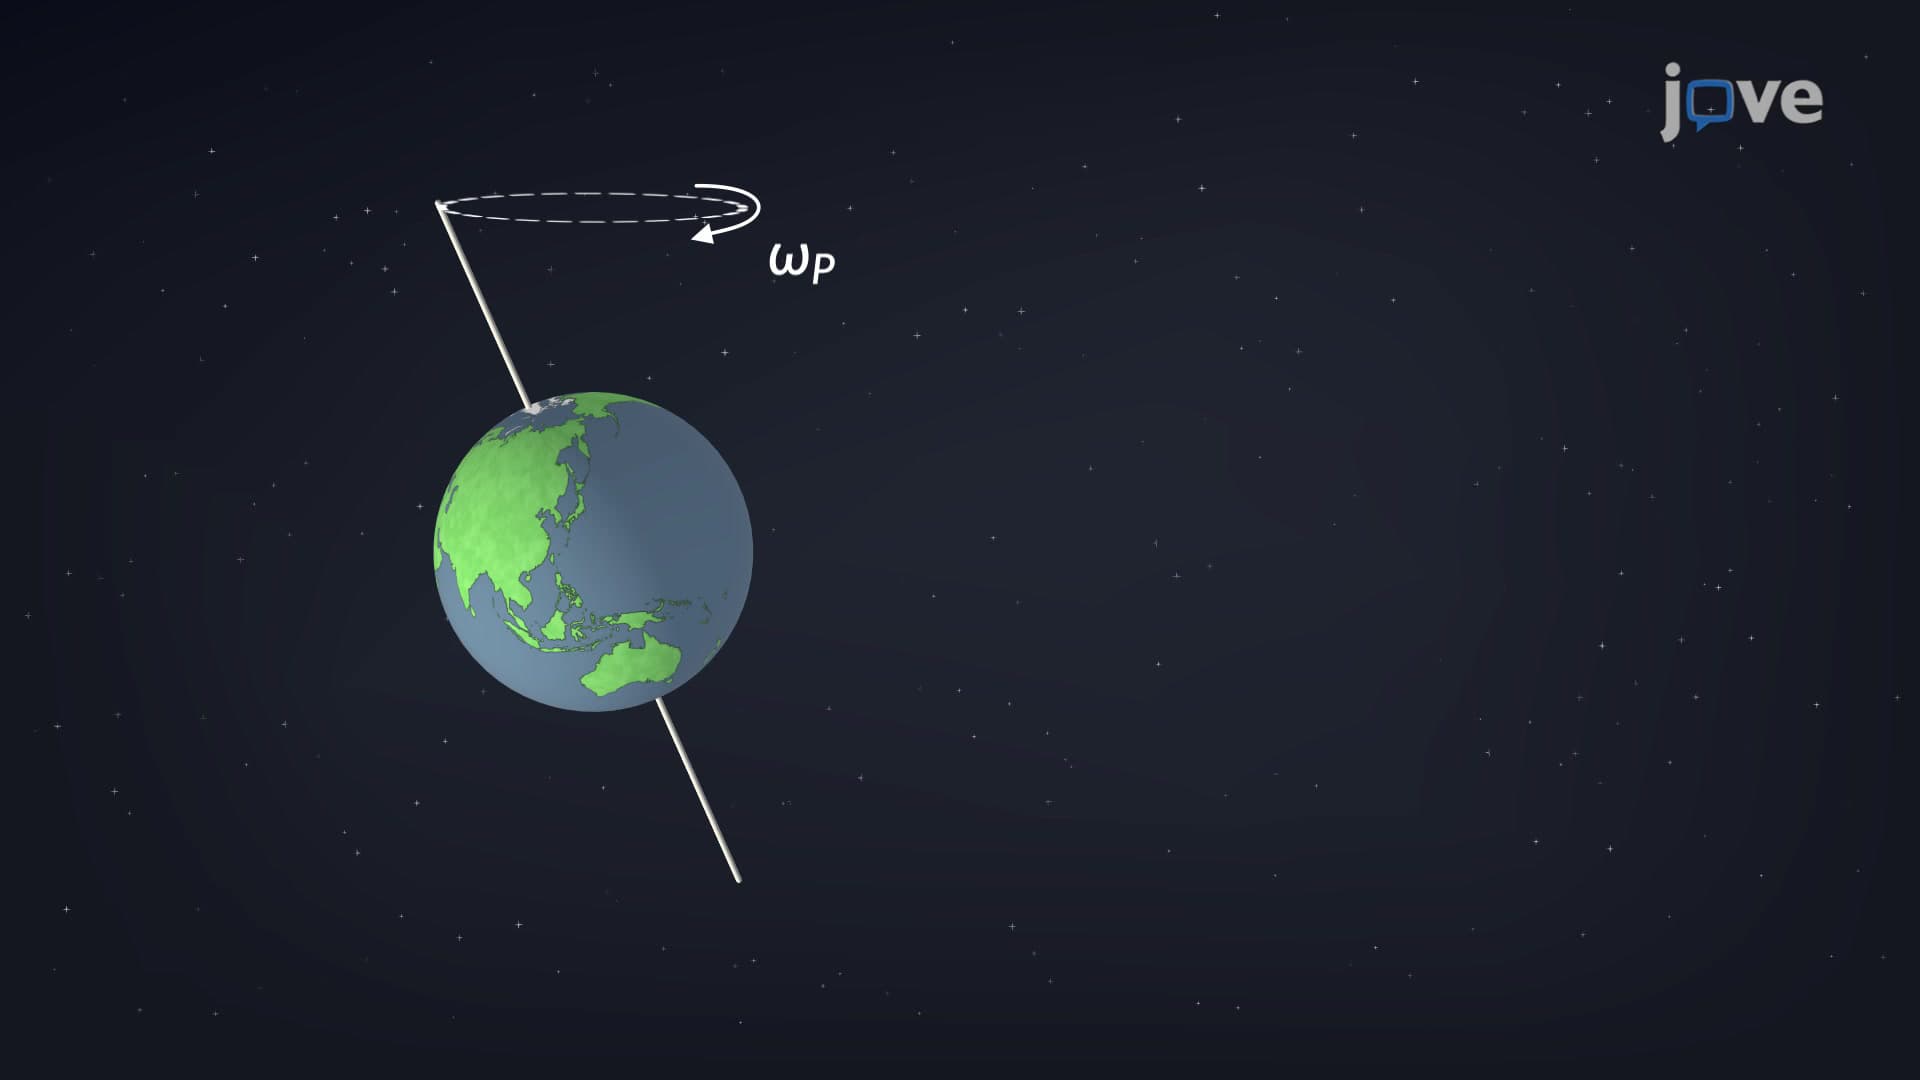
Gyroscope: Precession
 01:27
Non-inertial Frames of Reference
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...