相关实验视频
Updated: Jun 11, 2025
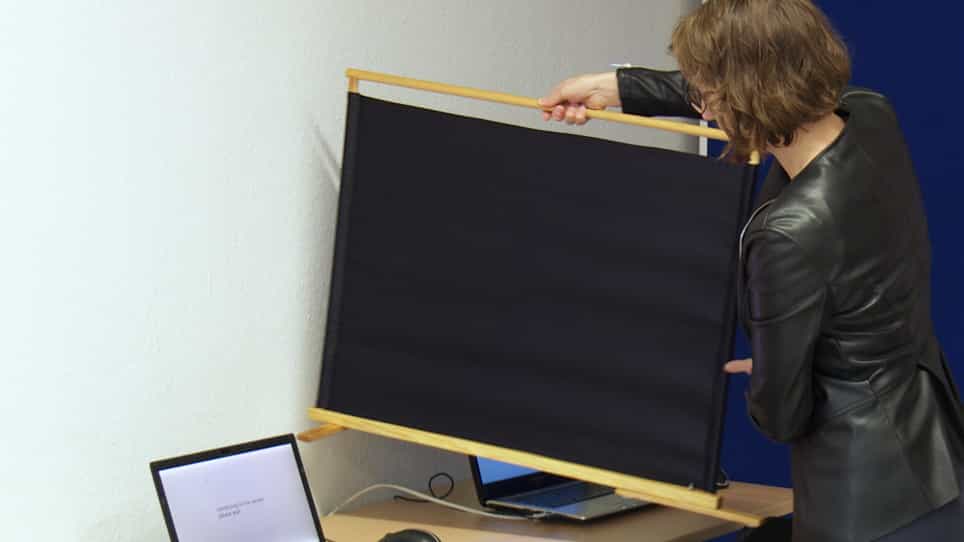
06:48

The HoneyComb Paradigm for Research on Collective Human Behavior
Published on: January 19, 2019
9.3K
强大的形成跟踪控制非合作的异质多剂体系统
IEEE transactions on cybernetics
|October 9, 2024

概括
本研究涉及异质多剂体系统的强有力的形成跟踪. 一个新的分布式观察器和控制器有效地管理不确定性和未知的输入,确保准确的形成控制.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统工程 控制系统工程
- 分布式系统 分布式系统
背景情况:
- 研究非合作性异质多剂体系统 (MAS) 中的强大的形成跟踪问题 (FTP).
- 解决异质代理参数,状态维度和领导代理未知的外部输入所带来的挑战.
- 考虑影响后续代理的不确定性和干扰.
研究的目的:
- 为非合作性异质多剂体系统开发一个强大的形成跟踪控制方法.
- 设计一个分布式扩展状态观察器,能够估计领导者的状态和未知的外部输入.
- 为了确保可以将训练跟踪错误最小化到所需的水平.
主要方法:
- 分布式扩展状态观察员的设计,以估计领导状态和外部输入.
- 关于针对异质多剂系统的强有力的形成跟踪控制策略的建议.
- 通过数值模拟和硬件在循环 (HITL) 模拟进行验证.
主要成果:
- 建议的分布式扩展状态观察器成功估计了领导者的状态和未知的外部输入.
- 强大的形成跟踪控制方法可以大大减少输出形成跟踪错误.
- 控制系统在最大限度地减少追踪错误的有效性,追踪错误到源地周围的一个小社区.
结论:
- 开发的分布式观察器和强大的控制器对非合作的异质多代理系统有效.
- 提出的方法为在不确定性和未知的输入下实现准确的形成跟踪提供了可行的解决方案.
- 模拟结果证实了拟议方法的实际适用性和性能.


相关概念视频
 01:13
Stability of Equilibrium Configuration: Problem Solving
590
The stability of equilibrium configurations is an important concept in physics, engineering, and other related fields. In simple terms, it refers to the tendency of an object or system to return to its equilibrium position after being disturbed. The stability of an equilibrium configuration can be analyzed by considering the potential energy function of the system and examining its behavior near the equilibrium point.
Problem-solving in the context of the stability of equilibrium configuration...
Problem-solving in the context of the stability of equilibrium configuration...
590
 01:06
Collisions in Multiple Dimensions: Problem Solving
3.7K
In multiple dimensions, the conservation of momentum applies in each direction independently. Hence, to solve collisions in multiple dimensions, we should write down the momentum conservation in each direction separately. To help understand collisions in multiple dimensions, consider an example.
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
3.7K
 01:58
Cooperative Allosteric Transitions
2.3K
2.3K
 01:22
Multi-input and Multi-variable systems
100
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
100
 01:24
One-Degree-of-Freedom System
465
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
465
 01:05
Collisions in Multiple Dimensions: Introduction
4.9K
It is far more common for collisions to occur in two dimensions; that is, the initial velocity vectors are neither parallel nor antiparallel to each other. Let's see what complications arise from this. The first idea is that momentum is a vector. Like all vectors, it can be expressed as a sum of perpendicular components (usually, though not always, an x-component and a y-component, and a z-component if necessary). Thus, when the statement of conservation of momentum is written for a...
4.9K