相关实验视频
Updated: Jun 10, 2025
07:46

Setting Limits on Supersymmetry Using Simplified Models
Published on: November 15, 2013
8.5K
关于扰乱立方可逆哈密尔顿系统的极限周期数
1School of Mathematical Sciences, Tianjin Normal University, Tianjin 300387, People's Republic of China.
Chaos (Woodbury, N.Y.)
|October 11, 2024

概括
这项研究研究了扰乱立方可逆哈密尔顿系中的极限周期. 研究人员使用一种新的梅尔尼科夫函数计算方法确定了极限周期数的边界.
科学领域:
- 微分方程 微分方程 微分方程
- 动态系统理论 动态系统理论
- 汉密尔顿力学 汉密尔顿力学
背景情况:
- 立方可逆哈密尔顿系统是动态系统的基础.
- 了解极限周期分叉对于分析系统行为至关重要.
- 扰动可以显著改变定性动态,包括出现极限周期.
研究的目的:
- 确定扰乱立方可逆哈密尔顿系中极限周期数的上下限.
- 用切换线分析多项式扰动对系统动态的影响.
- 开发和应用一种用于计算一阶梅尔尼科夫函数的新方法.
主要方法:
- 使用一阶梅尔尼科夫函数及其扩展.
- 使用代公式来计算梅尔尼科夫函数,将这种方法与其他方法区分开来.
- 在x=0.0处的开关线分析系统.
主要成果:
- 确立了限制周期数量的严格上下界限.
- 证明了Melnikov函数扩展对于这一类系统的有效性.
- 为梅尔尼科夫的函数分析提供了一种新的计算方法.
结论:
- 该研究成功地限制了扰乱系统的极限周期数.
- 开发的代方法为计算梅尔尼科夫函数提供了一种替代的,可能更有效的方法.
- 这些发现有助于理解可逆哈密尔顿系中的分叉.
相关概念视频
 01:10
Entropy Change in Reversible Processes
2.5K
In the Carnot engine, which achieves the maximum efficiency between two reservoirs of fixed temperatures, the total change in entropy is zero. The observation can be generalized by considering any reversible cyclic process consisting of many Carnot cycles. Thus, it can be stated that the total entropy change of any ideal reversible cycle is zero.
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
2.5K
 01:34
Woodward–Hoffmann Selection Rules and Microscopic Reversibility
3.0K
Electrocyclic reactions, cycloadditions, and sigmatropic rearrangements are concerted pericyclic reactions that proceed via a cyclic transition state. These reactions are stereospecific and regioselective. The stereochemistry of the products depends on the symmetry characteristics of the interacting orbitals and the reaction conditions. Accordingly, pericyclic reactions are classified as either symmetry-allowed or symmetry-forbidden. Woodward and Hoffmann presented the selection criteria for...
3.0K
 01:23
Root Loci for Positive-Feedback Systems
104
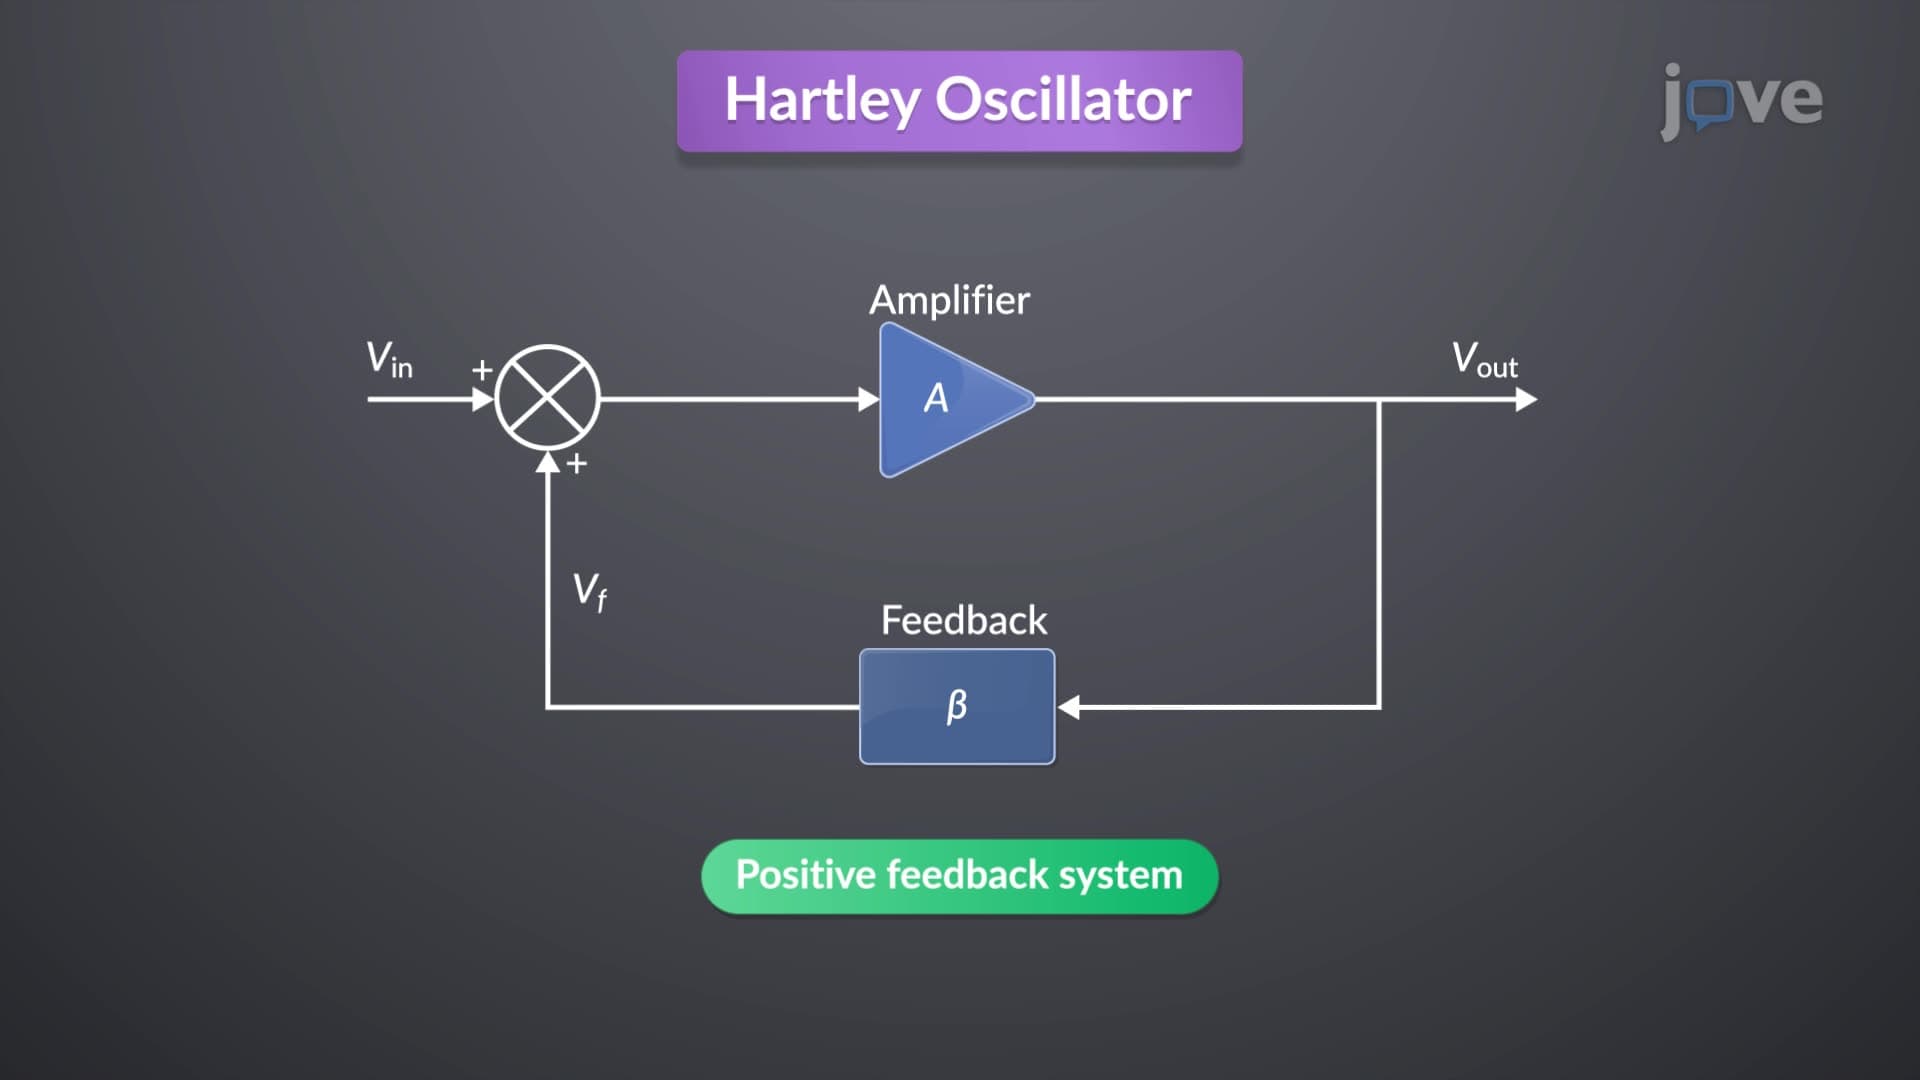
The Hartley oscillator is a positive feedback system that sustains oscillations by feeding the output back to the input in phase, thereby reinforcing the signal. Positive feedback systems can be viewed as negative feedback systems with inverted feedback signals. In these systems, the root locus encompasses all points on the s-plane where the angle of the system transfer function equals 360 degrees.
The construction rules for the root locus in positive feedback systems are similar to those in...
The construction rules for the root locus in positive feedback systems are similar to those in...
104
 01:24
Pole and System Stability
253
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
253
 01:24
One-Degree-of-Freedom System
465
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
465
 01:18
Second Order systems II
92
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
92