

基于UKF的最佳跟踪控制,用于具有不对称输入约束的不确定动态系统
IEEE transactions on cybernetics
|October 14, 2024

概括
使用无气味卡尔曼波器 (UKF) 的新算法改善了对不确定非线性系统的控制策略. 这种自适应动态编程方法提高了系统的稳定性,并优化了跟踪控制.
科学领域:
- 控制系统工程 控制系统工程
- 非线性系统分析 非线性系统分析
- 优化算法 优化算法
背景情况:
- 不确定性和不对称的输入约束在非线性离散时间系统中挑战了可靠的控制设计.
- 在这种情况下,现有的方法可能无法充分解决有限地平线最佳跟踪控制问题 (FHOTCP).
- 控制策略的自适应优化对于提高系统稳定性至关重要.
研究的目的:
- 开发一种新的算法,用于控制策略的强大和适应性优化.
- 为解决具有不确定性和不对称输入约束的非线性离散时间 (DT) 系统的有限地平线最佳跟踪控制问题 (FHOTCP).
- 为了确保成本函数在一个有限的范围内趋同到其最佳值.
主要方法:
- 开发一种基于卡尔曼波器 (UKF) 的代自适应动态编程 (ADP) 算法.
- 构建一个增强系统,以结合不对称的控制约束.
- 使用基于UKF的代ADP算法对离散时间汉密尔顿 - 雅各比 - 贝尔曼方程 (DTHJBE) 解决方案的近似.
- 在行为者-估计者-关键框架内实施,使用UKF进行系统状态估计.
主要成果:
- 拟议的基于UKF的代ADP算法确保成本函数在一个有限的范围内趋于其最佳值.
- 该算法有效地处理非线性DT系统中的不确定性和不对称输入约束.
- 模拟示例证明了拟议的控制方法的成功性能和稳定性.
- 演员-估计器-关键框架有助于执行基于UKF的代式ADP算法.
结论:
- 开发的基于UKF的代自适应动态编程算法为不确定非线性离散时间系统的有限地平线最佳跟踪控制问题提供了有效的解决方案.
- 该方法提高了系统的稳定性,并实现了控制策略的自适应优化.
- 演员 - 估计器 - 关键框架,结合UKF进行状态估计,使其能够在实践中实现并验证算法的性能.


相关概念视频
 01:10
Control Systems
1.1K
Control systems are everywhere in contemporary society, influencing diverse applications from aerospace to automated manufacturing. These systems can be found naturally within biological processes, such as blood sugar regulation and heart rate adjustment in response to stress, as well as in man-made systems like elevators and automated vehicles. A control system is essentially a network of subsystems and processes that collaboratively convert specific inputs into desired outputs.
At the heart...
At the heart...
1.1K
 01:26
Feedback control systems
293
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
293
 01:22
Controller Configurations
87
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
87
 01:21
Linear Approximation in Time Domain
68
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
68
 01:21
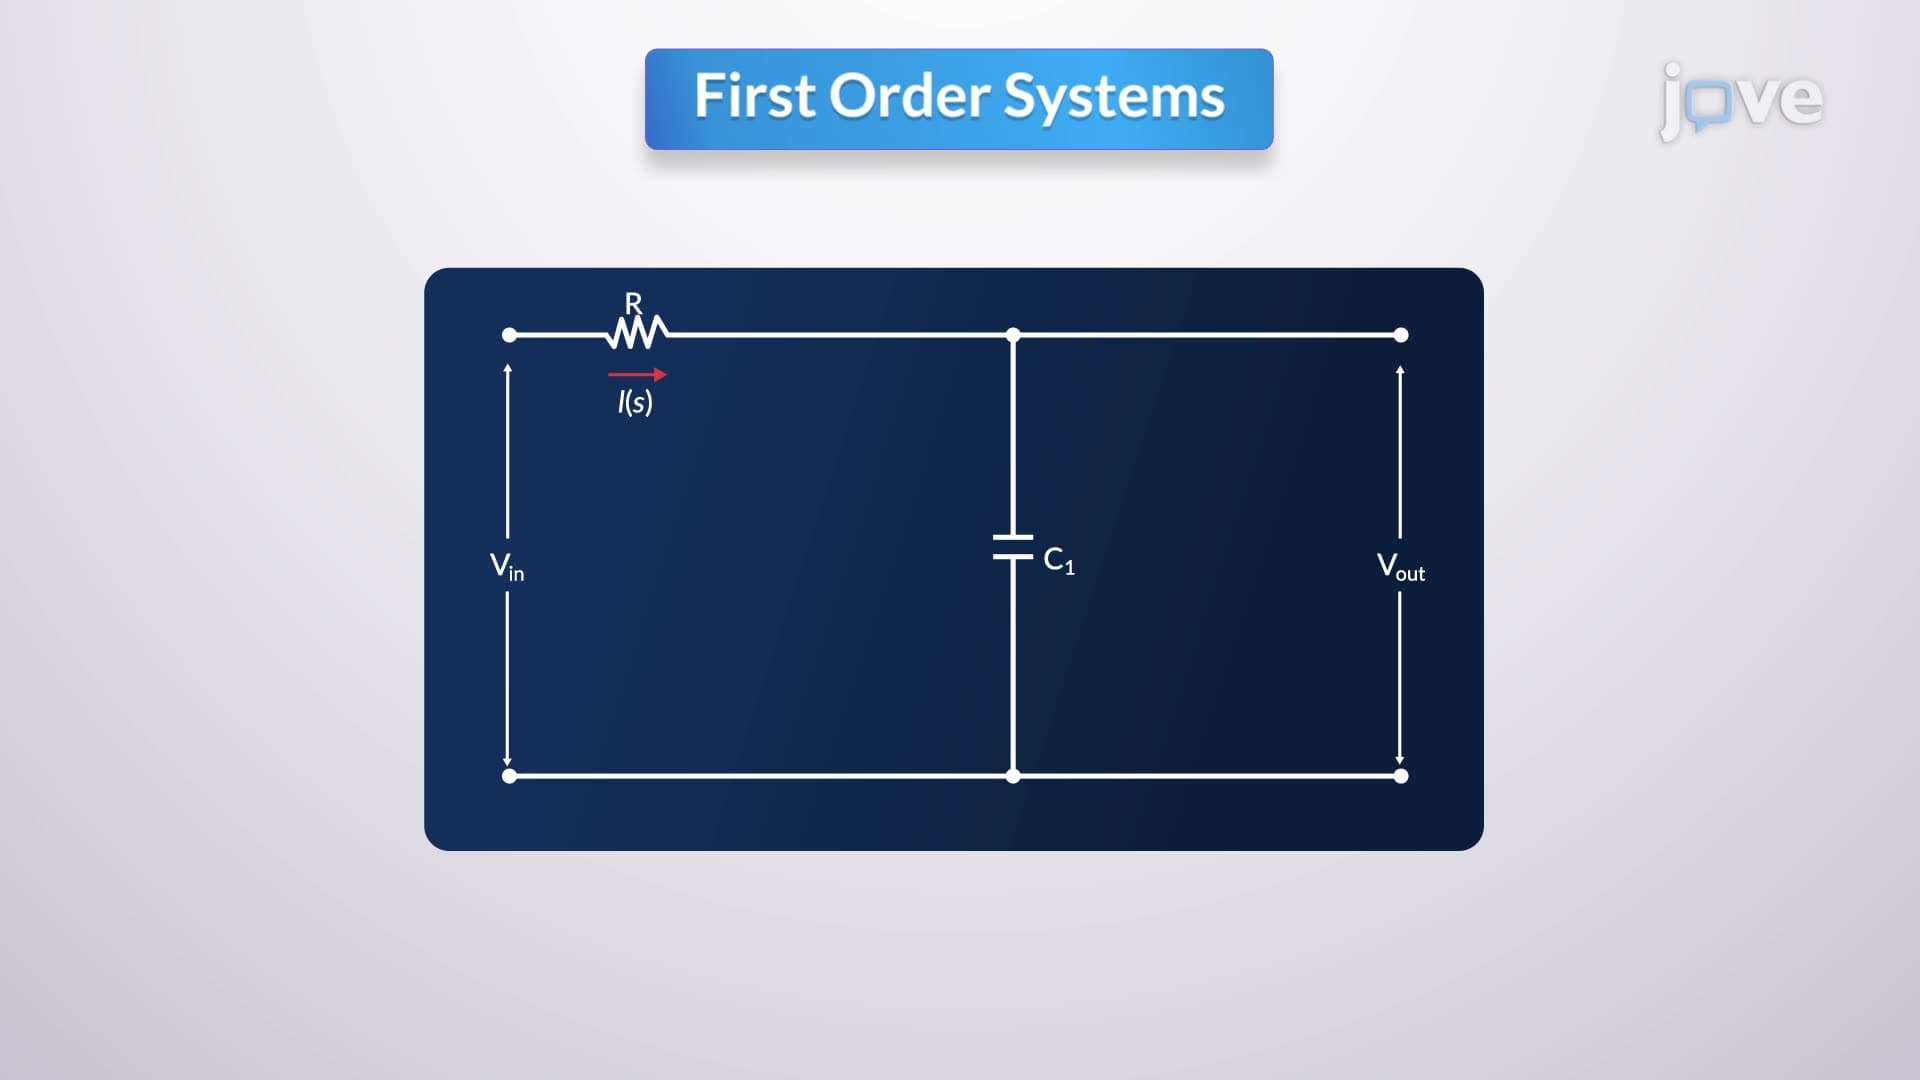
First Order Systems
86
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
86
 01:22
Multi-input and Multi-variable systems
100
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
100