SOD-YOLOv8-增强YOLOv8用于空中图像和交通场景中的小物体检测
Boshra Khalili1, Andrew W Smyth1
1Department of Civil Engineering and Engineering Mechanics, Columbia University, New York, NY 10027, USA.
Sensors (Basel, Switzerland)
|October 16, 2024

概括
本研究介绍了SOD-YOLOv8,这是一个新的模型,可以显著改善计算机视觉任务中的小物体检测. 它提高了从高空摄像机检测小物体的精度和回忆力,而不会增加计算成本.
科学领域:
- 计算机视觉 计算机视觉
- 机器学习 机器学习
- 人工智能的人工智能
背景情况:
- 对象检测对于自主系统和智能城市至关重要,但从高空摄像头检测小物体仍然是一个重大挑战.
- 现有的模型因物体大小,距离,形状多样化和背景杂乱等因素而难以检测小物体.
研究的目的:
- 开发一种新型模型,小型物体检测YOLOv8 (SOD-YOLOv8),专门设计用于在具有挑战性的成像条件下增强众多小型物体的检测.
- 提高计算机视觉应用中小物体检测的准确性和效率.
主要方法:
- 拟议的SOD-YOLOv8模型通过使用高效的通用特征金字塔网络 (GFPNs) 集成不同层次的功能来增强YOLOv8.
- 引入了第四个检测层,用于高分辨率的空间信息利用,以及一个高效的多尺度注意模块 (EMA),用于增强特征提取.
- 实现了强大的IoU (PIoU) 损失函数,以提高边界框回归精度和收速度.
主要成果:
- 在小物体检测指标方面,SOD-YOLOv8显著改善,包括回忆 (40.1%至43.9%),精度 (51.2%至53.9%),mAP0.5 (40.6%至45.1%),mAP0.5:0.95 (24%至26.6%).
- 与广泛使用的模型相比,该模型显示出优异的性能,而计算成本或延迟没有大幅增加.
- 现实世界的交通场景实验证实了SOD-YOLOv8在各种环境条件下的可靠性和有效性.
结论:
- SOD-YOLOv8有效地解决了从高空摄像机检测小物体的挑战,提供更高的准确性和效率.
- 拟议的模型为交通管理,自动驾驶和智能城市计划等关键应用提供了强大的解决方案.
- SOD-YOLOv8代表了物体检测技术的重大进步,特别是对于许多小物体的场景.


相关概念视频
 01:05
Difference from Background: Limit of Detection
5.9K
The limit of detection (LOD) is the smallest amount of analyte that can be distinguished from the background noise. The LOD value corresponds to the concentration at which the analyte signal is three times larger than the standard deviation of the blank signal. Below this value, the analyte signal cannot be differentiated from the background noise. It is calculated by dividing the calibration slope by 3 times the standard deviation of the blank signals.
The LOD indicates the presence or absence...
The LOD indicates the presence or absence...
5.9K
 01:18
Imaging Biological Samples with Optical Microscopy
4.6K
Optical microscopy uses optic principles to provide detailed images of samples. Antonie van Leeuwenhoek designed the first compound optical microscope in the 17th century to visualize blood cells, bacteria, and yeast cells. In 1830, Joseph Jackson Lister created an essentially modern light microscope. The 20th century saw the development of microscopes with enhanced magnification and resolution.
In optical microscopy, the specimen to be viewed is placed on a glass slide and clipped on the stage...
In optical microscopy, the specimen to be viewed is placed on a glass slide and clipped on the stage...
4.6K
 01:20
Deconvolution
137
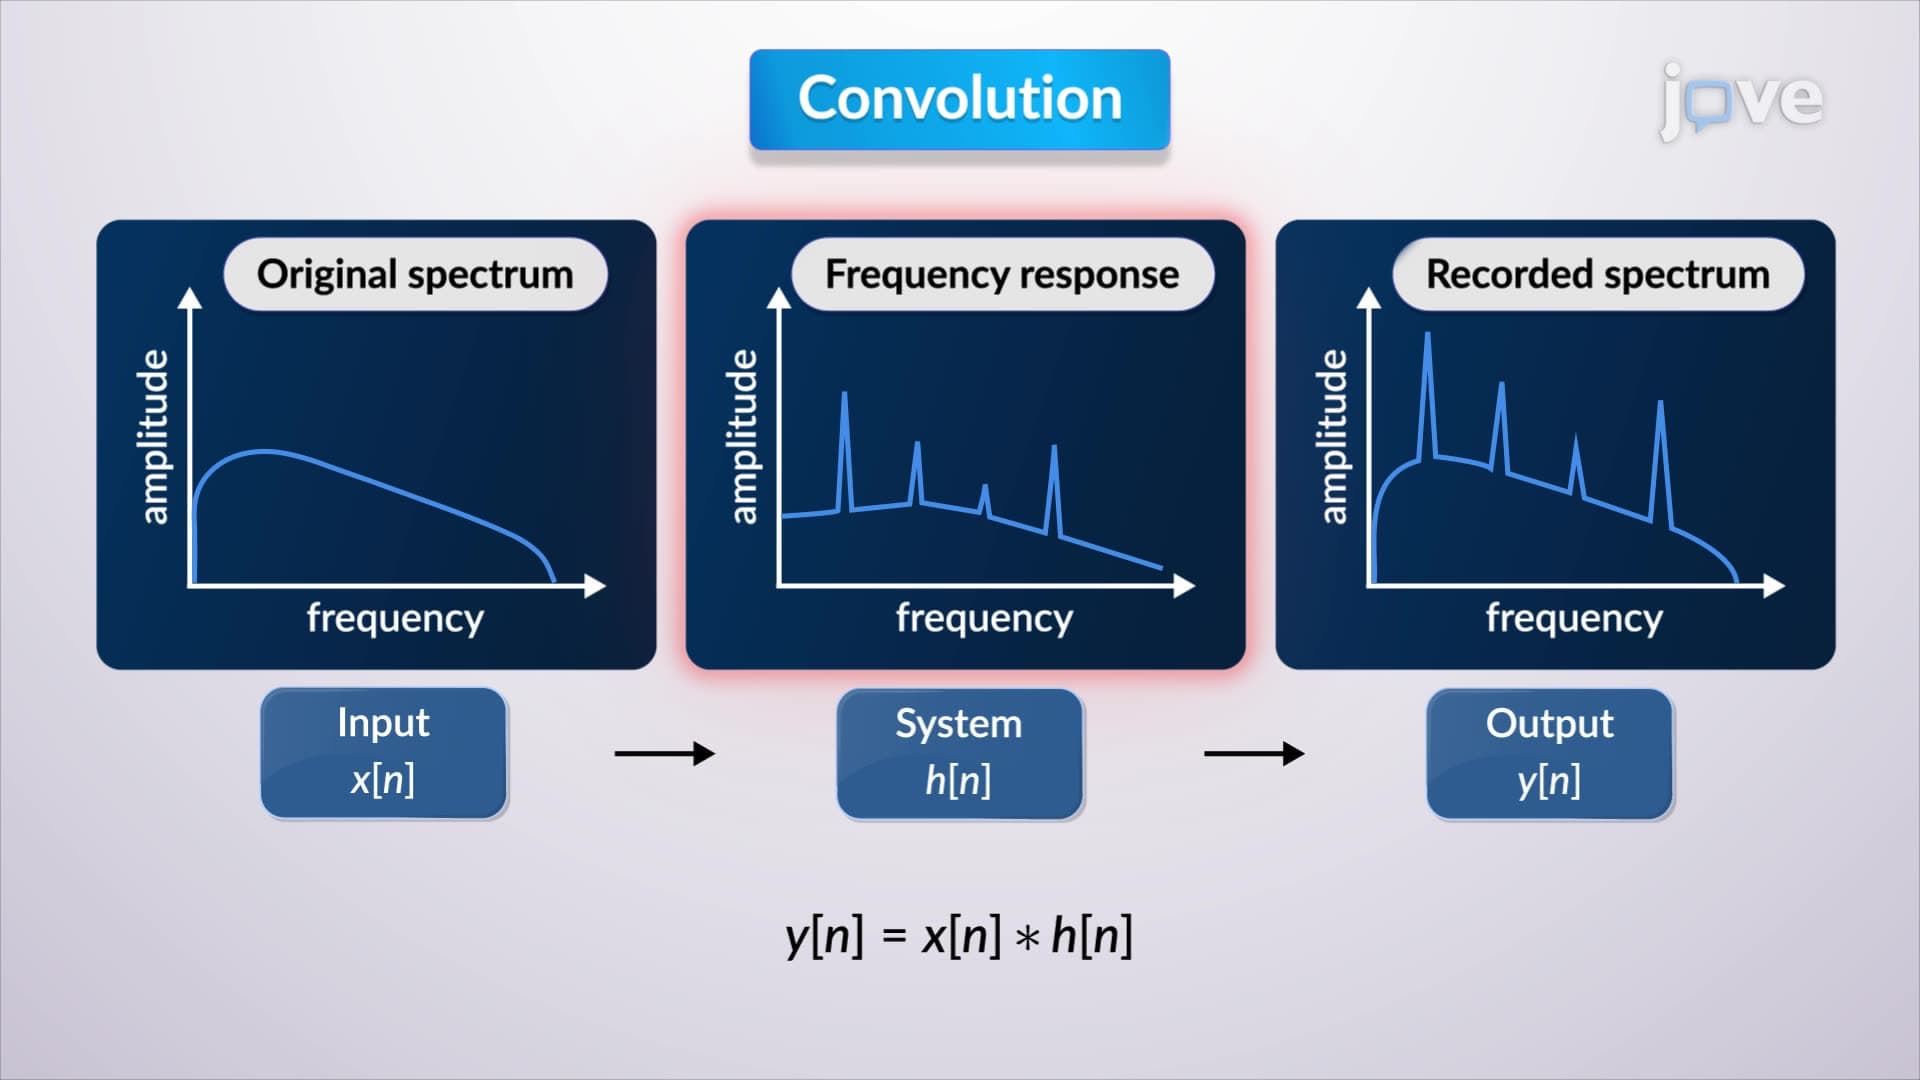
Deconvolution, also known as inverse filtering, is the process of extracting the impulse response from known input and output signals. This technique is vital in scenarios where the system's characteristics are unknown, and they must be inferred from the observable signals.
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
137
 01:18
Reducing Line Loss
147
In a three-phase circuit, line loss is an indicator of energy dissipated as heat due to the resistance of transmission lines. To address this, incorporating transformers into the system—a step-up transformer at the source and a step-down transformer at the load—is a strategic solution. Two three-phase transformers are introduced to improve this.
With a step-up transformer at the source, the voltage is increased, thereby reducing the current in the transmission lines since power loss...
With a step-up transformer at the source, the voltage is increased, thereby reducing the current in the transmission lines since power loss...
147
 01:30
Acceleration Vectors
8.0K
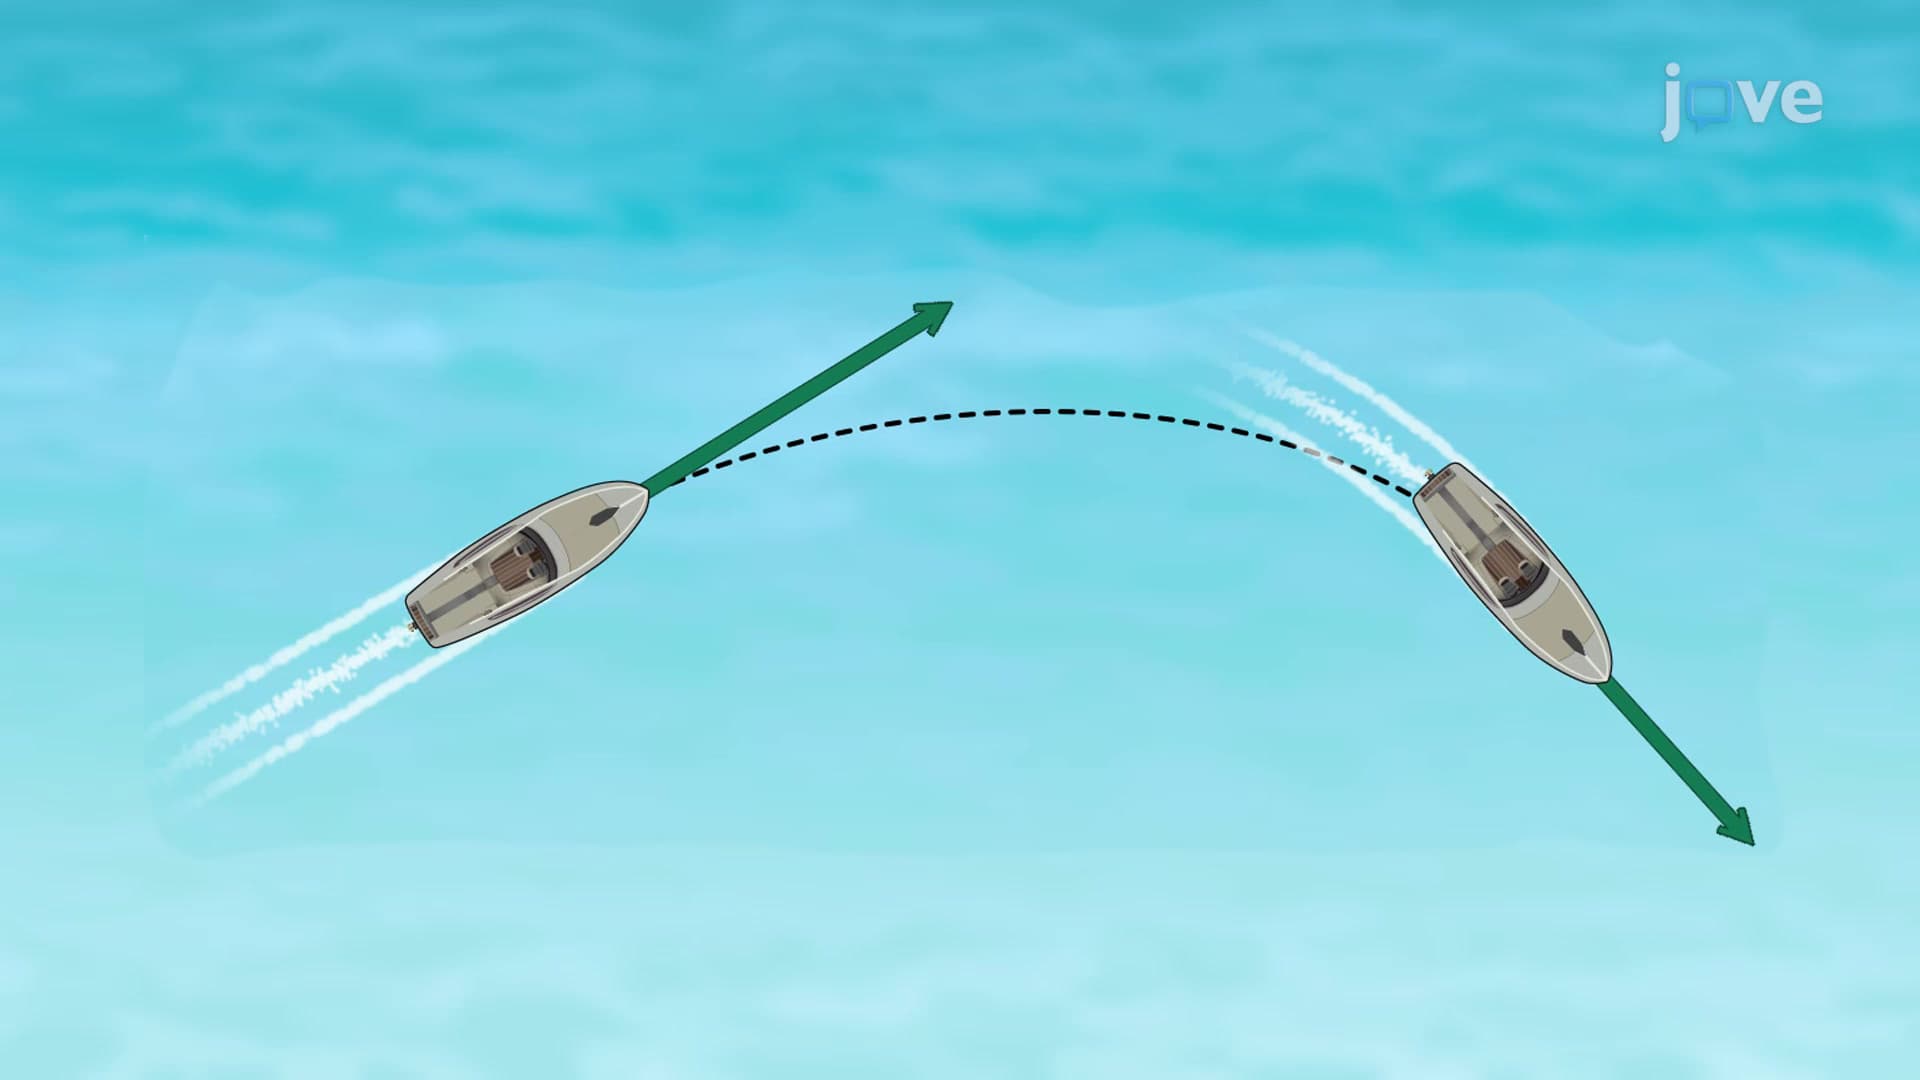
In everyday conversation, accelerating means speeding up. Acceleration is a vector in the same direction as the change in velocity, Δv, therefore the greater the acceleration, the greater the change in velocity over a given time. Since velocity is a vector, it can change in magnitude, direction, or both. Thus acceleration is a change in speed or direction, or both. For example, if a runner traveling at 10 km/h due east slows to a stop, reverses direction, and continues their run at 10 km/h...
8.0K
 01:15
Depth Perception and Spatial Vision
601
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
601