通过手动运动学分析阿拉伯手写风格
Vahan Babushkin1,2, Haneen Alsuradi1, Muhamed Osman Al-Khalil3
1Applied Interactive Multimedia Lab, Engineering Division, New York University Abu Dhabi, Abu Dhabi P.O. Box 129188, United Arab Emirates.
Sensors (Basel, Switzerland)
|October 16, 2024

概括
这项研究引入了一种新的方法,用于使用动态动力学数据来分类阿拉伯手写风格,达到88%的准确性. 该研究确定了关键特征,如手的速度和压力对于准确的风格检测至关重要.
科学领域:
- 计算机科学 计算机科学
- 人与计算机的交互
- 语言学的语言学.
背景情况:
- 阿拉伯手写有多种风格 (如Ruq'ah,Naskh),使得坚持一致的风格变得复杂.
- 现有的研究主要分析静态文档,忽视动态特征和混合风格.
研究的目的:
- 开发和评估一种基于使用动态特征的风格坚持的阿拉伯手写的分类模型.
- 为了确定影响阿拉伯手写风格分类的关键动态特征.
主要方法:
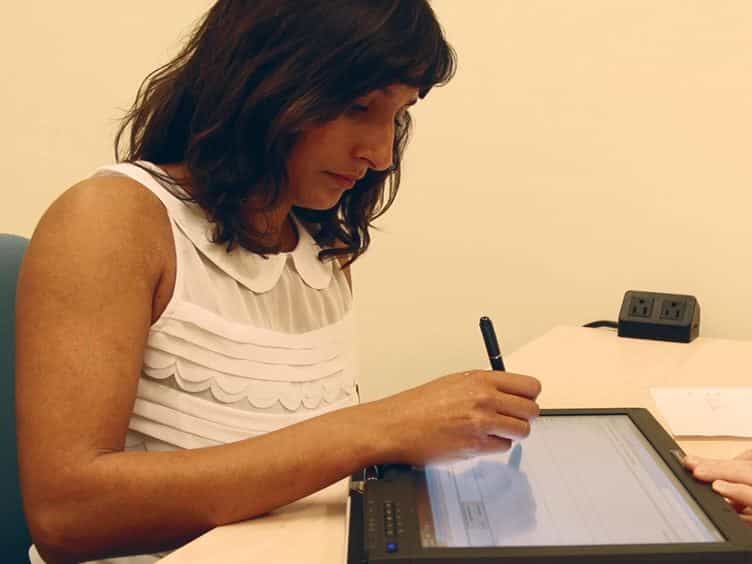
- 收集了50名参与者写阿拉伯文文本的动态笔和手动运动数据.
- 在纯,混合和非风格手写样本上培训的分类模型.
- 使用参数搜索以寻找最佳模型超参数,滑动窗口长度和重叠.
主要成果:
- 拟议的模型在将阿拉伯手写样本分为四个风格坚持类别时,达到88%的准确性.
- 可解释性分析 (夏普利值) 突出了手的速度,压力和笔斜率作为重要的特征.
- 其他动力学特征几乎同样对分类性能做出了贡献.
结论:
- 动态动态特征提供了一个强大的方法来分类阿拉伯手写风格的坚持.
- 手的速度,压力和笔斜率是区分阿拉伯手写风格的关键指标.
- 该研究提供了对定义阿拉伯手写风格的动态特征的见解.
相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
390
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
390
 01:15
Kinematic Equations: Problem Solving
11.9K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
11.9K
 01:25
Relative Motion Analysis using Rotating Axes
448
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
448