
在沿海观测中,用于激光雷达和摄像头数据融合的协调转换的神经方法
Ilona Garczyńska-Cyprysiak1, Witold Kazimierski1, Marta Włodarczyk-Sielicka2
1Department of Hydrography and Spatial Analyses, Faculty of Navigation, Maritime University of Szczecin, Waly Chrobrego 1-2, 70-500 Szczecin, Poland.

这项研究融合了来自无人驾驶表面车辆的摄像头和LiDAR数据,用于沿海观测. 神经网络对传感器对齐有前途,尽管一般化需要进一步研究.
科学领域:
- 机器人技术和自主系统
- 地理空间科学 地理空间科学
- 传感器融合技术 传感器融合技术
背景情况:
- 沿海观测需要准确的海岸特征数据.
- 无人驾驶地面车辆 (USV) 为数据收集提供了一个平台.
- 传感器融合,结合来自多个传感器的数据,如摄像头和LiDAR,提高信息质量.
研究的目的:
- 开发和验证神经网络算法,用于从USV获得的摄像头和LiDAR数据的时空对齐.
- 通过传感器数据融合,提高沿海观测的准确性和效率.
- 评估多层感知器 (MLP),辐射基函数 (RBF) 和总回归神经网络 (GRNN) 在坐标转换方面的性能.
主要方法:
- 利用点匹配算法在摄像头和LiDAR数据之间进行坐标转换.
- 实现并测试了用于传感器对齐的MLP,RBF和GRNN神经网络.
- 通过USV记录的真实数据验证了拟议的算法,并与数值方法进行了比较.
主要成果:
- 拟议的神经网络方法证明了作为替代传感器对齐传统数值方法的有效性.
- 对于平台动态,实现了令人满意的准确性,根平均平方误差 (RMSE) 通常低于1米.
- 虽然神经网络在训练数据上表现良好,但概括能力有限,这表明匹配点准确性存在挑战.
结论:
- 基于神经网络的传感器对齐是一种可行的方法,可以通过USV来增强沿海观测.
- 需要进一步的研究来提高模型的概括能力,并解决匹配点精度的局限性.
- 未来的工作将纳入船舶位置和方向数据,以进一步完善核聚变过程.
更多相关视频
 11:57
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy iPALM
Published on: December 1, 2016
 06:26
Stereo-Imaging System DLT Calibration to Capture 3D In Situ Displacements of Stretched Peripheral Nerves
Published on: January 12, 2024
相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:16
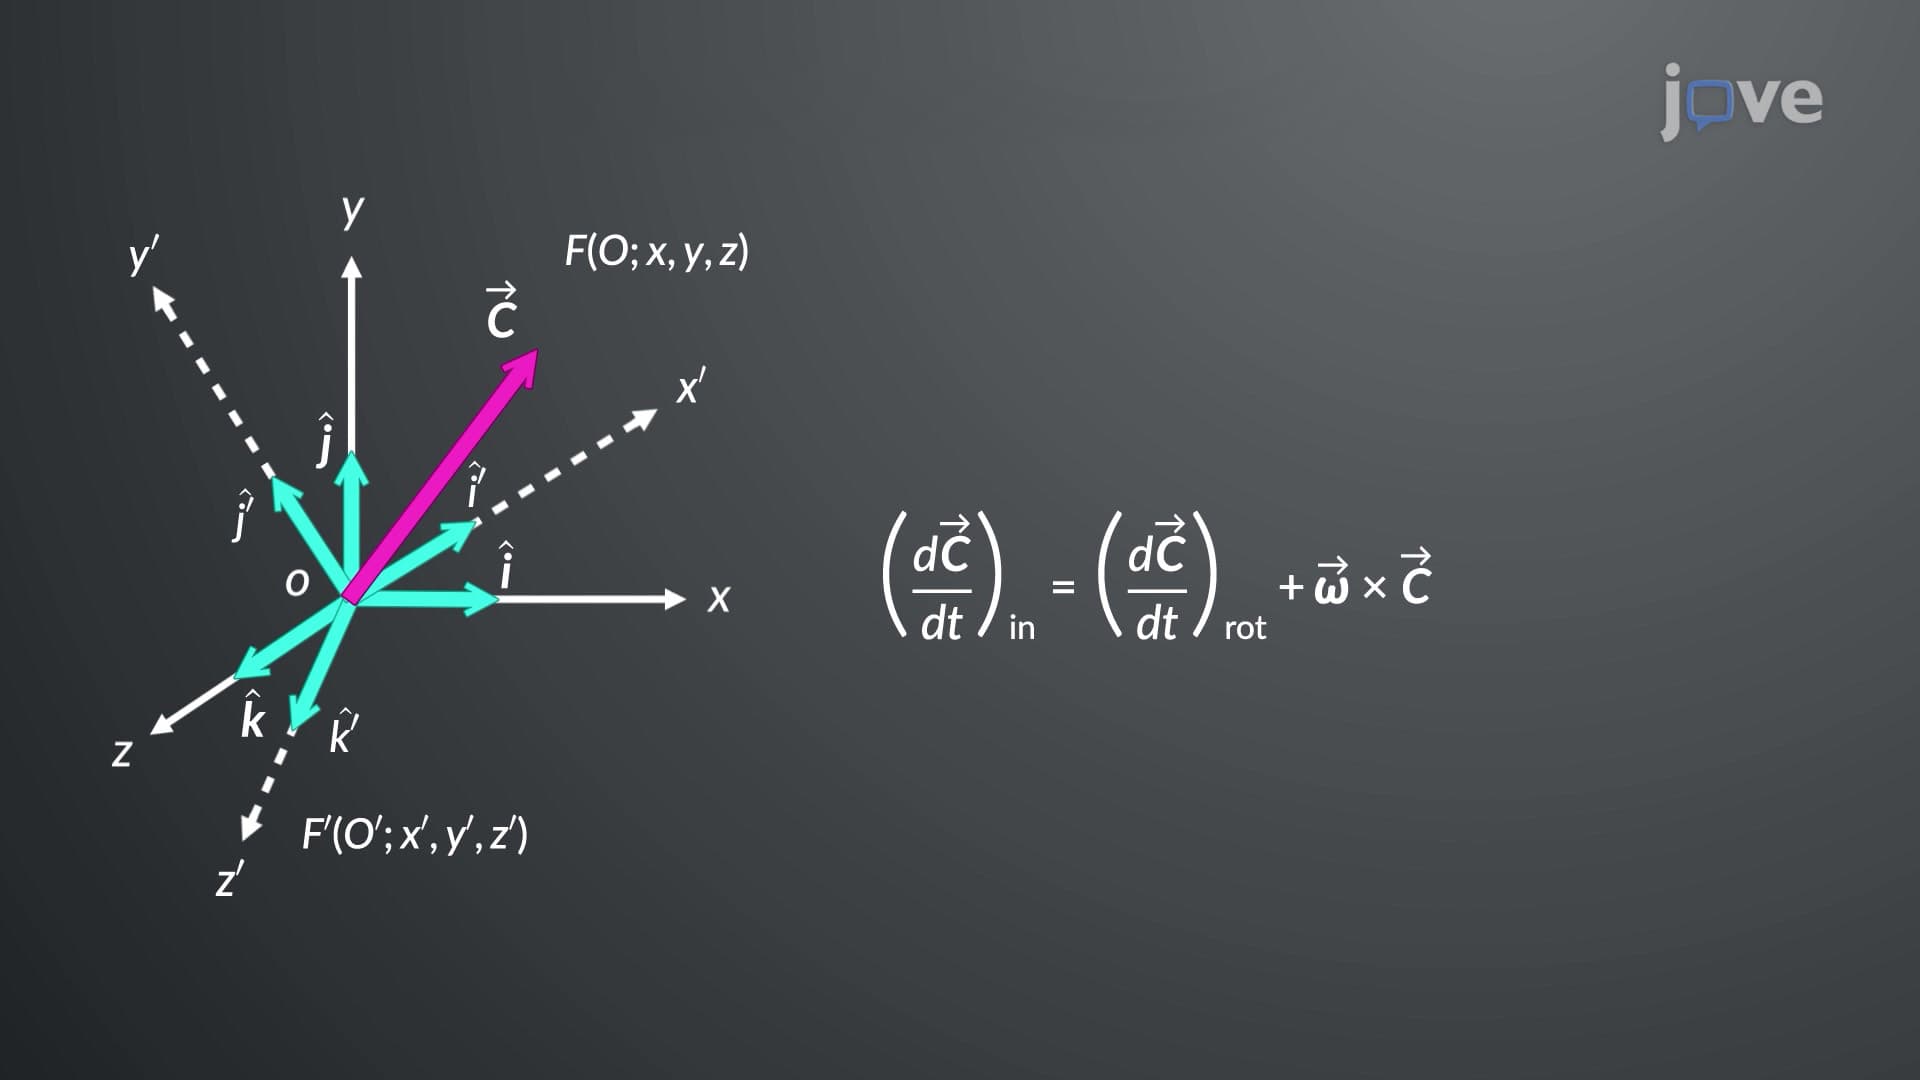
Vector Transformation in Rotating Coordinate Systems
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:22
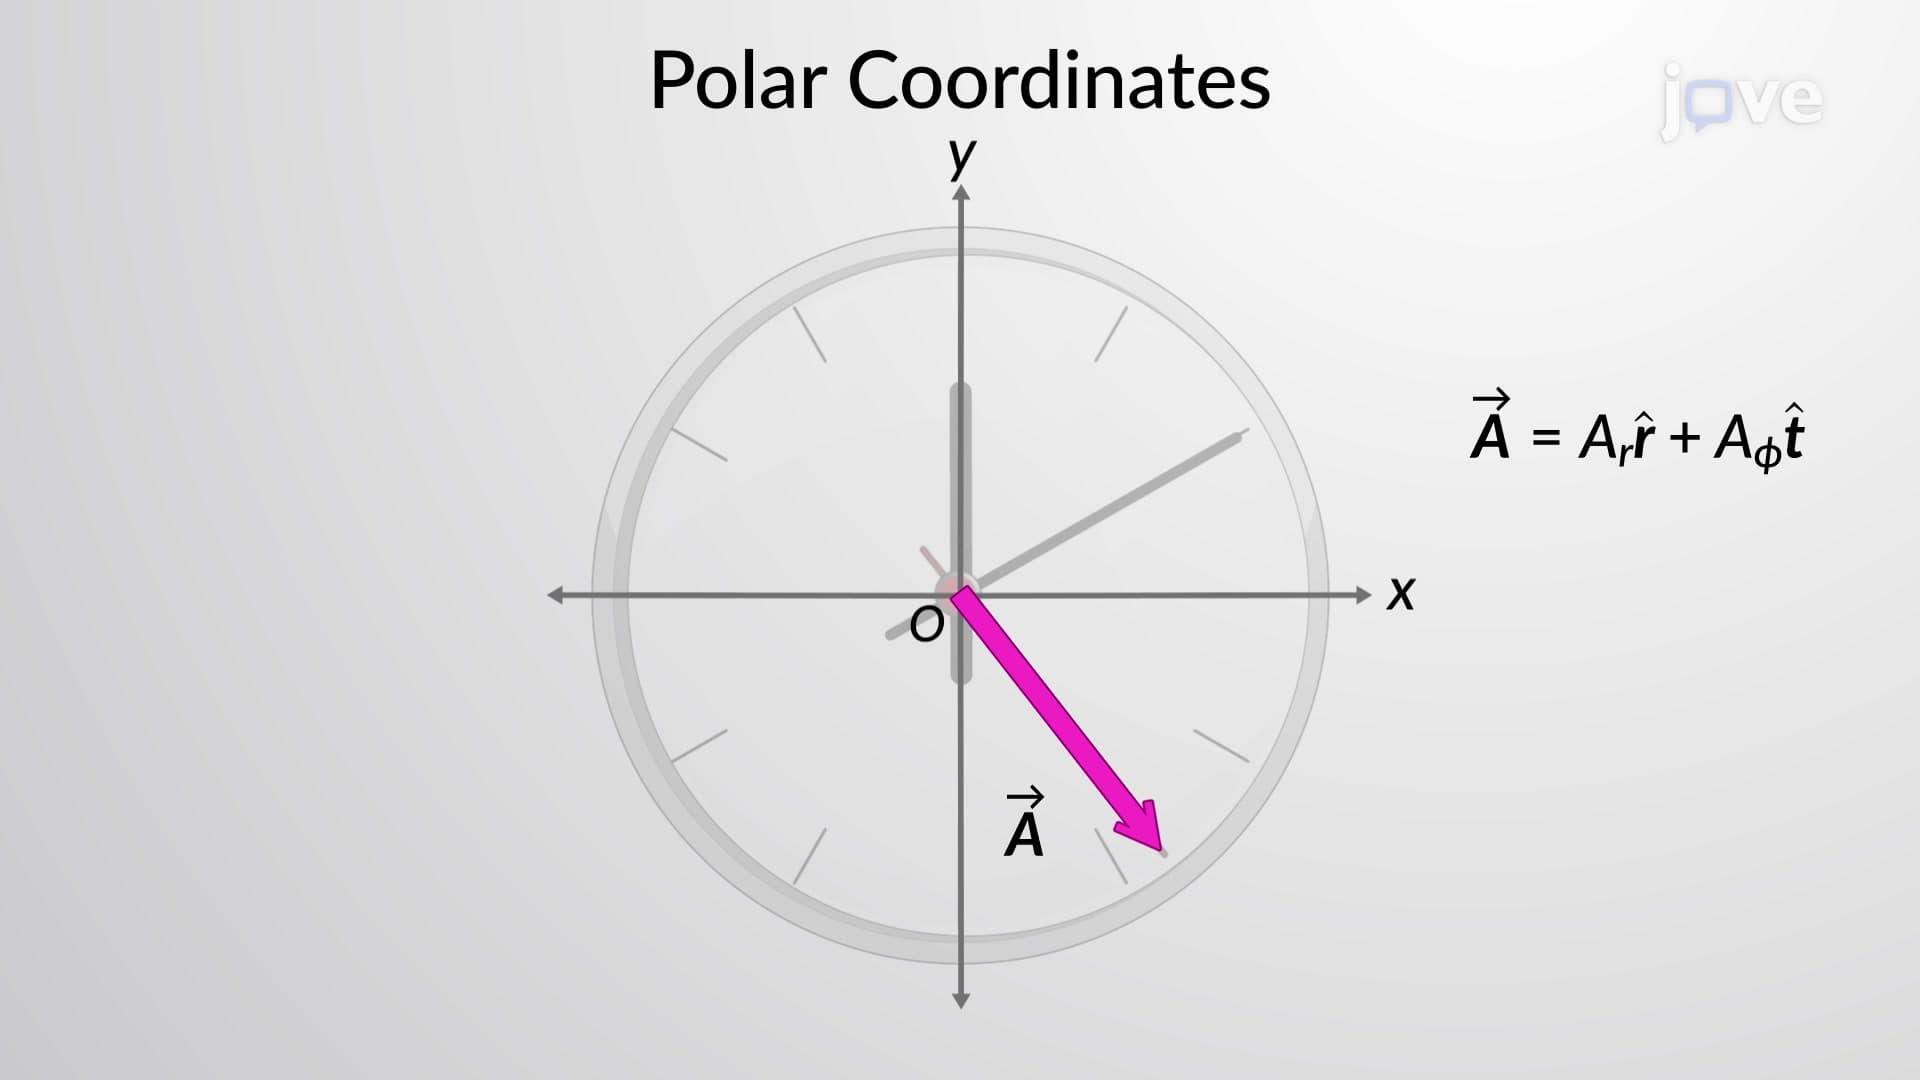
Polar and Cylindrical Coordinates