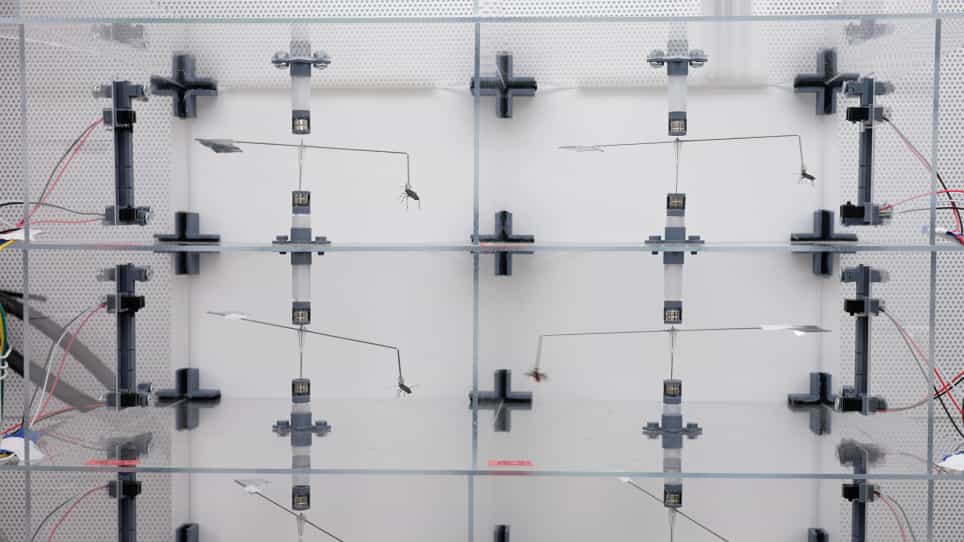
龙悬浮飞行期间的推力平衡模型
Kaixuan Zhang1, Xiaohui Su1, Yong Zhao2
1School of Hydraulic Engineering, Dalian University of Technology, Dalian 116024, People's Republic of China.
Bioinspiration & biomimetics
|October 30, 2024

概括
本研究引入了一种双翼推力平衡模型 (DTBM),以解决微型空中车辆 (MAV) 由于推力不平衡而产生的振荡. DTBM有效地平衡推力,改善MAV的稳定性和控制.
科学领域:
- 航空航天工程 航空航天工程
- 生物模拟学是一种生物模拟学.
- 流体动力学 流体动力学
背景情况:
- 微型空中车辆 (MAV) 由于推力失衡而经历振荡.
- 在MAV中实现稳定的飞行,特别是在悬浮时,仍然是一个挑战.
研究的目的:
- 提出和验证双翼推力平衡模型 (DTBM) 以减轻MAV振荡.
- 分析翅膀动力学和推力产生之间的关系,以改善MAV控制.
主要方法:
- 开发了一种双翼推力平衡模型 (DTBM),使用修改的旋转角度公式.
- 调查了"au角度" (中转时的翅膀角度) 对推力系数的影响.
- 在模拟龙飞行中分析了推力平衡的实现和运动模式 (线性与非线性).
主要成果:
- 在几次代中,DTBM将平均推力系数降低到0.001以下.
- 对于复杂的运动模式,推力平衡在0.278秒内实现.
- 确定了与侧向力干扰相关的"角度",翅膀间距和翻动轨迹之间的线性和非线性相关性.
结论:
- DTBM为MAV的推力失衡问题提供了有效的解决方案.
- 了解机翼运动的非线性动力学对于先进的MAV设计至关重要.
- 未来的MAV可以从整合DTBM的算法中获益,以提高悬浮稳定性.
相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
217
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
217
 01:23
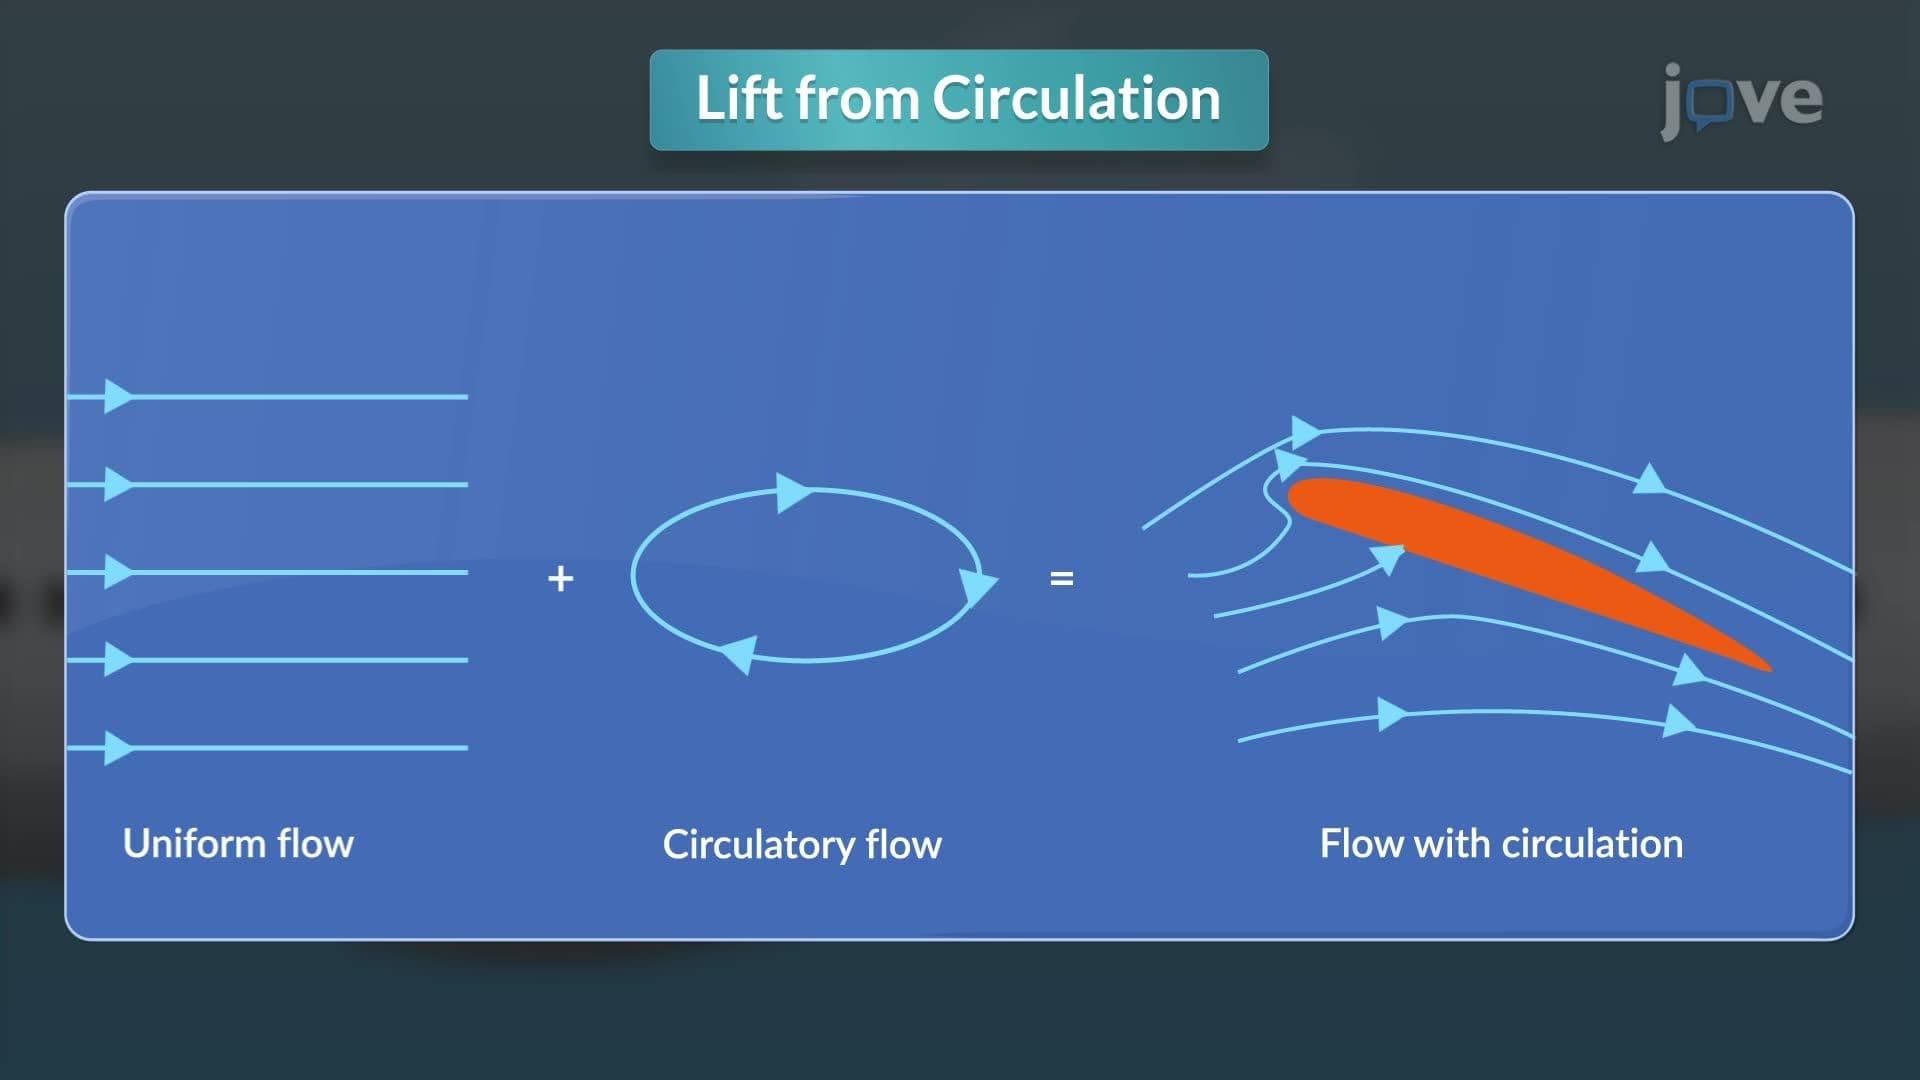
Lift
71
Lift is a fundamental aerodynamic force that acts perpendicular to the direction of airflow. It plays a central role in achieving and sustaining flight and in stabilizing various vehicles. Lift primarily originates from pressure differences created across surfaces, such as an airfoil. A lower pressure region forms above the wing, while a higher pressure region forms below it, generating an upward force. This differential results from the shape and orientation of the airfoil, enabling the wing...
71
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
1.4K
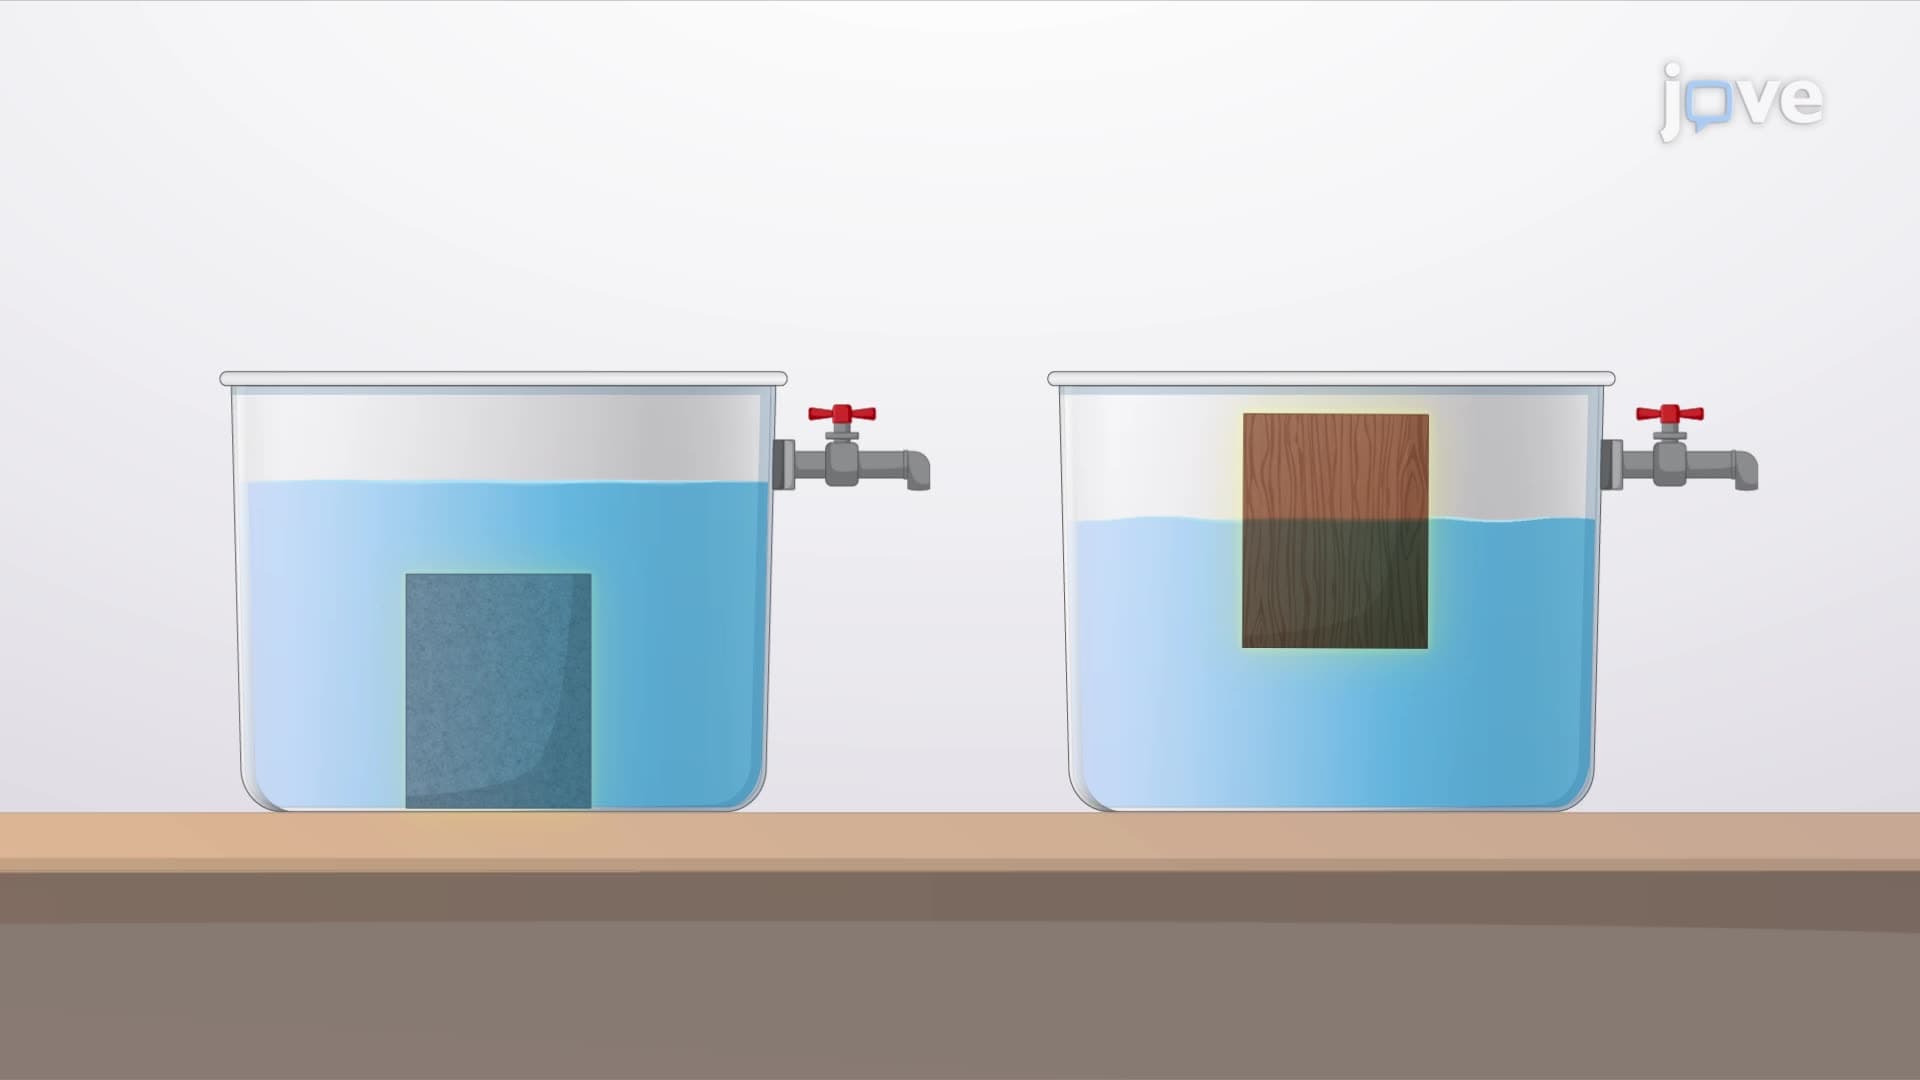
In fluid mechanics, buoyancy and stability are key concepts for understanding the behavior of submerged and floating bodies. When a stationary body is fully or partially submerged in a fluid, the fluid exerts a force on the body known as the buoyant force. This force acts vertically upward through a point called the center of buoyancy, which is the center of the displaced fluid volume. According to Archimedes' principle, the magnitude of the buoyant force is equal to the weight of the fluid...
1.4K
 01:25
Internal Forces and Center of Gravity
297
Internal forces and the center of gravity are fundamental concepts in mechanics, playing a crucial role in understanding the behavior and stability of structures and objects under various conditions. A comprehensive understanding of these principles is essential for engineers, architects, and designers to create safe and efficient systems.
Internal forces are generated within a body due to the interaction between its particles. These forces can be categorized into tension, compression, and...
Internal forces are generated within a body due to the interaction between its particles. These forces can be categorized into tension, compression, and...
297
 01:04
Hydrostatic Pressure Force on a Plane Surface
282
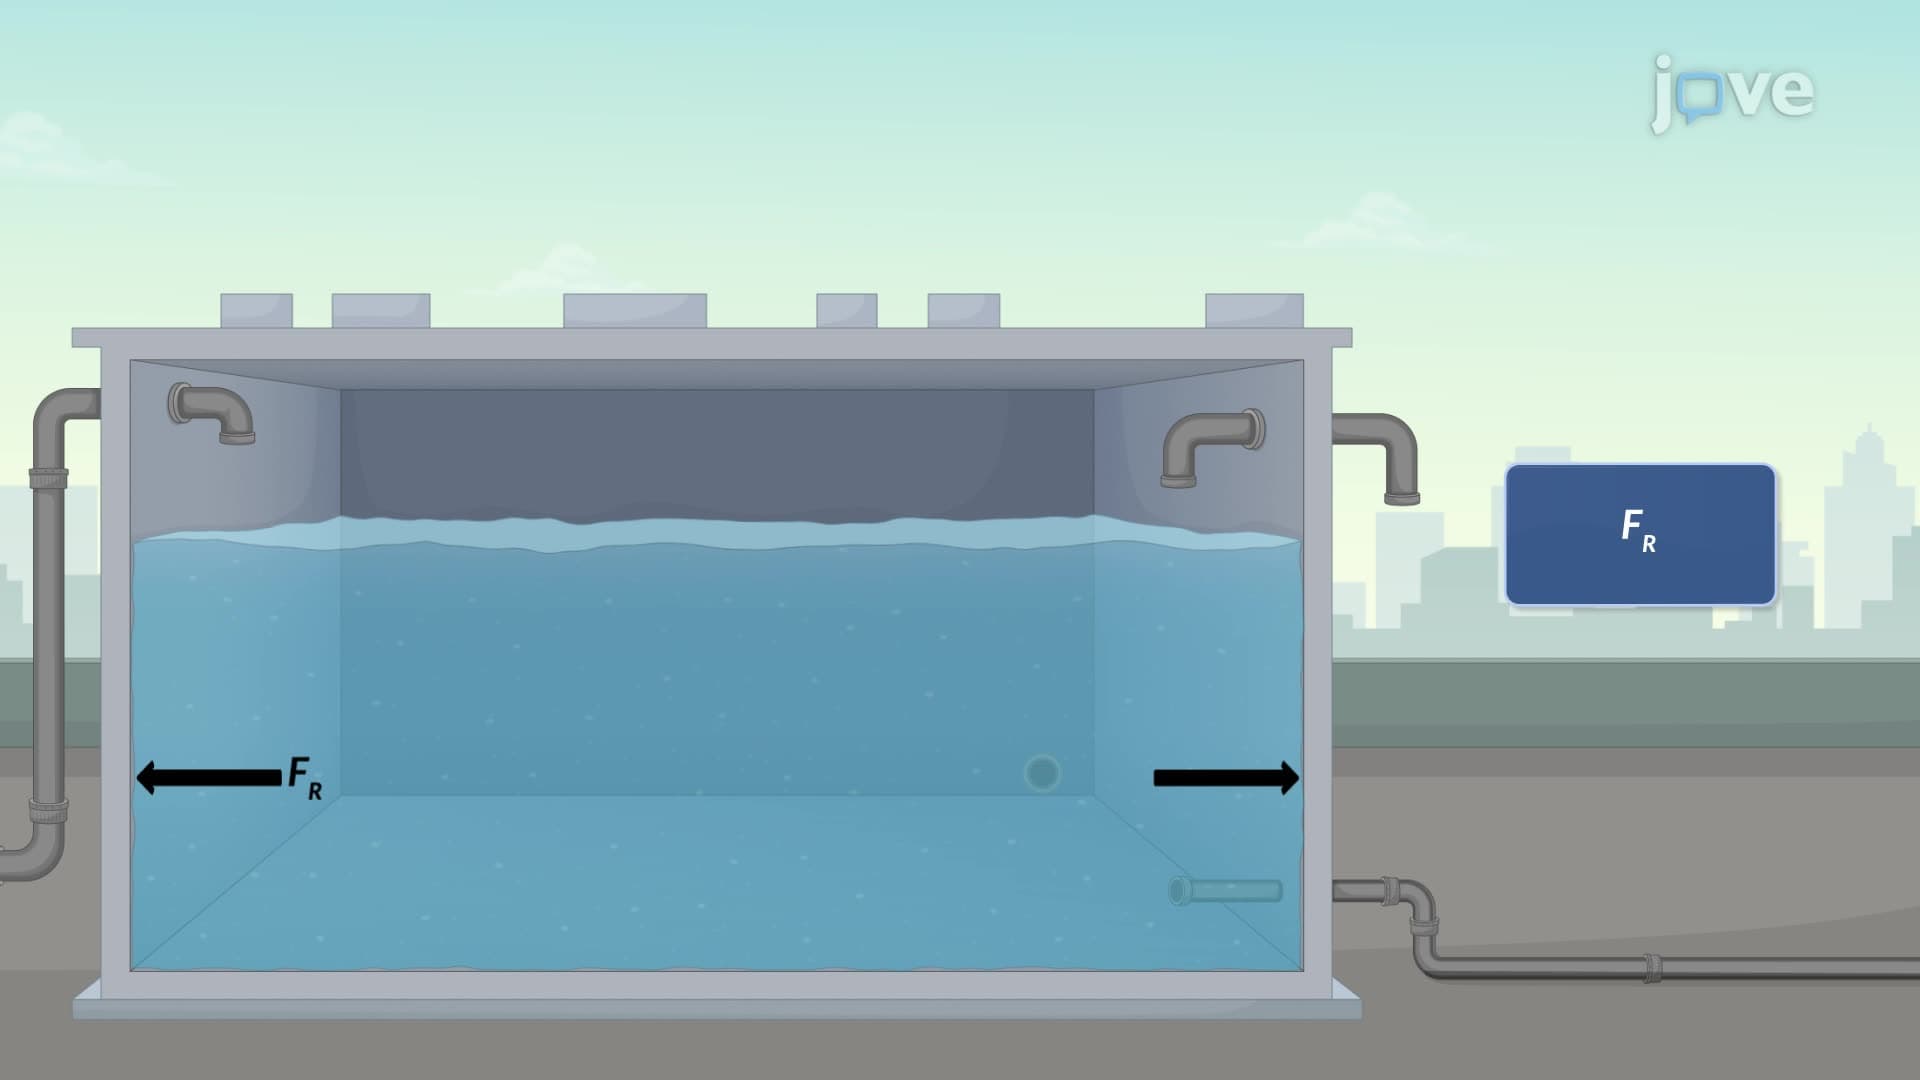
When a plane surface is submerged in a fluid, hydrostatic forces develop on the surface due to the fluid's pressure. For horizontal surfaces, the pressure exerted by the fluid is uniform because the depth remains constant. The resultant force is determined by the pressure at the given depth multiplied by the area of the surface, and it acts through the centroid of the surface. For vertical surfaces, the pressure varies with depth, increasing as the distance from the fluid's free surface...
282
 01:21
Rigid Body Equilibrium Problems - II
7.0K
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
7.0K