对于电力系统动态同步与传感器增益降解的稳健估计方法

Yi Wang1, Jiawei Zhang1, Yaoqiang Wang1
1School of Electrical and Information Engineering, Zhengzhou University, Zhengzhou 450001, China.
ISA transactions
|November 19, 2024

概括
这项研究引入了一种可靠的方法来估计电网同步动态,即使有传感器故障. 新型修改的耐故障扩展卡尔曼波器 (MFTEKF) 确保精确监控频率,电压和大小.
科学领域:
- 电气工程 电气工程
- 控制系统 控制系统
- 信号处理 信号处理
背景情况:
- 实时电力系统同步估计对于运行安全至关重要.
- 由于故障或干扰而导致的传感器增益降低会损害估计准确度.
研究的目的:
- 开发一种可靠的方法,用于在传感器增强降低下动态估计电网同步.
- 准确监测和跟踪频率,电压相角和大小.
主要方法:
- 使用离散分布 [0,1] 描述随机传感器增益降解.
- 建立了传感器增强降解的状态空间模型.
- 在递归估计器框架内开发了一种新的修改过失耐受扩展卡尔曼波器 (MFTEKF).
主要成果:
- 拟议的MFTEKF在动态估计方面表现强.
- 实现了电网动态特征的精确监测和跟踪.
- 实验结果验证了MFTEKF的有效性.
结论:
- 在传感器增益降低的情况下,MFTEKF为电网同步估计提供了可靠的解决方案.
- 这种方法提高了电力系统的安全性和操作控制.
- 开发的过器有效地解决了现实世界的传感器缺陷带来的挑战.
相关概念视频
 01:25
Multimachine Stability
141
Multimachine stability analysis is crucial for understanding the dynamics and stability of power systems with multiple synchronous machines. The objective is to solve the swing equations for a network of M machines connected to an N-bus power system.
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
141
 01:30
Simplified Synchronous Machine Model
185
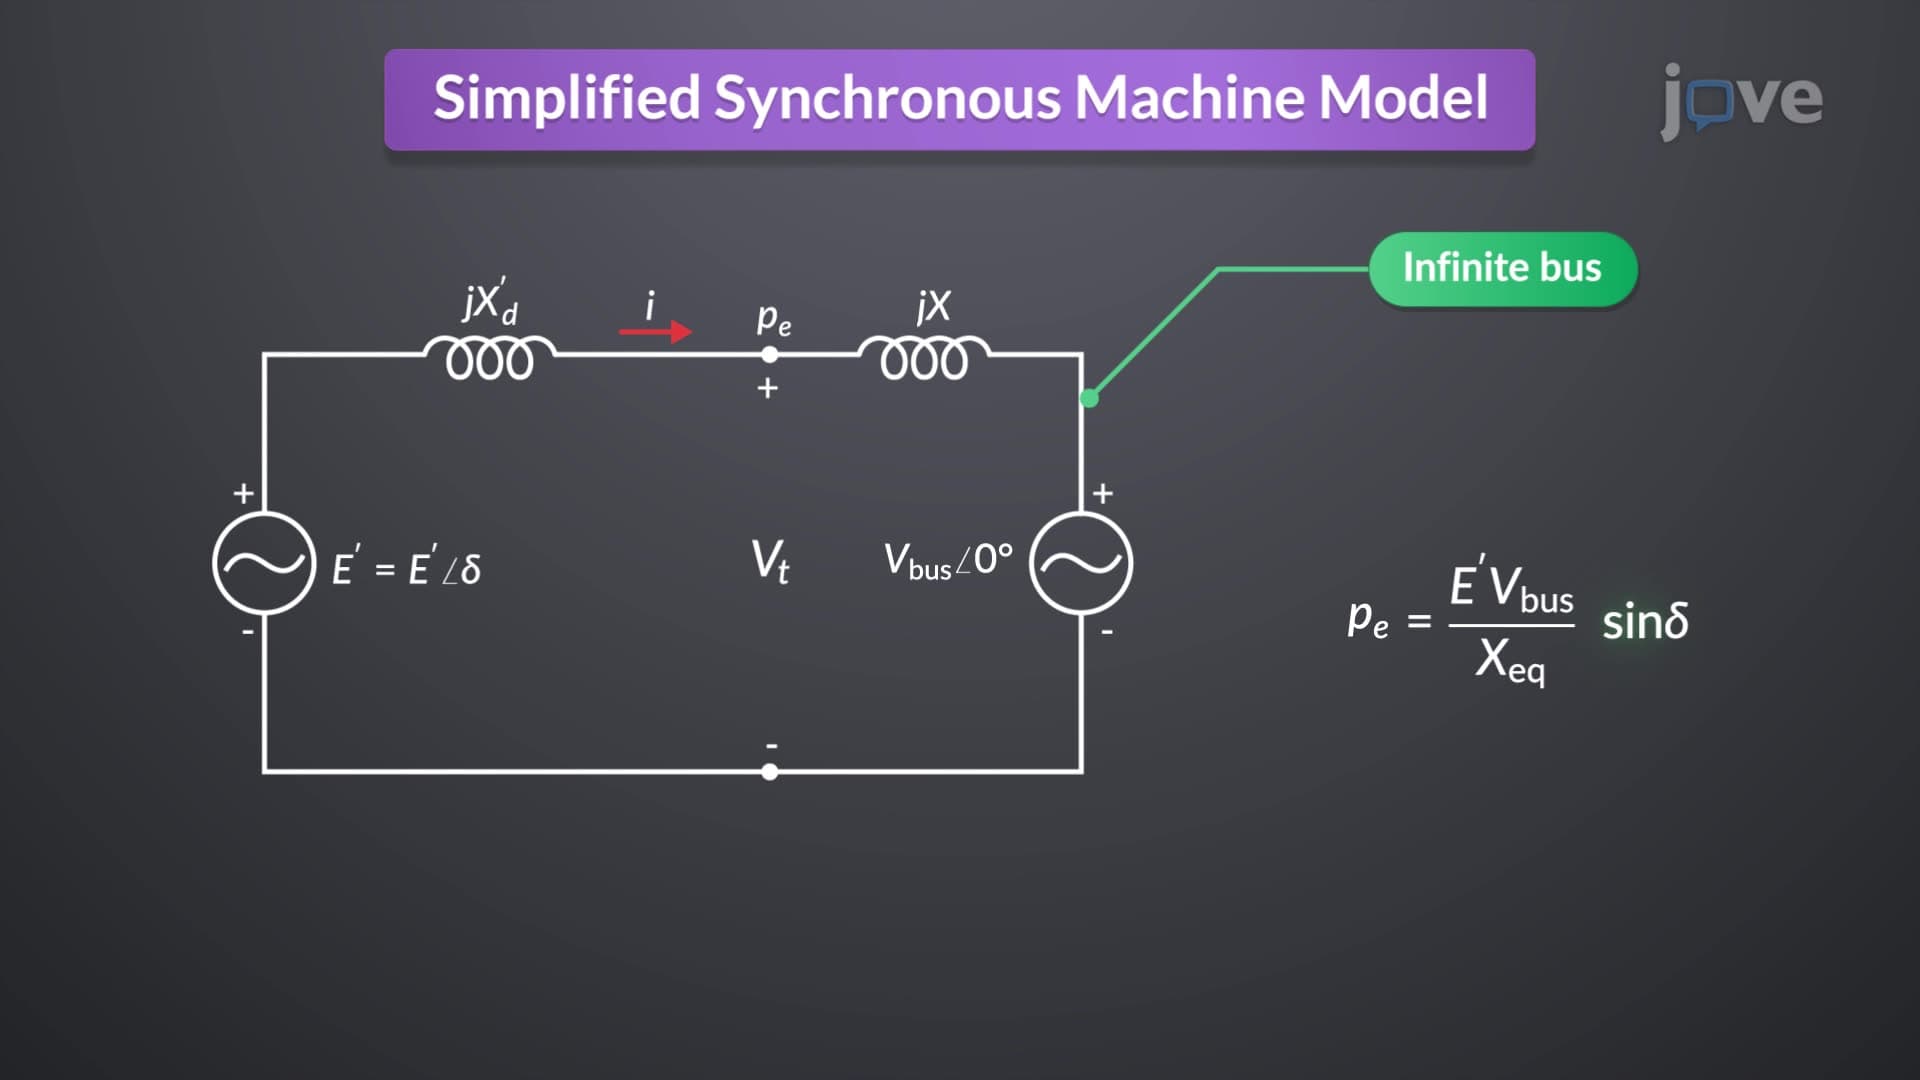
The Synchronous Machine Model is a fundamental tool in analyzing and ensuring the transient stability of power systems. This model simplifies the representation of a synchronous machine under balanced three-phase positive-sequence conditions, assuming constant excitation and ignoring losses and saturation. The model is pivotal for understanding the behavior of synchronous generators connected to a power grid, particularly during transient events.
In this model, each generator is connected to a...
In this model, each generator is connected to a...
185
 01:25
Distribution Reliability and Automation
105
Distribution reliability in electrical power systems is critical for ensuring an uninterrupted power supply to consumers at minimal cost. According to IEEE Standard Terms, reliability is the probability that a device will function without failure over a specified time period or amount of usage. For electric power distribution, this translates to maintaining continuous power supply and addressing customer concerns over power outages. Several indices, as defined by IEEE Standard 1366-2012, are...
105
 01:07
Time-Domain Interpretation of PD Control
83
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
83
 01:21
Energy Losses in Transformers
834
In an ideal transformer, it is assumed that there are no energy losses, and, hence, all the power at the primary winding is transferred to the secondary winding. However, in reality, the transformers always have some energy losses, and, hence, the output power obtained at the secondary winding is less than the input power at the primary winding due to energy losses.
There are four main reasons for energy losses in transformers.
The first cause can be the high resistance of the...
There are four main reasons for energy losses in transformers.
The first cause can be the high resistance of the...
834
 01:19
Plotting and Calibrating the Root Locus
92
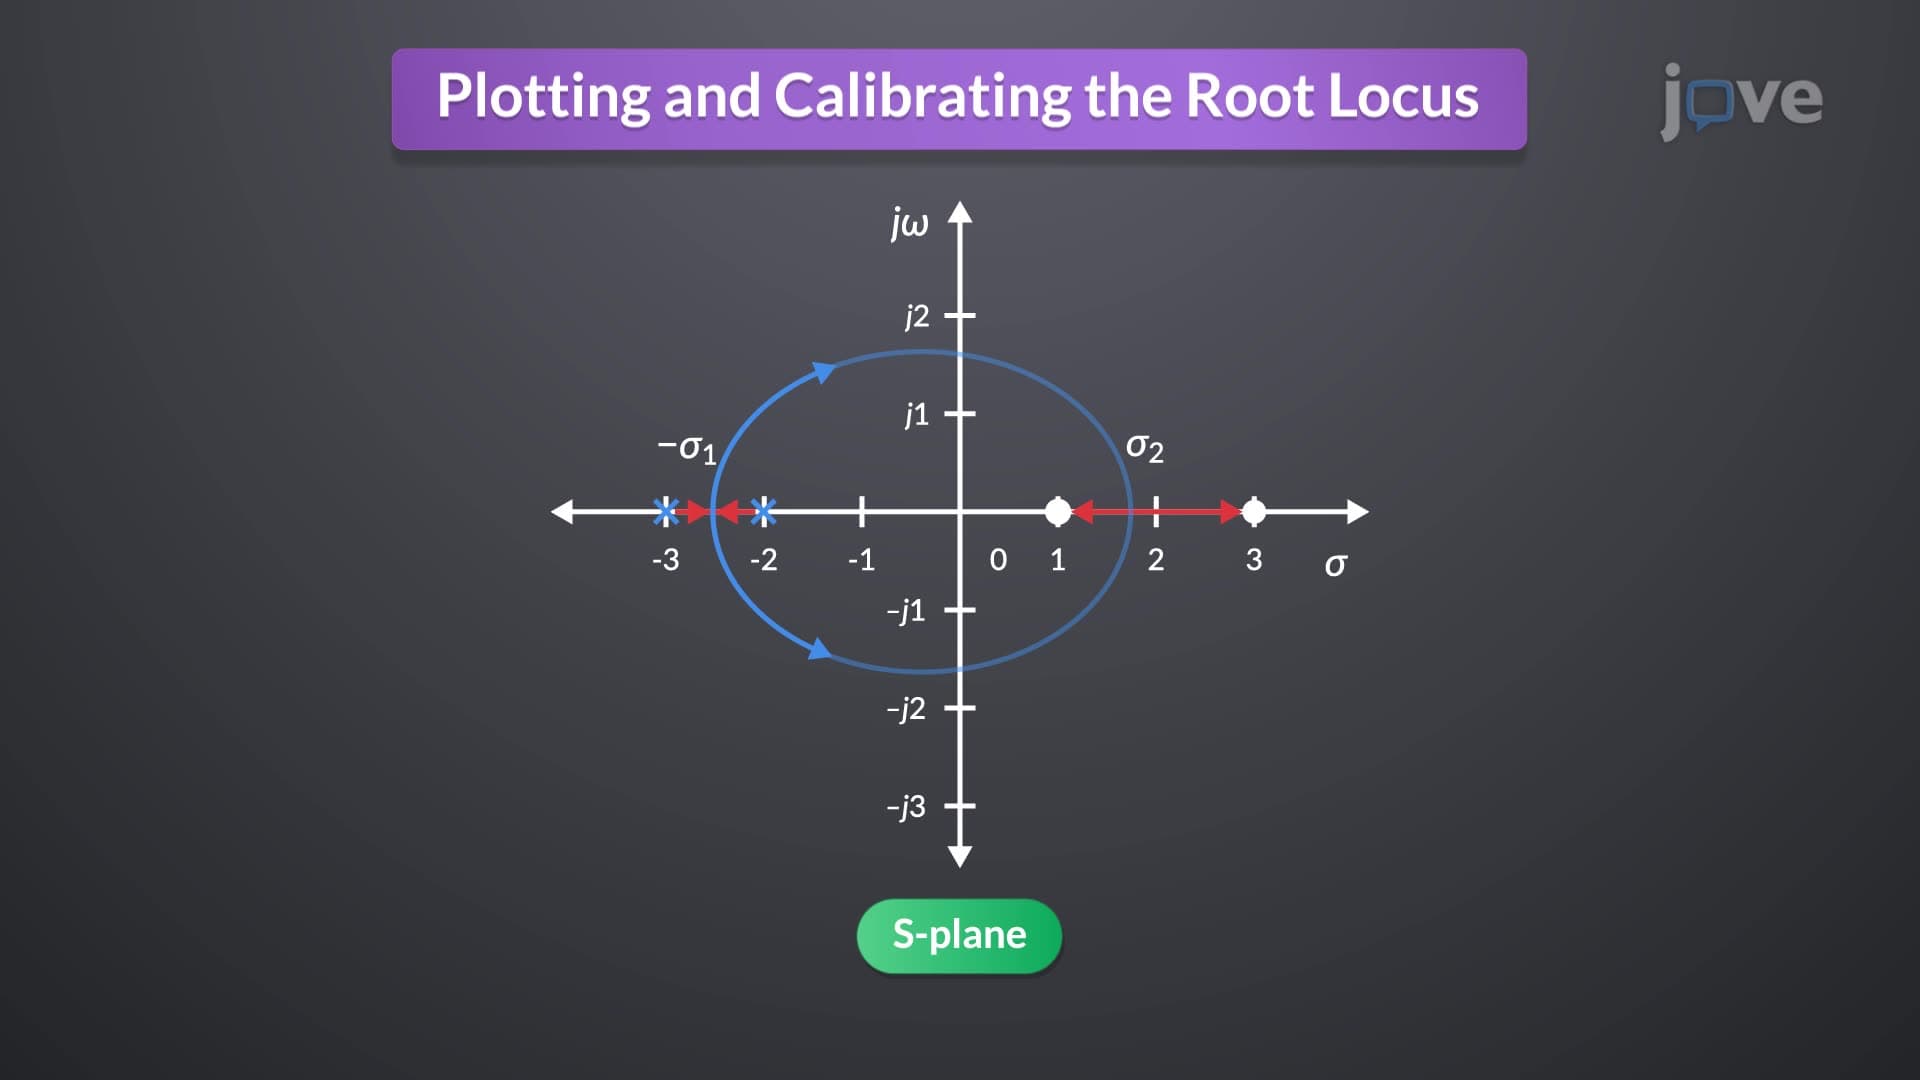
Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
92