
两个合的范德波尔振荡器的福克尔-普朗克动态受到随机强迫
Minwoo Lee1,2, Vikrant Gupta3,4, Larry K B Li2,5
1Department of Mechanical Engineering, <a href="https://ror.org/00x514t95">Hanbat National University</a>, Daejeon 34158, South Korea.
Physical review. E
|November 20, 2024

概括
这项研究为在随机强迫下合的范德波尔振荡器提供了概率解决方案. 这些发现为Hopf点附近的噪音振荡器系统提供了改进的预测和控制.
科学领域:
- 非线性动力学是一种非线性动力学.
- 随机系统 随机系统是指随机系统.
- 统计物理学的统计物理.
背景情况:
- 合范德波尔振荡器是非线性动力学的基本模型.
- 对于许多物理系统来说,了解它们在随机强迫下的行为至关重要.
- 之前的研究往往简化了合机制,或缺乏对噪声效应的全面分析.
研究的目的:
- 导出和验证相互合的范德波尔振荡器的概率解决方案,具有不同的合类型 (反应性,消散性,非线性).
- 调查随机强迫对振荡器动态的影响,包括振幅波动和分叉特征.
- 提供分析表达式,以加强对此类系统的预测和控制.
主要方法:
- 随机平均化来导出静止的福克-普朗克方程.
- 在各种噪声级别和合强度的分析解决方案的数值验证.
- 对波动幅度的概率密度函数的分析.
主要成果:
- 对于每个合器类型,导出固定福克-普朗克方程.
- 为波动幅度获得的概率密度函数.
- 数字验证的分析解决方案,证明不同随机和合参数的准确性.
- 具有特征的随机和分叉行为.
结论:
- 该研究成功地为合的范德波尔振荡器提出了验证的概率解决方案.
- 由此得出的分析表达式适用于噪声接近Hopf点的系统.
- 这些发现可以提高复杂的合振荡器系统的预测和控制.
相关概念视频
 01:06
Forced Oscillations
6.5K
When an oscillator is forced with a periodic driving force, the motion may seem chaotic. The motions of such oscillators are known as transients. After the transients die out, the oscillator reaches a steady state, where the motion is periodic, and the displacement is determined.
6.5K
 01:07
Damped Oscillations
5.7K
In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
Although friction and other non-conservative...
5.7K
 01:04
Oscillations about an Equilibrium Position
5.3K
Stability is an important concept in oscillation. If an equilibrium point is stable, a slight disturbance of an object that is initially at the stable equilibrium point will cause the object to oscillate around that point. For an unstable equilibrium point, if the object is disturbed slightly, it will not return to the equilibrium point. There are three conditions for equilibrium points—stable, unstable, and half-stable. A half-stable equilibrium point is also unstable, but is named so...
5.3K
 01:20
Types of Damping
6.4K
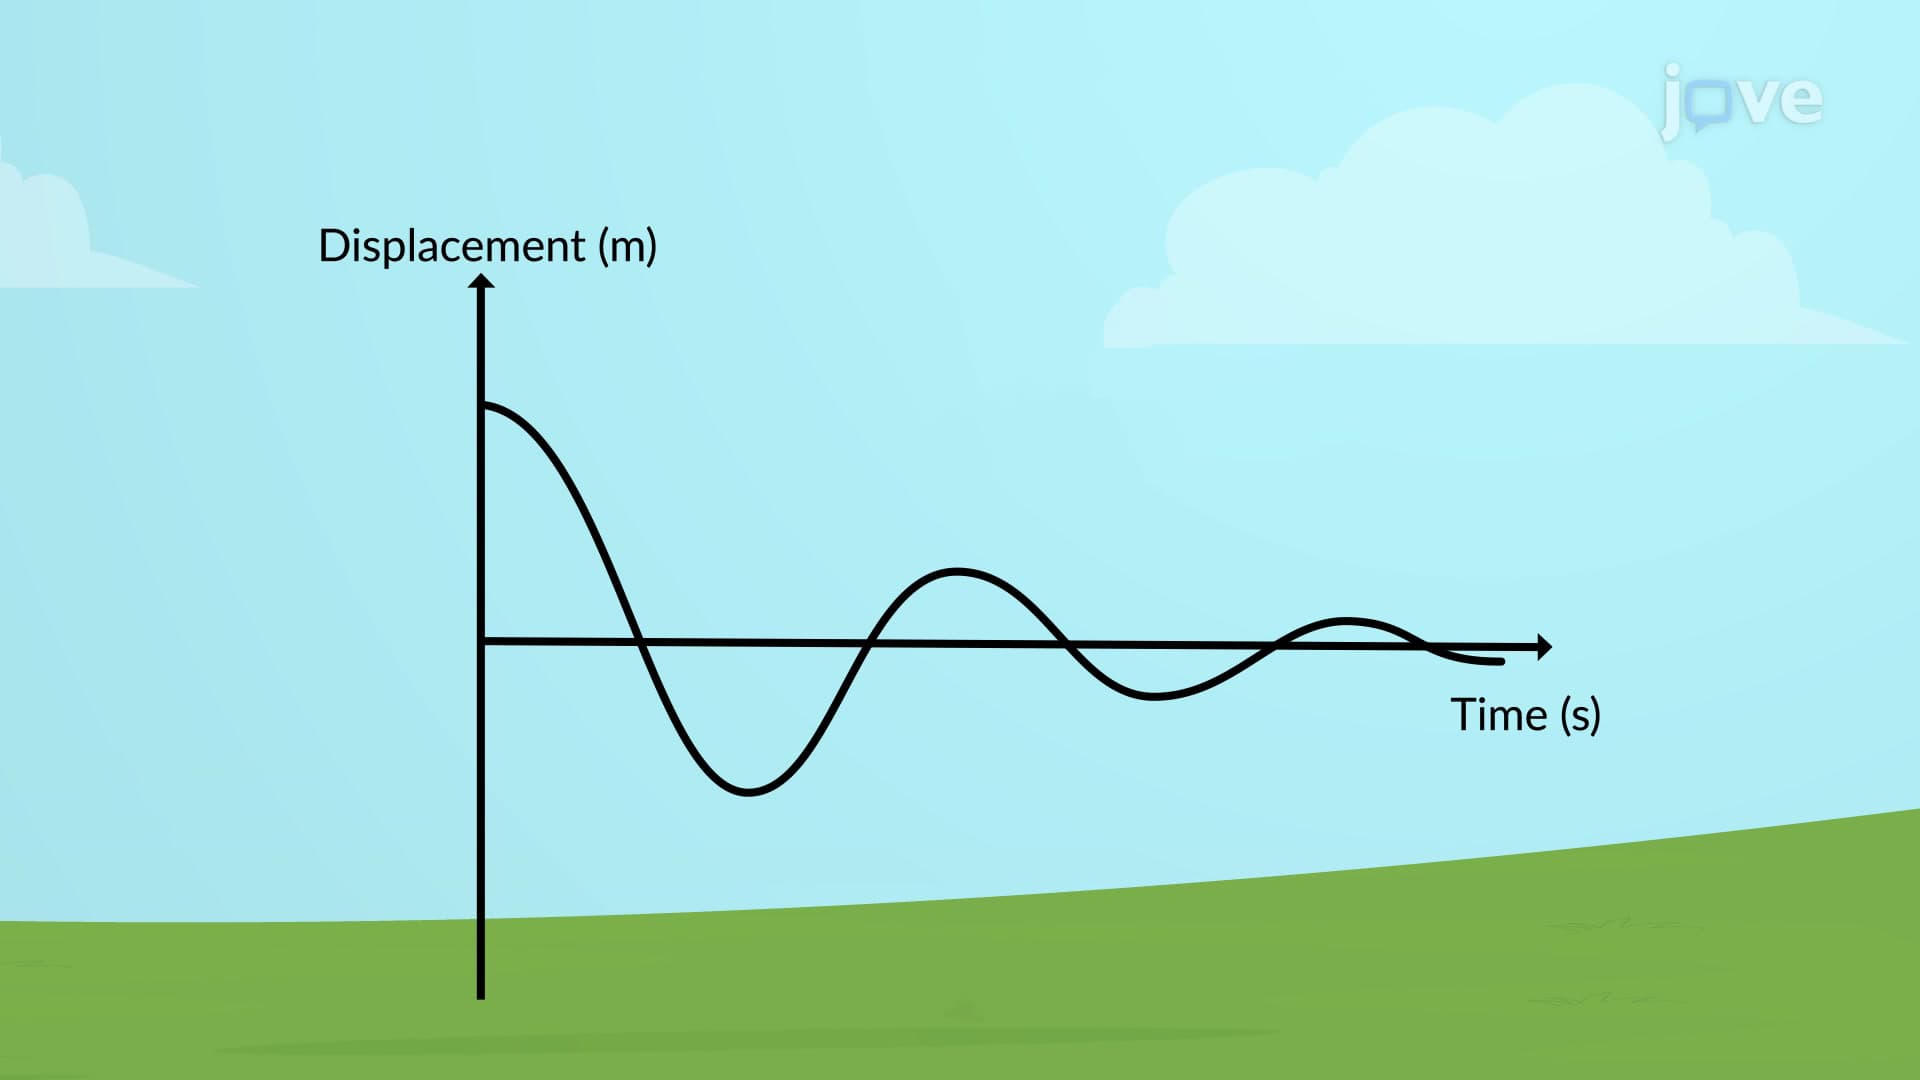
If the amount of damping in a system is gradually increased, the period and frequency start to become affected because damping opposes, and hence slows, the back and forth motion (the net force is smaller in both directions). If there is a very large amount of damping, the system does not even oscillate; instead, it slowly moves toward equilibrium. In brief, an overdamped system moves slowly towards equilibrium, whereas an underdamped system moves quickly to equilibrium but will oscillate about...
6.4K
 01:25
Poisson's And Laplace's Equation
2.6K
The electric potential of the system can be calculated by relating it to the electric charge densities that give rise to the electric potential. The differential form of Gauss's law expresses the electric field's divergence in terms of the electric charge density.
2.6K
 01:18
Second Order systems II
90
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
90