
双脚弹质量模型在行走中的触摸下降状态控制
Hamid Vejdani1, Albert Wu2, Hartmut Geyer2
1Mechanical, Robotics, and Industrial Engineering Department, Lawrence Technological University, Southfield, MI, United States of America.
Bioinspiration & biomimetics
|November 21, 2024

概括
研究人员为双脚弹质量模型制定了稳定控制策略,提高了对动物运动和机器人设计的理解. 这一政策确保了使用国家内部信息来防止干扰的稳定性.
科学领域:
- 机器人和生物力学
- 动态系统理论 动态系统理论
背景情况:
- 动物双脚运动是复杂的.
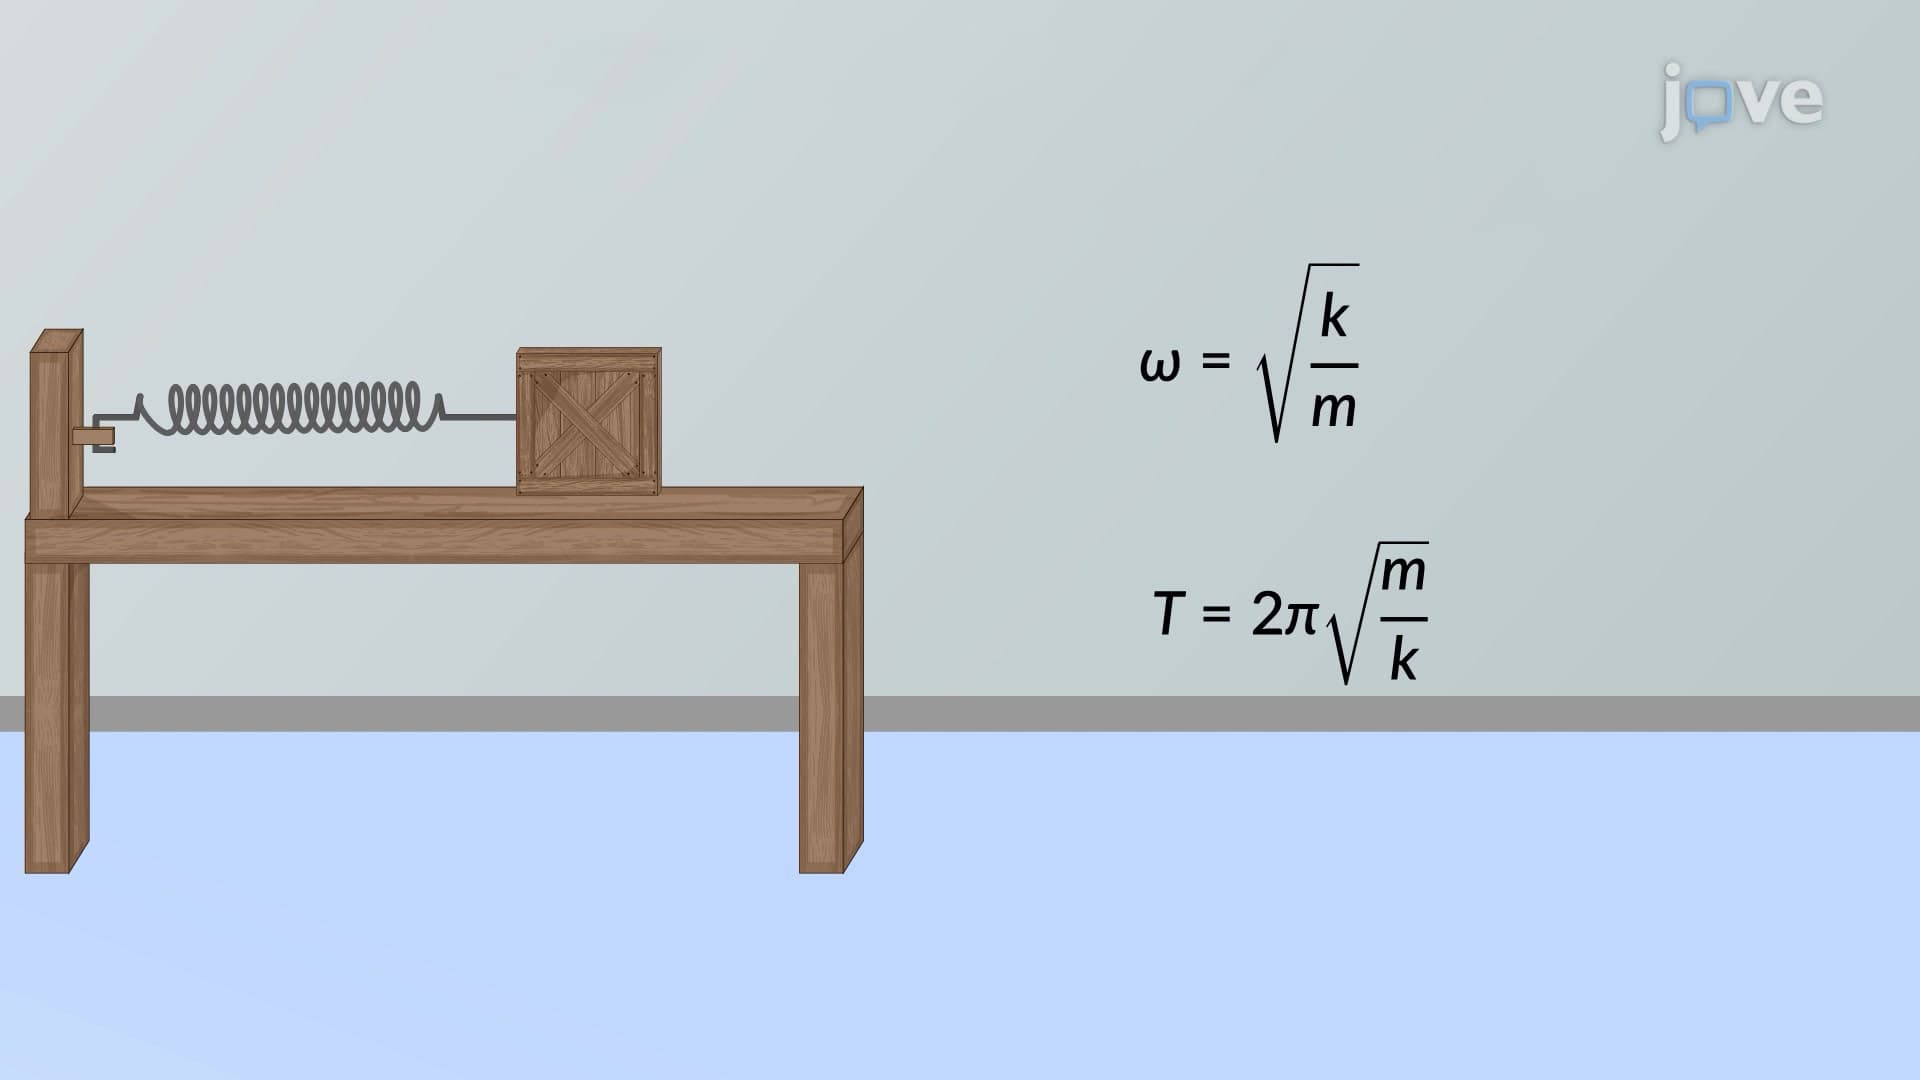
- 双脚弹质量模型简化并预测运动动态.
研究的目的:
- 分析双脚弹质量模型的步态.
- 提出一个稳定着陆触摸控制政策.
- 概括系统独立性的结果.
主要方法:
- 无维的运动方程. 无维的运动方程.
- 分析了平衡步态 (固定点).
- 执行了触地政策的稳定性分析.
主要成果:
- 拟议的政策稳定了对称平衡步态.
- 具有特征的峰值腿部力变化.
- 在不同地形上模拟机车运动.
结论:
- 触地政策对各种步态和条件有效.
- 这些发现有助于我们更好地理解动物的运动.
- 适用于机器人系统设计和控制.