

设计了一种新型状态反强大的滑动模式控制器,用于液压轮控制系统
Fang Dao1, Yidong Zou2, Jing Qian1
1Kunming University of Science and Technology, School of Metallurgical and Energy Engineering, Kunming, 650000, PR China.
Scientific reports
|November 23, 2024

概括
一个新的强大的滑动模式控制器增强了面临干扰的液压轮控制系统. 这种先进的控制方法在不确定的条件下提高了系统的稳定性和性能.
科学领域:
- 控制工程 控制工程 控制工程
- 流体动力学 流体动力学
- 电力系统 电力系统
背景情况:
- 水力轮机控制系统 (HTGS) 对于电网稳定性至关重要,但容易受到干扰.
- 复杂的管道动力学和外部负载变化带来了重大的控制挑战.
- 现有的控制器在不确定性下努力保持最佳性能.
研究的目的:
- 为HTGS开发一种新的状态反强大的滑动模式控制器 (SFRSMC).
- 提高HTGS对干扰和不确定性的稳定性和性能.
- 为了最佳的控制器设计,使用混合方法.
主要方法:
- 开发了一个HTGS动态的状态空间模型.
- 设计的SFRSMC使用滑动模式等效控制和干扰观察器.
- 使用混合线性矩阵不等式 (LMI) 进行滑动矩阵确定.
- 通过时间域模拟验证了控制器.
主要成果:
- 拟议的SFRSMC有效地减轻了外部负载干扰和控制信号的不确定性.
- 混合方法成功地平衡了稳健性和最佳性.
- 模拟显示,在各种操作场景中,控制性能得到了提高.
- 干扰观察者准确地估计和补偿未知的干扰.
结论:
- 新的SFRSMC为HTGS控制提供了强大而有效的解决方案.
- 混合LMI方法提供了一种系统的方式来设计高性能控制器.
- 拟议的方法提高了液压发电的稳定性和可靠性.
相关概念视频
 01:17
Turbine-Governor Control
167
Turbine-governor control is crucial for maintaining power system stability by balancing turbine mechanical power output with electrical load demand. This mechanism ensures that generator frequency and rotor speed are within acceptable limits during load variations. Turbine-generator units store kinetic energy due to their rotating masses; this energy is released to meet the load requirement when the load increases. The electrical torque of turbines rises to meet the demand, whereas the...
167
 01:11
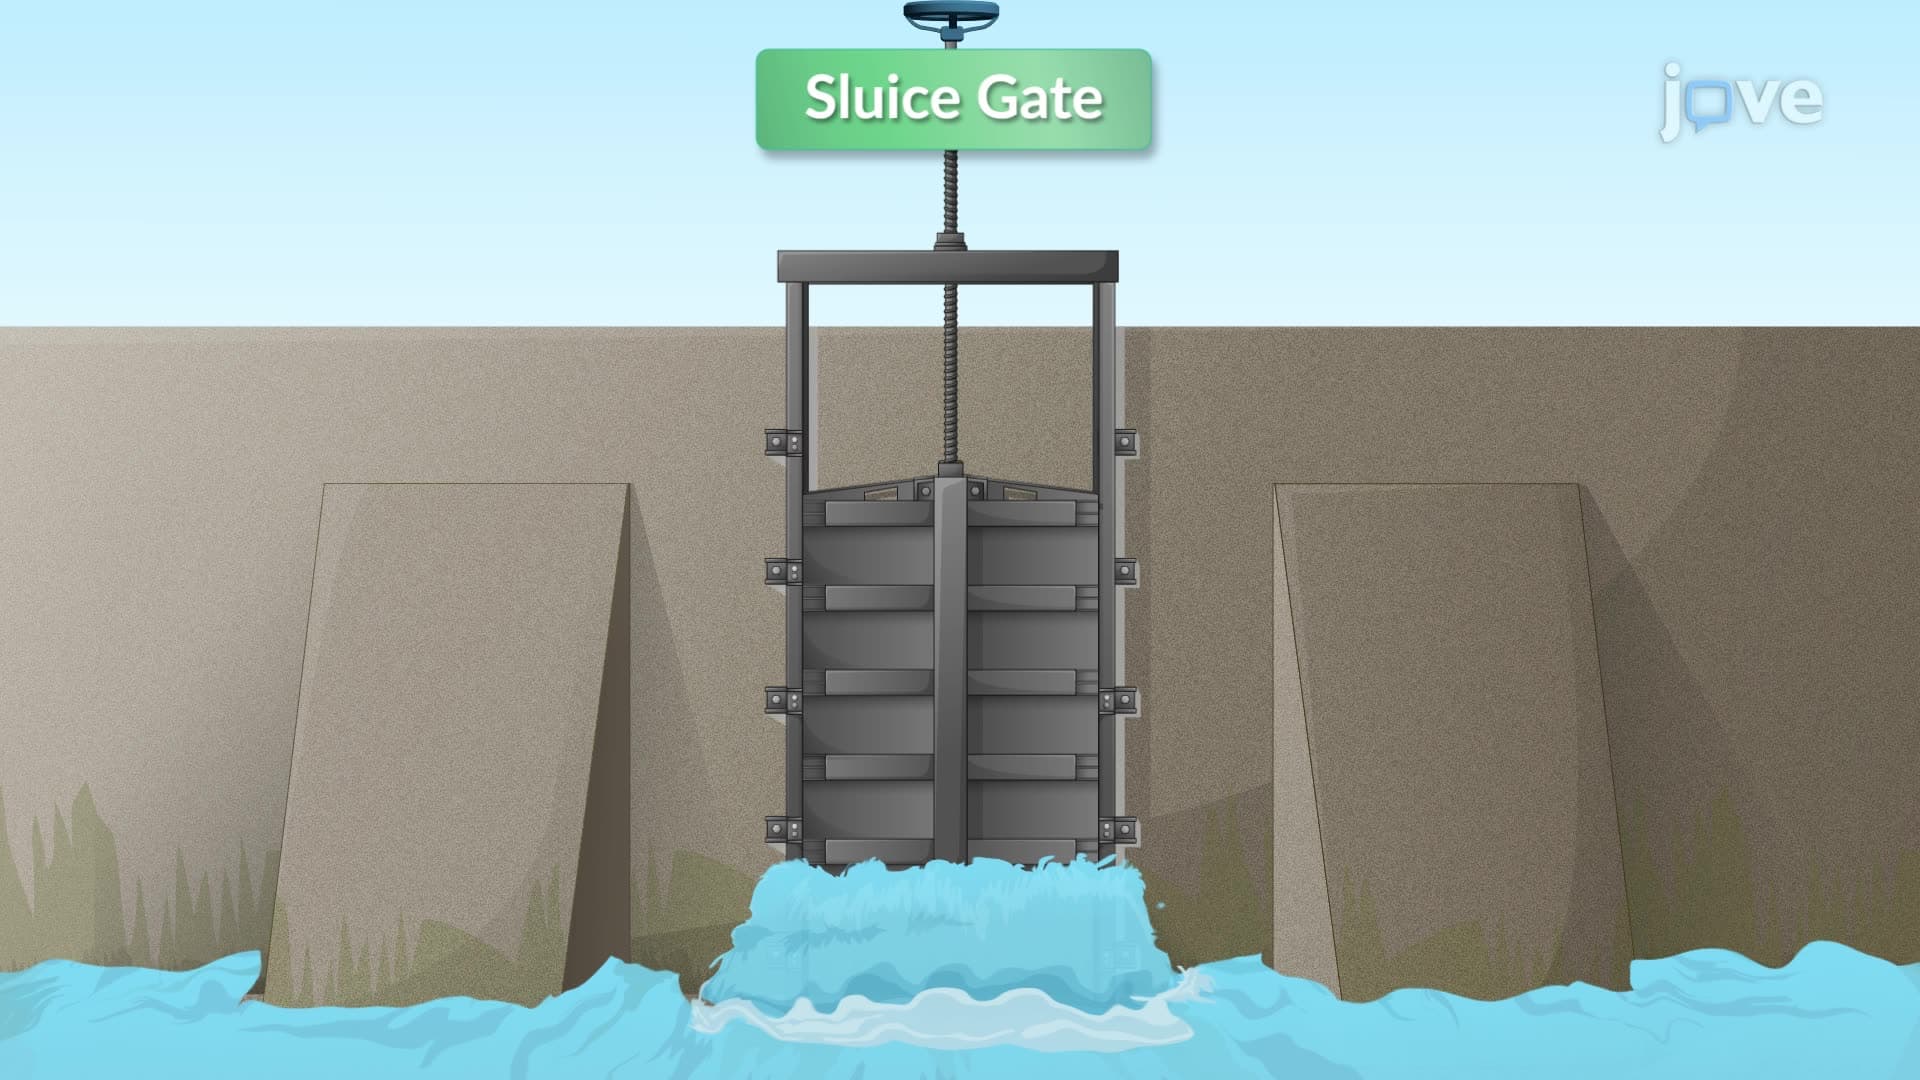
Design Example: Forces in Sluice Gate
361
In hydraulic engineering, sluice gates are essential for managing water flow through channels, reservoirs, and irrigation systems. Sluice gates, acting as vertical barriers, regulate water by adjusting the gate's opening height, which changes the velocity and pressure of water flowing beneath the gate. Understanding the forces involved is crucial to designing sluice gates that can withstand dynamic pressure differences, especially when the gate is closed or partially open.
Key variables in...
Key variables in...
361
 01:22
Controller Configurations
85
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
85
 01:26
PD Controller: Design
191
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
191
 01:21
Design Example: Creating a Hydraulic Model of a Dam Spillway
125
Scaled hydraulic models of dam spillways provide a practical way to replicate and study the intricate flow dynamics of these structures. Often built to a 1:15 ratio, these models allow for observing critical water behavior, such as velocity distribution, flow patterns, and energy dissipation.
125
 01:17
Open and closed-loop control systems
642
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
642