相关实验视频
Updated: Jun 29, 2026
10:19

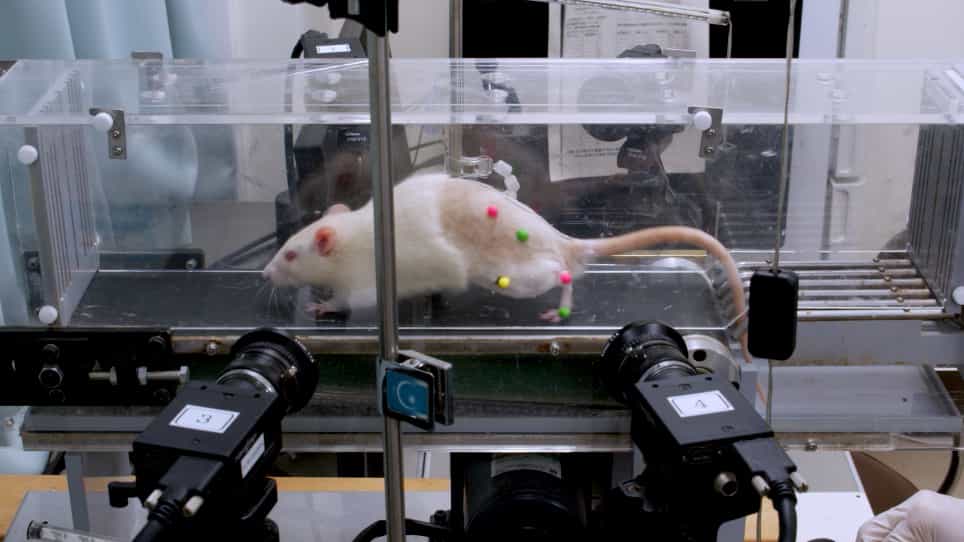
3D Kinematic Gait Analysis for Preclinical Studies in Rodents
Published on: August 3, 2019
10.6K
基于步态调整的蛇形机器人的同时定位和映射方法
Chaoquan Tang1, Zhipeng Zhang1, Meng Sun1
1Jiangsu Key Laboratory of Mine Mechanical and Electrical Equipment, School of Mechatronic Engineering, China University of Mining and Technology, Xuzhou 221116, China.
Biomimetics (Basel, Switzerland)
|November 26, 2024

概括
这项研究通过改进步态运动和融合视觉惯性数据来增强蛇机器人本地化和绘制 (SLAM). 新方法减少了传感器干扰,改善了现场应用的定位和制图精度.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 计算机视觉 计算机视觉
- 传感器融合式传感器
背景情况:
- 蛇机器人需要准确的自主定位和映射 (SLAM) 进行现场操作.
- 它们的复杂运动,包括大转和快速旋转,导致SLAM错误,如漂移和故障.
- 蛇机器人中的头特别阻碍了SLAM算法的融合.
研究的目的:
- 为强大的蛇机器人SLAM开发改进的步态运动和传感器融合方法.
- 为了应对蛇机器人运动在定位和制图准确性方面所带来的挑战.
- 提高SLAM系统在具有挑战性的机器人应用中的可靠性和性能.
主要方法:
- 评估了各种蛇机器人步行的适用于SLAM的适用性.
- 开发了一种用于蛇形行走的头部稳定性控制方法,以最大限度地减少传感器干扰.
- 提出了一种紧密结合的视觉惯性SLAM方法,整合了蛇形和弧形滚动步态.
主要成果:
- 改进的蛇形步态和头部稳定性控制减少了运动诱导的传感器干扰.
- 视觉惯性SLAM方法证明了蛇机器人的强度和准确性.
- 实验验证证了定位和地图构建能力的显著改进.
结论:
- 拟议的步态改进和紧密结合的视觉惯性SLAM有效地提高了蛇机器人的自主导航.
- 这些方法减轻了运动工件,导致更可靠,更精确的定位和映射.
- 这些发现有助于推进蛇机器人的现场应用.

相关概念视频
 01:24
One-Degree-of-Freedom System
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Controller Configurations
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:30
Vector Functions and Motion: Problem Solving
Accurate position tracking is fundamental to the safe and effective operation of unmanned aerial vehicles (UAVs), particularly during precision maneuvers near complex structures. In this scenario, a drone is programmed to perform a high-precision inspection of a vertical structure, starting at position ((x, y, z) = (3, 0, 0)), with an initial velocity oriented in the positive z-direction. The trajectory of the drone is governed by a time-dependent acceleration function a(t), which is predefined...