相关实验视频
Updated: Jun 6, 2025

10:09

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
6.6K
一个新的多传感器非线性紧紧合框架用于复合机器人定位和映射
Lu Chen1,2, Amir Hussain1,2, Yu Liu1
1School of Aeronautics and Astronautics, University of Electronic Science and Technology of China, Chengdu 611731, China.
Sensors (Basel, Switzerland)
|November 27, 2024

概括
这项研究引入了一个新的传感器融合框架,IIVL-LM,用于在具有挑战性的条件下改进机器人的定位和导航. 该系统通过集成多个传感器,提高了准确性和可靠性,特别是在低光环境中.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 计算机视觉 计算机视觉
- 传感器融合式传感器
背景情况:
- 复合机器人在感知方面面临挑战,并因照明变化,干扰和传感器错误而造成估计.
- 现有的系统在动态和低光环境中难以获得准确性和可靠性.
研究的目的:
- 开发一个集成的本地化和导航框架,IIVL-LM,克服环境感知和估计困难.
- 为了提高机器人系统在复杂,可变条件下的强度和精度.
主要方法:
- 提出了一种非线性优化方法,用于密切合的IMU,红外,RGB摄像头和LiDAR数据的数据级融合.
- 开发了一个实时发光率计算模型和特征融合的快速近似方法.
- 在R3LIVE++框架内使用红外摄像头深度信息优化了视觉惯性计数 (VIO) 模块.
主要成果:
- 在具有挑战性的亮度条件下,IIVL-LM系统显示出显著的性能改进,特别是在低光环境中.
- 在模拟的室内救援场景中,在RMSE ATE中平均改善了23%至39% (0.006至0.013).
- 通过对TUM-VI数据集进行比较实验,验证了红外图像融合的关键重要性.
结论:
- 通过保持至少三个传感器的积极参与,IIVL-LM框架显著提高了机器人的稳定性和精度,在未知的和广的环境中.
- 这种综合方法对于在复杂场景中要求高可靠性的应用至关重要,例如室内救援行动.


相关概念视频
 01:24
One-Degree-of-Freedom System
465
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
465
 01:30
Three-Dimensional Force System:Problem Solving
628
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
628
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
389
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
389
 01:27
Non-inertial Frames of Reference
5.8K
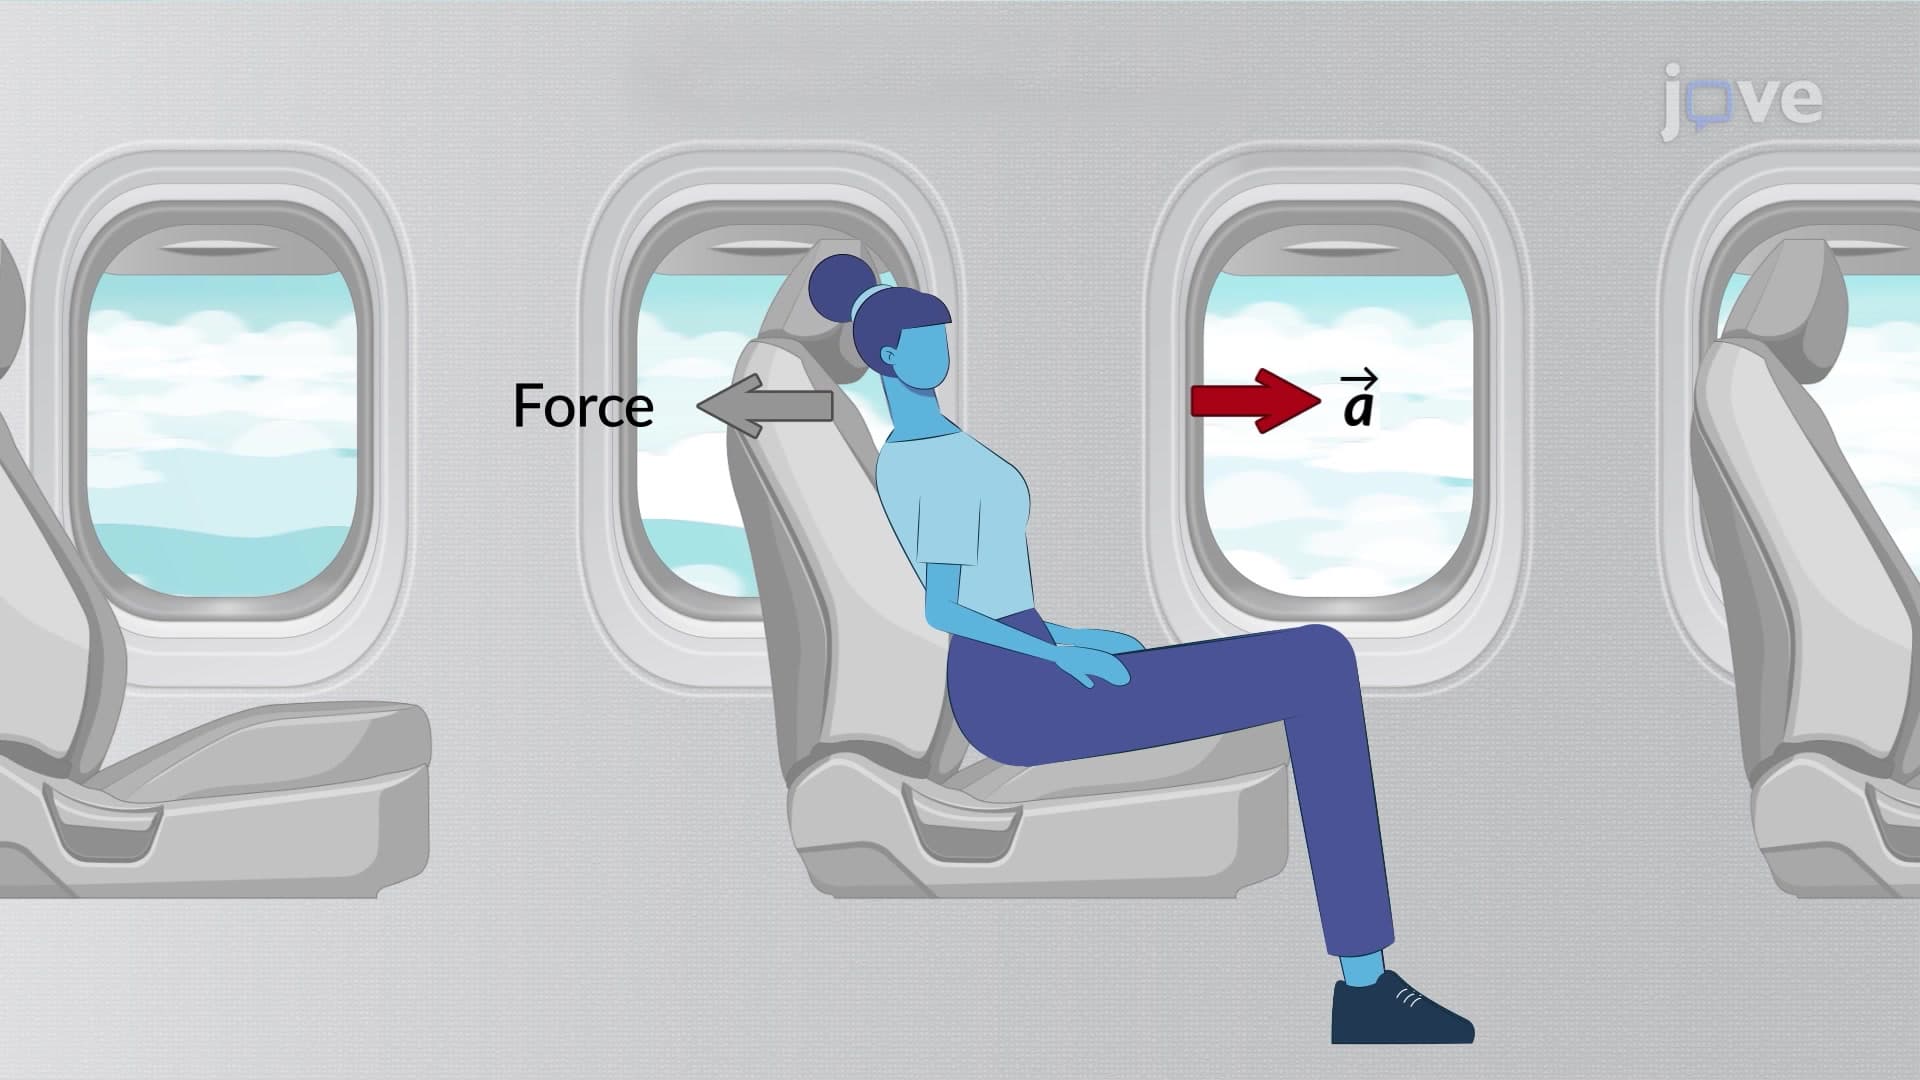
A reference frame accelerating or decelerating relative to an inertial frame is a non-inertial frame. To help understand this, consider what taking off in an airplane, turning a corner in a car, riding a merry-go-round, and the circular motion of a tropical cyclone all have in common. All these systems are accelerating, decelerating, or rotating relative to the Earth; hence, they all are non-inertial frames. All these systems exhibit inertial forces, which merely seem to arise from motion,...
5.8K
 01:25
Relative Motion Analysis using Rotating Axes
448
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
448
 01:30
Three-Dimensional Force System
2.0K
In mechanical engineering, a three-dimensional force system is a system of forces acting in three dimensions, with forces applied along the x, y, and z coordinate axes. The three-dimensional force system is an important concept in mechanical engineering, as it allows engineers to understand and analyze the behavior of objects and structures in three dimensions. By understanding the forces acting on a system, engineers can design more efficient and effective mechanical systems that can withstand...
2.0K