

概括
我们开发了一种超薄的拓绝缘体超表面,用于高效地产生轨道角动量 (OAM) 束. 这种新的方法提供了显著的OAM转换效率,克服了传统等离子体材料的局限性.
科学领域:
- 光子学和等离子学.
- 材料科学 材料科学 材料科学
- 拓绝缘体 拓绝缘体 是一种绝缘体.
背景情况:
- 束中的轨道角动量 (OAM) 对于光通信和光操纵至关重要.
- 传统的OAM生成等离子金属表面由于金属特性而遭受高光学损失和有限的可调性.
研究的目的:
- 设计和制造一个超薄的拓绝缘体 (TI) 等离子金属表面,以实现高效的OAM生成.
- 探索3D信息技术在克服OAM应用中常规等离子材料的局限性的潜力.
主要方法:
- 制造超薄的Sb2Te3TI元表面,使用磁铁喷射沉积和聚焦离子束光刻.
- 在可见光谱中的表面等离子体共振 (SPR) 的表征.
- 使用自建测试系统进行OAM生成的实验演示.
主要成果:
- 18纳米厚的TI超表面在可见光谱中有效地产生了SPR.
- TI超表面有效地调节了OAM生成事件光的空间相.
- 基于TI的超表面的OAM转换效率明显高于基于黄金的超表面.
- 成功生成了一个具有第一阶拓电荷的明显束.
结论:
- 超薄的TI等离子金属表面为生成OAM提供了一种新的,高效的方法.
- 这项工作突出了拓绝缘体在先进的光场操纵和超薄光学设备中的潜力.
更多相关视频
 09:06
Visualizing Uniaxial-strain Manipulation of Antiferromagnetic Domains in Fe1+YTe Using a Spin-polarized Scanning Tunneling Microscope
Published on: March 24, 2019
8.0K
 08:48
Demonstration of Spin-Multiplexed and Direction-Multiplexed All-Dielectric Visible Metaholograms
Published on: September 25, 2020
5.7K
相关概念视频
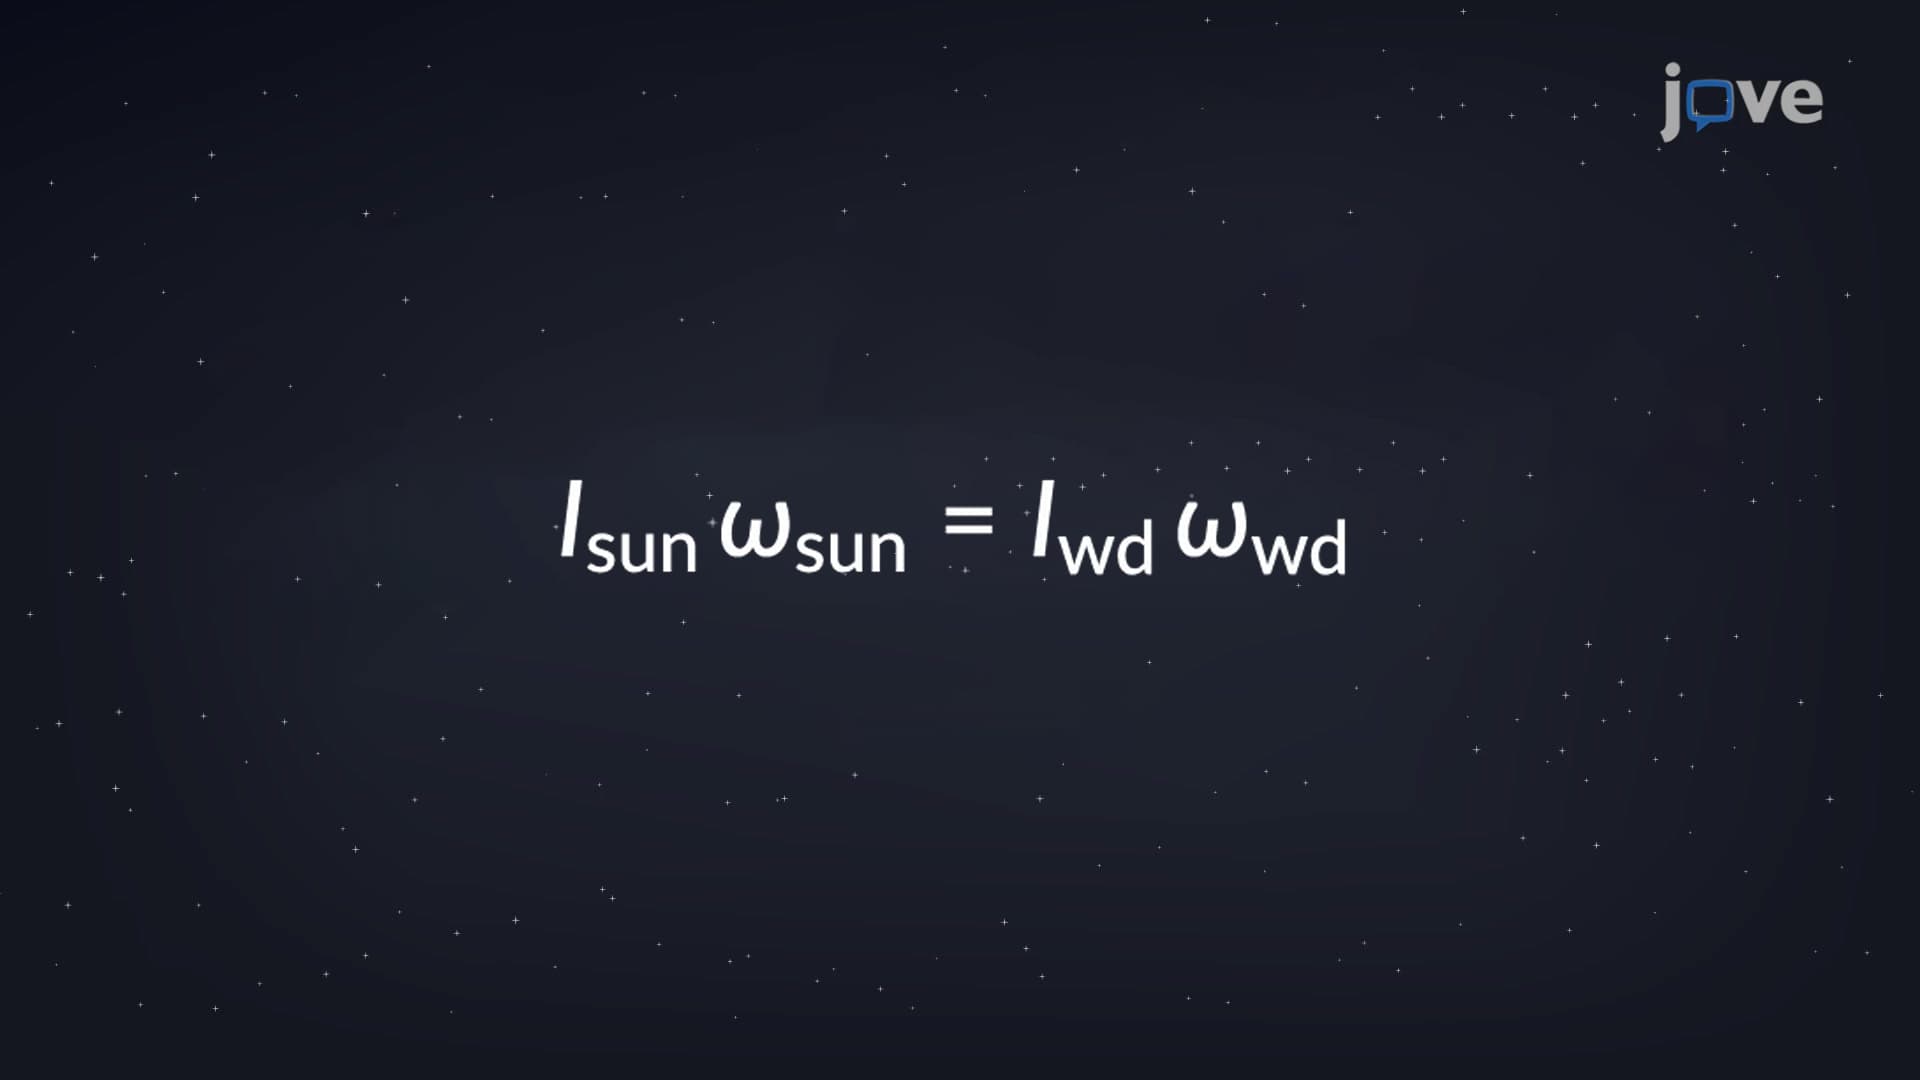 01:18
Conservation of Angular Momentum: Application
10.8K
A system's total angular momentum remains constant if the net external torque acting on the system is zero. Examples of such systems include a freely spinning bicycle tire that slows over time due to torque arising from friction, or the slowing of Earth's rotation over millions of years due to frictional forces exerted on tidal deformations. However in the absence of a net external torque, the angular momentum remains conserved. The conservation of angular momentum principle requires a...
10.8K
 01:10
Angular Momentum: Single Particle
6.1K
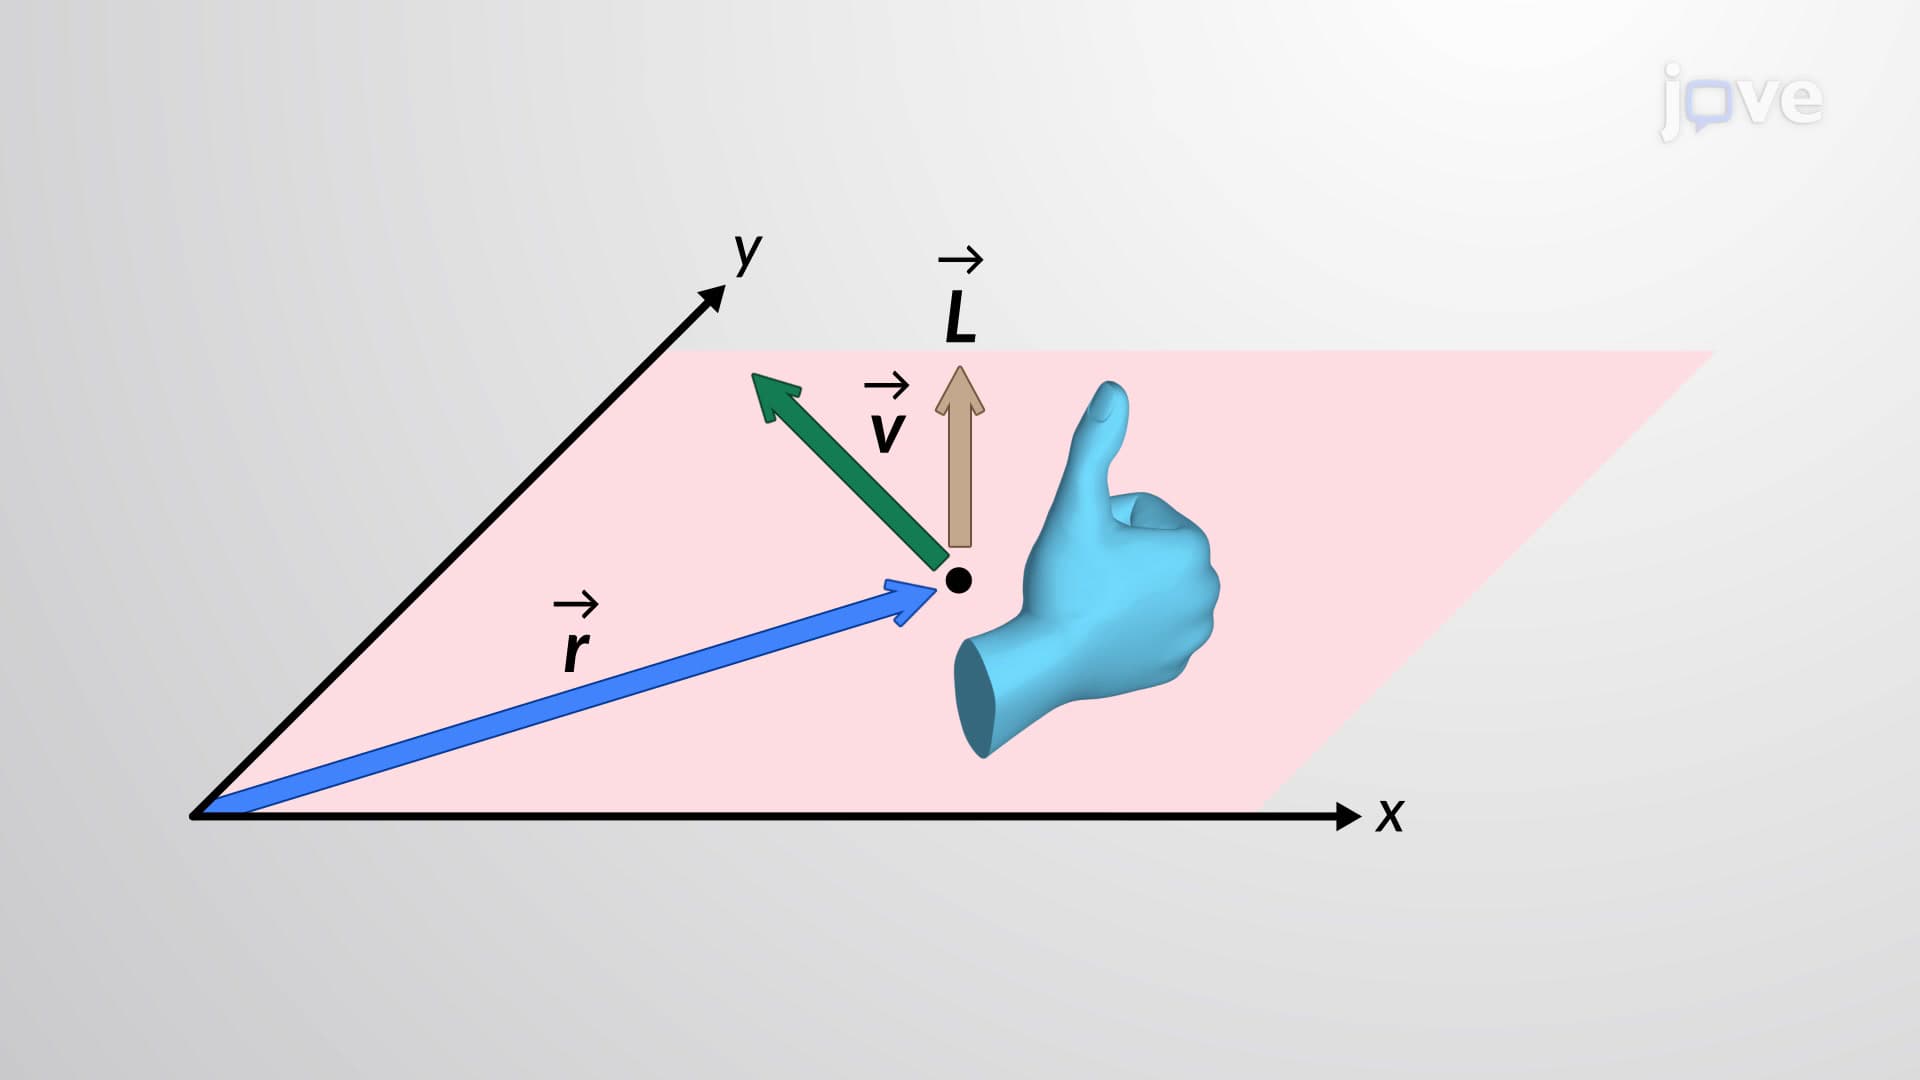
Angular momentum is directed perpendicular to the plane of the rotation, and its magnitude depends on the choice of the origin. The perpendicular vector joining the linear momentum vector of an object to the origin is called the “lever arm.” If the lever arm and linear momentum are collinear, then the magnitude of the angular momentum is zero. Therefore, in this case, the object rotates about the origin such that it lies on the rim of the circumference defined by the lever arm...
6.1K
 01:11
Angular Momentum about an Arbitrary Axis
193
Imagine a rigid body with a mass denoted as 'm', which has its center of mass at point G and is rotating around an inertial reference frame. The angular momentum at an arbitrary point P can be calculated by taking the cross product of the position vector and linear momentum vector for each individual mass element.
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into...
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into...
193
 01:09
Conservation of Angular Momentum
10.2K
A system's total angular momentum remains constant if the net external torque acting on the system is zero. Considering a system that consists of n tiny particles, the angular momentum of any tiny particle may change, but the system's total angular momentum would remain constant. The principle of conservation of angular momentum only considers the net external torque acting on the system. While there are internal forces exerted by different particles within the system that also produce...
10.2K
 01:11
Rotation of Asymmetric Top
854
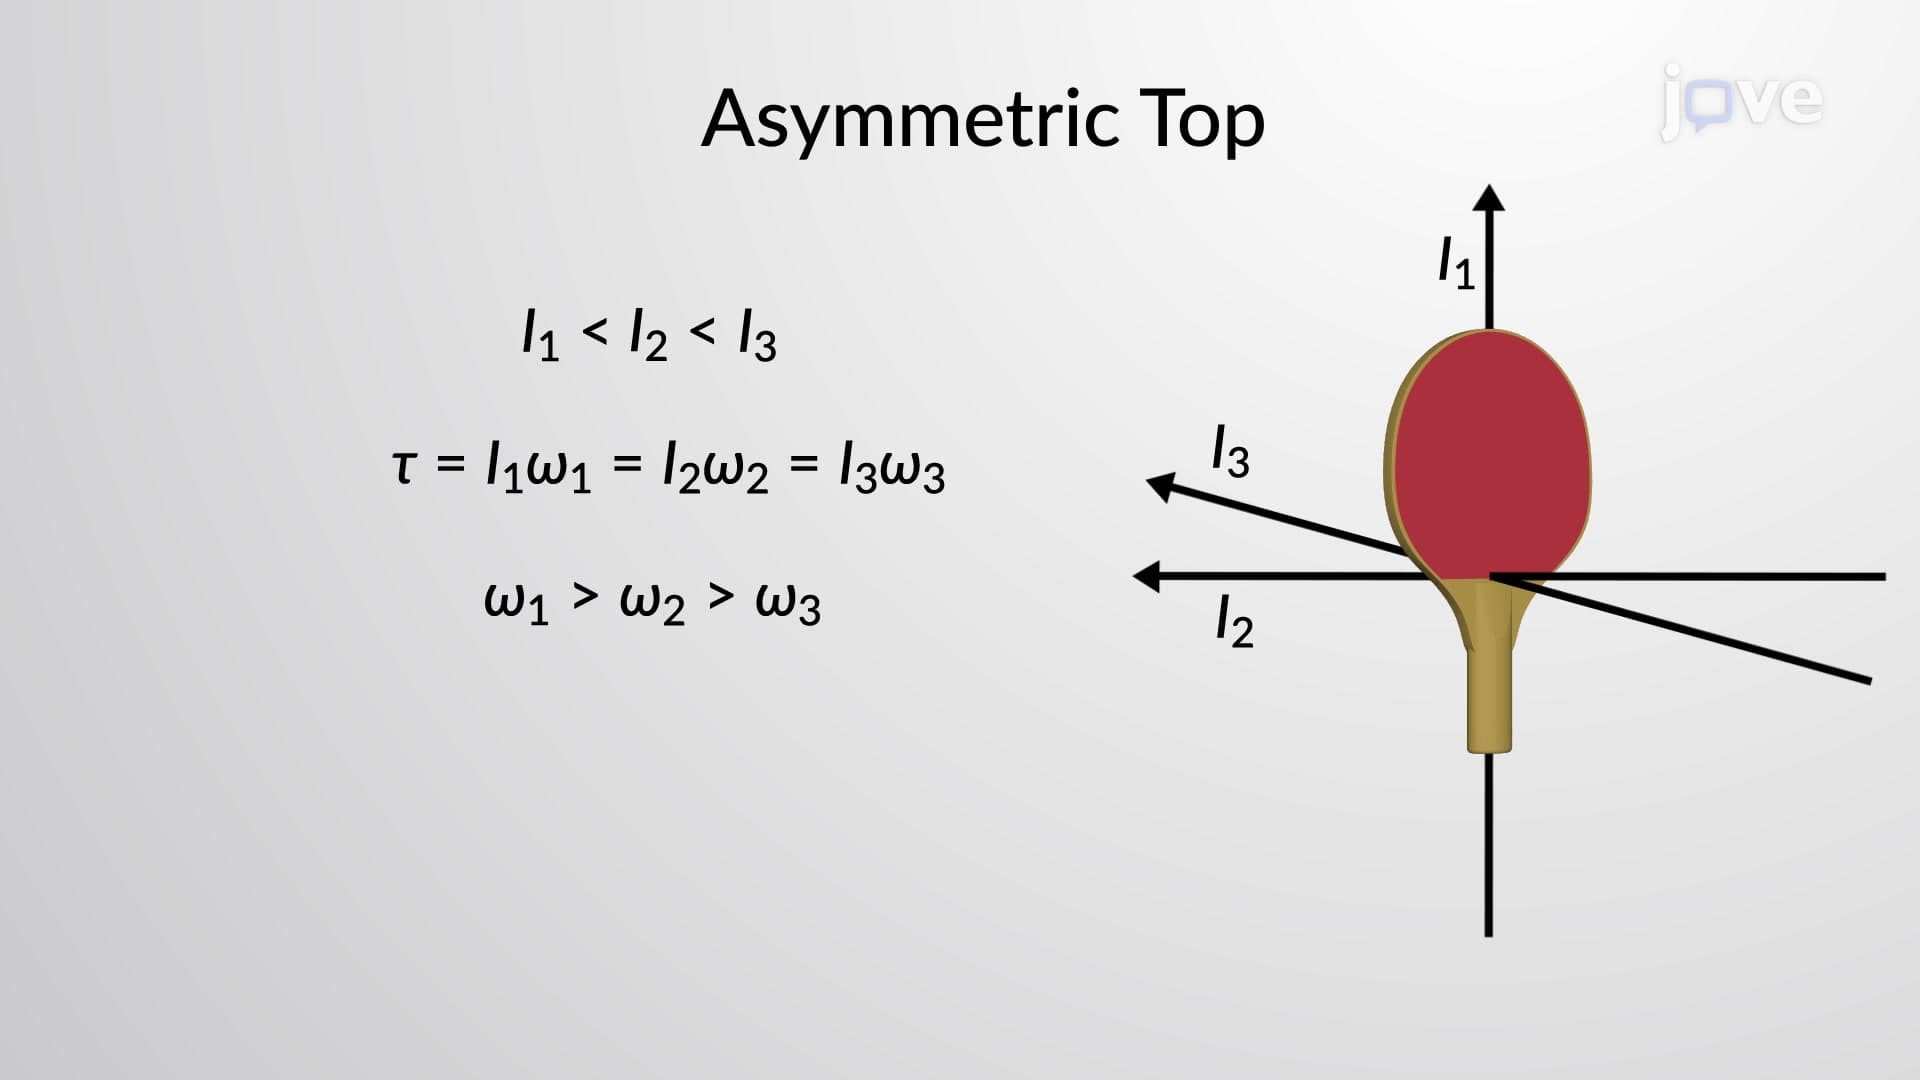
By definition, a spherically symmetric body has the same moment of inertia about any axis passing through its center of mass. This situation changes if there is no spherical symmetry. Since most rigid bodies are not spherically symmetric, these require special treatment.
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
854
 01:09
Angular Momentum and Principle Axes of Inertia
198
The concept of angular momentum for a solid structure is illustrated as the cumulative result of the cross-product of the position vector of the mass element and the cross-product of the body's angular velocity with the position vector.
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
198