
在执行器/传感器故障的情况下,用于多代理系统的事件触发式容错跟踪控制
Zhengyu Ye1, Ziquan Yu1, Bin Jiang1
1College of Automation Engineering, Nanjing University of Aeronautics and Astronautics, Nanjing 210016, China.
ISA transactions
|November 28, 2024

概括
本研究引入了一个事件触发的容错跟踪控制 (FTTC) 协议,以确保多代理系统 (MAS) 的可靠估计和稳定性,尽管有传感器故障. 该方法提高了系统性能,并降低了通信负载.
科学领域:
- 控制系统工程 控制系统工程
- 机器人技术 机器人技术 机器人技术
- 故障诊断和故障容忍能力
背景情况:
- 多代理系统 (MAS) 中的传感器故障会损害测量可靠性和系统稳定性.
- 在通信限制下,现有的方法可能无法充分解决同时进行状态估计和故障诊断.
研究的目的:
- 为MAS开发一个事件触发的故障耐受跟踪控制 (FTTC) 协议.
- 确保可靠的状态估计和系统稳定性在存在传感器和执行器故障的情况下.
主要方法:
- 利用描述器方法重新设计系统并消除传感器故障效应.
- 设计了一个滑动模式观察器,用于同时进行状态估计和故障诊断 (FD).
- 开发了一个事件触发的分布式估计器,以最大限度地减少通信开销和估计领导者状态.
主要成果:
- 拟议的FTTC协议在执行器和传感器故障的情况下确保了系统稳定性.
- 事件触发机制有效地减少了通信负载,同时保持了估计准确性.
- 同时实现了状态估计和故障诊断.
结论:
- 开发的FTTC协议为面临传感器故障的MAS提供了强大的解决方案.
- 事件触发策略提高了分布式控制系统的效率和可靠性.
- 通过多个四旋翼模拟进行验证,证明了实际适用性.

相关概念视频
 01:18
Fault Types
75
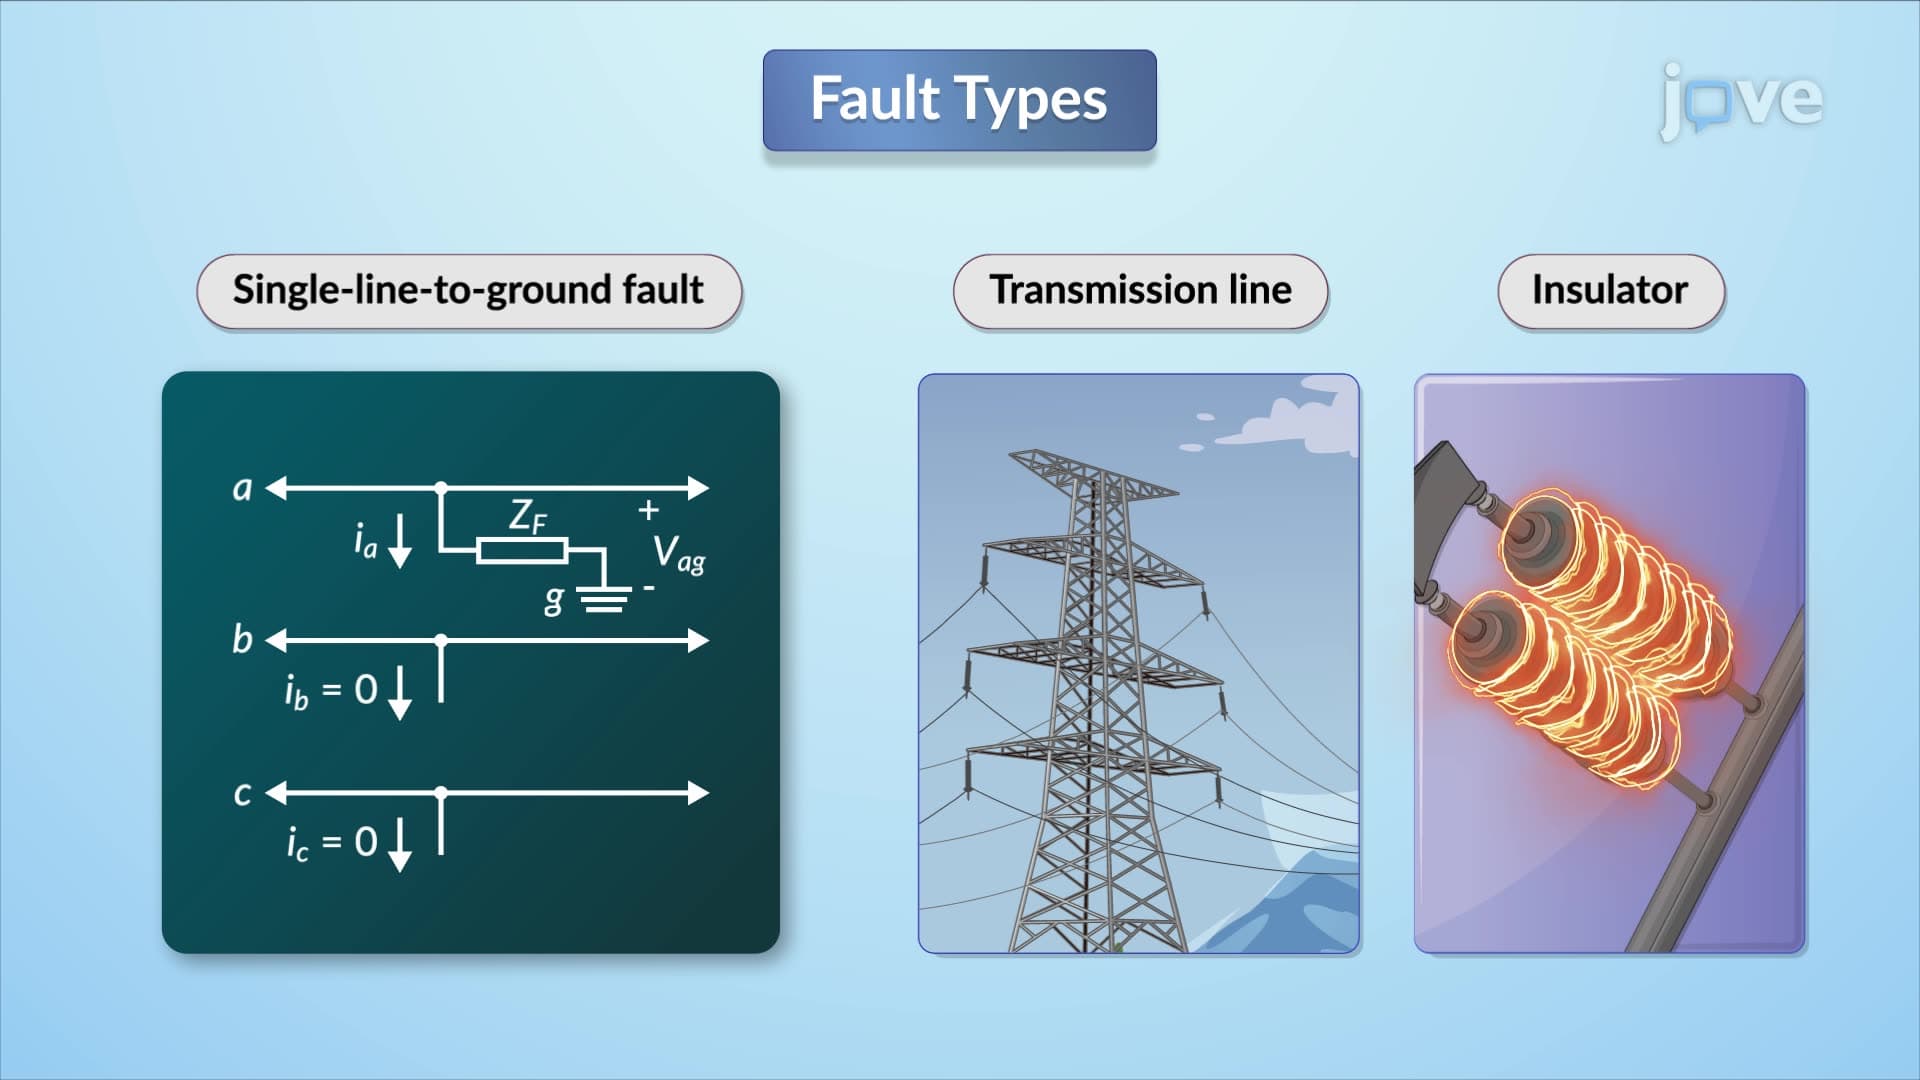
When analyzing a single line-to-ground fault from phase A to ground at a three-phase bus, it is important to consider the fault impedance. This impedance is zero for a bolted fault, equal to the arc impedance for an arcing fault, and represents the total fault impedance for a transmission-line insulator flashover. To derive sequence and phase currents, fault conditions are translated from the phase domain to the sequence domain.
For line-to-line faults occurring between phases B and C, the...
For line-to-line faults occurring between phases B and C, the...
75
 01:10
Control Systems
1.1K
Control systems are everywhere in contemporary society, influencing diverse applications from aerospace to automated manufacturing. These systems can be found naturally within biological processes, such as blood sugar regulation and heart rate adjustment in response to stress, as well as in man-made systems like elevators and automated vehicles. A control system is essentially a network of subsystems and processes that collaboratively convert specific inputs into desired outputs.
At the heart...
At the heart...
1.1K
 01:21
Control System Problem
107
In an open-loop system, such as a basic thermostat, the poles of the transfer function influence the system's response but do not determine its stability. However, when feedback is introduced to form a closed-loop system, such as an advanced thermostat that adjusts heating based on room temperature, stability is governed by the new poles of the closed-loop transfer function.
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
107
 01:21
Distributed Loads: Problem Solving
624
Beams are structural elements commonly employed in engineering applications requiring different load-carrying capacities. The first step in analyzing a beam under a distributed load is to simplify the problem by dividing the load into smaller regions, which allows one to consider each region separately and calculate the magnitude of the equivalent resultant load acting on each portion of the beam. The magnitude of the equivalent resultant load for each region can be determined by calculating...
624
 01:26
Feedback control systems
286
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
286
 01:24
One-Degree-of-Freedom System
465
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
465