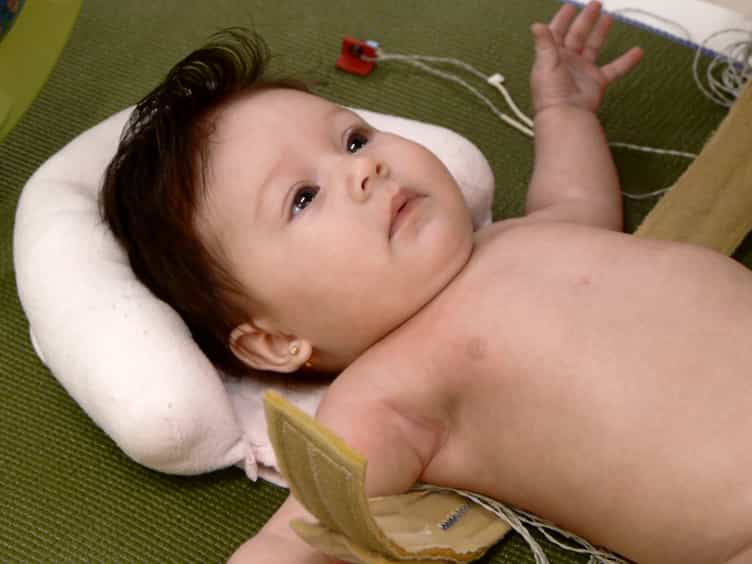

站着,还没有停下来?! 探索学习环境中的运动能力,作为提高年轻人运动技能的杆
Ruth Stevens1,2, Kristine De Martelaer3, Lindsay Everaert2
1Faculty of Architecture and arts, research group ArcK, Hasselt University, Belgium.
Studies in health technology and informatics
|December 2, 2024

概括
孩子们创造性地使用学校空间进行运动,但主要从事运动动作. 需要进一步关注平衡和对象控制,以加强他们的运动技能发展.
科学领域:
- 环境心理学 环境心理学
- 儿科运动发展 儿科运动发展
- 建筑设计为福祉的设计.
背景情况:
- 设计教育环境面临的挑战是由于建筑的缓慢演变与快速的社会变化.
- 年轻人越来越久坐的生活方式需要了解环境在促进身体活动和福祉方面的作用.
- 随着COVID-19的流行,人们对儿童的身体健康以及对积极学习空间的需求的担忧加剧了.
研究的目的:
- 调查儿童如何感知和利用学习空间内的身体活动的环境负担能力.
- 探索重新想象学校环境和培养身体活跃的生活方式以改善运动技能之间的关系.
- 解决了解儿童在各种空间环境中对运动能力的解释方面的差距.
主要方法:
- 一项涉及14名学生 (8-14岁) 在大学校园的实验,涉及三个不同的场景和空间 (食堂,礼堂, agora).
- 参与者根据每个环境的空间特征进行了运动活动,从结构元素到室内细节.
- 使用总运动发育测试-3进行运动分析,评估独特性,运动活动类型和能力概念,并使用视频记录.
主要成果:
- 初步发现表明,儿童表现出创造性的运动行为,利用各种空间元素.
- 观察到的主要活动是运动动作,对稳定/平衡和对象控制的参与有限.
- 儿童主要依赖于环境结构进行基本运动,而不是复杂的技能发展.
结论:
- 儿童擅长在周围环境中找到和利用运动机会,展示适应能力.
- 该研究强调需要设计环境,特别鼓励稳定/平衡和对象控制行动.
- 专注于这些较少使用的运动技能对于支持这个年龄组从基本运动技能过渡到特定运动技能至关重要.

相关概念视频
 01:18
Hierarchy of Motor Control
2.5K
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
2.5K
 01:24
Relative Motion Analysis - Velocity
341
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
341
 01:10
Relative Motion Analysis - Acceleration
330
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
330
 01:26
Kinetic Friction
902
Consider a truck trying to pull a stationary car. As the truck exerts a force on the car, static friction is created at the point of contact between the two surfaces. This frictional force resists the car's movement and keeps it at rest. However, when the applied force by the truck surpasses the limiting static frictional force, an interesting phenomenon occurs. The frictional force at the interface reduces to a lower value, known as the kinetic frictional force. At this point, the car...
902
 01:24
Absolute Motion Analysis- General Plane Motion
214
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
214
 01:15
Kinematic Equations: Problem Solving
11.9K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
11.9K