

开发一种基于旋翼无人驾驶飞行器的大气边界层探测系统
Guang You1, Jie Yang2, Xiaotian Wang2
1Tianchang Research Institute, Nanjing University of Information Science and Technology, 210044 Tianchang, China.
The Review of scientific instruments
|December 3, 2024

概括
一个新的大气边界层探测系统使用旋翼无人机 (UAV) 来进行增强的气象测量. 该系统结合了计算流体动力学 (CFD) 和神经网络,用于准确的温度传感,平均误差为0.05°C.
科学领域:
- 气象学和大气科学 大气科学
- 航空航天工程是航空航天工程.
- 数据科学和人工智能数据科学和人工智能
背景情况:
- 传统的气象检测方法在捕捉大气边界层动态方面存在局限性.
- 无人驾驶飞行器 (UAV) 为移动大气传感提供了一个有希望的平台.
- 在动态无人机环境中精确的温度测量需要先进的传感器设计和错误校正.
研究的目的:
- 开发和验证使用旋翼无人机的大气边界层探测系统.
- 通过计算流体动力学 (CFD) 建模,优化无人机上的传感器位置.
- 通过一种新的辐射屏蔽和CFD神经网络错误纠正模型来提高温度测量的准确性.
主要方法:
- 利用计算流体动力学 (CFD) 模拟空气流并确定最佳传感器位置.
- 设计了一种用于温度传感器的新型辐射屏蔽,平衡屏蔽和通风.
- 开发了一个使用CFD模拟错误和机器学习算法 (随机森林,多层感知器) 的错误校正模型.
主要成果:
- 错误校正模型表现出高精度,平均绝对误差,根平均平方误差和相关系数分别为0.055,0.066和0.971°C.
- 与参考测量相比,经过校正的温度数据显示的平均误差仅为0.05°C.
- 在无人机悬浮期间温度,湿度和气压的差异很小 (0.6°C,1.6%RH,0.77hPa).
结论:
- 拟议的无人机系统显著提高了大气边界层检测能力.
- 集成的CFD和神经网络方法有效地纠正温度测量错误.
- 该系统提供准确可靠的气象数据,与已建立的仪器进行验证.
更多相关视频
 07:49
Automated Deployment of an Internet Protocol Telephony Service on Unmanned Aerial Vehicles Using Network Functions Virtualization
Published on: November 26, 2019
8.0K
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
1.6K
相关概念视频
 01:18
Boundary Layer Characteristics
53
When a fluid encounters a solid surface, a boundary layer forms due to the interaction between the fluid's motion and the stationary surface. This phenomenon is characterized by a thin region adjacent to the surface where viscous forces dominate, influencing the fluid's velocity profile. The development of the boundary layer begins at the leading edge of the surface and evolves as the fluid moves downstream.As the fluid flows over the surface, friction between the fluid and the wall slows down...
53
 01:23
Lift
64
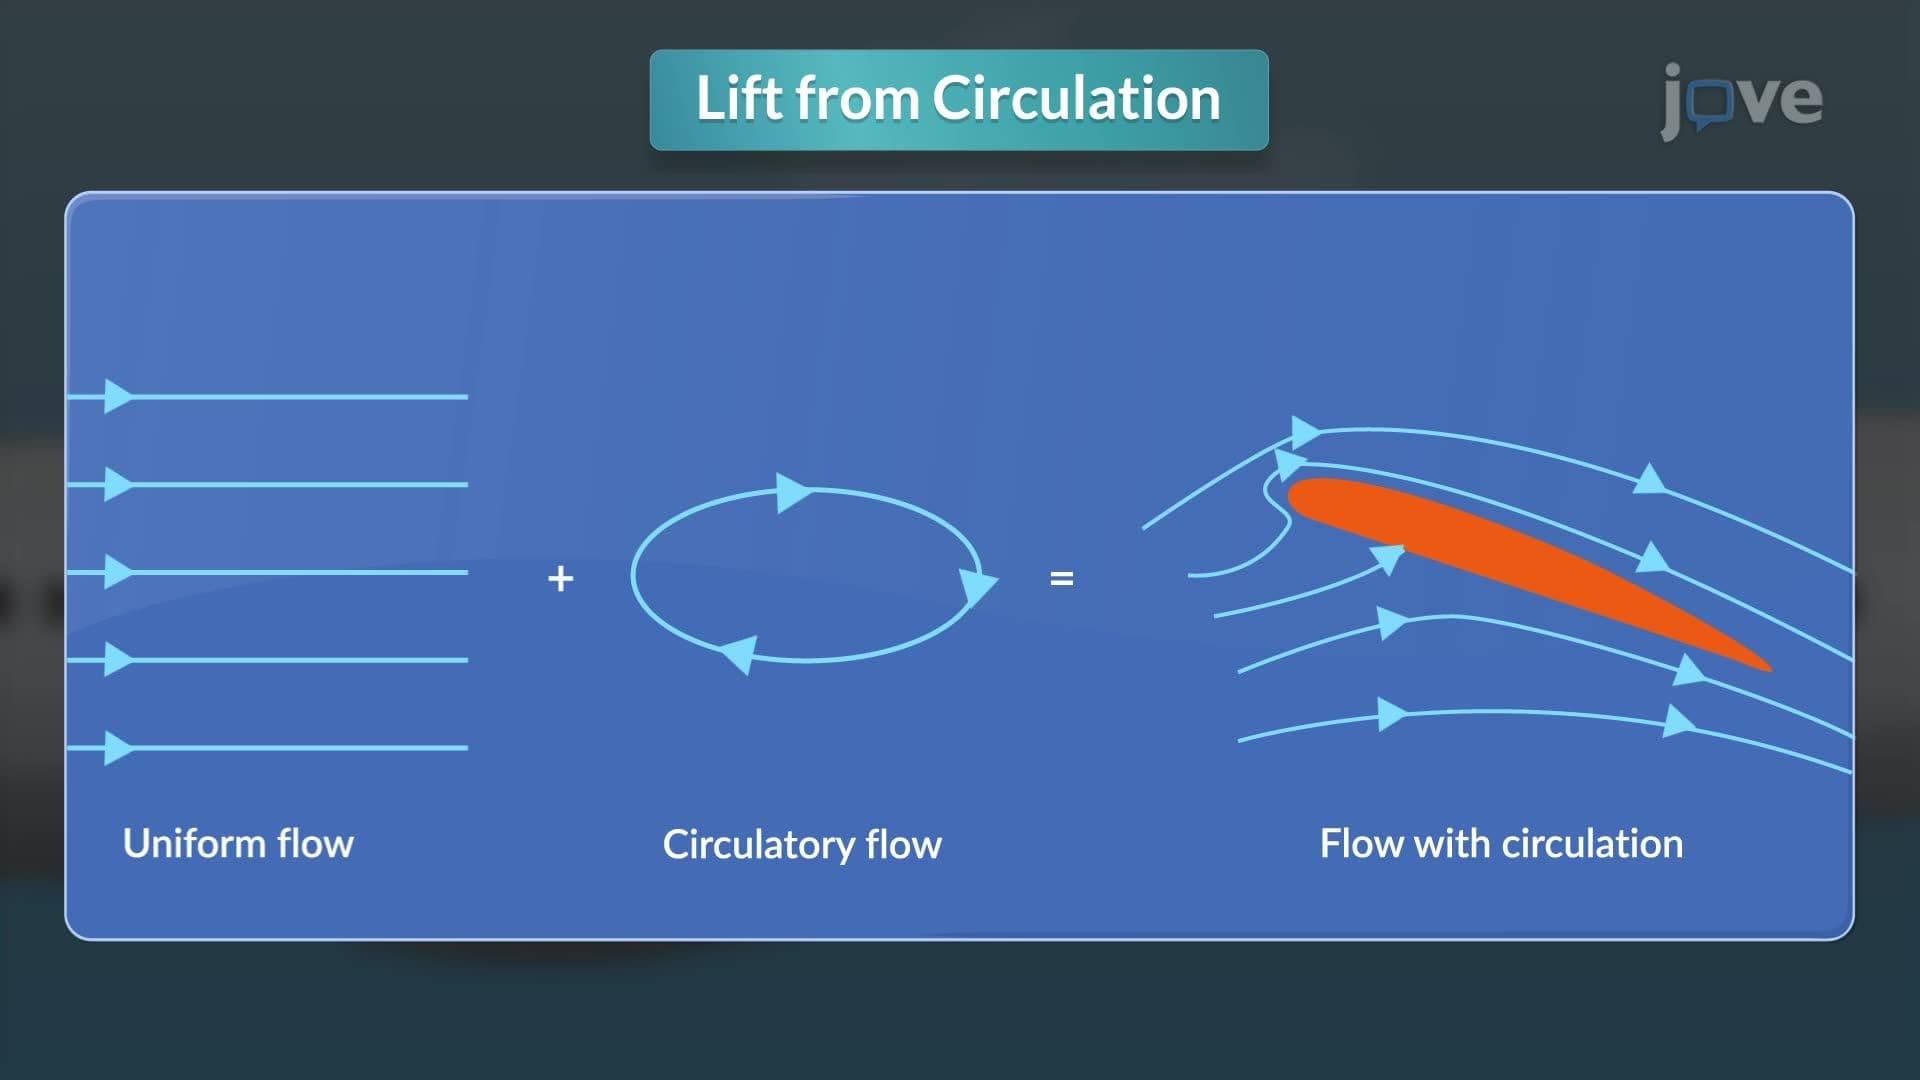
Lift is a fundamental aerodynamic force that acts perpendicular to the direction of airflow. It plays a central role in achieving and sustaining flight and in stabilizing various vehicles. Lift primarily originates from pressure differences created across surfaces, such as an airfoil. A lower pressure region forms above the wing, while a higher pressure region forms below it, generating an upward force. This differential results from the shape and orientation of the airfoil, enabling the wing...
64
 01:25
Relative Motion Analysis using Rotating Axes
448
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
448