相关实验视频
Updated: Jun 5, 2025
04:46

Rat Model of Adhesive Capsulitis of the Shoulder
Published on: September 28, 2018
7.3K
模拟研究的上肢同度式钥匙可行设置与 Glenohumeral联合约束的模拟研究
Nasser Rezzoug1, Antun Skuric2,3, Vincent Padois2
1Université de Poitiers, CNRS, ISAE-ENSMA, Institut PPRIME, Poitiers F-86000, France.
Journal of biomechanical engineering
|December 5, 2024

概括
这项研究通过结合膜关节稳定性约束来增强机器人上肢模型. 改进的模型可以防止关节脱,并优化肌肉协调,以实现更安全的人机交互.
科学领域:
- 生物力学 生物力学
- 机器人技术 机器人技术 机器人技术
- 人体工程学就是人体工程学.
背景情况:
- 肌肉骨模型对于了解上肢能力至关重要.
- 现有的模型往往忽略了关节稳定性的约束.
- 准确的匙可行设置 (WFS) 估计对于协作机器人和人工程学至关重要.
研究的目的:
- 改进上肢肌肉骨模型,通过整合膜关节的非脱和压缩限制.
- 加强代凸船体方法 (ICHM) 以实现更现实的关能力评估.
- 分析这些约束对手力能力,关节反应力和肌肉协调的影响.
主要方法:
- 升级代凸船体方法 (ICHM) 以包括膜关节稳定性约束.
- 进行in silico调查,将原始ICHM与增强模型进行比较.
- 分析匙可行集 (WFS),关节力和肌肉激活模式的变化.
主要成果:
- 最初的ICHM预测了许多匙可行集 (WFS) 元素的潜在膜位.
- 改进的模型成功地结合了稳定性约束,防止关节脱.
- 肌肉协调转移,有利于稳定肌肉,如旋转,减少对可能破坏稳定的肌肉的依赖.
结论:
- 整合腺关节稳定性约束可以显著提高上肢肌肉骨模型的准确性和安全性.
- 增强的ICHM提供了更现实的WFS,对于协作机器人和计算机辅助人体工程学的应用至关重要.
- 这些发现表明,优化肌肉招募策略,以实现更安全的人机协作.

相关概念视频
 01:30
Method of Joints: Problem Solving II
517
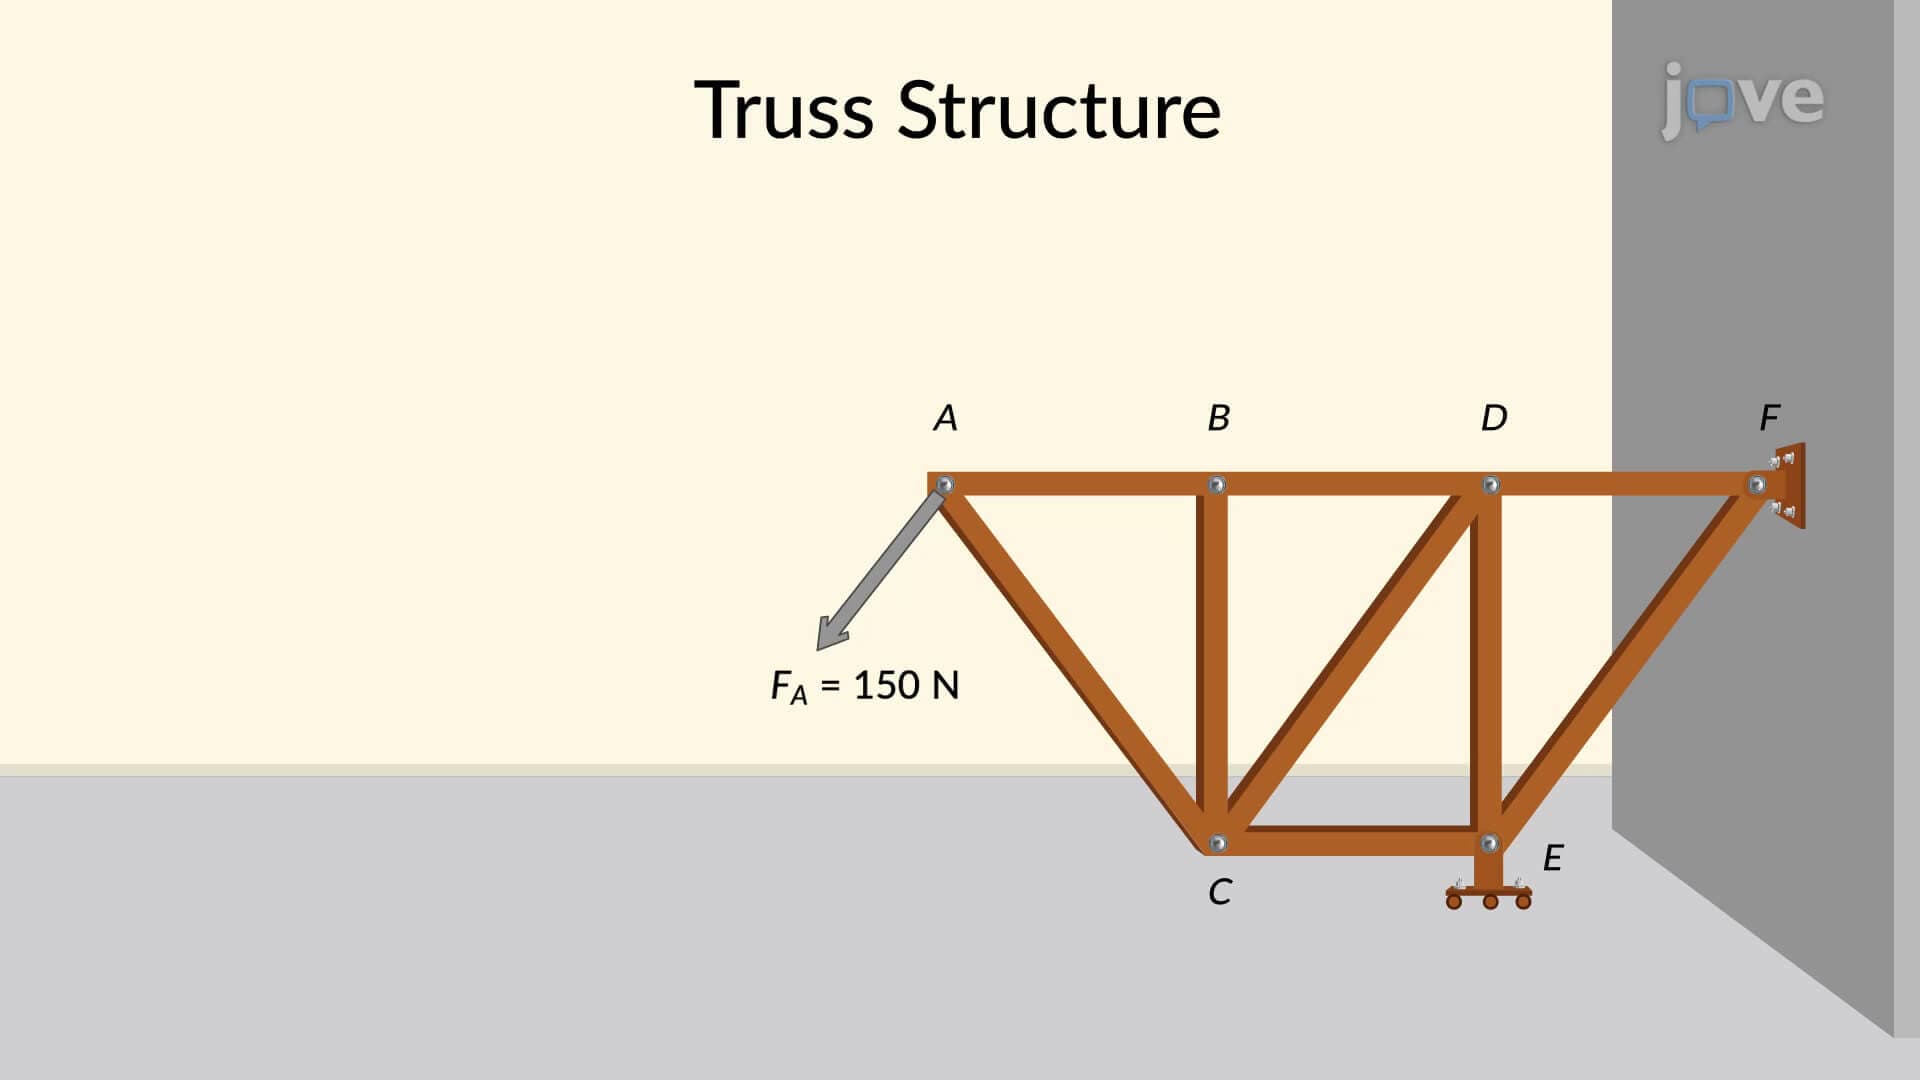
Consider a truss structure with frictionless joints fixed to a wall and roller support. If a force of 150 N is applied to joint A, the forces in each member of the truss can be determined using the method of joints.
517
 01:30
Method of Joints: Problem Solving I
1.1K
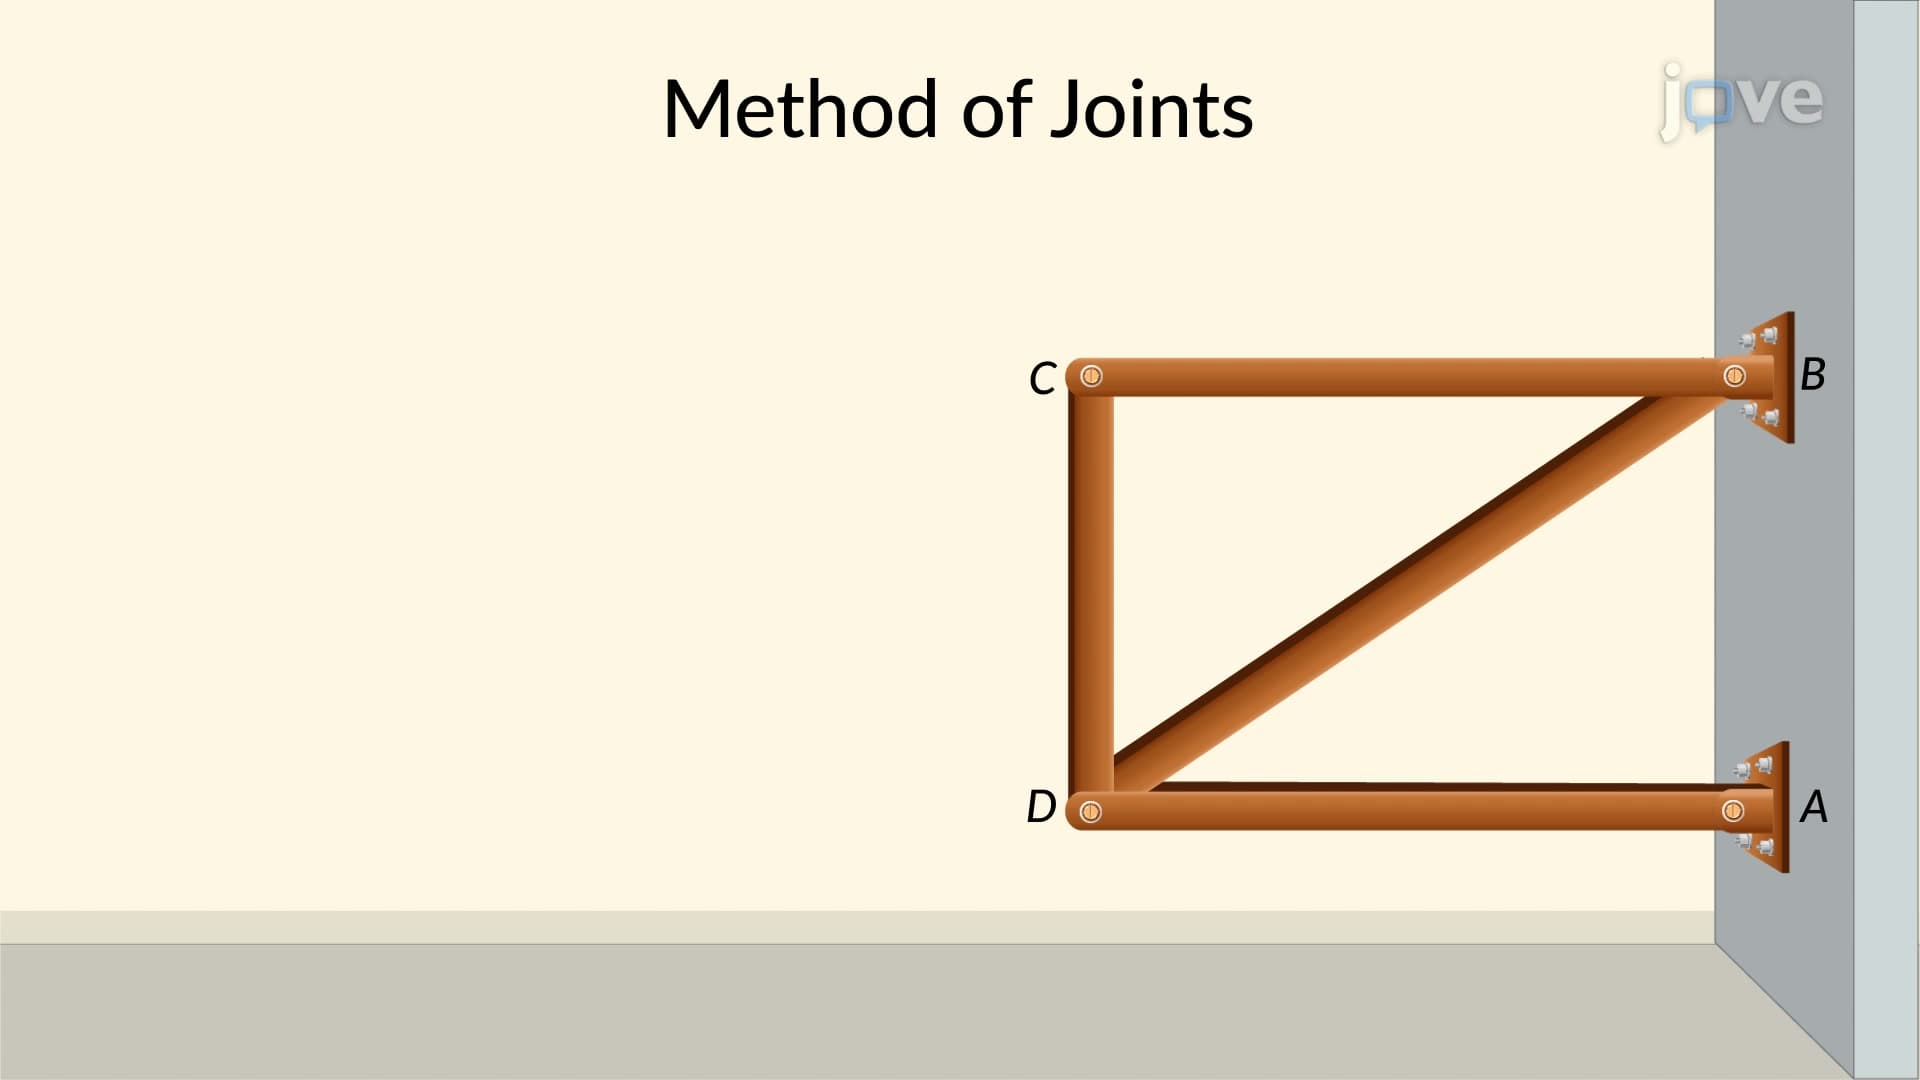
The method of joints is a commonly used technique to analyze the forces in structural trusses. The method is based on the principle of equilibrium, which assumes that the truss members are connected by frictionless pins. The forces at each joint can be determined by considering the equilibrium of the forces acting on that joint. Consider a truss structure with two forces of 20 N and 10 N acting at joints C and D, respectively. The method of joints can be used to determine the forces FCB, FDC,...
1.1K
 01:21
Rigid Body Equilibrium Problems - II
7.0K
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
7.0K
 00:49
Rigid Body Equilibrium Problems - I
4.3K
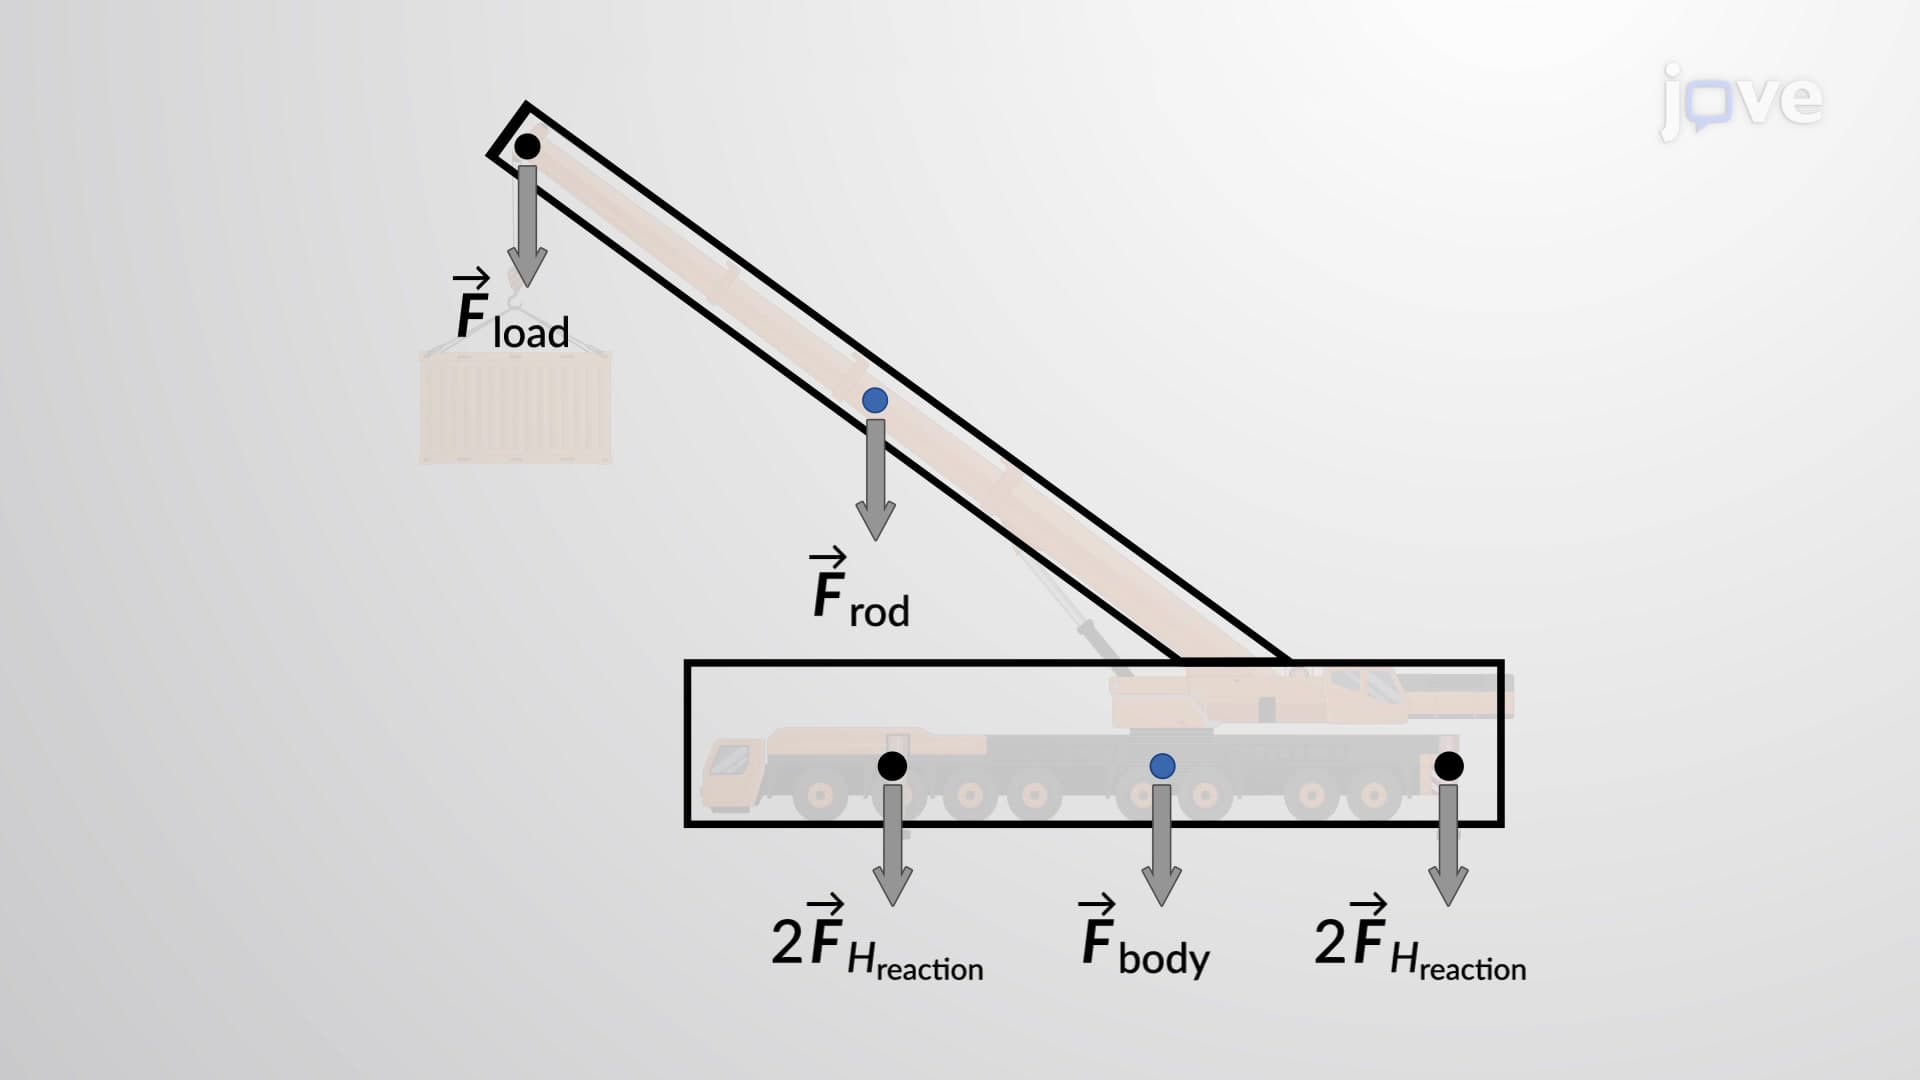
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
4.3K
 01:06
Virtual Work for a System of Connected Rigid Bodies
371
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
371
 01:12
General Case of Eccentric Axial Loading
172
Unsymmetrical bending occurs when the bending moment applied to a structural member does not align with its principal axis. This misalignment leads to complex stress distributions and deflection patterns that differ from symmetrical bending, which are essential for designing structures to withstand different loading conditions.
Consider a member subjected to equal and opposite forces that are applied along a line that does not coincide with the member's neutral axis. In unsymmetrical...
Consider a member subjected to equal and opposite forces that are applied along a line that does not coincide with the member's neutral axis. In unsymmetrical...
172