

使用IMU传感器编写Punjabi字符的惯性测量数据集
AnchalPreet Sharma1, Harsh Kumar1, Lakhjeet Kaur1
1Department of Computer Science, Akal University, Bathinda, Punjab 151302, India.
Data in brief
|December 6, 2024

概括
这项研究开发了一种使用惯性测量单位 (IMU) 收集数据以识别手写的旁遮普语和英语字母的新方法. 该系统捕捉了各种不同的写作风格,以提高模式识别准确度.
科学领域:
- 模式识别 模式识别
- 人与计算机的交互
- 计算语言学 计算语言学
背景情况:
- 手写识别系统经常与语言和区域脚本变化作斗争.
- 现有的数据集可能无法充分捕捉各种写作风格的动态细微差别.
- 惯性测量单位 (IMU) 提供了一种新的方法来捕获细粒度的运动数据.
研究的目的:
- 引入一种方法来创建一个全面的数据集,用于手写的旁遮普字母识别.
- 为了利用IMU捕捉动态的手写运动模式.
- 通过结合不同的写作风格来提高字符识别的准确性.
主要方法:
- 开发了使用惯性测量单位 (IMU) 的数据收集方法.
- 记录了多个参与者的手写动作,以捕捉不同的旁遮普语写作风格.
- 利用IMU数据来追踪详细的动态手写动作.
主要成果:
- 创建了一个数据集,有效地捕捉了手写的旁遮普文字的细微差别.
- 初步结果显示,在印度背景下识别手写英语字母的潜力很大.
- 该方法通过利用动态运动数据,证明了字符识别准确度的提高.
结论:
- 开发的方法和数据集为旁遮普语手写识别提供了坚实的基础.
- 这种方法显示了跨语言字母表识别的前景,包括印度语境内的英语.
- 这项研究有助于为各种语言环境开发更具适应性的模式识别系统.
相关概念视频
 01:03
Inertial Frames of Reference
7.0K
Newton’s first law is usually considered to be a statement about reference frames. It provides a method for identifying a special type of reference frame: the inertial reference frame. In principle, we can make the net force on a body zero. If its velocity relative to a given frame is constant, then that frame is said to be inertial. So, by definition, an inertial reference frame is a reference frame where Newton's first law holds valid. Newton's first law applies to objects with...
7.0K
 01:02
Gyroscope
2.9K
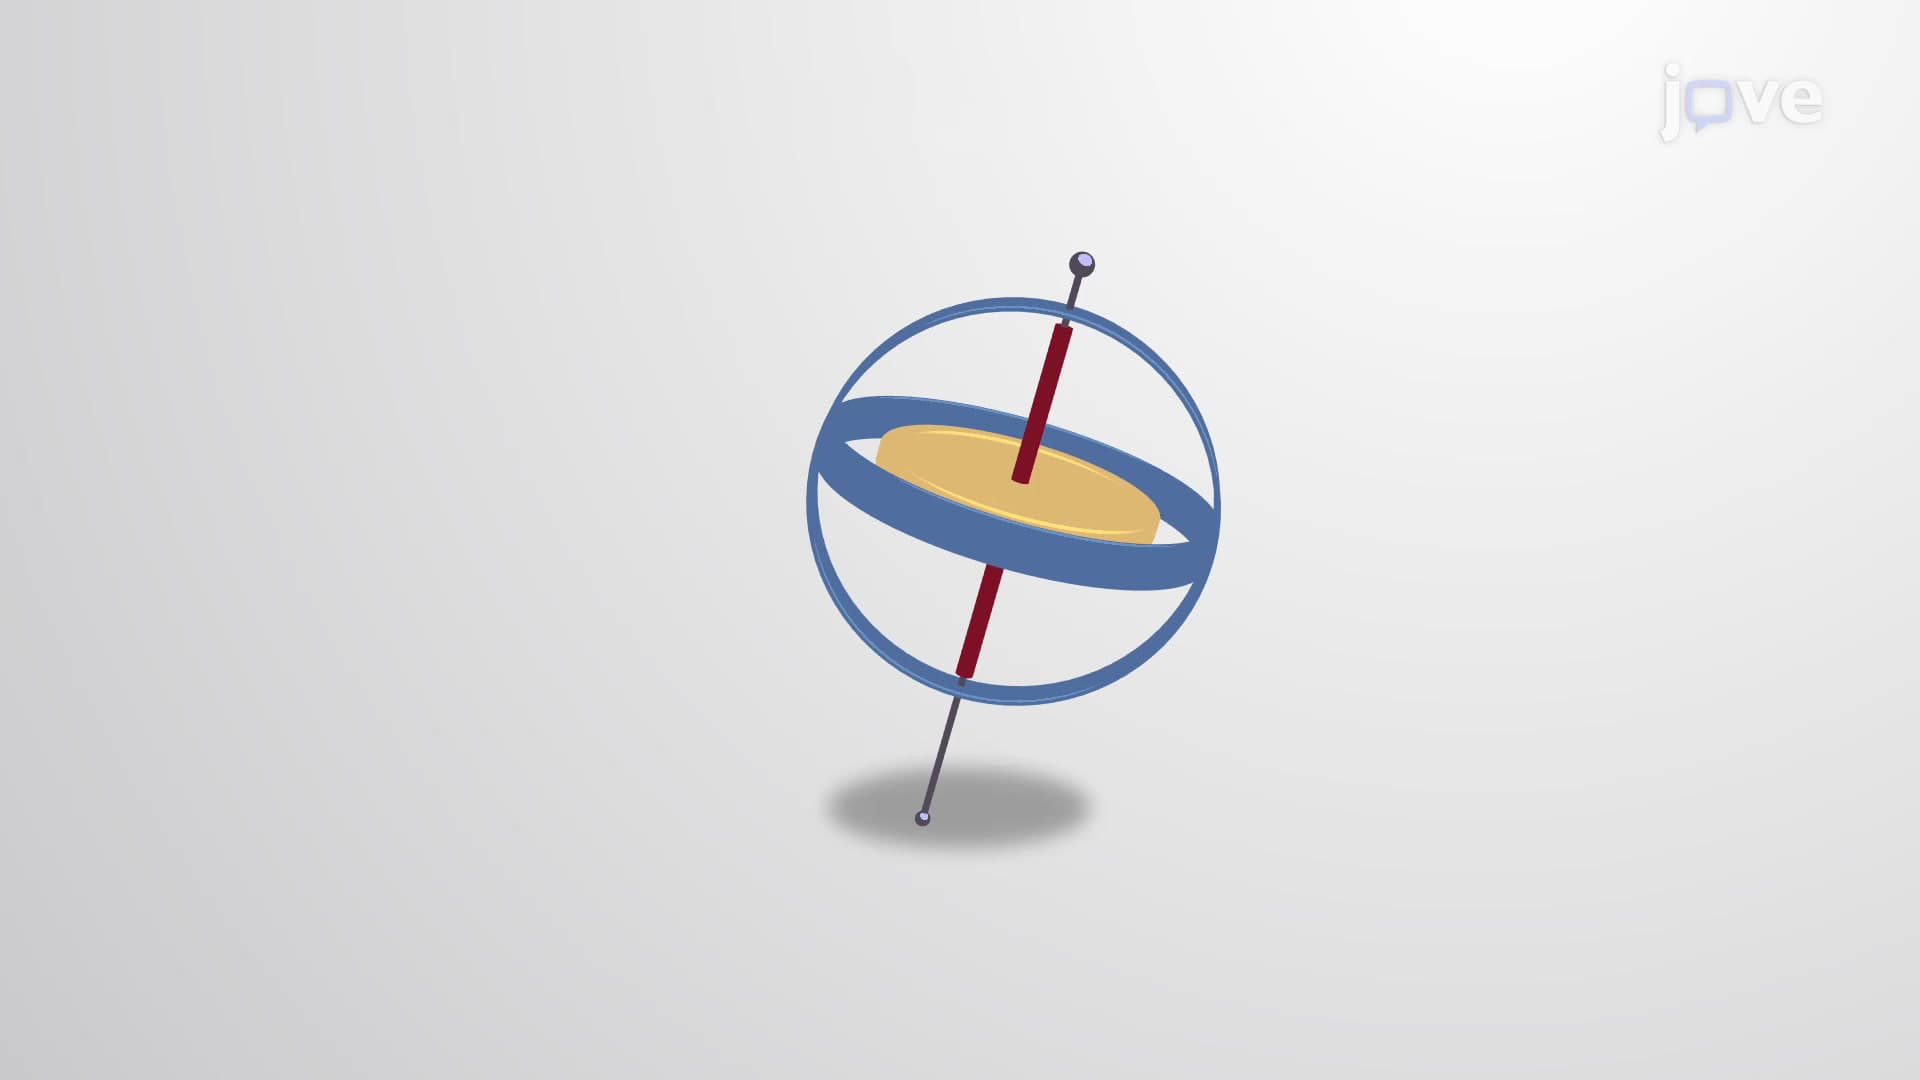
A gyroscope is defined as a spinning disk in which the axis of rotation is free to assume any orientation. When spinning, the orientation of the spin axis is unaffected by the orientation of the body that encloses it. The body or vehicle enclosing the gyroscope can be moved from place to place, while the orientation of the spin axis remains the same. This makes gyroscopes very useful in navigation, especially where magnetic compasses cannot be used, such as in crewed and crewless spacecraft,...
2.9K
 01:12
Measuring Acceleration Due to Gravity
532
Consider a coffee mug hanging on a hook in a pantry. If the mug gets knocked, it oscillates back and forth like a pendulum until the oscillations die out.
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
532
 01:24
Gyroscope: Precession
4.0K
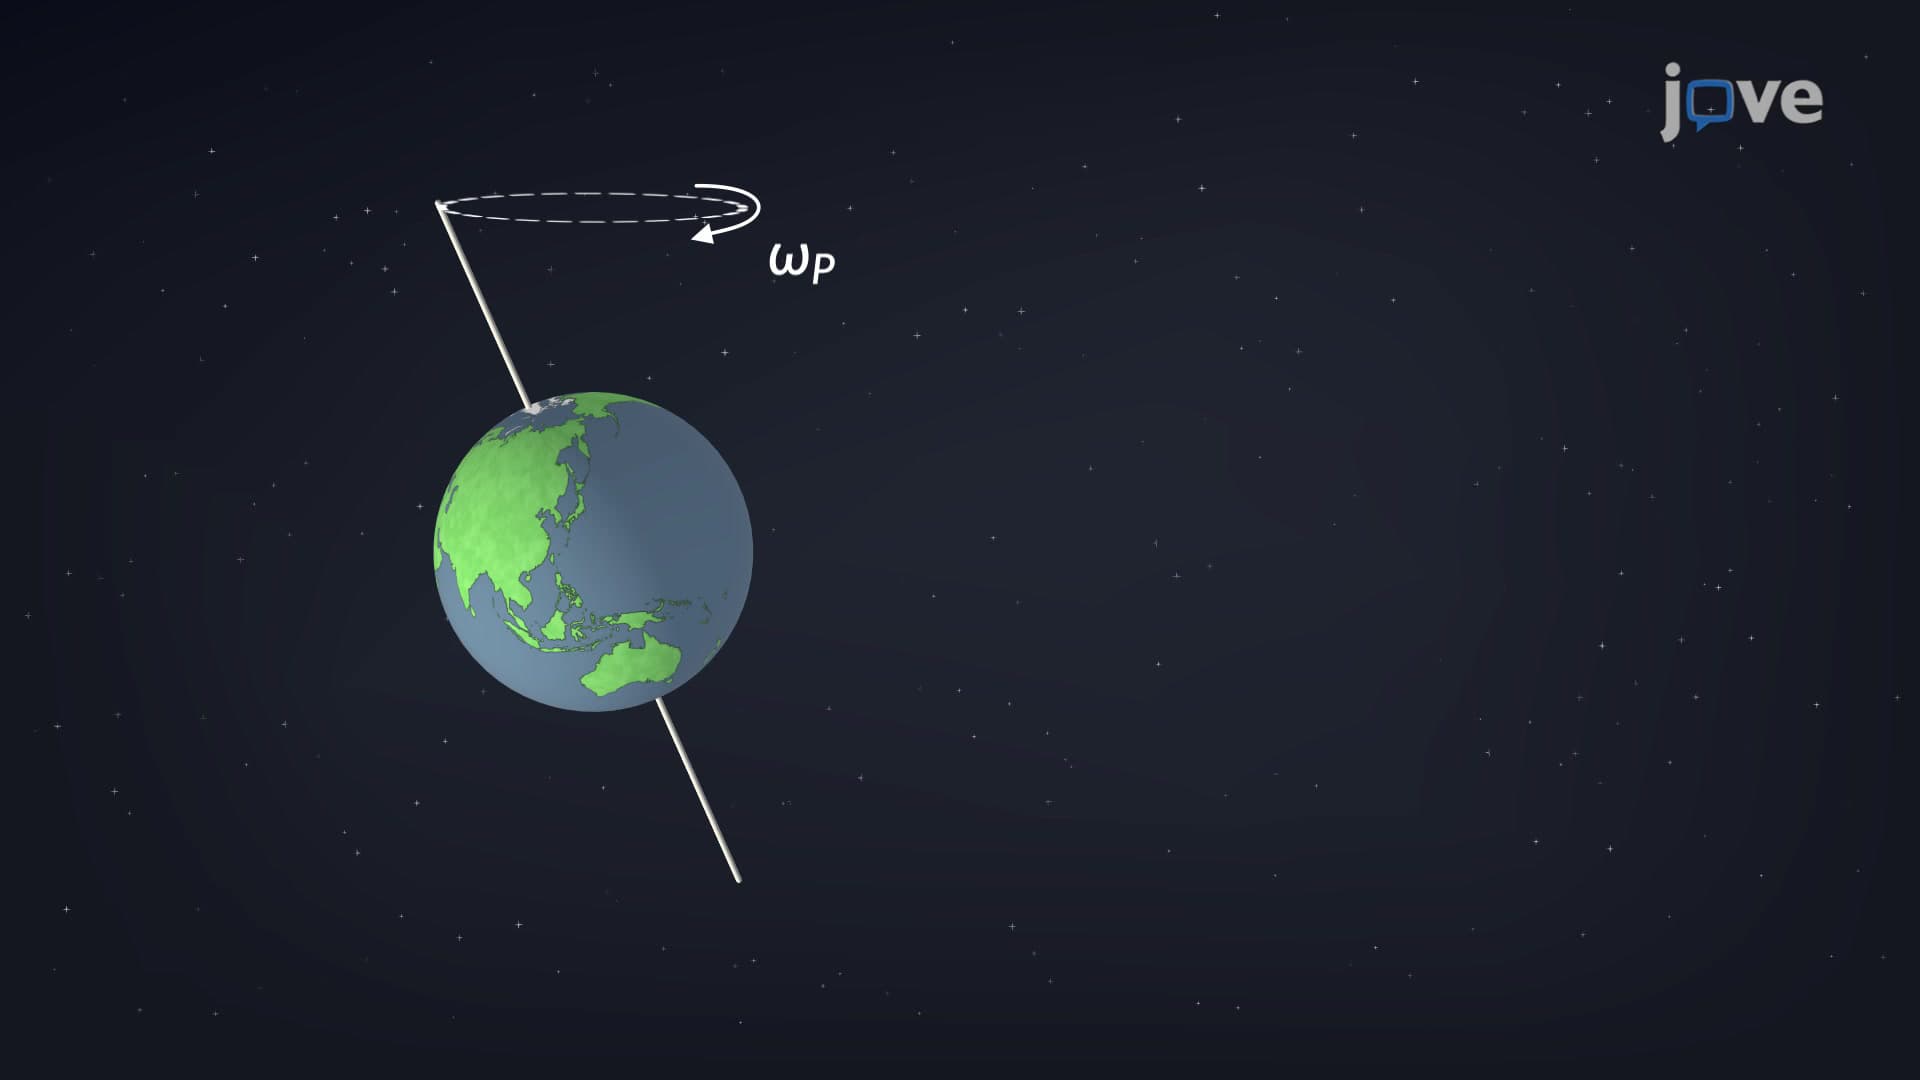
Precession can be demonstrated effectively through a spinning top. If a spinning top is placed on a flat surface near the surface of the Earth at a vertical angle and is not spinning, it will fall over due to the force of gravity producing a torque acting on its center of mass. However, if the top is spinning on its axis, it precesses about the vertical direction, rather than topple over due to this torque. Precessional motion is a combination of a steady circular motion of the axis and the...
4.0K
 01:18
Distance Measurements by Taping
27
Tapes are essential in surveying for accurate, durable, and short-distance measurements. Made from lightweight, nylon-coated steel, they offer flexibility and strength for rugged outdoor use. The nylon coating protects against rust and wear, extending the tape's life. Standard lengths, around 30 meters, are marked in meters and millimeters for precision.Surveyors select tapes based on site conditions and accuracy needs. Lightweight, nylon-coated tapes are commonly used for ease of handling and...
27
 01:22
Polar and Cylindrical Coordinates
14.4K
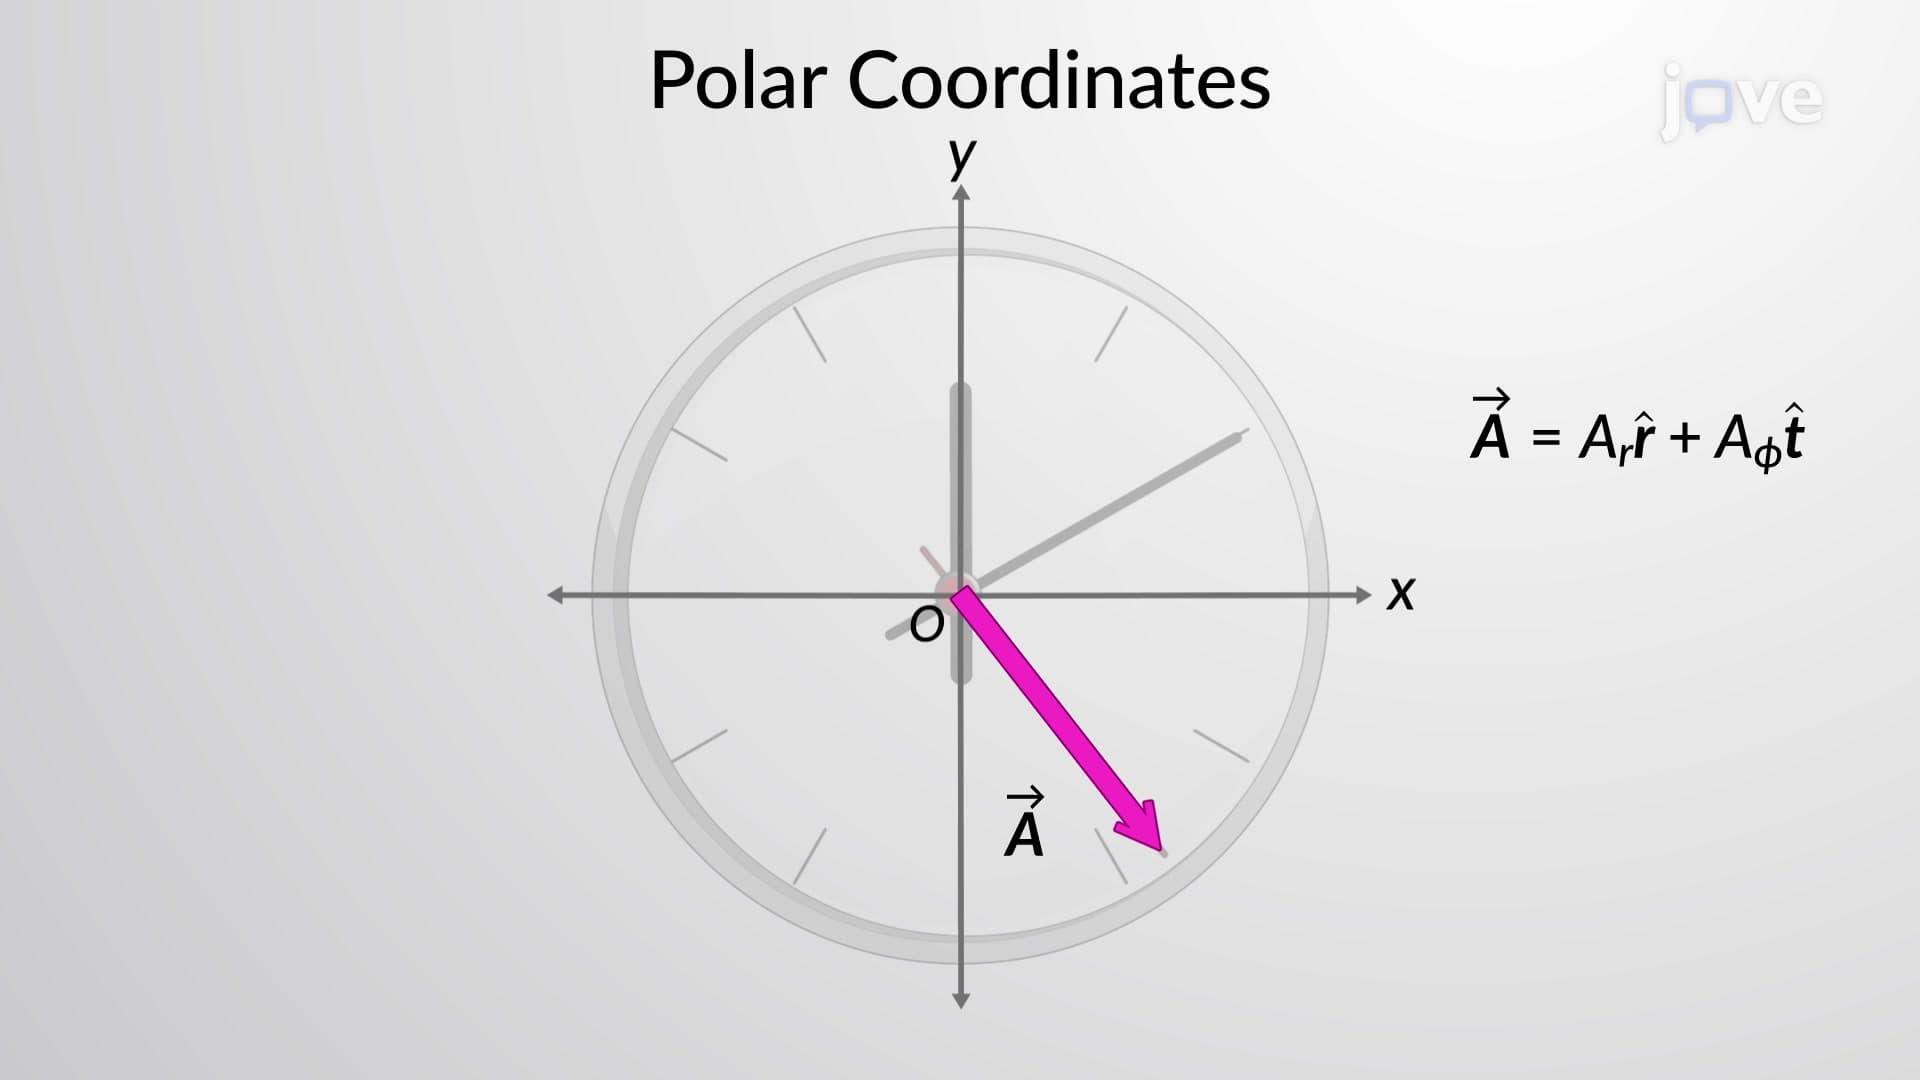
The Cartesian coordinate system is a very convenient tool to use when describing the displacements and velocities of objects and the forces acting on them. However, it becomes cumbersome when we need to describe the rotation of objects. So, when describing rotation, the polar coordinate system is generally used.
14.4K