

交叉转速螺杆电机轴承故障诊断结合多空间变量尺度自适应过器和前混合战略
Hao Zhou1, Jianzhong Yang1, Qian Zhu1
1National Numerical Control System Engineering Research Center, Huazhong University of Science and Technology, Mechanical Building, 1037 Luoyu Road, Wuhan 430074, China.
ISA transactions
|December 8, 2024

概括
本研究介绍了一种自适应性正弦融合卷积神经网络 (ASFCNN),用于在不同速度的CNC机器中诊断螺旋电机轴承故障. ASFCNN有效降低噪音,并增强故障特征,以提高准确性.
科学领域:
- 机械工程 机械工程
- 人工智能的人工智能
- 信号处理 信号处理
背景情况:
- 在CNC加工中,线轴电机的振动信号是复杂的,含有噪声和调制波.
- 由于信号特征的变化,螺旋转速的变化使故障诊断复杂化.
研究的目的:
- 开发一个强大的故障诊断方法,用于轴承螺旋电机,有效地运行在不同的速度.
- 为应对CNC机床诊断中噪声和信号变化所带来的挑战.
主要方法:
- 提出了一个自适应性鼻状融合卷积神经网络 (ASFCNN) 模型.
- 使用多空间可变尺度自适应性阴影过器 (MVASF) 来降低噪音和提取特征.
- 实施了多层次的前混合战略 (MFHS),以融合CNN的功能和时间序列信息.
主要成果:
- 在现实数据集上,ASFCNN模型显示出与经典方法相比,更高的诊断准确性.
- 实现了有效的降噪和故障特征增强.
- 使用可视化技术验证了模型的有效性和可解释性.
结论:
- 拟议的ASFCNN方法为螺旋电机轴承的横速故障诊断提供了显著的进步.
- MVASF和MFHS的集成提供了一个强大的方法来处理复杂的振动信号.
- 该研究验证了ASFCNN在CNC机床中可靠和可解释的故障诊断能力.

相关概念视频
 01:25
Multimachine Stability
141
Multimachine stability analysis is crucial for understanding the dynamics and stability of power systems with multiple synchronous machines. The objective is to solve the swing equations for a network of M machines connected to an N-bus power system.
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
141
 01:24
Bearings: Problem Solving
272
Understanding the calculations and concepts related to double-collar bearings is essential for engineers and designers to optimize the performance of these components in various applications. By analyzing the bearing under different conditions, one can ensure that it can withstand the forces and moments experienced during operation. This knowledge enables better decision-making when designing and selecting bearings for specific purposes and configurations. Consider a double-collar bearing with...
272
 01:30
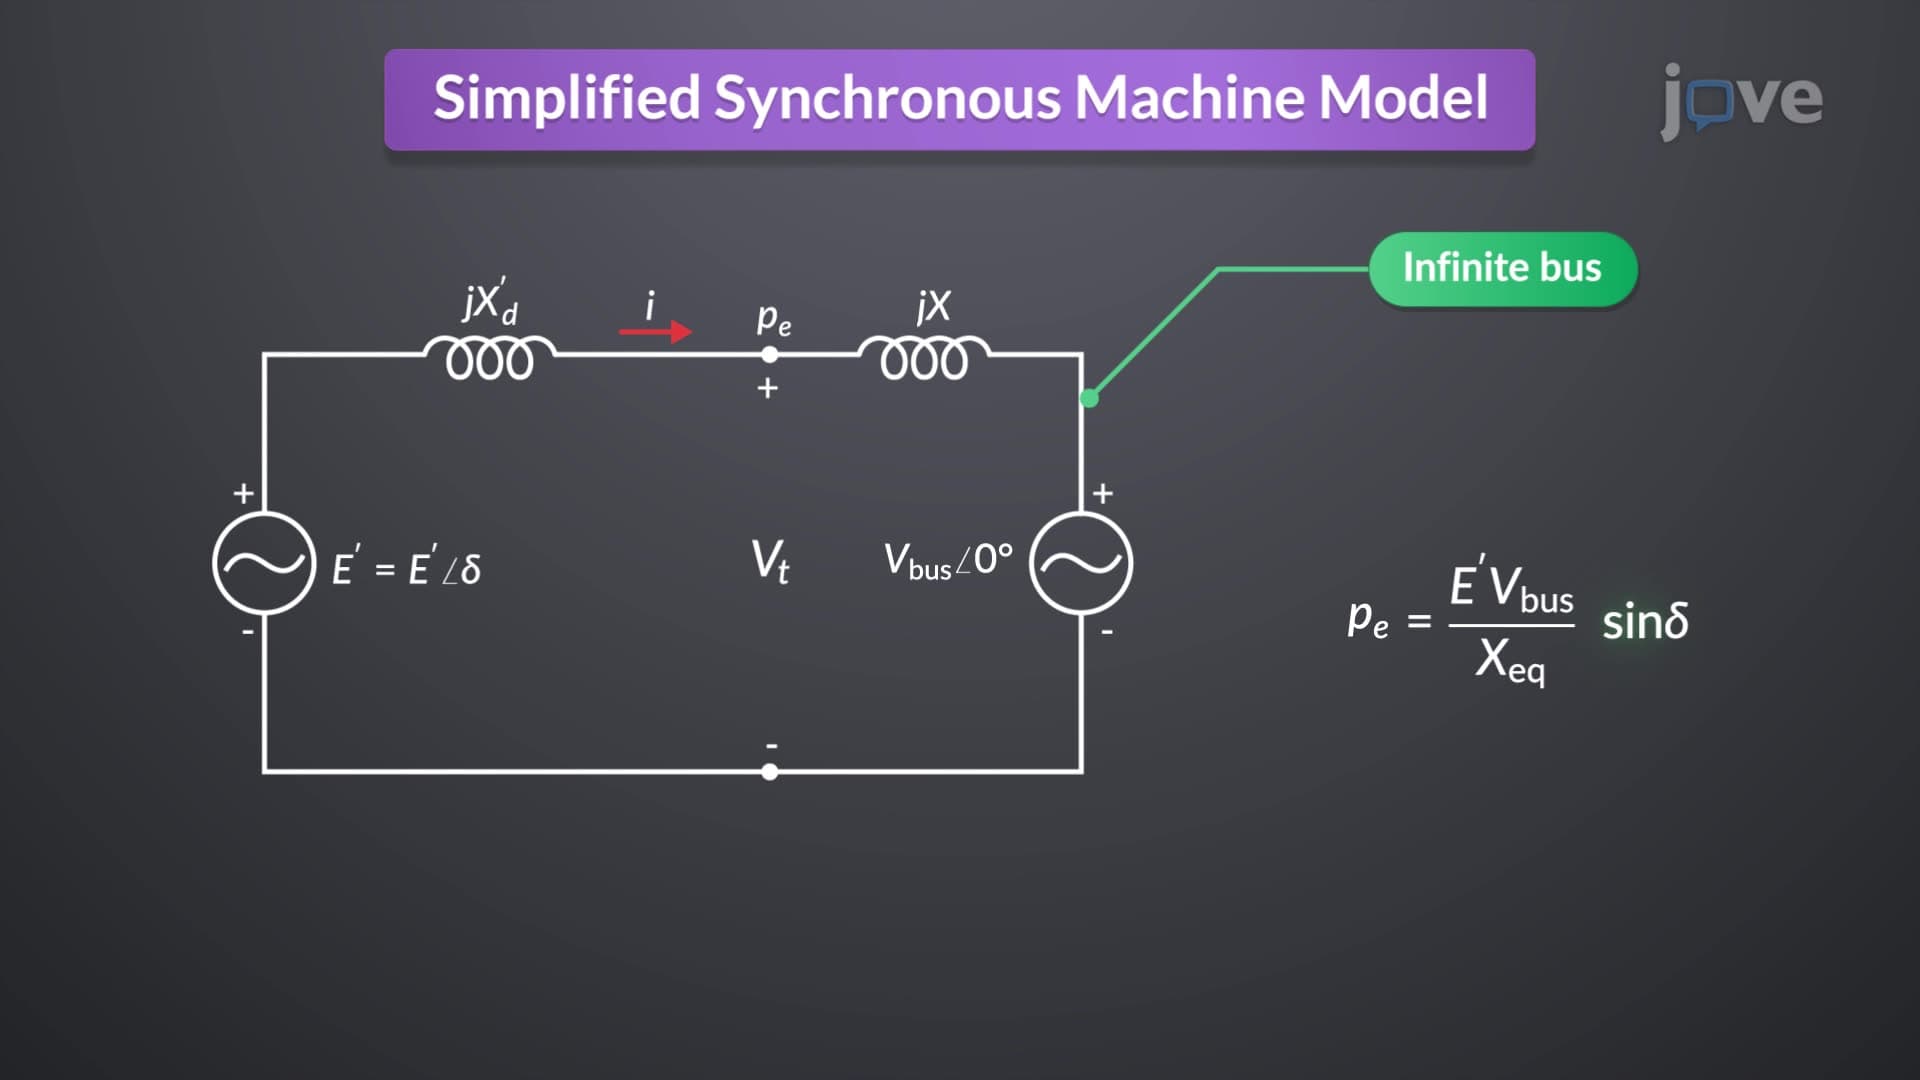
Simplified Synchronous Machine Model
181
The Synchronous Machine Model is a fundamental tool in analyzing and ensuring the transient stability of power systems. This model simplifies the representation of a synchronous machine under balanced three-phase positive-sequence conditions, assuming constant excitation and ignoring losses and saturation. The model is pivotal for understanding the behavior of synchronous generators connected to a power grid, particularly during transient events.
In this model, each generator is connected to a...
In this model, each generator is connected to a...
181
 01:22
Multi-input and Multi-variable systems
96
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
96
 01:26
Feedback control systems
286
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
286
 01:07
Time-Domain Interpretation of PD Control
83
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
83