

轻量级双层控制架构用于人类跟随机器人的机器人
Gustavo A Acosta-Amaya1, Deimer A Miranda-Montoya2, Jovani A Jimenez-Builes2
1Instrumentation and Control Department, Faculty of Engineering, Politécnico Colombiano Jaime Isaza Cadavid, Medellín 050022, Colombia.
Sensors (Basel, Switzerland)
|December 17, 2024

概括
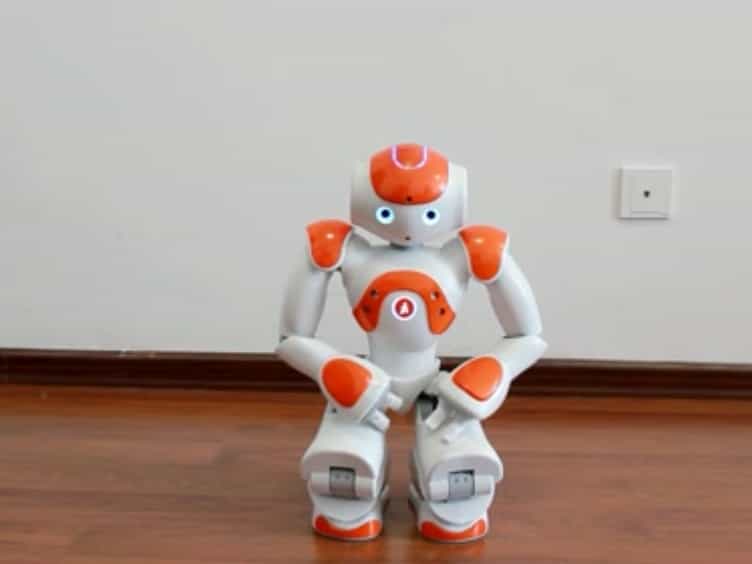
这项研究引入了一个新的机器人控制系统,帮助机器人跟随室内的人. 该系统使用模糊逻辑控制器和先进的算法,证明了对辅助机器人的有效性.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
- 人工智能的人工智能
背景情况:
- 人类检测和跟踪对于室内环境中安全的人机交互至关重要,特别是对辅助机器人来说.
- 老年人和残疾人对援助的日益增长的需求推动了先进机器人系统的发展.
研究的目的:
- 为人类跟随机器人展示一种轻量级的两层控制架构.
- 整合一个模糊的基于行为的控制系统与低级嵌入式控制器,以提高性能.
主要方法:
- 使用RGB-D传感器捕获距离和角度数据.
- 实现了一个模糊控制器来生成电机转速设定点.
- 开发了使用杆位和内部模型控制 (IMC) 方法的低级控制器.
主要成果:
- 机器人成功地实时跟随一个人,在五次试验中保持1.3米的距离.
- 内部模型控制 (IMC) 控制器在所有评估指标上都表现优于杆位控制器.
- 实验验证证证实了该架构在现实世界场景中的有效性.
结论:
- 拟议的控制架构为有限的计算能力的人类跟随辅助机器人提供了强大的实时解决方案.
- 该系统的模块化和可扩展性支持未来个人辅助机器人技术的进步.
- 这种方法有效地解决了室内人机交互的挑战.

相关概念视频
 01:24
One-Degree-of-Freedom System
464
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
464
 01:22
Controller Configurations
85
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
85
 01:18
Hierarchy of Motor Control
2.5K
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
2.5K
 01:29
Two-Dimensional Force System: Problem Solving
540
Solving problems related to two-dimensional force systems is an essential aspect of mechanics and engineering. By applying the principles of vector analysis and force equilibrium, one can determine the effect of multiple forces acting on an object in a two-dimensional space.
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
540
 01:20
Two-Dimensional Force System
871
A two-dimensional system in mechanical engineering involves the analysis of motion and forces in a plane. A two-dimensional force vector can be resolved into its components as:
871
 01:30
Three-Dimensional Force System:Problem Solving
625
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
625