

优化逆动力学建模和关节角度预测,用于具有可解释AI的六度自由度人形机器人
Rakesh Chandra Joshi1, Jaynendra Kumar Rai2, Radim Burget3
1Amity Centre for Artificial Intelligence, Amity University, Noida, UP, India.
ISA transactions
|December 20, 2024

概括
本研究探讨了人工智能模型,以解决六度自由度 (六度DoF) 人类型机器人的复杂反向动力学. 最优的人工智能模型平衡了准确性和计算效率,以实现实际的机器人自动化.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
- 计算动力学计算动力学
背景情况:
- 反向动力学对于机器人控制至关重要,它可以确定所需端效应器姿势的关节配置.
- 六度自由度 (six-DoF) 的人类型机器人由于复杂的数学,非线性和多个解决方案而带来了重大的反向动力学挑战.
- 现有的方法经常与计算需求和通用性作斗争.
研究的目的:
- 系统地探索和确定最佳的人工智能 (AI) 模型,以解决六个DoF的人形机器人的反动力学问题.
- 在人工智能驱动的反动力学解决方案中平衡预测准确性和计算效率.
- 使用可解释AI (XAI) 技术增强模型的解释性.
主要方法:
- 系统地探索和严格评估各种人工智能模型.
- 贝叶斯优化用于超参数调整,以选择最佳回归器.
- 在性能评估的公共数据集上进行五重交叉验证.
- 可解释性AI (XAI) 使用SHAP (夏普利添加式扩展) 进行特征重要性分析.
主要成果:
- 选择的AI模型在预测六个连接角度方面取得了很高的准确性,平均平方误差在1.934 × 10⁻³和3.522 × 10⁻³之间.
- 证明了显著的计算效率,每个样本的预测时间约为1.25毫秒.
- SHAP分析证实了模型的可解释性,并突出了关键特征的重要性.
结论:
- 人工智能模型为六个DoF的人类型机器人的复杂反向动力学提供了可行和高效的解决方案.
- 开发的方法成功地平衡了预测准确性和计算速度,这对于现实世界机器人自动化至关重要.
- 这项研究通过为机器人系统提供可解释和高效的动力学解决方案,推进了最先进的技术.

相关概念视频
 01:24
One-Degree-of-Freedom System
464
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
464
 01:30
Kinematic Equations for Rotation
315
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
315
 01:15
Kinematic Equations: Problem Solving
11.9K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
11.9K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
388
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
388
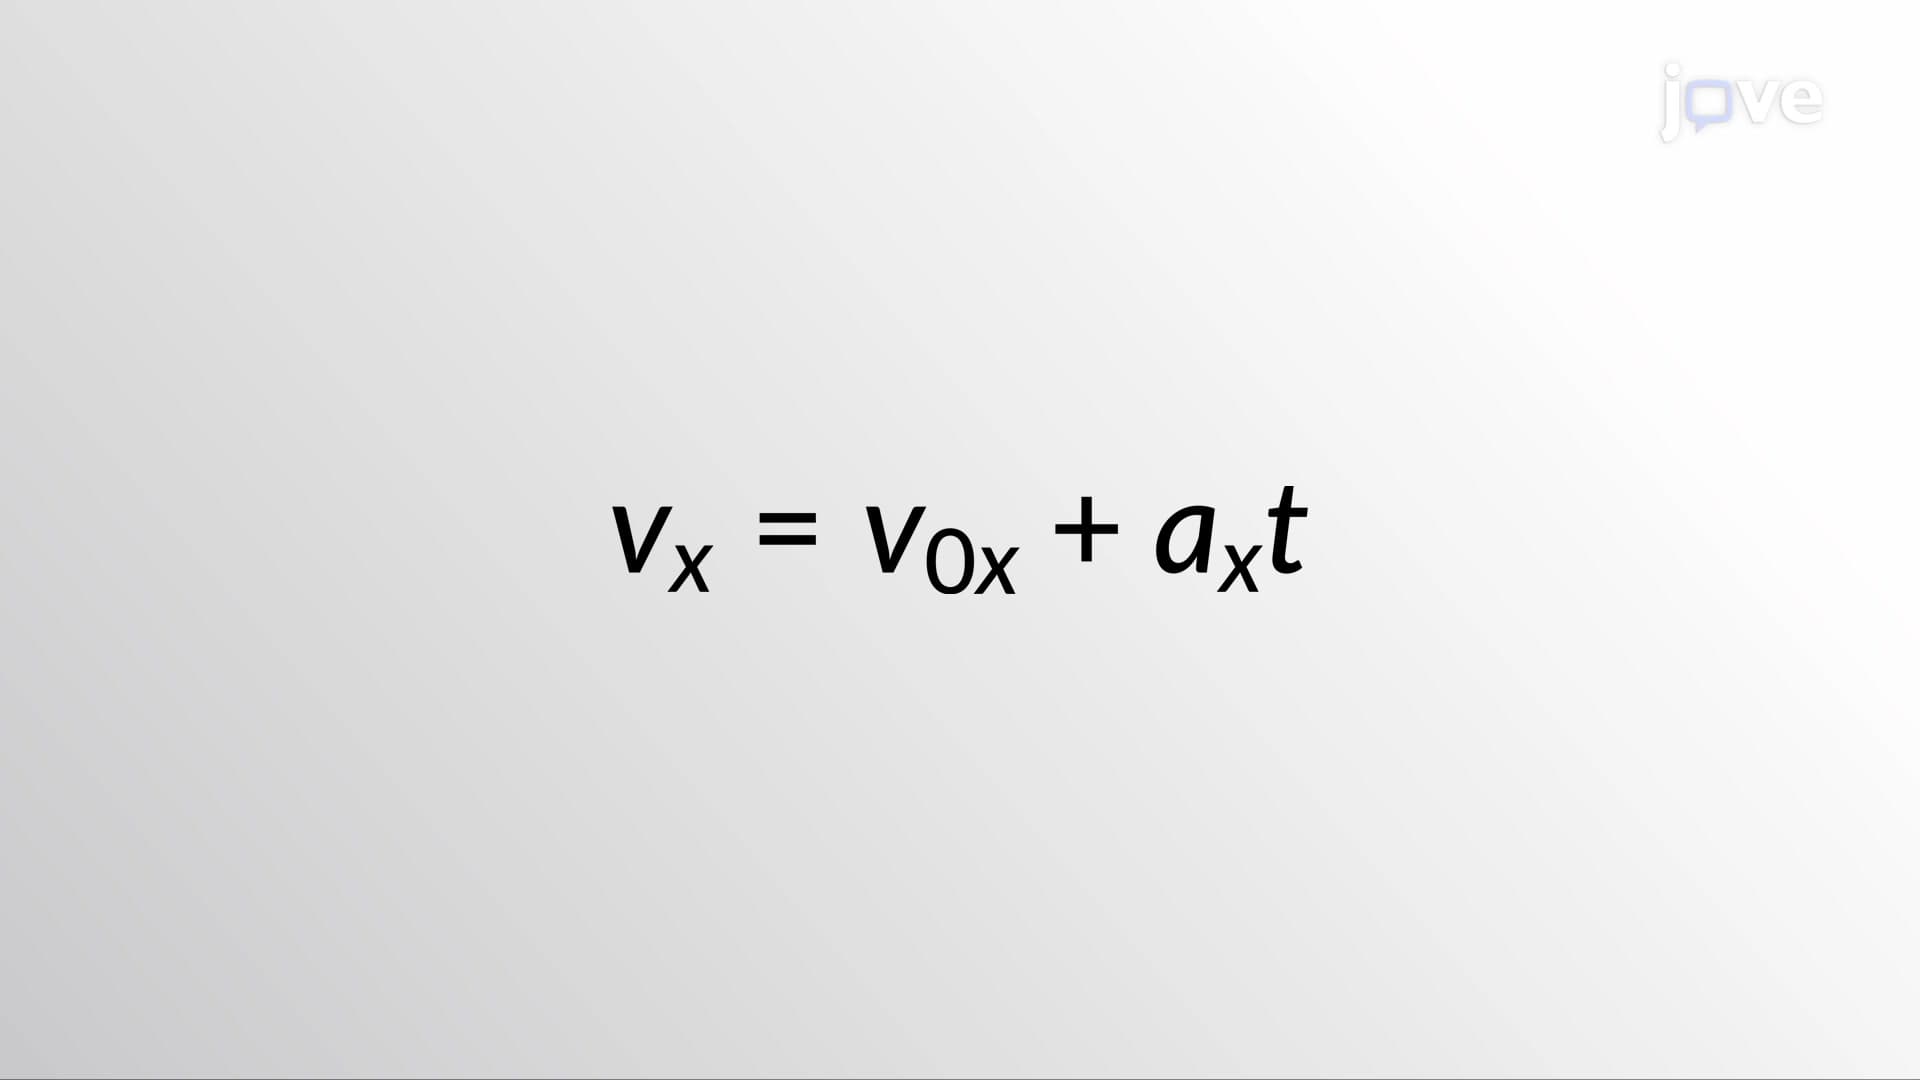 01:26
Kinematic Equations - I
10.3K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.3K
 01:18
Kinematic Equations - III
7.5K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.5K