基于神经网络的形状分析和连续性对象的控制
Yuqiao Dai1, Shilin Zhang1, Wei Cheng2
1School of Mechanical Engineering and Automation, Harbin Institute of Technology Shenzhen, Shenzhen 518055, China.
Biomimetics (Basel, Switzerland)
|December 27, 2024

概括
这项研究引入了一种新方法,使软机器人能够准确地识别和复制它们的形状. 它结合了轮提取,摄像头重建和神经网络,为灵活的连续机器人控制提供了一个有希望的解决方案.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
背景情况:
- 软机器人越来越多地研究他们的连续结构.
- 软机器人精确的形状识别和复制存在重大挑战.
研究的目的:
- 开发一种用于形状估计和控制灵活连续机器人的新方法.
- 为了解决软机器人的形状识别和复制方面的局限性.
主要方法:
- 一种混合方法,结合了轮提取和摄像头重建,以捕捉形状特征.
- 利用神经网络来建模运动指令和机器人形状之间的复杂关系.
- 建立一个模拟环境来验证拟议的方法.
主要成果:
- 提出的方法有效地预测了灵活的连续机器人的形状.
- 这种方法成功地复制了软机器人的预期形状.
- 在模拟中的验证证实了形状估计和控制策略的有效性.
结论:
- 这种新的方法为软机器人中的连续形状控制提供了一个强大的解决方案.
- 这项研究提升了软机器人在形状意识和操纵方面的能力.
- 这些发现为灵活连续机器人的更复杂应用铺平了道路.
相关概念视频
 01:14
Bending of Curved Members - Strain Analysis
125
The mechanics of deformation in curved members, such as beams or arches, under bending moments, involve complex responses. When such a member, symmetric about the y-axis and shaped like a segment of a circle centered at point C, is subjected to equal and opposite forces, its curvature and surface lengths change significantly. This alteration results in the shift of the curvature's center from C to C', indicating a tighter curve.
The important part of bending analysis for such a member...
The important part of bending analysis for such a member...
125
 01:16
Control Volume and System Representations
714
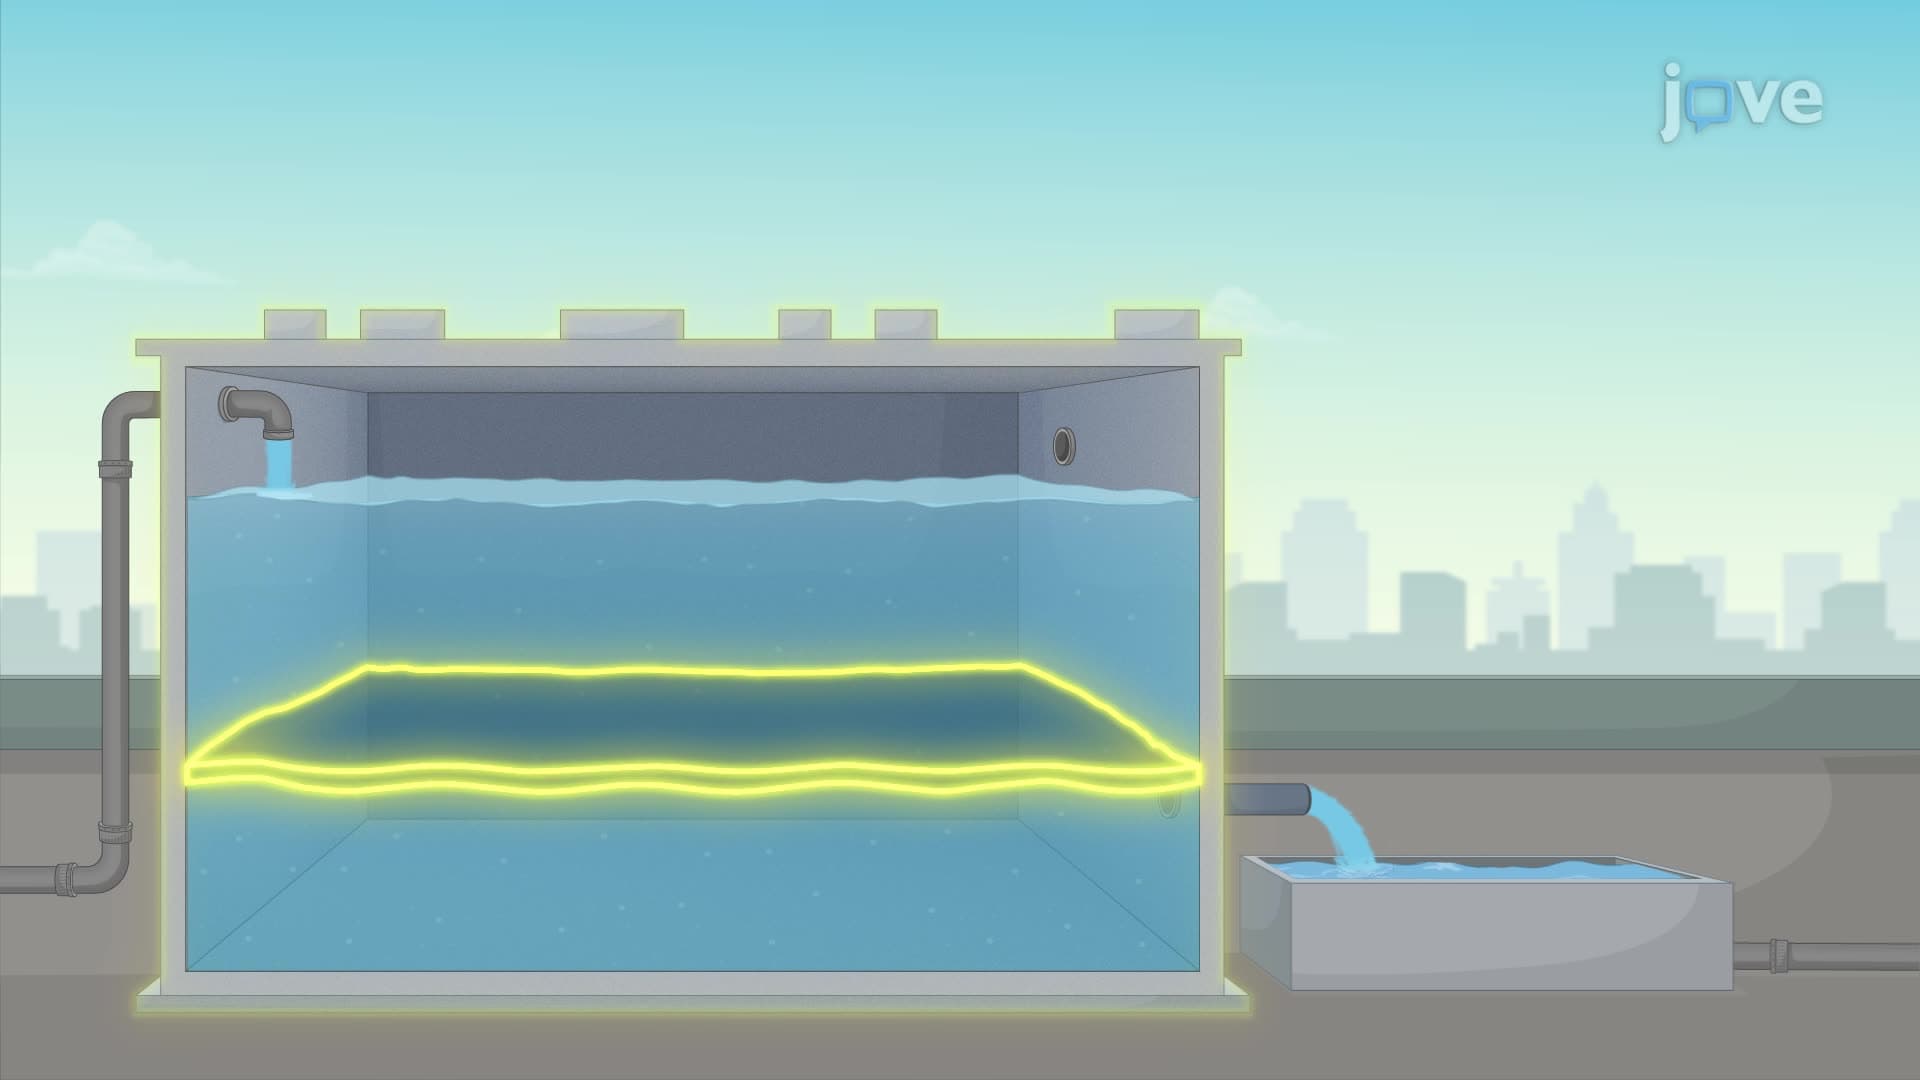
Two key frameworks are employed to analyze mass, energy, and momentum transfer: the control volume approach and the system approach. These frameworks offer different perspectives, depending on whether the focus is on a specific region in space (control volume approach) or a defined mass of fluid (system approach).
The control volume approach considers a stationary region in space through which fluid flows. This region is bounded by a control surface. For instance, in the case of water...
The control volume approach considers a stationary region in space through which fluid flows. This region is bounded by a control surface. For instance, in the case of water...
714
 01:03
Centroid of a Body: Problem Solving
1.0K
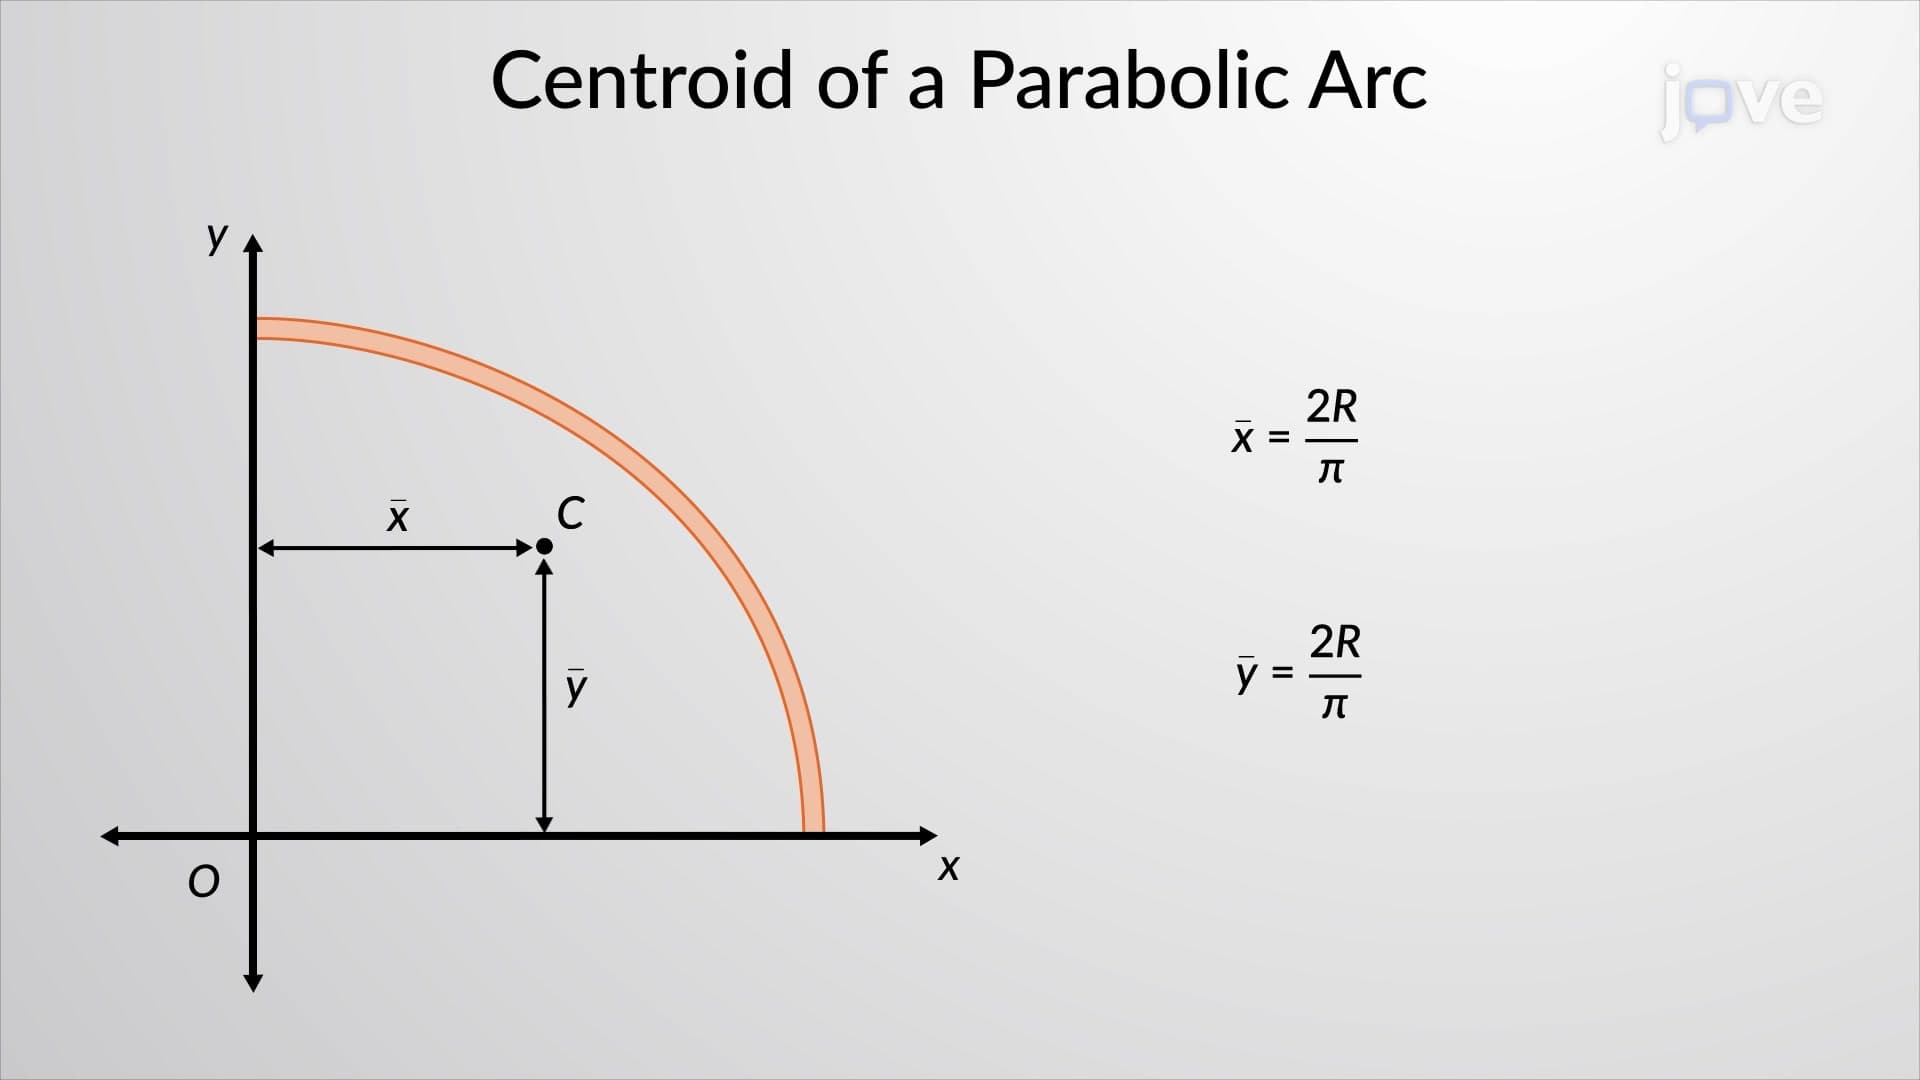
The centroid of a body is a crucial concept in engineering and physics. Finding the centroid of a body can help determine its stability, its balance point, and even its design. In this context, consider a thin wire bent in the form of a quarter circular arc. Polar coordinates are used to calculate the centroid. The wire is first divided into small differential elements of a length equal to the radius multiplied by the differential angle.
The x-coordinates and y-coordinates of each element's...
The x-coordinates and y-coordinates of each element's...
1.0K