在患有膝关节骨关节炎和没有膝关节骨关节炎的个体中,在上升和下降楼梯时的全身角动量
Daisy O M Chan1, Ransi S S Subasinghe Arachchige2, Sizhong Wang3
1Physiotherapy Department, Princess Margaret Hospital, Lai Chi Kok, Hong Kong.
Scientific reports
|December 27, 2024

概括
患有膝关节关节炎的个体在楼梯谈判期间表现出较差的动态平衡控制,表现出更大的全身角动量. 这一发现为它们增加的跌倒风险提供了机制性的解释.
科学领域:
- 生物力学 生物力学
- 运动学 运动学
- 整形外科 整形外科 整形外科
背景情况:
- 膝关节关节炎 (KOA) 与跌倒的风险增加有关,这可能会产生严重的后果.
- 动态平衡控制对于安全的楼梯谈判至关重要.
- 全身角动量 (WBAM) 作为动态平衡的关键指标,动量增加可能意味着更高的跌倒风险.
研究的目的:
- 为了比较WBAM在楼梯上升和下降的个人和没有KOA.
- 调查在楼梯谈判期间KOA平衡控制差异背后的生物力学机制.
主要方法:
- 七名患有症状的KOA和八名无症状的对照参与者上升和下降一个仪器化的楼梯.
- 收集了动力学和动力学数据,以计算WBAM在斜面,正面和横面的平面.
- 统计分析比较了KOA和对照组之间的WBAM和联合动力学/动力学.
主要成果:
- 在KOA组显示,在上升和下降阶梯期间,在斜面平面中WBAM显著增加.
- 患有KOA的个体在楼梯下降期间也表现出更大的横平面WBAM.
- 这些差异与更大的部曲,减少膝盖曲时刻,以及KOA组中改变的脚前进角度有关.
结论:
- 患有KOA的个体在楼梯谈判期间表现出动态平衡控制受损,其特征是增加WBAM.
- 改变的关节机制,包括部和膝盖运动,有助于这种平衡缺陷.
- 这些发现为膝关节骨关节炎患者观察到的较高跌倒风险提供了生物力学理由.
相关概念视频
 01:23
Knee Joint
1.3K
The knee joint is the most complicated joint in the body. It consists of three articulations– two tibiofemoral and one patellofemoral. As is characteristic of synovial joints, the knee joint has a thin articular capsule that partially surrounds this joint cavity. Additionally, several ligaments, muscles, and cartilaginous structures support the movement of the knee.
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
1.3K
 01:10
Ankle Joint
1.3K
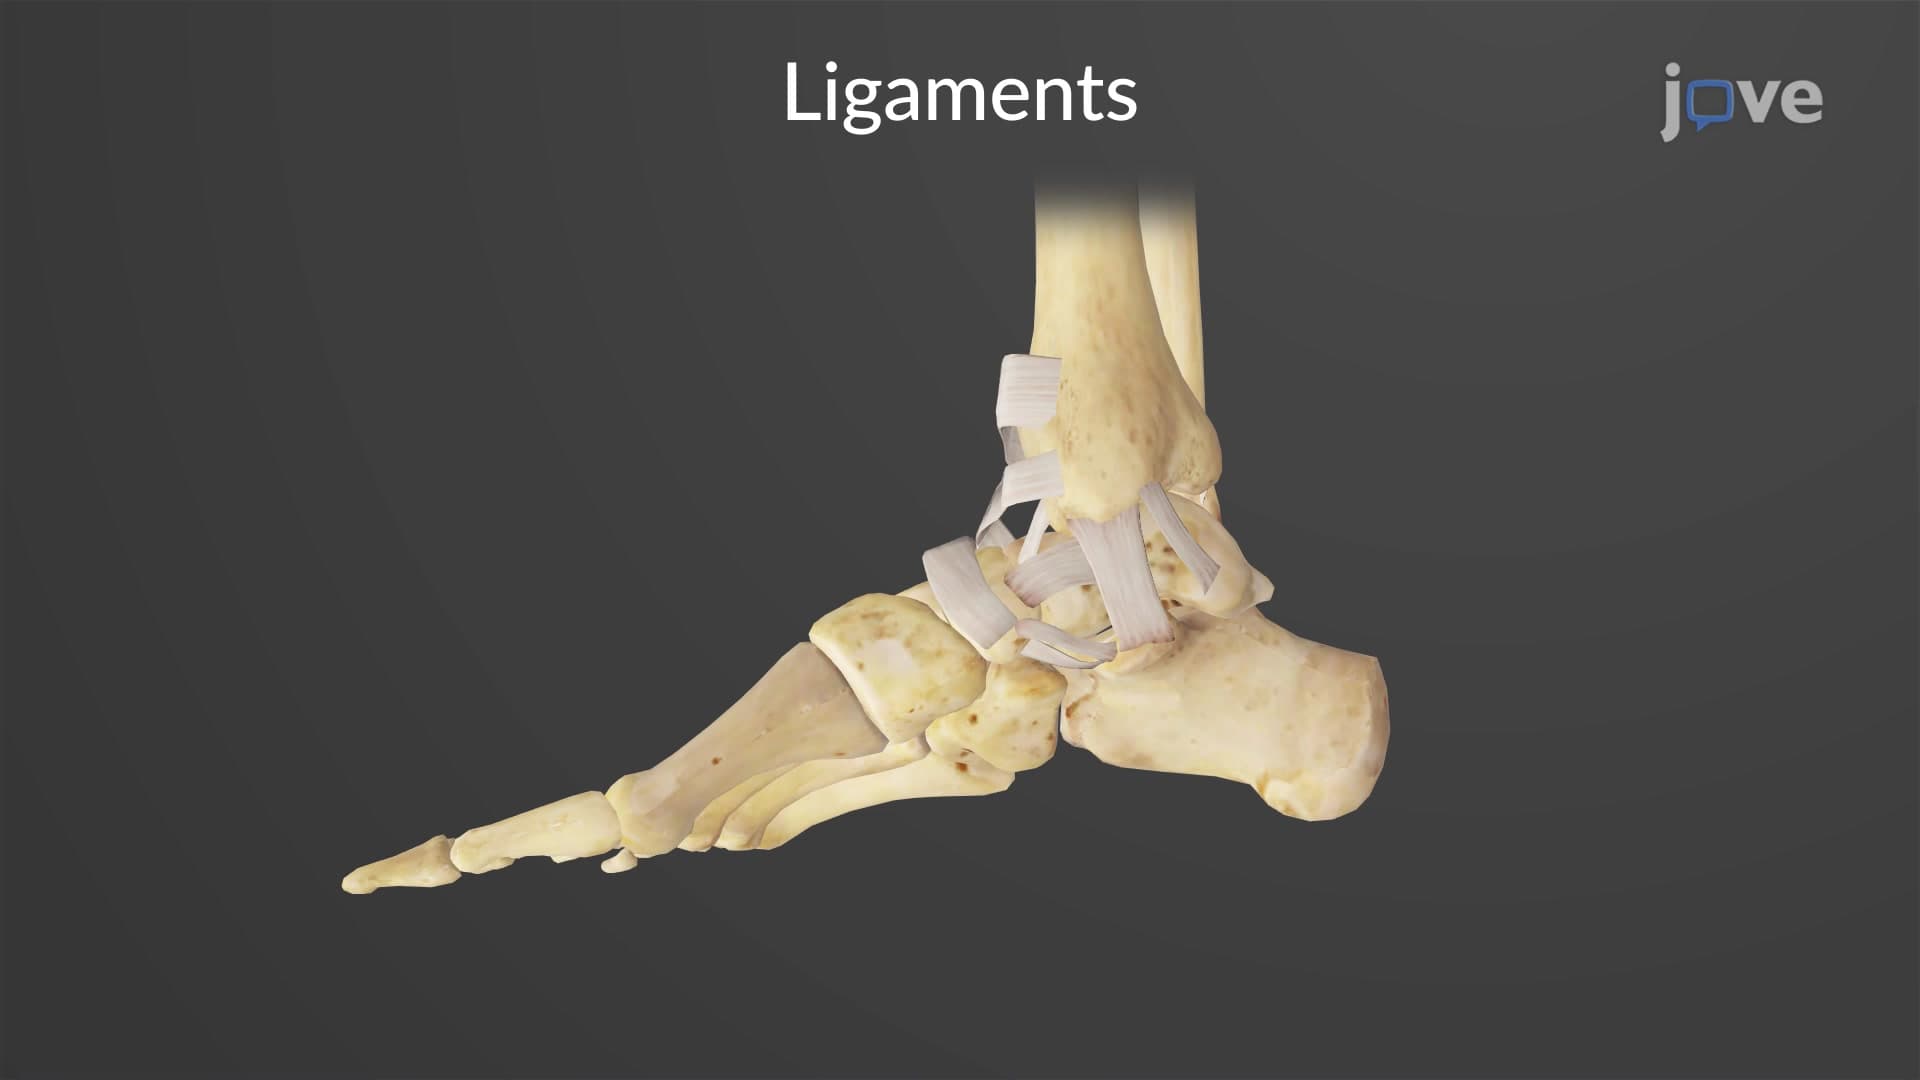
The ankle is formed by the talocrural joint (crural = leg). It consists of the articulations between the talus bone of the foot and the distal ends of the tibia and fibula of the leg. The superior aspect of the talus bone is square-shaped and has three areas of articulation. The top of the talus articulates with the inferior tibia. This is the portion of the ankle joint that carries the body weight between the leg and foot. The sides of the talus are firmly held in position by the articulations...
1.3K
 01:09
Angular Momentum and Principle Axes of Inertia
170
The concept of angular momentum for a solid structure is illustrated as the cumulative result of the cross-product of the position vector of the mass element and the cross-product of the body's angular velocity with the position vector.
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
170
 01:11
Angular Momentum about an Arbitrary Axis
166
Imagine a rigid body with a mass denoted as 'm', which has its center of mass at point G and is rotating around an inertial reference frame. The angular momentum at an arbitrary point P can be calculated by taking the cross product of the position vector and linear momentum vector for each individual mass element.
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into...
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into...
166
 01:09
Conservation of Angular Momentum
10.0K
A system's total angular momentum remains constant if the net external torque acting on the system is zero. Considering a system that consists of n tiny particles, the angular momentum of any tiny particle may change, but the system's total angular momentum would remain constant. The principle of conservation of angular momentum only considers the net external torque acting on the system. While there are internal forces exerted by different particles within the system that also produce...
10.0K
 01:10
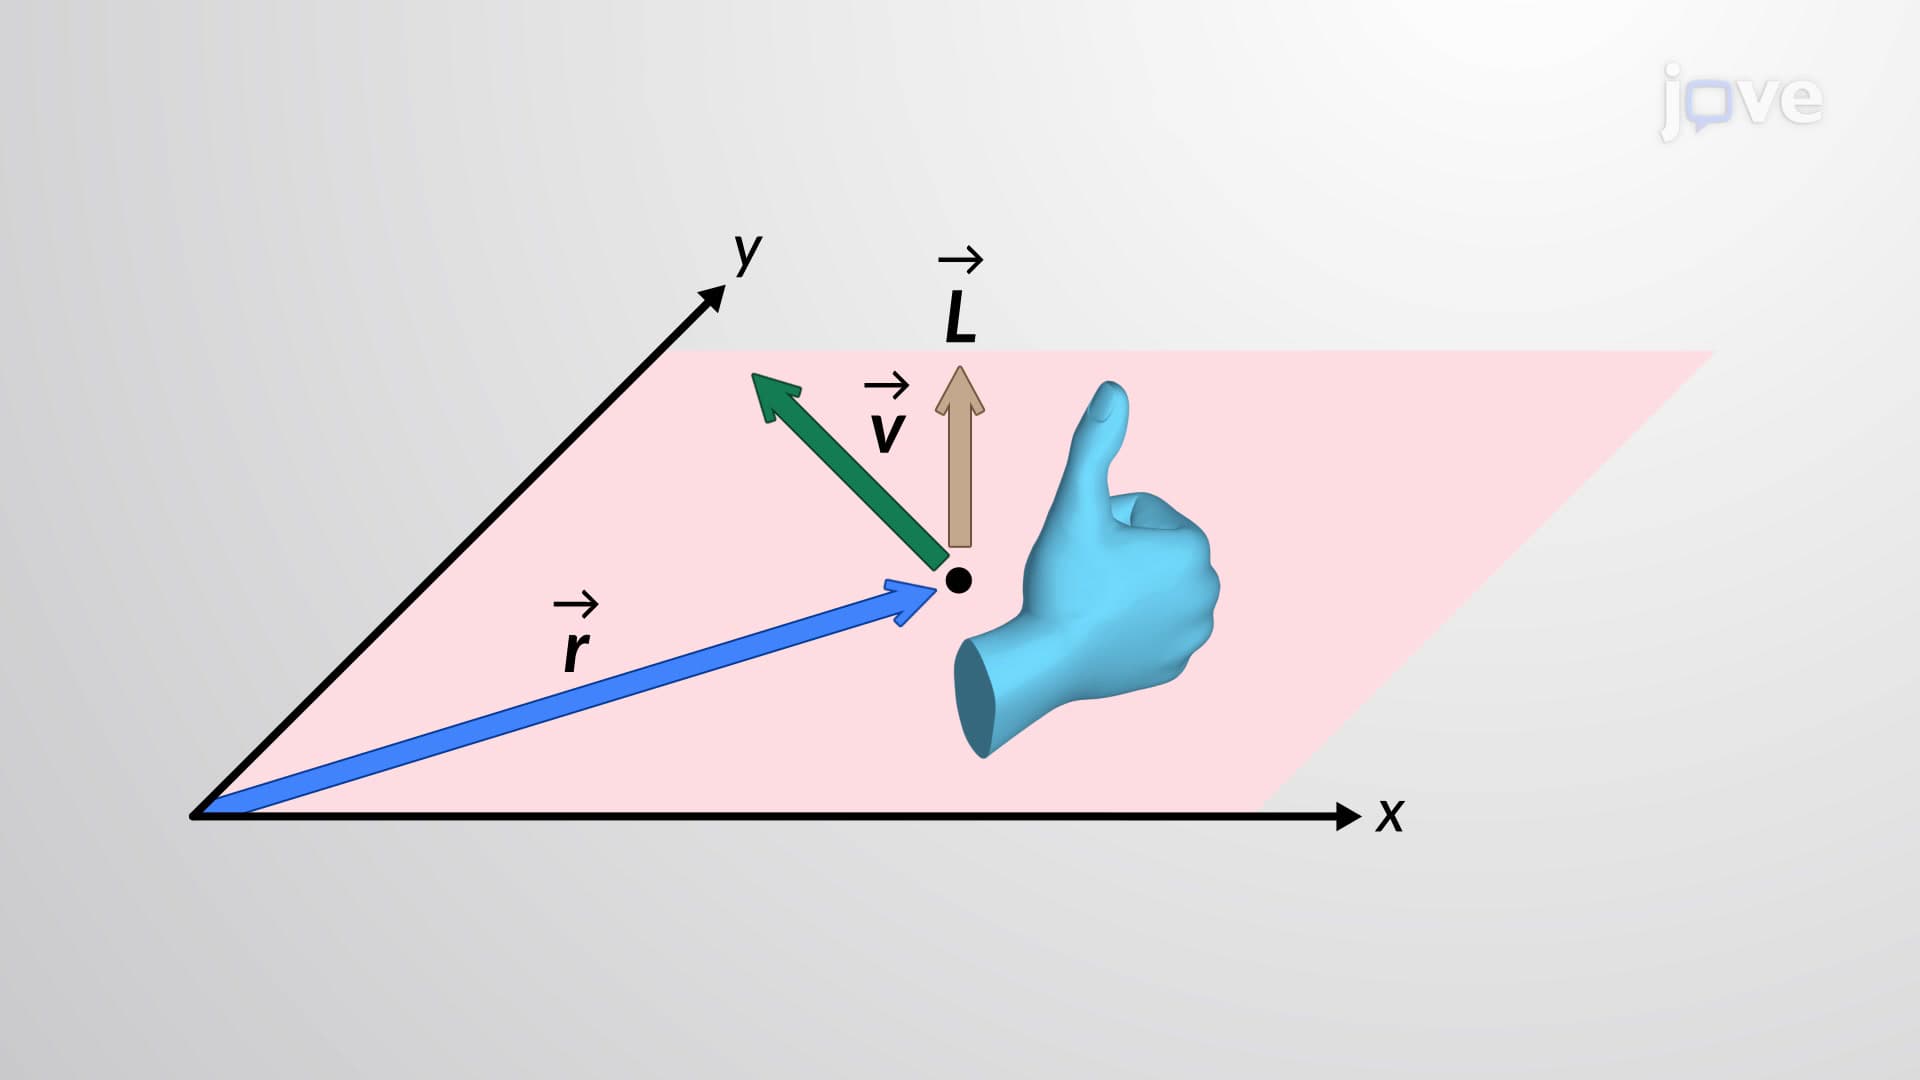
Angular Momentum: Single Particle
6.0K
Angular momentum is directed perpendicular to the plane of the rotation, and its magnitude depends on the choice of the origin. The perpendicular vector joining the linear momentum vector of an object to the origin is called the “lever arm.” If the lever arm and linear momentum are collinear, then the magnitude of the angular momentum is zero. Therefore, in this case, the object rotates about the origin such that it lies on the rim of the circumference defined by the lever arm...
6.0K