
基于深度学习和模糊逻辑的自动制动驾驶员辅助系统
A R García-Escalante1, R Q Fuentes-Aguilar2, A Palma-Zubia1
1Tecnológico de Monterrey, Escuela de Ingenieria y Ciencias, Zapopan, Jalisco, México.
PloS one
|December 31, 2024

概括
本研究介绍了1级高级驾驶辅助系统 (ADAS),用于使用交通信号灯检测的自动制动. 现实世界的测试验证了系统的有效性.
科学领域:
- 计算机视觉和机器人技术
- 智能运输系统 智能运输系统
- 汽车工程 汽车工程
背景情况:
- 先进的驾驶辅助系统 (ADAS) 对于实现完全的运输自动化至关重要.
- 目前的ADAS研究通常依赖于室内实验,需要现实世界的验证才能实际实施.
- 交通灯检测和自动制动是提高车辆安全和自主性的关键组成部分.
研究的目的:
- 提出并验证一级ADAS,重点是使用交通信号灯检测的自动制动.
- 为了解决对ADAS功能户外,现实世界的测试需求.
- 开发一个精确的同步和短的反应时间制动决策的系统.
主要方法:
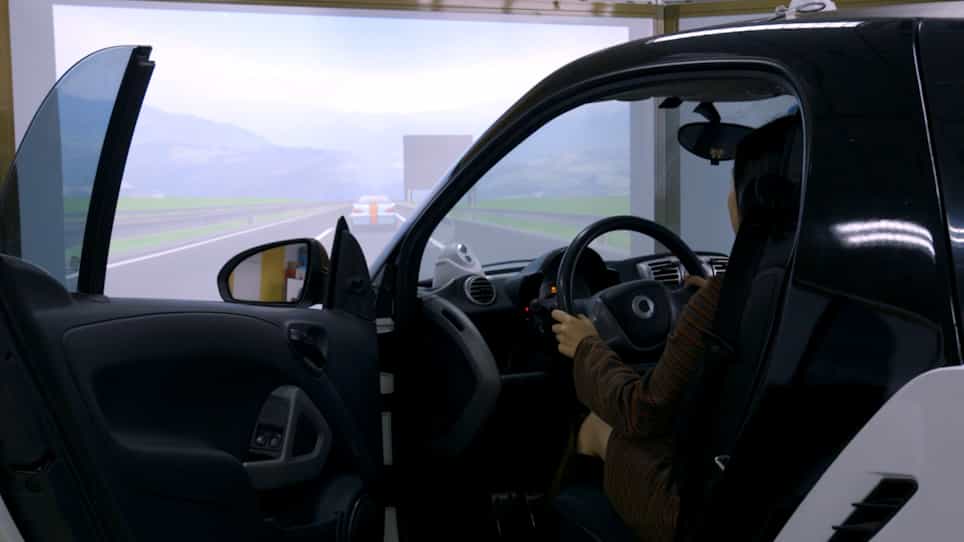
- 实现了一个NVIDIA Jetson TX2与ZED立体相机用于交通信号灯检测.
- 利用模糊的推断系统,根据交通信号灯状态和距离做出决策.
- 开发使用EfficientDet D0.0的一级交通信号灯状态探测器.
- 通过道路实验进行验证.
主要成果:
- EfficientDet D0模型在不同距离的交通信号检测 (0.96在<13m,0.89在15m) 中获得了高的mAP分数.
- 模糊逻辑制动配置文件显示,距离的平均RMSE为0.9m,制动力的平均RMSE为0.05m.
- 集成系统的快速响应时间为0.23秒.
结论:
- 开发的1级ADAS有效地集成了交通信号灯检测和自动制动,以适应现实环境.
- 该系统在道路实验中的性能验证了其在提高汽车安全方面的潜力.
- 这项研究通过实践验证来推进自动驾驶系统的最新技术.
相关概念视频
 01:26
PD Controller: Design
128
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
128
 01:22
Multi-input and Multi-variable systems
84
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
84
 01:22
Controller Configurations
69
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
69