在被动横向转换后更新目标的记忆位置
John J J Kim1, Laurence R Harris1
1Department of Psychology, York University, Toronto, Ontario, Canada.
PloS one
|December 31, 2024

概括
空间更新错误发生在自动移动过程中. 人们错误地判断物体位置,特别是对于古怪的目标,因为他们的运动范围如何影响空间感知.
科学领域:
- 认知心理学 认知心理学
- 神经科学是一个神经科学.
- 人类空间导航是人类的空间导航.
背景情况:
- 空间更新对于自我中心导航至关重要.
- 人类在线性自动运动后更新物体位置时会出现系统错误.
研究的目的:
- 调查空间更新错误的来源.
- 确定自我运动和目标异常度如何影响空间更新精度.
主要方法:
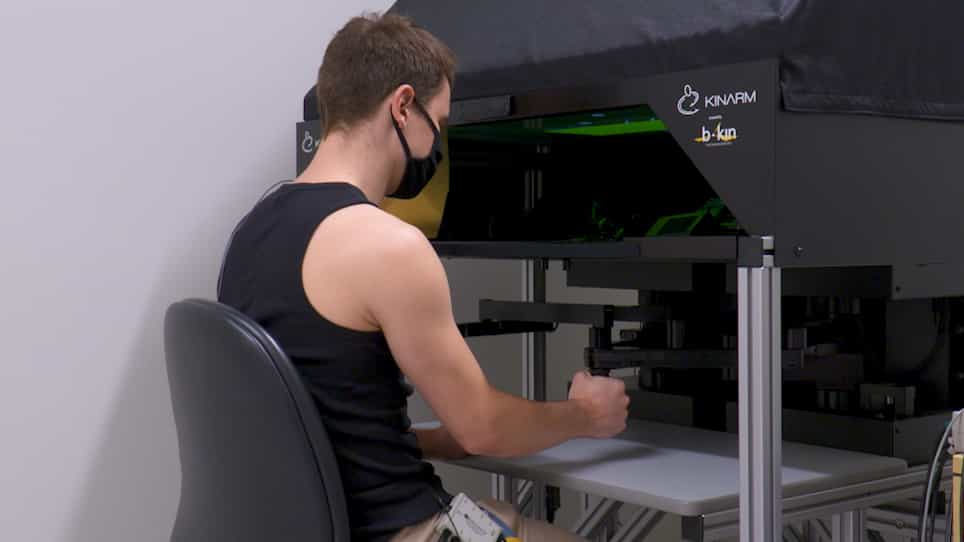
- 在模拟和物理自动运动期间记住目标位置的测量错误.
- 包括被动横向转换和多样化的目标异常度.
- 利用虚拟现实和一个6DOF运动平台.
主要成果:
- 参与者普遍低估了目标异常度.
- 低估值随着目标异常度的增加而增加.
- 错误取决于目标异常度和观察者的运动范围.
- 在移动范围内的目标跨越视觉中线的位置变化过高估计.
结论:
- 空间更新效率随着自我运动的感知而变化.
- 当目标在更新过程中穿过视觉半场时,会产生感知后果.
- 错误与对象位置在不同视觉领域的重建有关.
相关概念视频
 01:25
Long-term Potentiation
2.7K
Long-term potentiation, or LTP, is one of the ways by which synaptic plasticity—changes in the strength of chemical synapses—can occur in the brain. LTP is the process of synaptic strengthening that occurs over time between pre and postsynaptic neuronal connections. The synaptic strengthening of LTP works in opposition to the synaptic weakening of long-term depression (LTD) and together are the main mechanisms that underlie learning and memory.
Hebbian LTP
LTP can occur when...
Hebbian LTP
LTP can occur when...
2.7K
 01:25
Relative Motion Analysis using Rotating Axes
433
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
433
 01:00
Position and Displacement Vectors
9.3K
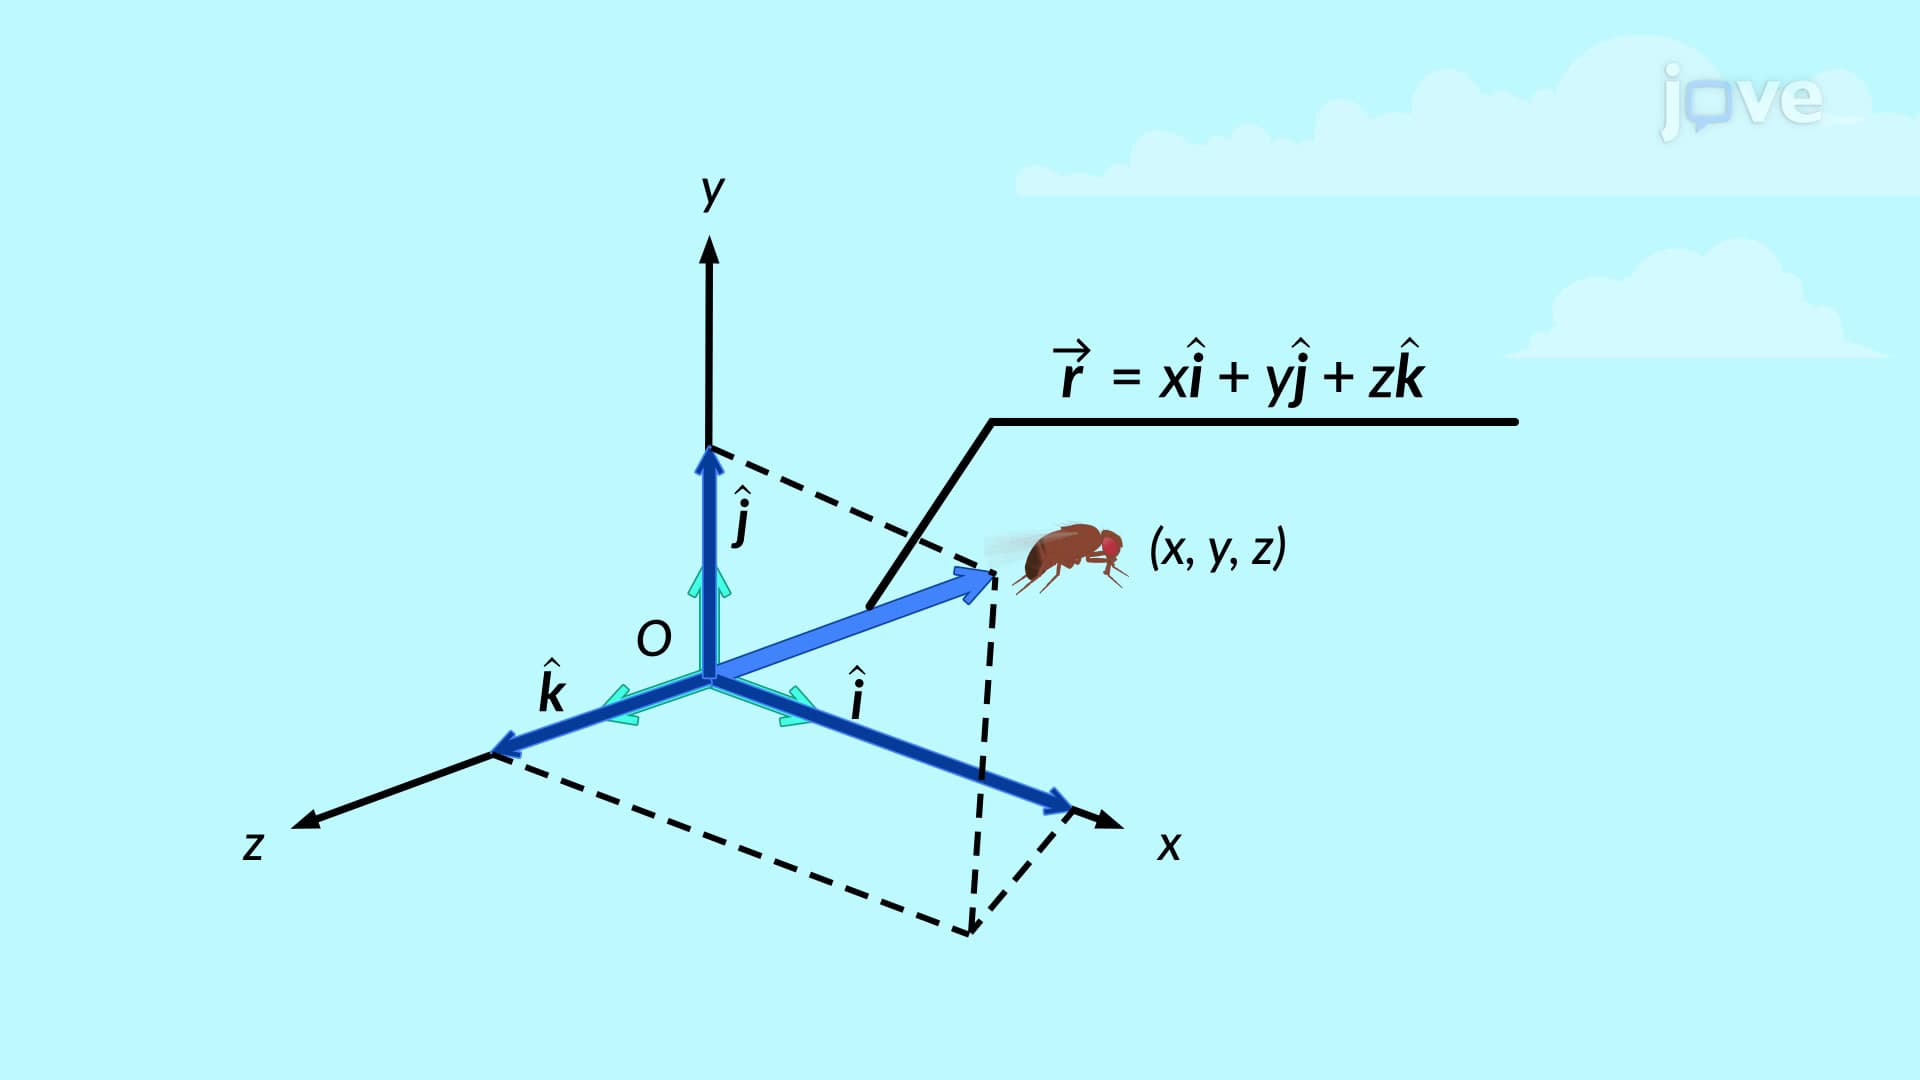
To describe the motion of an object, one should first be able to describe its position (where it is at any particular time). More precisely, the position needs to be specified relative to a convenient frame of reference. A frame of reference is an arbitrary set of axes from which the position and motion of an object are described. Earth is often used as a frame of reference to describe the position of an object in relation to stationary objects on Earth.
Further, several important kinds of...
Further, several important kinds of...
9.3K
 01:24
Relative Motion Analysis - Velocity
327
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
327
 02:07
Improving Translational Accuracy
8.5K
Base complementarity between the three base pairs of mRNA codon and the tRNA anticodon is not a failsafe mechanism. Inaccuracies can range from a single mismatch to no correct base pairing at all. The free energy difference between the correct and nearly correct base pairs can be as small as 3 kcal/ mol. With complementarity being the only proofreading step, the estimated error frequency would be one wrong amino acid in every 100 amino acids incorporated. However, error frequencies observed in...
8.5K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
309
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
309