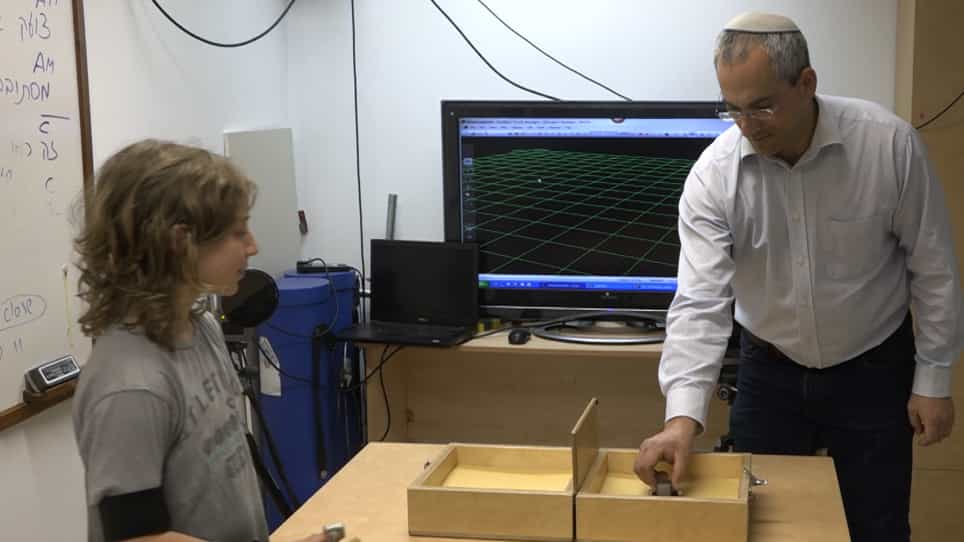

在触觉辅助的虚拟现实远程操作中,通过可视化交互力增强视觉反
Alex van den Berg1,2, Jelle Hofland2, Cock J M Heemskerk2
1Department of Cognitive Robotics, Delft University of Technology, Delft, Netherlands.
Frontiers in robotics and AI
|January 2, 2025

概括
视觉线索和头部安装的显示器提高机器人手臂远程操作的安全性和性能. 这两种方法都提高了用户的接受度,视觉线索提高了安全性,头部显示器改善了虚拟环境中的任务执行.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 人与计算机的交互
- 虚拟现实 虚拟现实 虚拟现实
背景情况:
- 触觉辅助远程操作受益于对相互作用力的视觉反.
- 对于机器人手臂远程操作性能的视觉提示设计和显示类型的理解有限.
研究的目的:
- 调查新型视觉线索和头部显示器 (HMD) 增强现实对机器人手臂触觉辅助远程操作的影响.
- 为了评估这些方法在模拟的工业任务 (Dross移除) 使用虚拟具的触觉辅助.
主要方法:
- 开发一种新的视觉暗示方法,用于交互力.
- 使用HMD实现增强视觉反.
- 人为因素实验是在模拟虚拟环境中进行的,用于清除渣的任务.
主要成果:
- 视觉暗示和HMD方法都显著改善了任务性能.
- 视觉暗示方法通过减少峰值碰撞力来提高安全性.
- 该HMD方法提供了显著的性能改进.
- 主观分析表明,用户对这两种方法的接受度都增加了.
结论:
- 对相互作用力和空间信息的视觉反对于有效的触觉辅助远程操作至关重要.
- 开发的视觉暗示和HMD方法为机器人手臂远程操作提供了实际好处.
- 这些发现有助于优化工业应用中的人机交互.

相关概念视频
 01:30
Three-Dimensional Force System:Problem Solving
577
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
577
 01:30
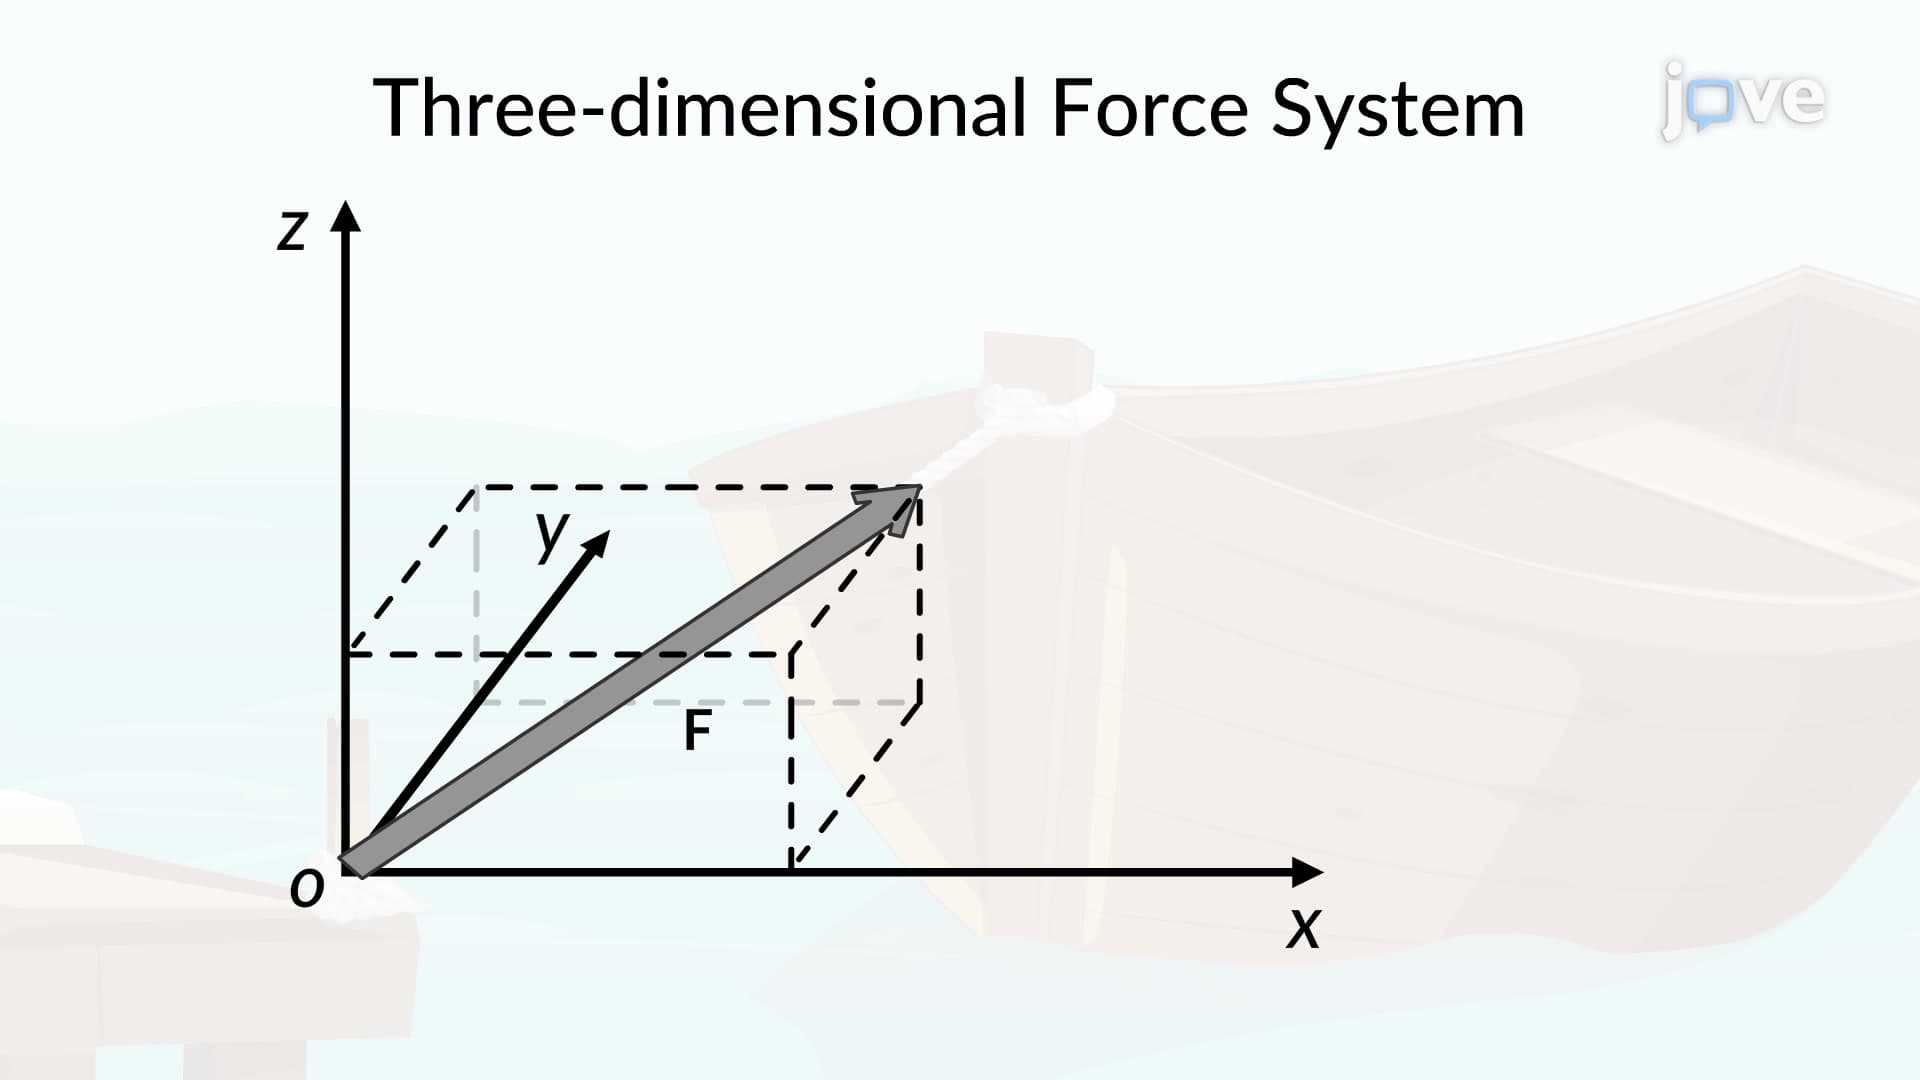
Three-Dimensional Force System
1.9K
In mechanical engineering, a three-dimensional force system is a system of forces acting in three dimensions, with forces applied along the x, y, and z coordinate axes. The three-dimensional force system is an important concept in mechanical engineering, as it allows engineers to understand and analyze the behavior of objects and structures in three dimensions. By understanding the forces acting on a system, engineers can design more efficient and effective mechanical systems that can withstand...
1.9K
 01:06
Virtual Work for a System of Connected Rigid Bodies
345
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
345