
如果-然后规则的稳定性和调节与双重任务条件下的运动选择中的前性规划相比
S E M Stoll1,2,3, A Wenzel1, B Hitzler1
1Department of Psychology, University of Konstanz, Konstanz, Germany.
Scientific reports
|January 8, 2025

概括
与前性规划相比,使用if-then规则的运动选择更有效. 然而,当次要任务需要对象分类时,这种优势会减少,从而支持双机制假设.
科学领域:
- 认知心理学 认知心理学
- 发动机控制器的控制器
- 人类运动科学科学 人类运动科学
背景情况:
- 运动选择涉及选择行动,有两个主要方法:基于规则的 (如果-然后) 和前性规划.
- 以前的研究表明,基于规则的选择更有效,但根本原因仍在争论中.
研究的目的:
- 在双重任务条件下,研究基于规则的运动选择与基于计划的运动选择的效率.
- 测试效率假设和双机制假设,解释运动选择中的差异.
主要方法:
- 48名参与者使用基于规则或基于计划的运动选择执行了旋任务.
- 实施了四个双重任务条件:听觉对象识别,听觉对象识别和分类,语义词语分类和计算.
主要成果:
- 基于规则的方法通常在大多数双重任务条件下产生更有效的运动选择.
- 基于规则的方法的优势消失了,特别是当次要任务涉及识别和分类对象声音时.
结论:
- 研究结果支持双机制假设,表明不同的认知过程是基于规则和基于计划的运动选择的基础.
- 二次任务的差异性影响凸显了认知负载和任务类型如何调节运动选择效率.
相关概念视频
 01:34
Woodward–Hoffmann Selection Rules and Microscopic Reversibility
Electrocyclic reactions, cycloadditions, and sigmatropic rearrangements are concerted pericyclic reactions that proceed via a cyclic transition state. These reactions are stereospecific and regioselective. The stereochemistry of the products depends on the symmetry characteristics of the interacting orbitals and the reaction conditions. Accordingly, pericyclic reactions are classified as either symmetry-allowed or symmetry-forbidden. Woodward and Hoffmann presented the selection criteria for...
 01:26
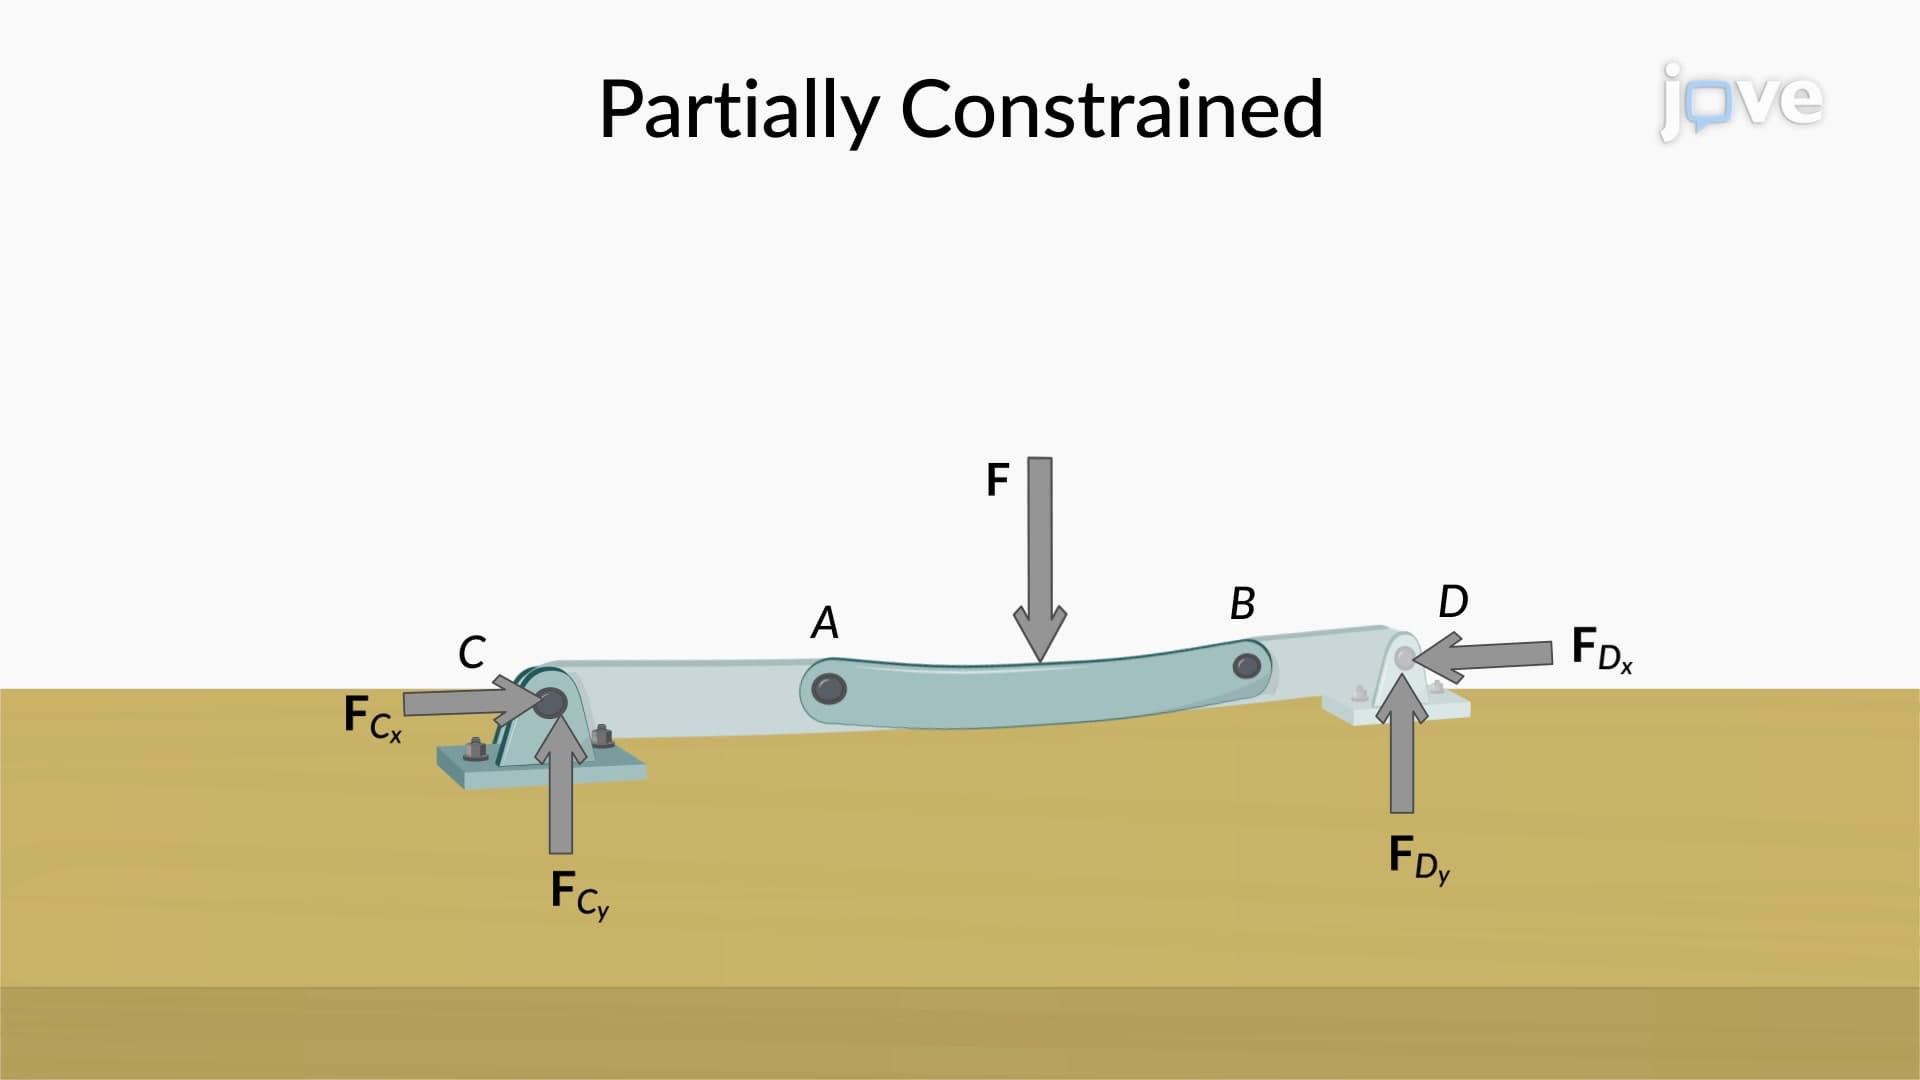
Constraints and Statical Determinacy
In structural engineering, the equilibrium of a system is not only determined by its equations of equilibrium but also with the help of constraints. Constraints refer to restrictions on the motion of a system. The proper combinations of constraints can minimize the total number of constraints needed to maintain a system in mechanical equilibrium. When this happens, the system is said to be statically determinate. For such systems, the unknown reaction supports can be estimated using equilibrium...
 01:13
Stability of Equilibrium Configuration: Problem Solving
The stability of equilibrium configurations is an important concept in physics, engineering, and other related fields. In simple terms, it refers to the tendency of an object or system to return to its equilibrium position after being disturbed. The stability of an equilibrium configuration can be analyzed by considering the potential energy function of the system and examining its behavior near the equilibrium point.
Problem-solving in the context of the stability of equilibrium configuration...
Problem-solving in the context of the stability of equilibrium configuration...
 01:22
Controller Configurations
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:25
Multimachine Stability
Multimachine stability analysis is crucial for understanding the dynamics and stability of power systems with multiple synchronous machines. The objective is to solve the swing equations for a network of M machines connected to an N-bus power system.
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:28
Lagrange Multipliers: Two Constraints
The method of Lagrange multipliers with two constraints is used to optimize a function subject to two independent constraints. In many applications, the objective function represents a quantity to be maximized or minimized, such as cost, area, distance, or energy. The two constraints represent requirements that the solution must satisfy, such as fixed volume, limited resources, or prescribed dimensions.For a function of three variables, each constraint forms a surface in three-dimensional space.