在Kuramoto-Sivashinsky方程中,一个混乱的吸引子的拓
Marie Abadie1, Pierre Beck2, Jeremy P Parker3
1Department of Mathematics, University of Luxembourg, 6, Av. de la Fonte, 4364 Esch-sur-Alzette, Luxembourg.
Chaos (Woodbury, N.Y.)
|January 10, 2025

概括
这项研究将Kuramoto-Sivashinsky部分微分方程 (PDE) 的混乱吸引子映射成三维. 缩小尺寸的技术揭示了同等的拓模板,证实了混乱动态的强有力的特征.
科学领域:
- 动态系统和混沌理论
- 计算物理 计算物理
- 非线性科学 非线性科学
背景情况:
- 伯曼-威廉姆斯定理将不稳定的周期轨道 (UPOs) 与3D系统中的吸引子拓连接起来.
- 部分微分方程 (PDEs) 中的混沌吸引器可以显示小数维小于三,尽管无限维嵌入.
- 了解混乱吸引子的拓对于描述复杂的动态系统至关重要.
研究的目的:
- 在混乱开始时调查Kuramoto-Sivashinsky PDE的混乱吸引力的拓性质.
- 应用缩小维度的技术,将吸引物映射到一个三维空间.
- 构建拓模板并推导出不稳定周期轨道 (UPO) 的符号序列.
主要方法:
- 使用正确的直角分解 (POD) 来减少维度.
- 采用自编码神经网络来实现另一个缩小维度的方法.
- 从吸引器映射出不稳定的周期轨道 (UPOs) 进入缩小的三维空间.
- 计算了UPO的连接数,以构建分支式多元组模板.
主要成果:
- 两种不同的缩小维度方法为混乱吸引器产生了同等的拓模板.
- 在这两种减少方法中,不稳定周期轨道 (UPO) 的组织被发现是相同的.
- 成功地获得了低周期UPO的一致的符号序列.
结论:
- 不同缩小方法的模板之间的一致性为维度缩小的稳定性提供了有力的证据.
- 已经实现了Kuramoto-Sivashinsky PDE的混乱吸引力的准确拓特征.
- 这项研究表明了分析PDE混乱吸引子拓学的可靠方法.
相关概念视频
 01:26
Transmission-Line Differential Equations
231
Transmission lines are essential components of electrical power systems. They are characterized by the distributed nature of resistance (R), inductance (L), and capacitance (C) per unit length. To analyze these lines, differential equations are employed to model the variations in voltage and current along the line.
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
231
 01:28
Stability
87
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
87
 01:21
Linear Approximation in Time Domain
62
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
62
 01:19
Plotting and Calibrating the Root Locus
90
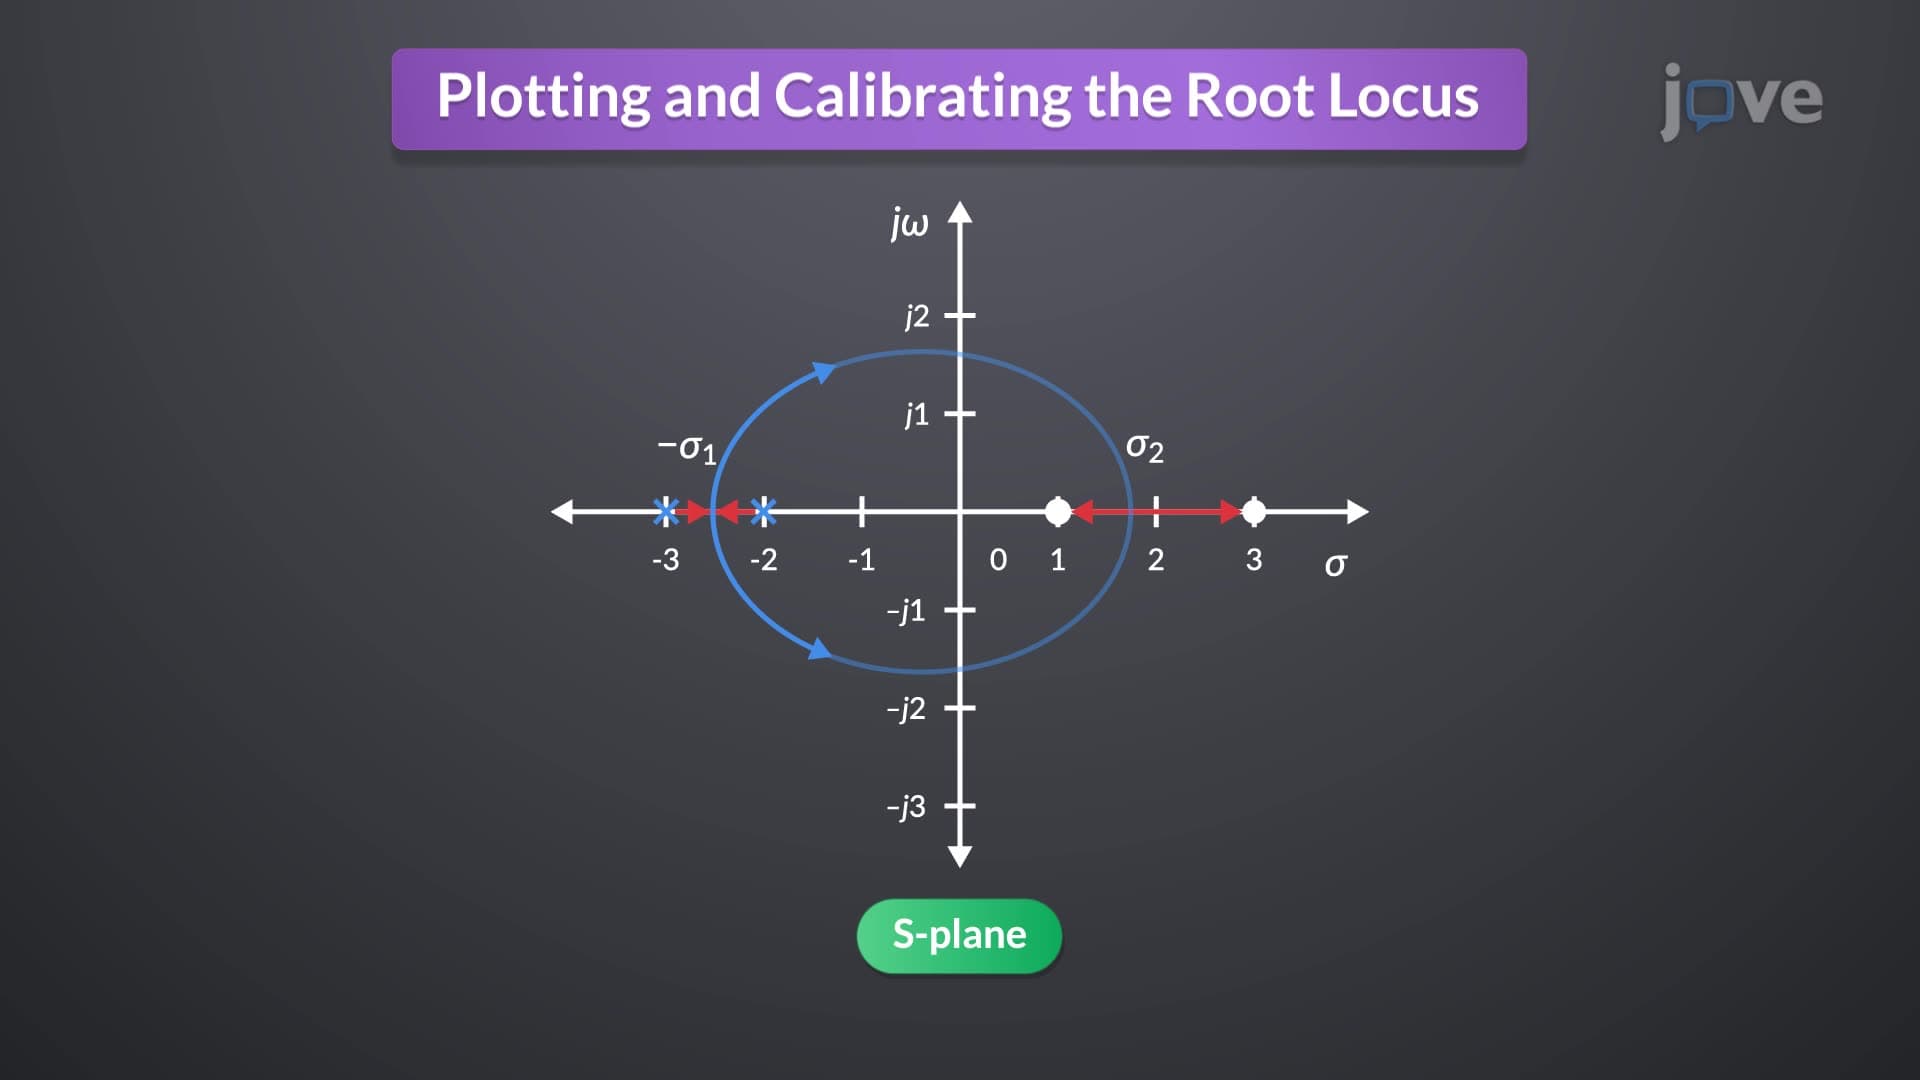
Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
90
 01:23
Stability of Equilibrium Configuration
430
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
430
 01:26
Linear Approximation in Frequency Domain
85
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
85