相关实验视频
Updated: Jun 2, 2025
08:16
Adaptation of a Haptic Robot in a 3T fMRI
Published on: October 4, 2011
9.7K
在球形机器人的视觉集体行为
Diego Castro1,2, Christophe Eloy2, Franck Ruffier1
1Aix Marseille Université, CNRS, ISM, Marseille 13288, France.
Bioinspiration & biomimetics
|January 15, 2025

概括
本研究介绍了机器人视觉集群模型,使用有限的视觉输入来实现集体运动. 循环中的机器人系统成功地复制了蜂群和磨削行为,桥梁模拟和现实世界的实验.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
- 集体行为 集体行为
背景情况:
- 传统的集体运动模型往往假定不现实的全能感知.
- 个人机器人拥有有限的传感能力,但经常被忽视.
研究的目的:
- 使用循环中的机器人方法实现视觉集群模型.
- 用最小的视觉信息在一群10个球形机器人中复制集体运动行为.
- 在机器人集体运动中弥合模拟和物理实验之间的差距.
主要方法:
- 利用来自单个机器人的全景视觉信息 (视网膜位置,光学尺寸,光学流量).
- 采用虚拟,限制机器人的运动,防止墙壁互动.
- 在一个机器人循环系统中验证了模型,比较模拟和物理实验.
主要成果:
- 通过独立的机器人成功地复制了集体运动阶段,包括蜂群和削.
- 在模拟和物理机器人循环环境中表现出几乎相同的行为.
- 展示了最小的视觉模型在重现复杂的集体行为中的有效性.
结论:
- 一种简单的视觉机器人在循环中的方法可以有效地复制集体机器人运动.
- 开发的模型弥合了模拟和物理机器人实验之间的差距.
- 在机器人系统中,最小的视觉线索足以实现复杂的集体行为.
相关概念视频
 01:23
Spherical Coordinates
9.9K
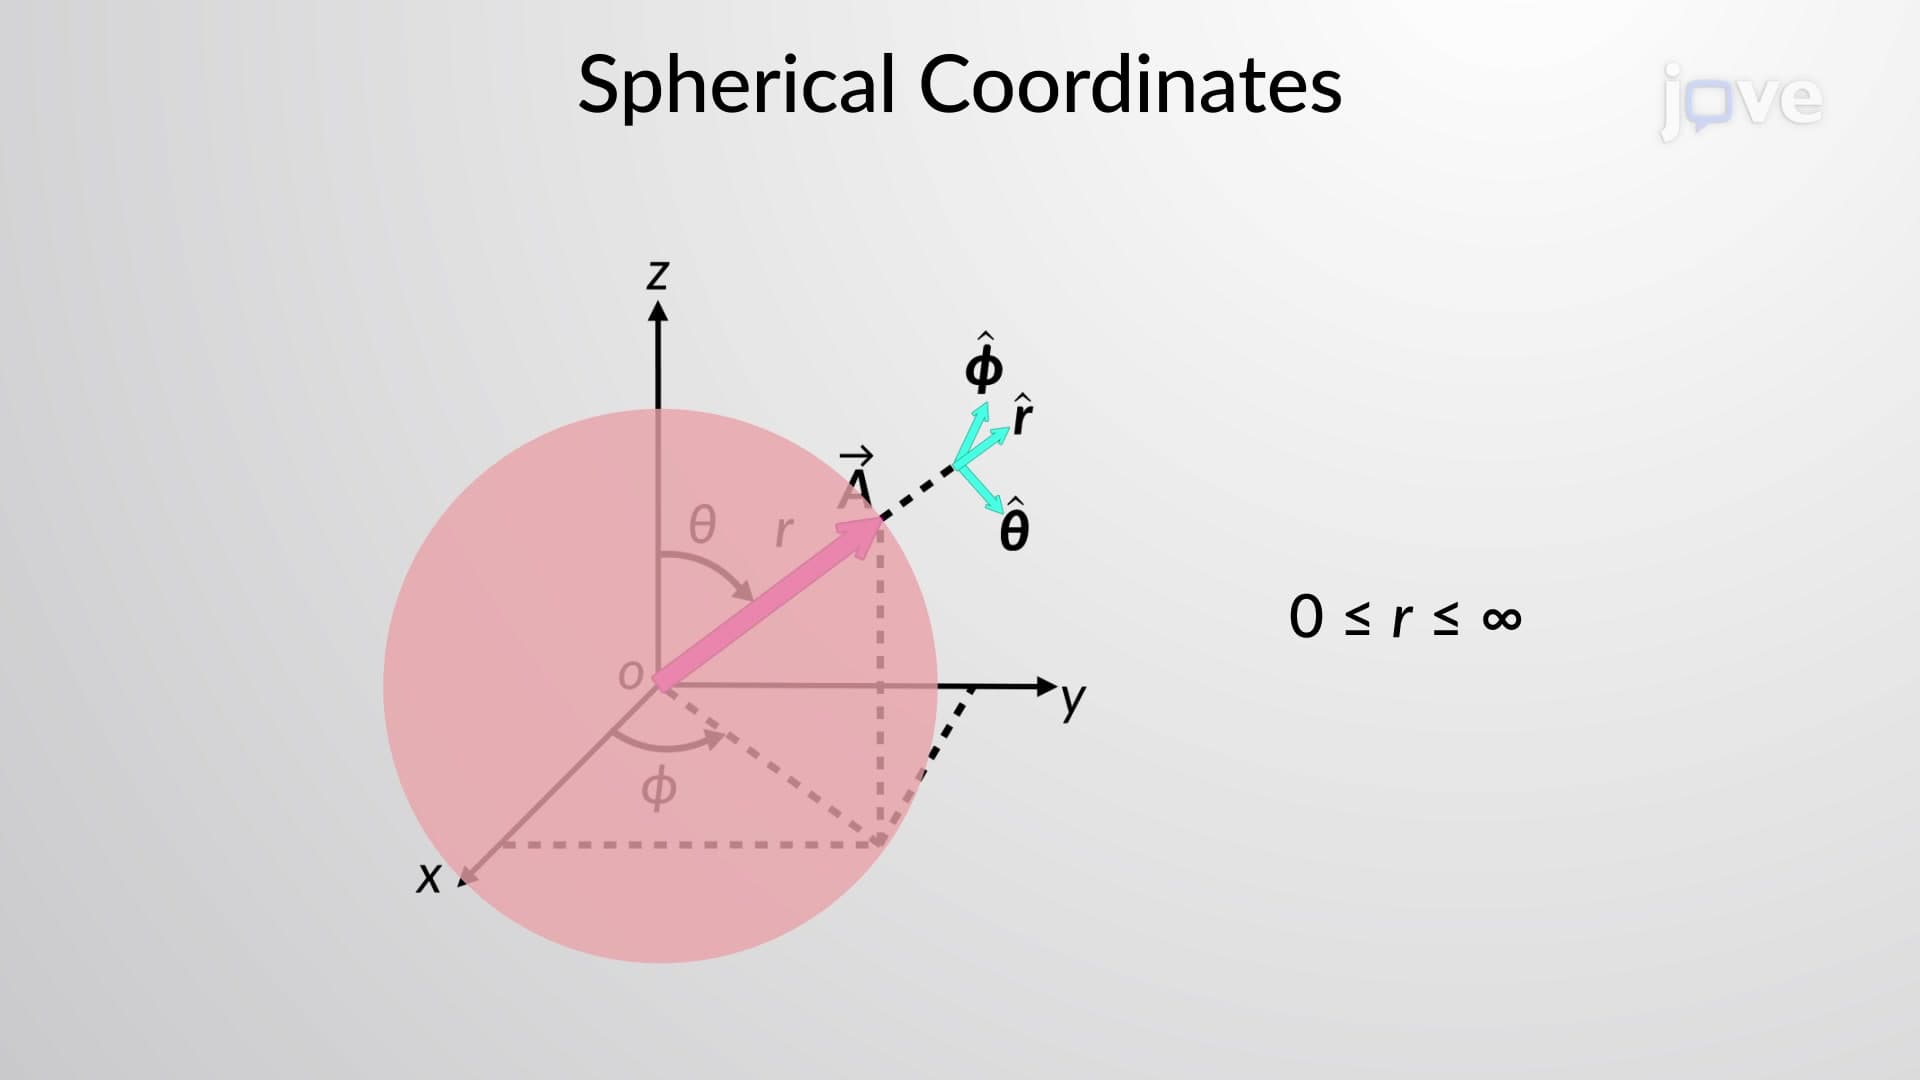
Spherical coordinate systems are preferred over Cartesian, polar, or cylindrical coordinates for systems with spherical symmetry. For example, to describe the surface of a sphere, Cartesian coordinates require all three coordinates. On the other hand, the spherical coordinate system requires only one parameter: the sphere's radius. As a result, the complicated mathematical calculations become simple. Spherical coordinates are used in science and engineering applications like electric and...
9.9K
 01:30
Three-Dimensional Force System:Problem Solving
622
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
622
 01:06
Virtual Work for a System of Connected Rigid Bodies
369
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
369
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
385
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
385
 01:34
Velocity and Position by Graphical Method
7.3K
Velocity and position can be calculated from the known function of acceleration as a function of time. The total area under the acceleration-time graph and the velocity-time graph gives the change in velocity and position, respectively. In the case of an airplane, its acceleration is tracked using the inertial navigation system. The pilot provides the input of the airplane's initial position and velocity before takeoff. The inertial navigation system then uses the acceleration data to...
7.3K
 01:03
Centroid of a Body: Problem Solving
1.1K
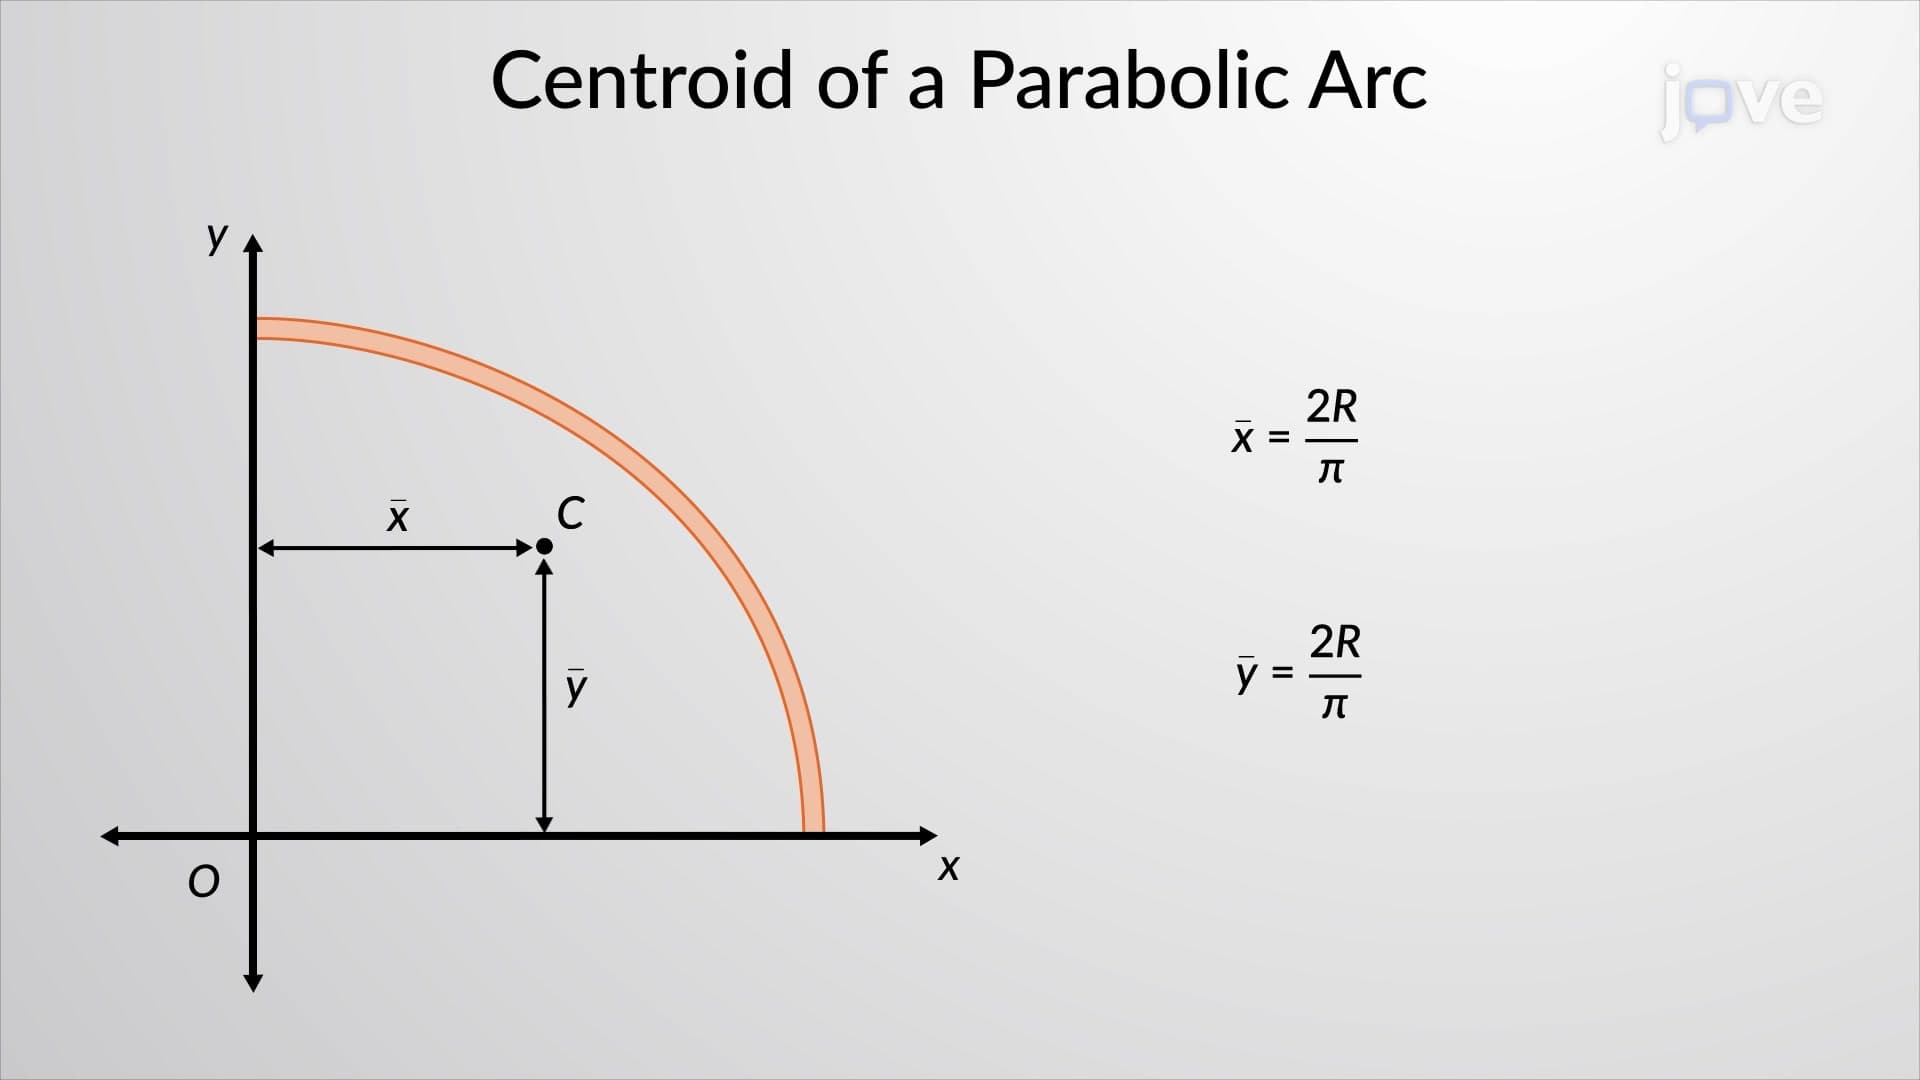
The centroid of a body is a crucial concept in engineering and physics. Finding the centroid of a body can help determine its stability, its balance point, and even its design. In this context, consider a thin wire bent in the form of a quarter circular arc. Polar coordinates are used to calculate the centroid. The wire is first divided into small differential elements of a length equal to the radius multiplied by the differential angle.
The x-coordinates and y-coordinates of each element's...
The x-coordinates and y-coordinates of each element's...
1.1K