运行动力学,动力学和肌肉激活的数据集在不同的速度,表面梯度,节奏和前方的干部倾斜时
Bas Van Hooren1, Kenneth Meijer1
1NUTRIM School of Nutrition and Translational Research in Metabolism, Maastricht University Medical Centre+, Department of Nutrition and Movement Sciences, Maastricht, the Netherlands.
Data in brief
|January 17, 2025

概括
这一数据集提供了来自19个健康个体的综合运行生物力学数据,涉及各种性能水平. 它包括在各种运行条件下详细的动力学和动力学数据,用于未来的研究和模型验证.
科学领域:
- 生物力学 生物力学
- 运动科学 运动科学 运动科学
- 人类运动分析 人类运动分析
背景情况:
- 了解跑步生物力学对于预防伤害和提高表现至关重要.
- 现有的数据集可能缺乏跨各种运行条件的全面数据.
- 跨绩效水平的健康个体提供了有价值的基线.
研究的目的:
- 为了呈现一个丰富的运行生物力学数据集.
- 促进模型验证和生物力学结果调查的研究.
- 建立一个健康年轻人的跑步生物力学参考数据库.
主要方法:
- 使用了一台带有仪器的跑步机,采用了3D运动捕捉和表面电肌图.
- 收集了来自19名健康参与者的数据 (从未训练到精英运动员).
- 在13个条件下测量了生物力学:5个速度,4个梯度,3个节奏,以及车倾斜的变化.
主要成果:
- 提供原始 (.C3D) 和处理数据 (联合角度,力等) 的数据. 在使用OpenSim 3.3.3时.
- 包括详细的3D标记位置,地面反应力和肌肉激活.
- 收集了所有参与者的标准人体统计数据 (身高,体重).
结论:
- 该数据集为运行生物力学提供了有价值的见解.
- 它可以重复用于验证肌肉骨模型.
- 在各种运行场景中作为生物力学结果的参考.
相关概念视频
 01:06
Force
26.1K
Forces affect every moment of our life. Our bodies are held to the Earth by force, and they are held together by the forces of charged particles. When we open a door, walk down a street, lift a fork, or touch a baby's face, we are applying force. Our body's atoms are held together by electrical forces, and the core of an atom, called the nucleus, is held together by the strongest force known to us—nuclear force.
The study of motion is called kinematics, but kinematics only...
The study of motion is called kinematics, but kinematics only...
26.1K
 01:10
Work and Energy for Variable Forces
4.8K
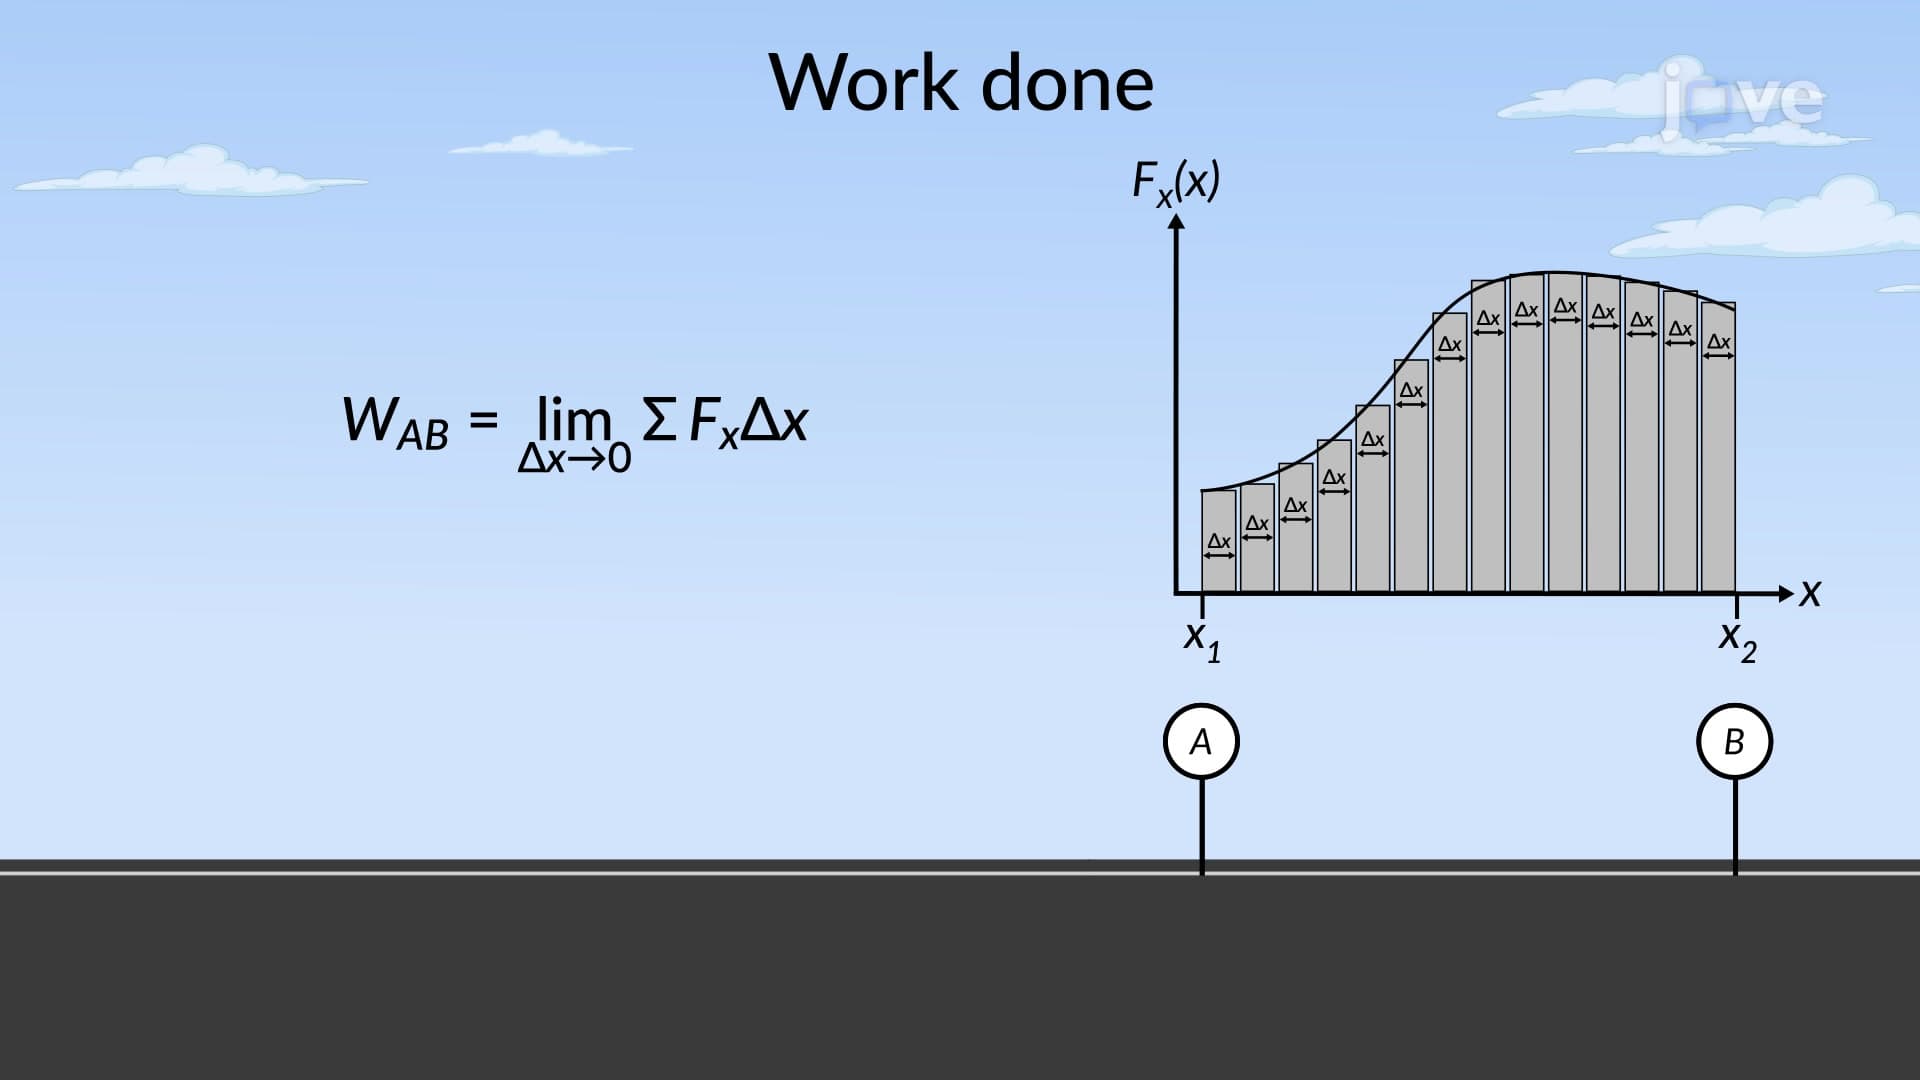
When an object is acted upon by a variable force, the amount of work done and the change in energy of the object can be more complex to calculate compared to when a constant force is applied. Work is the product of force and displacement, while energy is the capacity of a system to do work. When a constant force is applied to an object, the work done can be calculated as the product of the force and the distance moved in the direction of the force. However, when a variable force is applied, the...
4.8K
 01:24
Relative Motion Analysis - Velocity
982
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
982
 01:15
Torque Free Motion
945
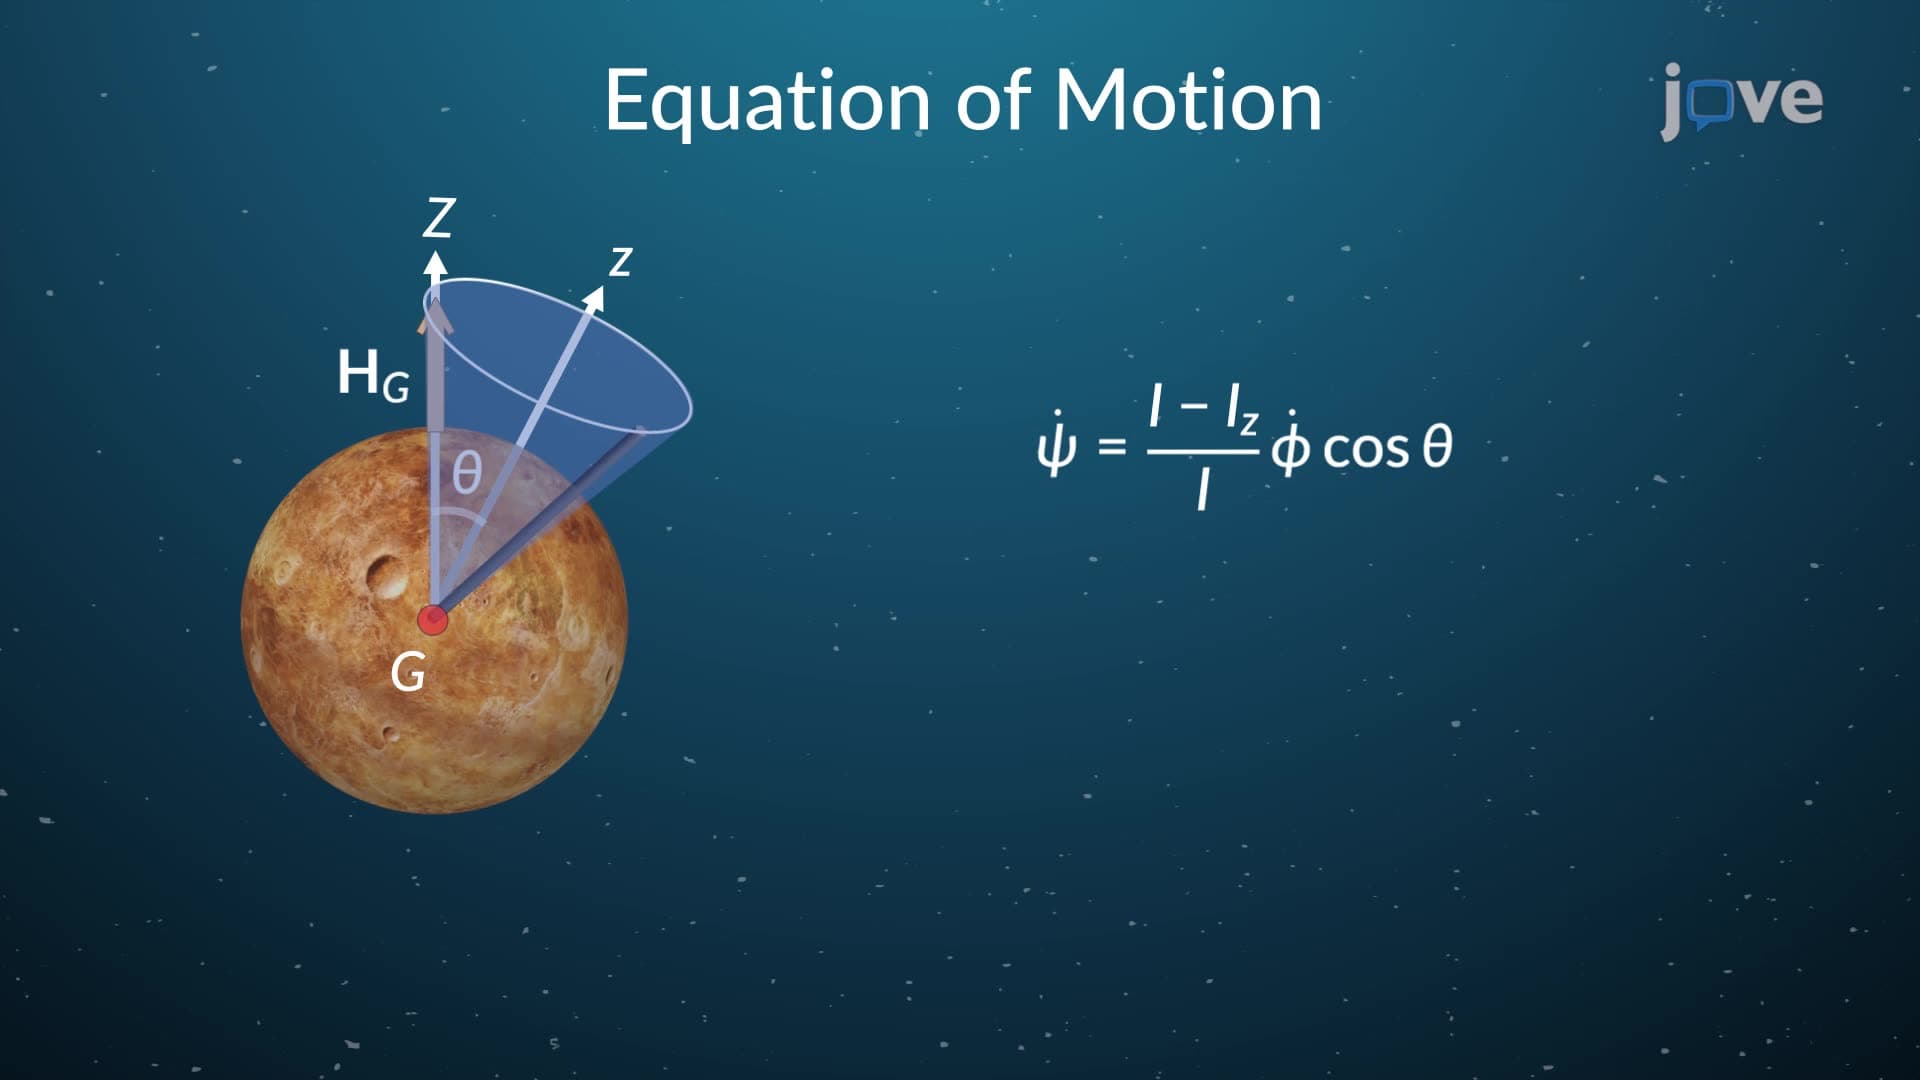
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
945
 01:10
Relative Motion Analysis - Acceleration
1.1K
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
1.1K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
1.0K
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
1.0K