
概括
本研究介绍了一种使用事件摄像头和结构化照明的新型3D测量系统. 该系统以最小的偏差实现高准确度的3D测量,为动态4D成像铺平了道路.
科学领域:
- 计算机视觉 计算机视觉
- 计量学 计量学 计量学
- 传感器技术 传感器技术
背景情况:
- 事件摄像头基于亮度变化提供稀疏,事件驱动的数据流.
- 传统的3D测量技术在动态场景中可能受到限制.
研究的目的:
- 开发和评估一个立体现象摄像系统,用于对静态物体进行精确的3D测量.
- 为了研究结构化照明对比对测量准确性的影响.
主要方法:
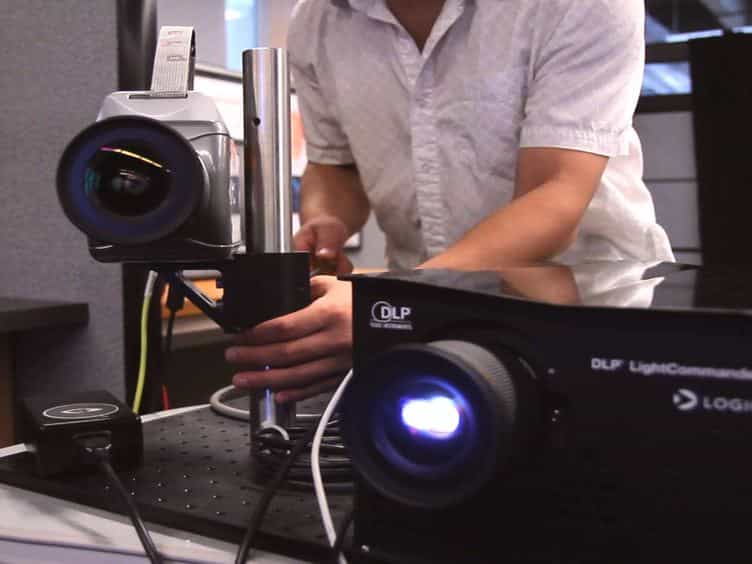
- 使用了两个事件摄像头的立体声配置.
- 集成了一个专门的投影仪用于结构化照明.
- 优化照明对比度,以增强数据捕获.
主要成果:
- 实现了对静态物体的高保真度3D测量.
- 证明的3D根-平方平均偏差低至0.6毫米 (约. 0.3%的测量体积对角).
- 证实了最佳对比对准确结果的重要性.
结论:
- 开发的事件摄像系统提供了准确的3D计量.
- 优化结构化照明对于高准确度基于事件的测量至关重要.
- 这项技术可以实现未来精确,高度动态的4D测量.
相关概念视频
 02:16
Light Acquisition
In order to produce glucose, plants need to capture sufficient light energy. Many modern plants have evolved leaves specialized for light acquisition. Leaves can be only millimeters in width or tens of meters wide, depending on the environment. Due to competition for sunlight, evolution has driven the evolution of increasingly larger leaves and taller plants, to avoid shading by their neighbors with contaminant elaboration of root architecture and mechanisms to transport water and nutrients.
 01:15
Depth Perception and Spatial Vision
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.