
数据驱动的基于物理的行人动态建模
Caspar A S Pouw1,2, Geert G M van der Vleuten1, Alessandro Corbetta1,3
1Eindhoven University of Technology, Department of Applied Physics and Science Education, 5600 MB Eindhoven, The Netherlands.
Physical review. E
|February 7, 2025

概括
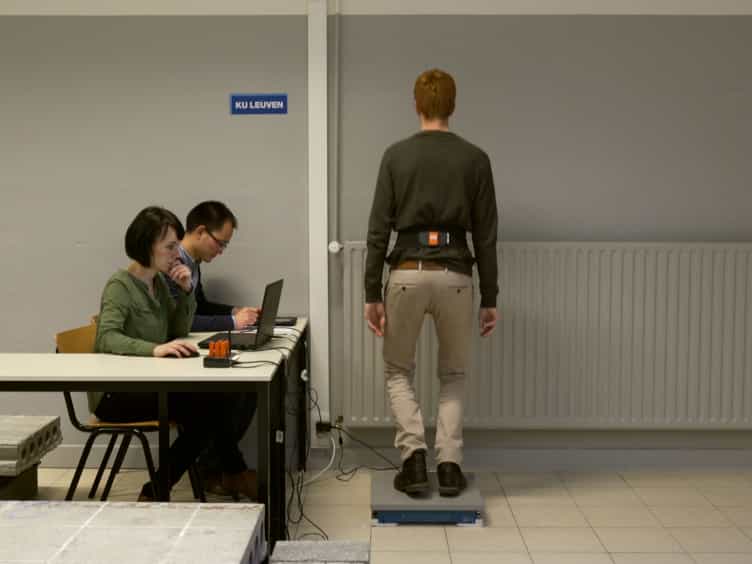
这项研究引入了一种新的两次级朗格温动力学模型,以准确模拟复杂环境中的行人运动. 该模型从真实世界的数据中学习有效的潜力,捕捉在稀疏和密集的人群中个别行人动态.
科学领域:
- 物理 物理学 物理
- 复杂的系统复杂的系统.
- 数据科学数据科学数据科学
背景情况:
- 以前使用朗格温方程的模型有效地捕捉了简单的行人动态.
- 模拟复杂的行人运动与多个路线和目的地仍然是一个挑战.
- 现有的方法在故意运动,可变性和环境相互作用的相互作用中扎.
研究的目的:
- 开发一种新的,通用的框架来描述任何几何设置中的行人动态.
- 通过结合两个时间尺度来扩展之前的工作,以实现更现实的运动模拟.
- 创建一个基于数据的模型,能够从现实世界的行人轨迹中学习复杂的潜力.
主要方法:
- 开发了一个具有快速 (随机波动) 和缓慢 (计划路径) 时间尺度的朗格温动力学模型.
- 采用数据驱动的方法,灵感来自统计领域理论,从轨迹数据中学习潜力.
- 通过使用现实行人轨迹在各种环境中的高统计数据库验证了该模型.
主要成果:
- 该模型成功地捕获了个人行人动态中的波动统计数据.
- 它准确地模拟了在稀释和密集的人群条件下行人的行为.
- 该框架在五个互补的越来越复杂的环境中表现出有效性,包括火车平台.
结论:
- 新的两次尺度朗格温模型为行人动态提供了一种通用和基于物理的方法.
- 数据驱动的方法允许学习有效的潜力,增强预测能力.
- 这个框架提供了基本的见解,并且在交通,人群管理和集体动物行为的潜在应用.

相关概念视频
 01:15
Kinematic Equations: Problem Solving
11.8K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
11.8K
 01:06
Model Approaches for Pharmacokinetic Data: Distributed Parameter Models
56
Pharmacokinetic models are mathematical constructs that represent and predict the time course of drug concentrations in the body, providing meaningful pharmacokinetic parameters. These models are categorized into compartment, physiological, and distributed parameter models.
The distributed parameter models are specifically designed to account for variations and differences in some drug classes. This model is particularly useful for assessing regional concentrations of anticancer or...
The distributed parameter models are specifically designed to account for variations and differences in some drug classes. This model is particularly useful for assessing regional concentrations of anticancer or...
56
 01:17
Kinematic Equations - II
9.3K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.3K
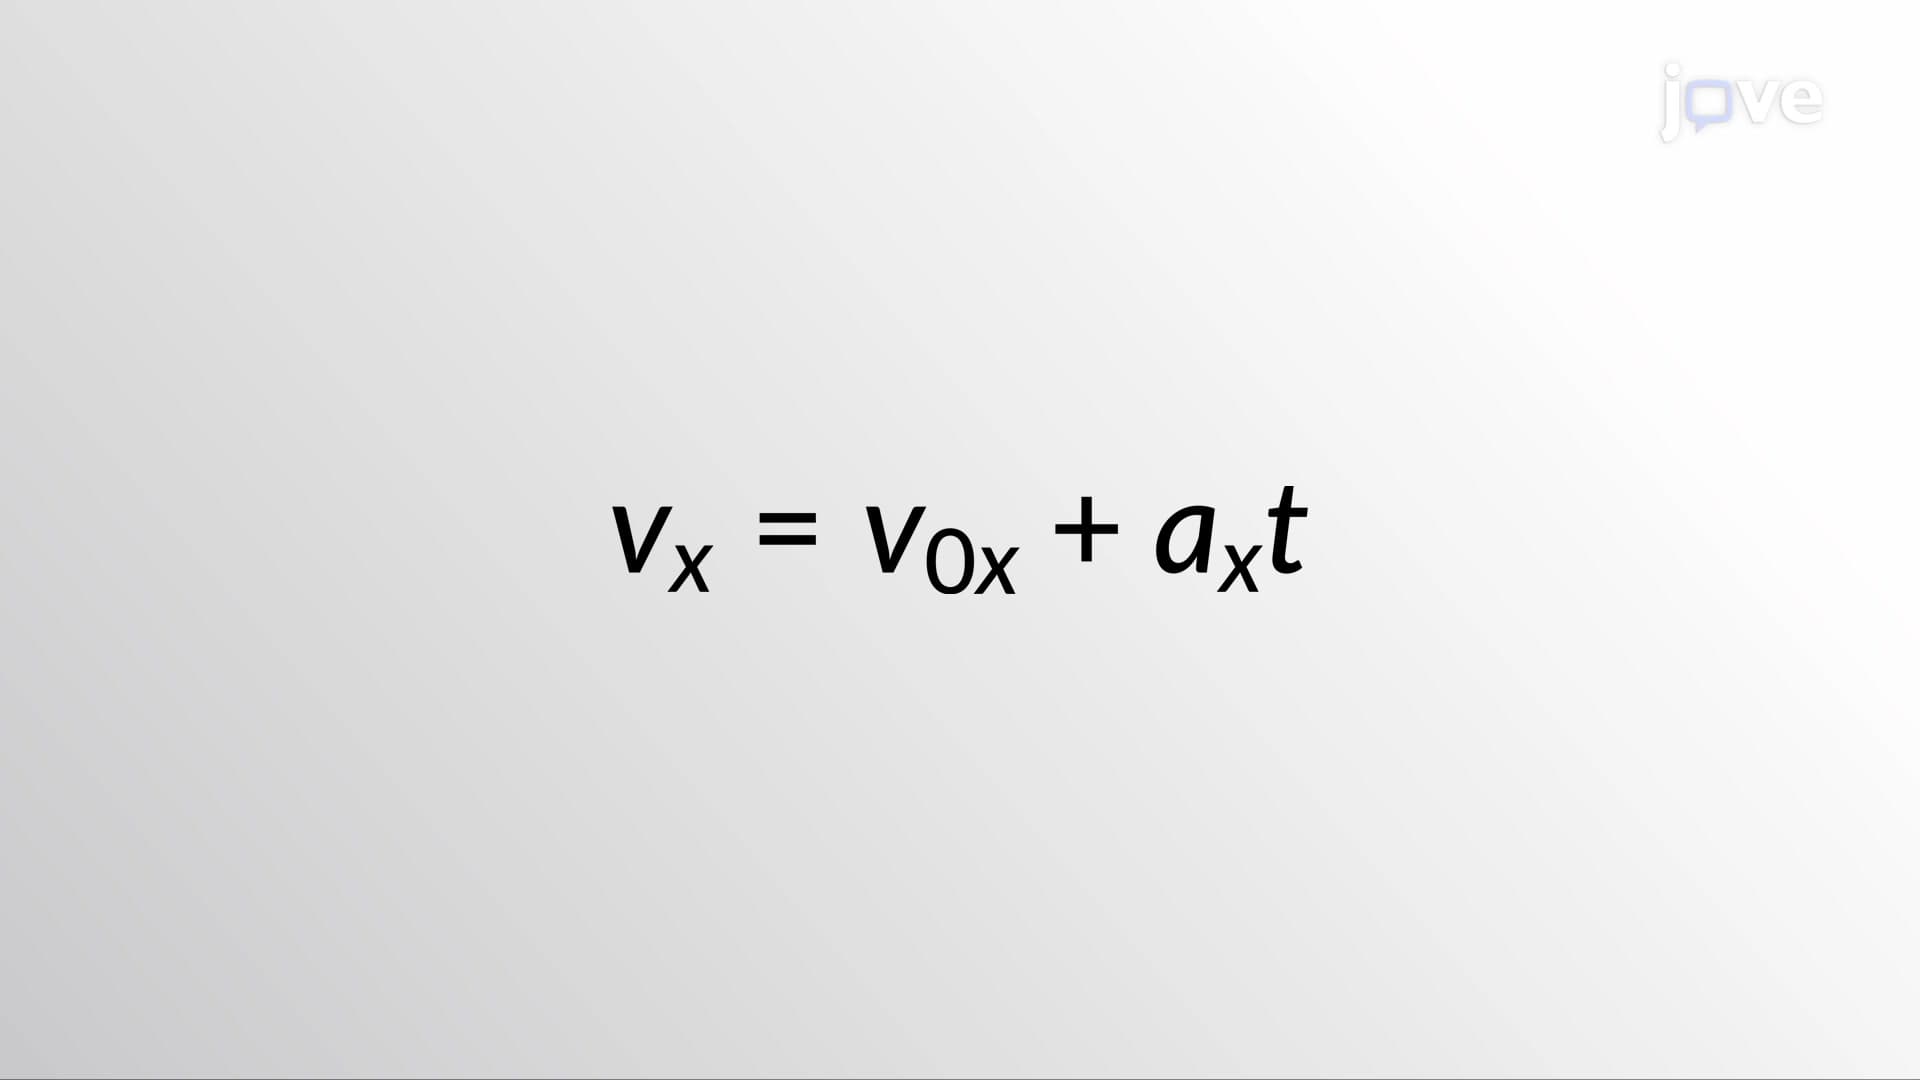 01:26
Kinematic Equations - I
10.3K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.3K
 01:18
Kinematic Equations - III
7.4K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.4K
 01:05
Static and Kinetic Frictional Force
15.6K
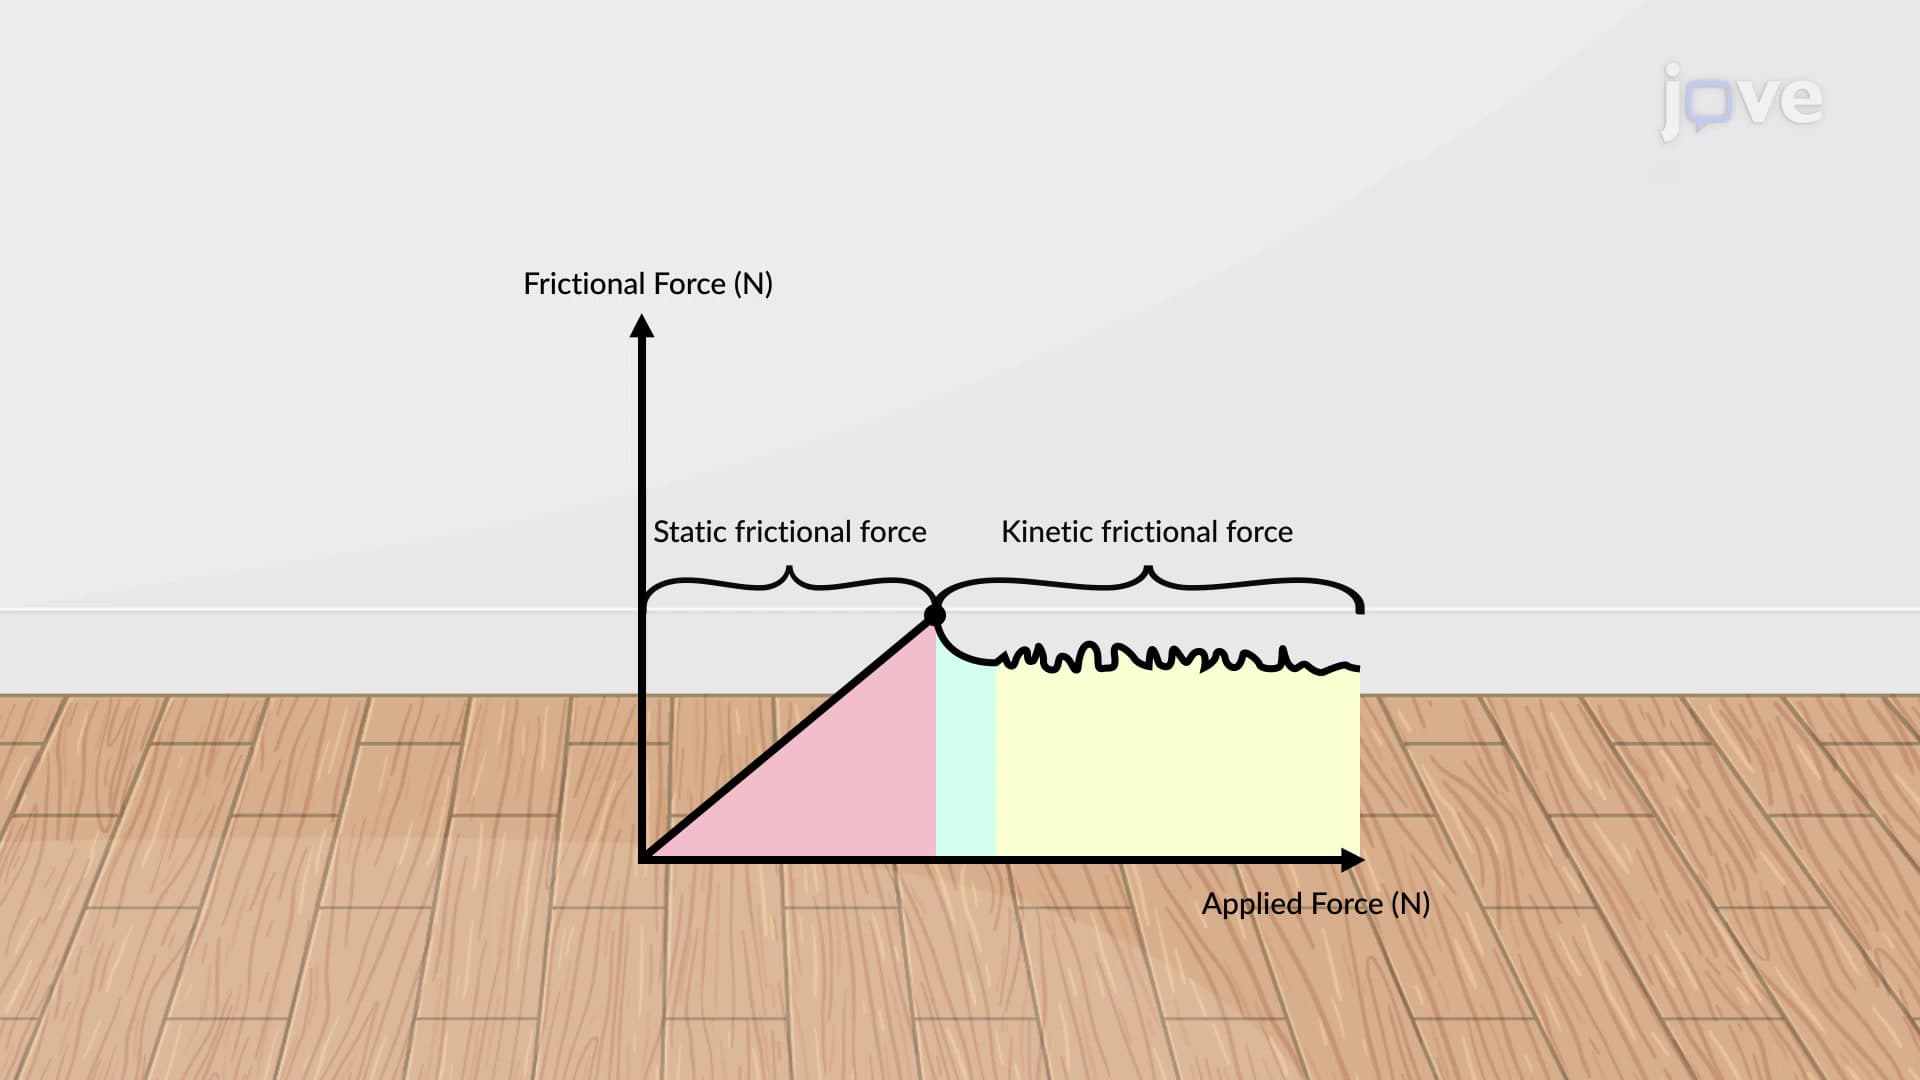
One of the simpler characteristics of sliding friction is that it is parallel to the contact surfaces between systems, and is always in a direction that opposes the motion or attempted motion of the systems relative to each other. If two systems are in contact and moving relative to one another, then the friction between them is called kinetic friction. For example, kinetic friction slows a hockey puck sliding on ice.
However, if two systems are in contact and are stationary relative to one...
However, if two systems are in contact and are stationary relative to one...
15.6K