
在基于神经驱动的肌肉骨模型的关节约束下改善运动解码性能
Lizhi Pan1,2, Xingyu Yan1,2, Shizhuo Yue1,2
1The Key Laboratory of Mechanism Theory and Equipment Design of Ministry of Education, School of Mechanical Engineering, Tianjin University, 135 Yaguan Road, Jinnan District, Tianjin, 300350, China.
Medical & biological engineering & computing
|February 11, 2025

概括
一个新的神经驱动的肌肉骨模型 (N-DMM) 通过使用高密度的EMG信号,改善了对假肢控制的运动解码. 与传统的电肌图驱动模型相比,这种模型可以更准确地估计关节位置.
科学领域:
- 生物医学工程 生物医学工程
- 神经科学是一个神经科学.
- 康复工程 康复工程 康复工程
背景情况:
- 电肌图驱动的肌肉骨模型 (E-DMMs) 将用户命令与关节位置联系起来,但面临诸如表面EMG信号交叉声等局限性.
- 高密度 (HD) EMG信号分解通过提取神经驱动器来增强人机接口提供了一个解决方案.
研究的目的:
- 提出和验证一种新的神经驱动的肌肉骨模型 (N-DMM),用于在约束条件下改进手腕和手指甲关节 (MCP) 关节位置的解码.
- 为了比较N-DMM与传统的E-DMM在估计关节运动中的性能.
主要方法:
- 从八名受试者中记录了高强度EMG信号,这些受试者在双边镜像训练中用受约束和不受约束的四肢进行了双边训练.
- 快速独立组件分析 (fICA) 用于从EMG信号中提取动力单元放电和估计神经驱动器.
- 神经驱动器作为N-DMM的输入来预测关节运动,而E-DMM用于比较.
主要成果:
- 与E-DMM相比,N-DMM在估计联合立场方面表现优越.
- 拟议的模型显示了连续运动的更准确和更强大的解码的潜力,即使在联合约束下.
结论:
- N-DMM为人机接口提供了有前途的进步,特别是在假肢应用中.
- 进一步开发N-DMM可以显著提高对截肢者的控制精度和稳定性.
相关概念视频
 01:27
Movement Joints in Buildings
103
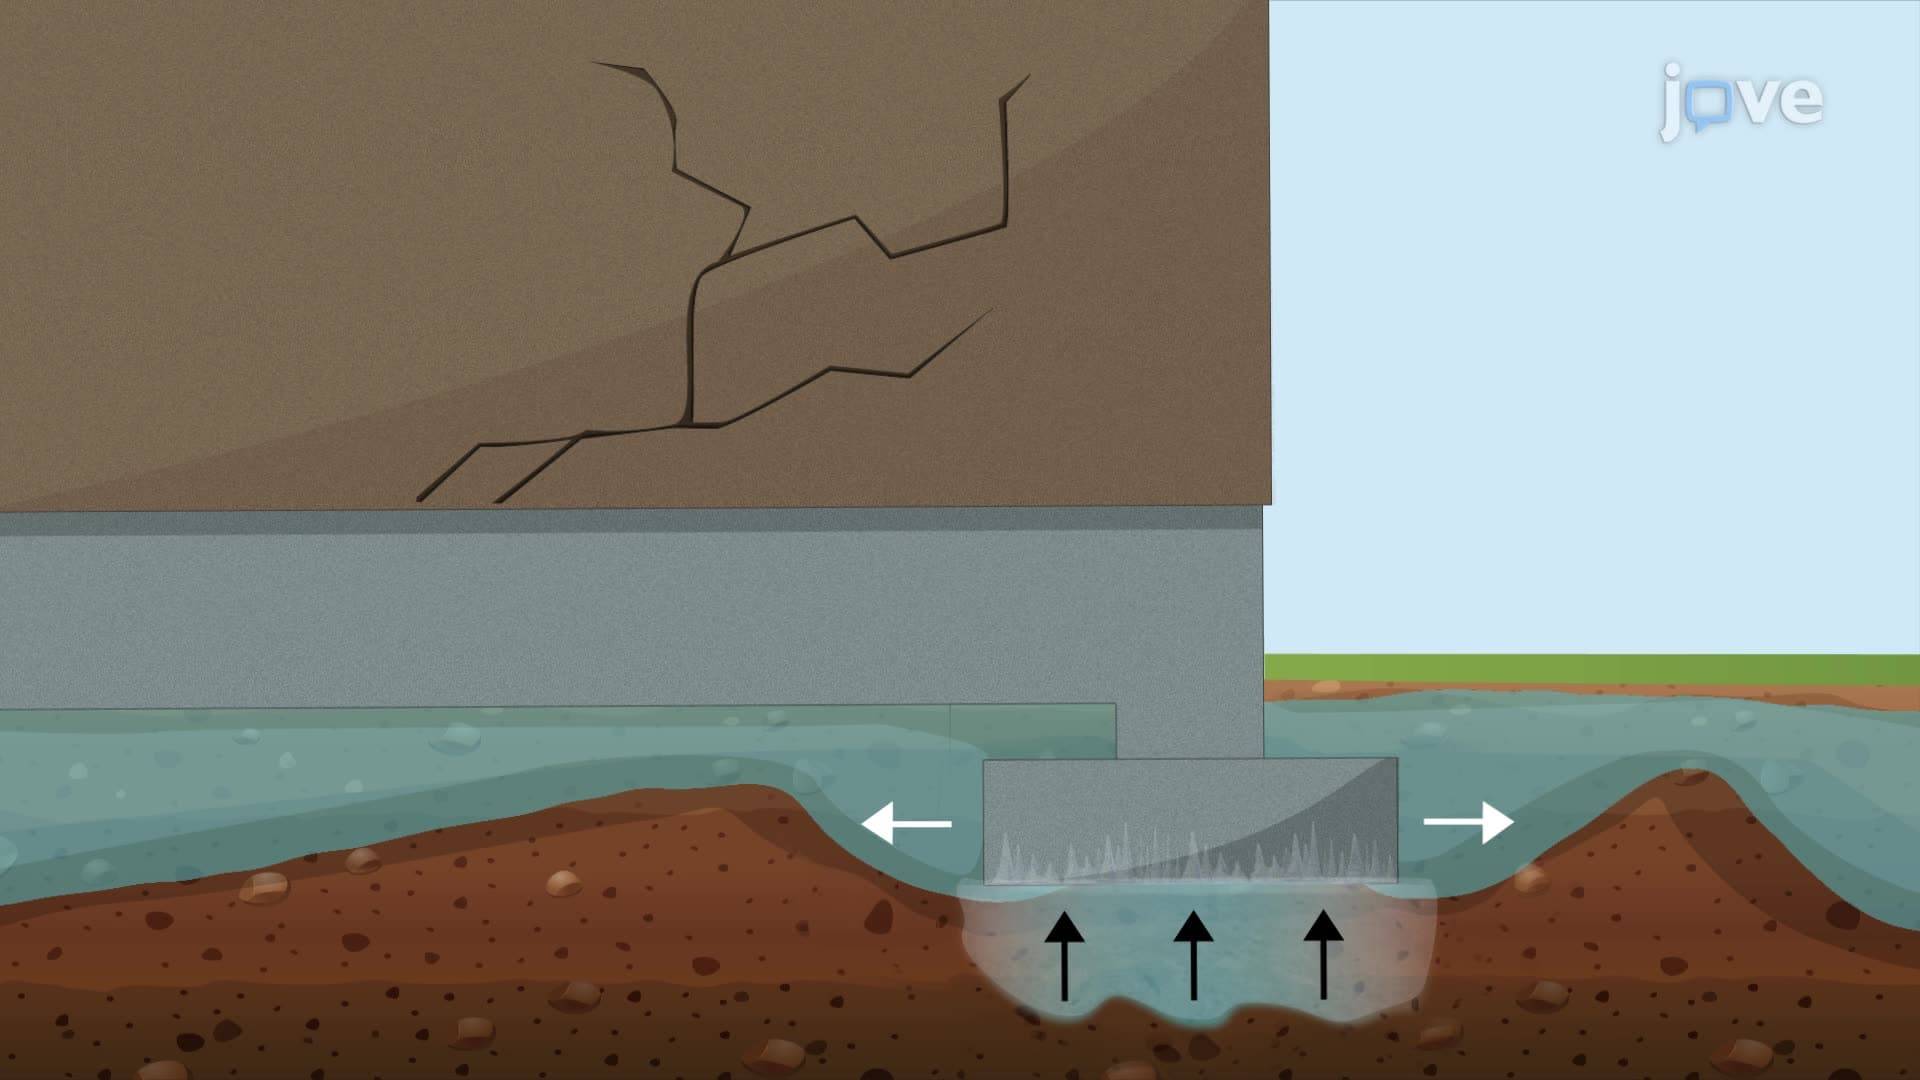
Movement joints in buildings are essential design elements that accommodate inevitable motions caused by various factors such as temperature changes, moisture content variations, and structural deflections. These motions, if not considered in design and construction, can lead to unsightly or dangerous damage. Movement joints are incorporated in different forms to manage these stresses and allow materials to move without causing distress.
The simplest type of movement joints, working joints, are...
The simplest type of movement joints, working joints, are...
103
 01:15
Kinematic Equations: Problem Solving
11.8K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
11.8K
 01:24
Muscle Coordination and Action
1.3K
Muscle coordination is a complex and finely tuned process essential for smooth and purposeful movements like flexion, extension, adduction, abduction, and rotation. The human body orchestrates the actions of various muscles working in concert, each with a specific role. Four functional types describe how muscles work together: agonist, antagonist, synergist, and fixator.
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
1.3K
 01:17
Kinematic Equations - II
9.3K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.3K
 01:18
Kinematic Equations - III
7.4K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.4K
 01:30
Method of Joints: Problem Solving II
508
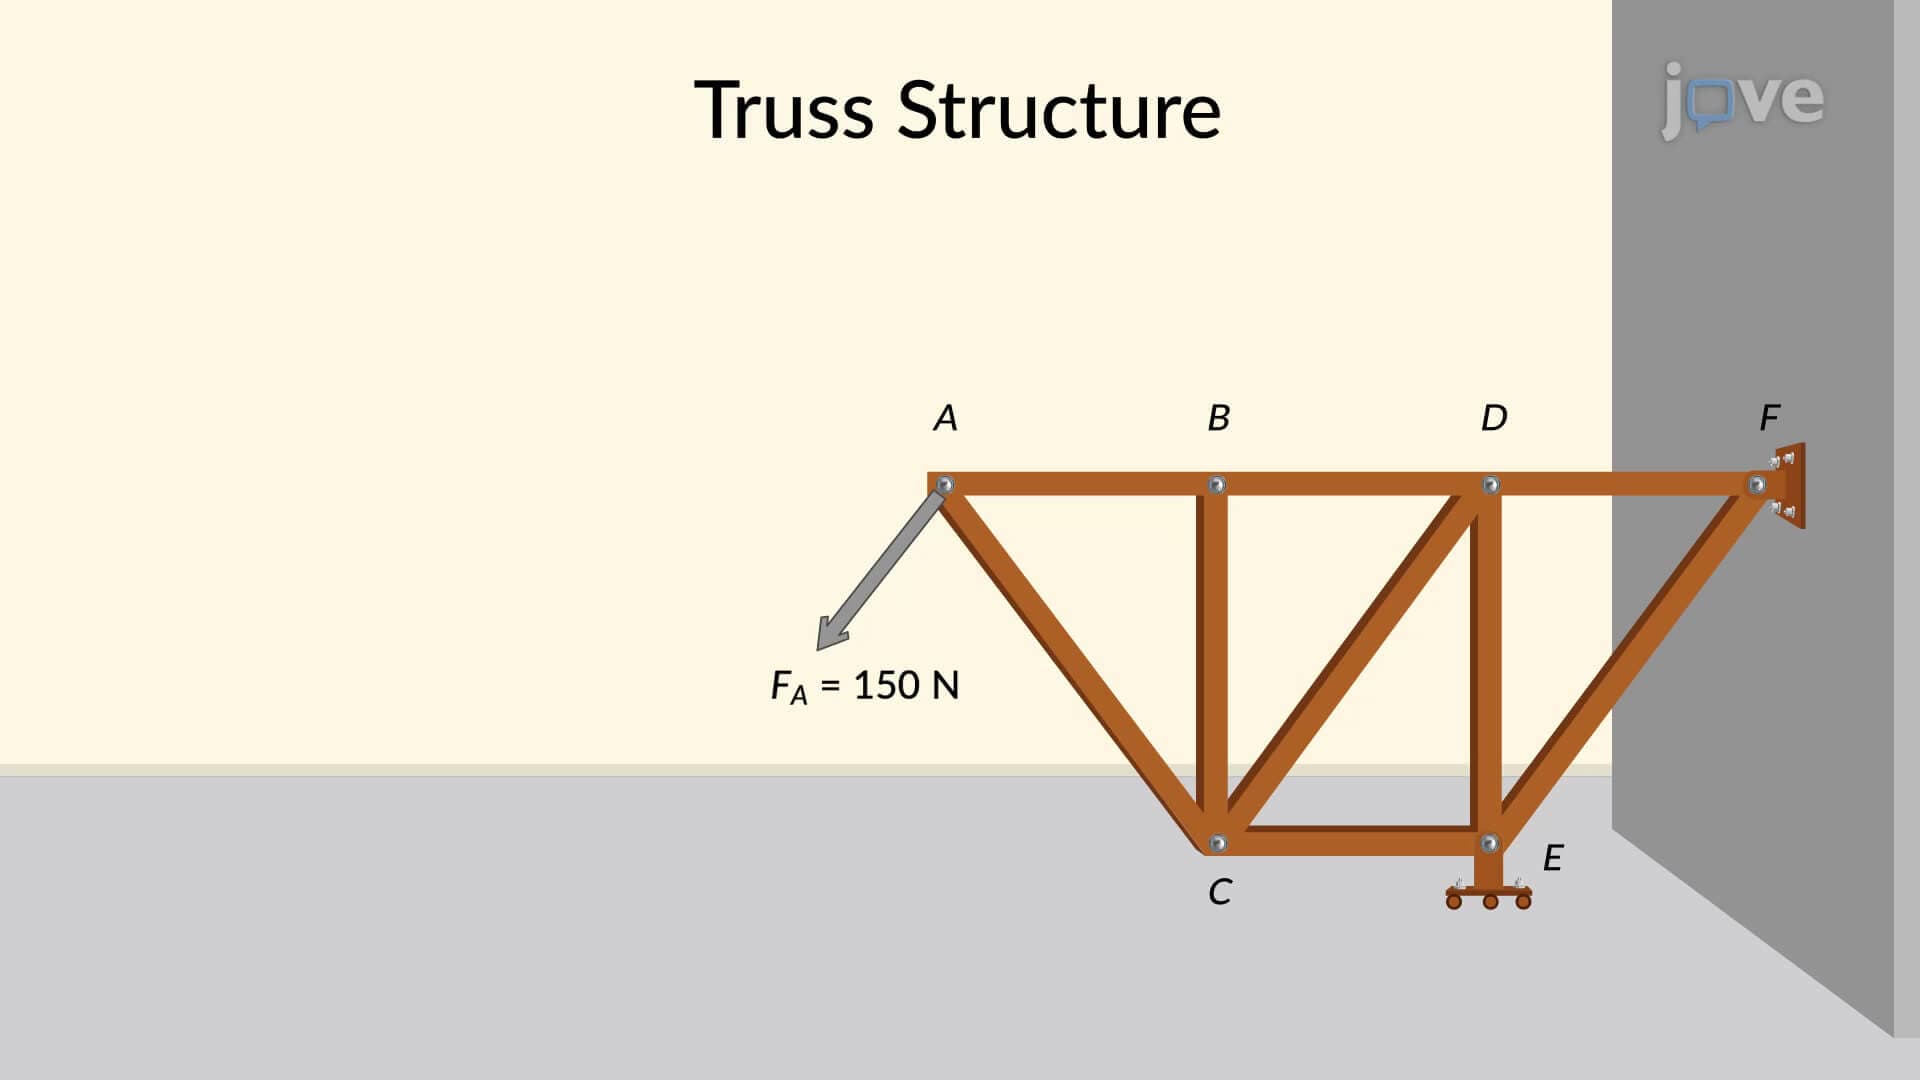
Consider a truss structure with frictionless joints fixed to a wall and roller support. If a force of 150 N is applied to joint A, the forces in each member of the truss can be determined using the method of joints.
508