

一个新的自适应非单元快速终端滑动模式控制,用于在4WID电动汽车中直接控制转时刻
Jung Eun Lee1, Byeong Woo Kim1
1Department of Electrical, Electronic and Computer Engineering, University of Ulsan, Ulsan 44610, Republic of Korea.
Sensors (Basel, Switzerland)
|February 13, 2025

概括
本研究引入了电动汽车的自适应性非单元快速终端滑动模式控制 (NFTSMC),提高了驾驶稳定性. 这种新的方法减少了控制信号波动 (聊天) 并提高了车辆在机动过程中的响应.
科学领域:
- 汽车工程 汽车工程
- 控制系统理论 控制系统理论
- 机器人技术 机器人技术 机器人技术
背景情况:
- 在四轮独立驱动 (4WID) 电动汽车中,驾驶稳定性至关重要.
- 传统的滑动模式控制 (SMC) 方法存在聊天和对不确定性的敏感性.
- 现有的非单元快速终端SMC (NFTSMC) 方法需要了解不确定性边界.
研究的目的:
- 在4WID电动汽车中开发适应性NFTSMC战略,用于4WID电动汽车的直接转时刻控制 (DYC).
- 为了提高驾驶稳定性和跟踪准确性,同时减轻喋喋不休.
- 创建一个控制法,适应系统的不确定性,而不需要事先了解它们的界限.
主要方法:
- 通过将非单元快速终端滑动模式表面与快速到达的控制规律集成,开发了一种新的自适应NFTSMC.
- 包含一个自适应开关机制,以动态调整滑动增益.
- 设计了一项具有快速影响力的法律,以实现快速融合和准确的跟踪性能.
主要成果:
- 与传统的SMC和NFTSMC相比,拟议的自适应NFTSMC显著提高了跟踪精度和驾驶稳定性.
- 显著减少了平方根平均值 (RMS) 和峰值曲折率错误.
- 有效地减轻了喋喋不休,在各种方向盘操作中提高了车辆的整体安全性和稳定性.
结论:
- 适应性NFTSMC策略提供了一个强大的和有效的解决方案,以提高4WID电动汽车的驾驶稳定性.
- 控制收益的实时调整减少了喋喋不休,并提高了性能,而不需要不确定性限制.
- 这种先进的控制方法代表了车辆动力控制和安全系统的重大进步.


相关概念视频
 01:26
Feedback control systems
275
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
275
 01:26
PD Controller: Design
171
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
171
 01:17
Open and closed-loop control systems
622
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
622
 01:13
Linear Momentum in Control Volume
702
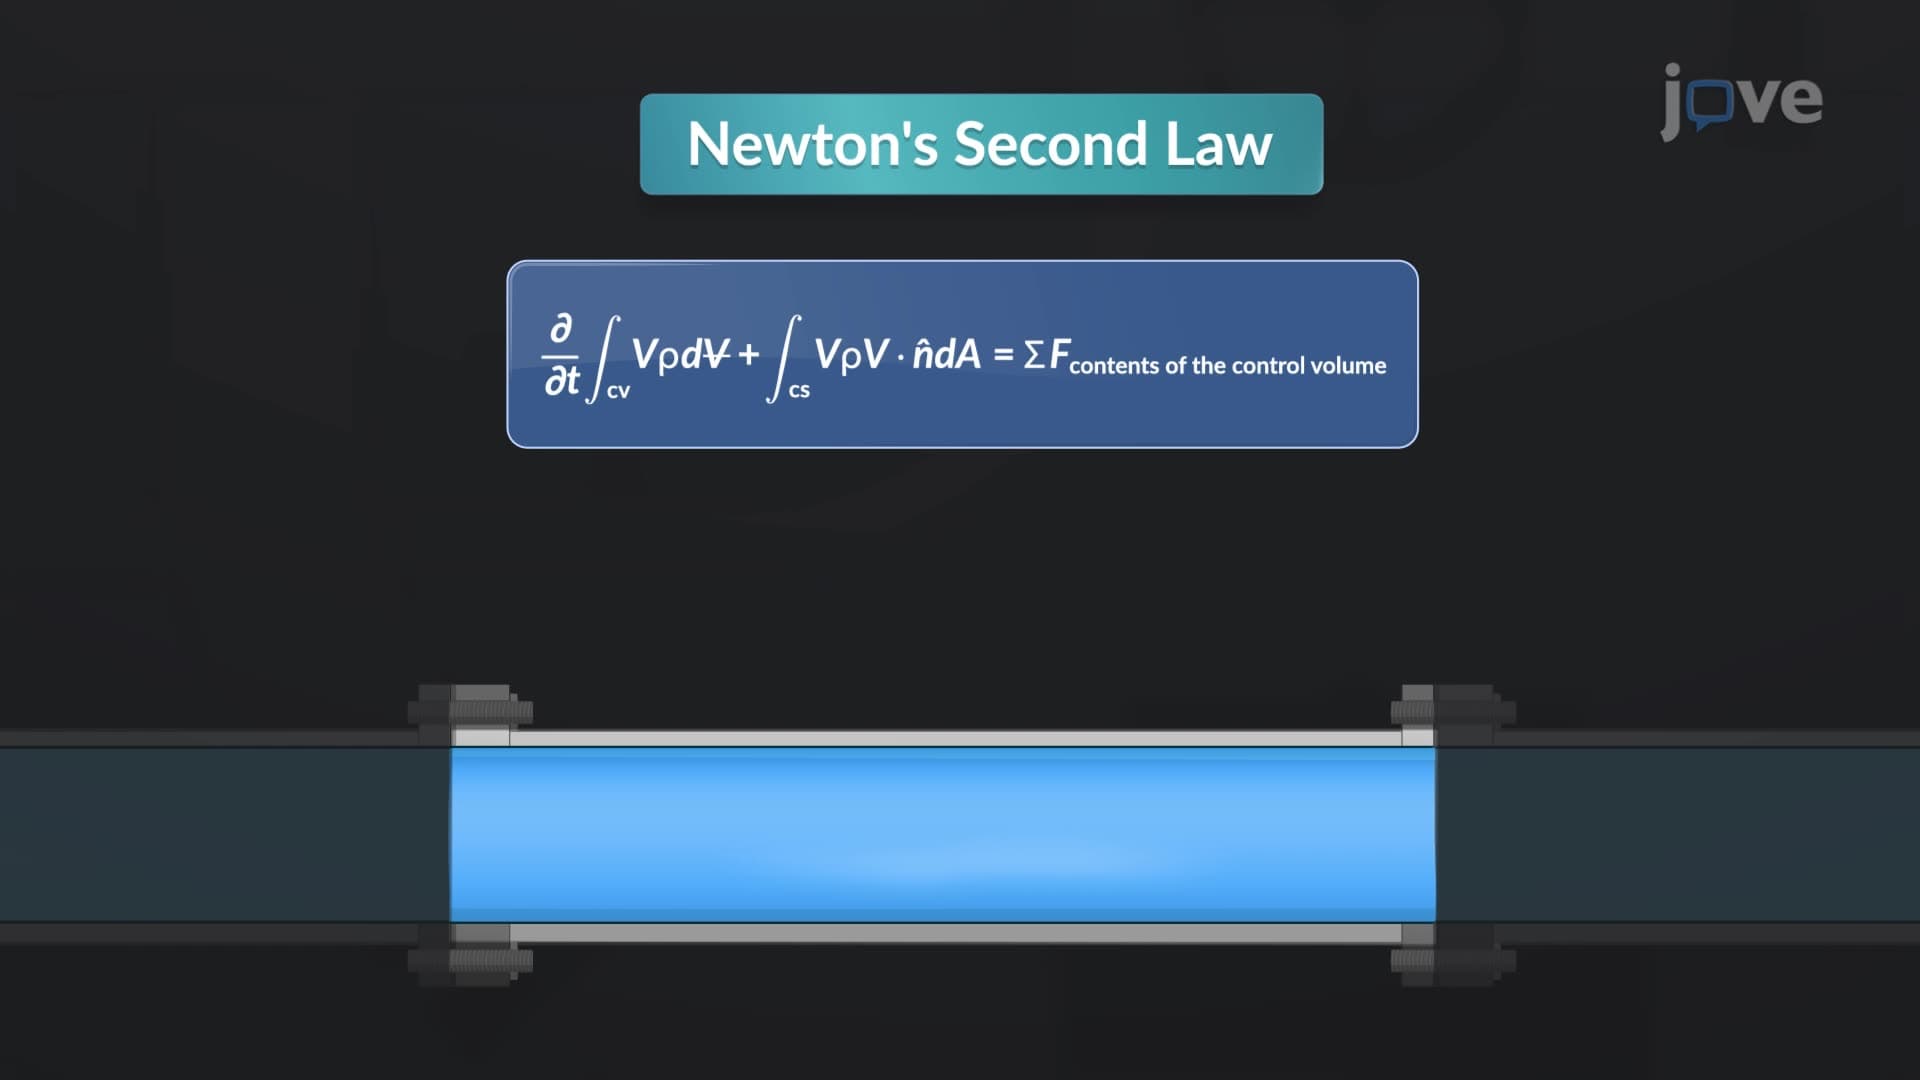
Newton's second law is applied to obtain the linear momentum in a control volume in a fluid system. According to this law, the rate of change of linear momentum is equal to the sum of external forces acting on the system. When a control volume matches the fluid system at a specific moment, the forces acting on both are identical. Reynolds transport theorem helps explain this by breaking down the system's linear momentum into two components: the rate of change of linear momentum within...
702
 01:07
Time-Domain Interpretation of PD Control
79
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
79
 01:19
PID Controller
93
Proportional-Integral-Derivative (PID) controllers are widely used in various control systems to enhance stability and performance. In a thermostat, it adjusts heating or cooling based on the temperature difference between the actual and desired levels. They are often used in automotive speed systems, effectively managing sudden speed changes while maintaining a constant speed under varying conditions. On the other hand, PI controllers, commonly employed in voltage regulation, enhance stability...
93