
泰拳道干预对平衡能力的影响:元分析和系统审查
1School of Physical Education, Guangdong University of Education, Guangzhou, China.
PloS one
|February 13, 2025

概括
泰拳道训练显著改善静态和动态平衡,特别是在成年女性中. 一个最佳的方案包括12周的训练,每周一次60-70分钟,以最大限度地提高效益.
科学领域:
- 运动科学 运动科学 运动科学
- 运动学 运动学
- 康复 康复 康复 康复
背景情况:
- 平衡对于日常活动和预防伤害至关重要.
- 泰拳道是一种武术,涉及复杂的运动,可以提高平衡.
- 关于泰拳道对平衡的影响的现有研究需要综合.
研究的目的:
- 系统地审查和元分析泰拳道干预措施对平衡的影响.
- 为了确定一个最佳的泰拳道训练方案,以改善平衡.
主要方法:
- 在多个数据库 (CNKI,WANFANG DATA,科学网,PubMed,KISS,RISS,DBPIA) 进行系统的文献搜索.
- 包括21项研究 (972名参与者),包括RCT,前后和横截面设计.
- 使用Cochrane RoB 2.0和MINORS标准进行偏差风险和方法质量评估.
- 静态和动态平衡指标的定量分析 (例如,单腿姿势,在位行进).
主要成果:
- 泰拳道干预显著改善了静态 (ES = 0.862) 和动态 (ES = 0.296) 的平衡.
- 在成年女性中观察到的最大益处是静态平衡.
- 最佳干预:12周,每周一次,每次60-70分钟.
结论:
- 泰拳道是一种有效的干预措施,可以增强静态和动态平衡.
- 成年女性在泰拳道的静态平衡方面表现出显著的改善.
- 建议进行12周的计划,每周一次,每次60-70分钟,以获得最佳的静态平衡增强.

相关概念视频
 01:21
Rigid Body Equilibrium Problems - II
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:16
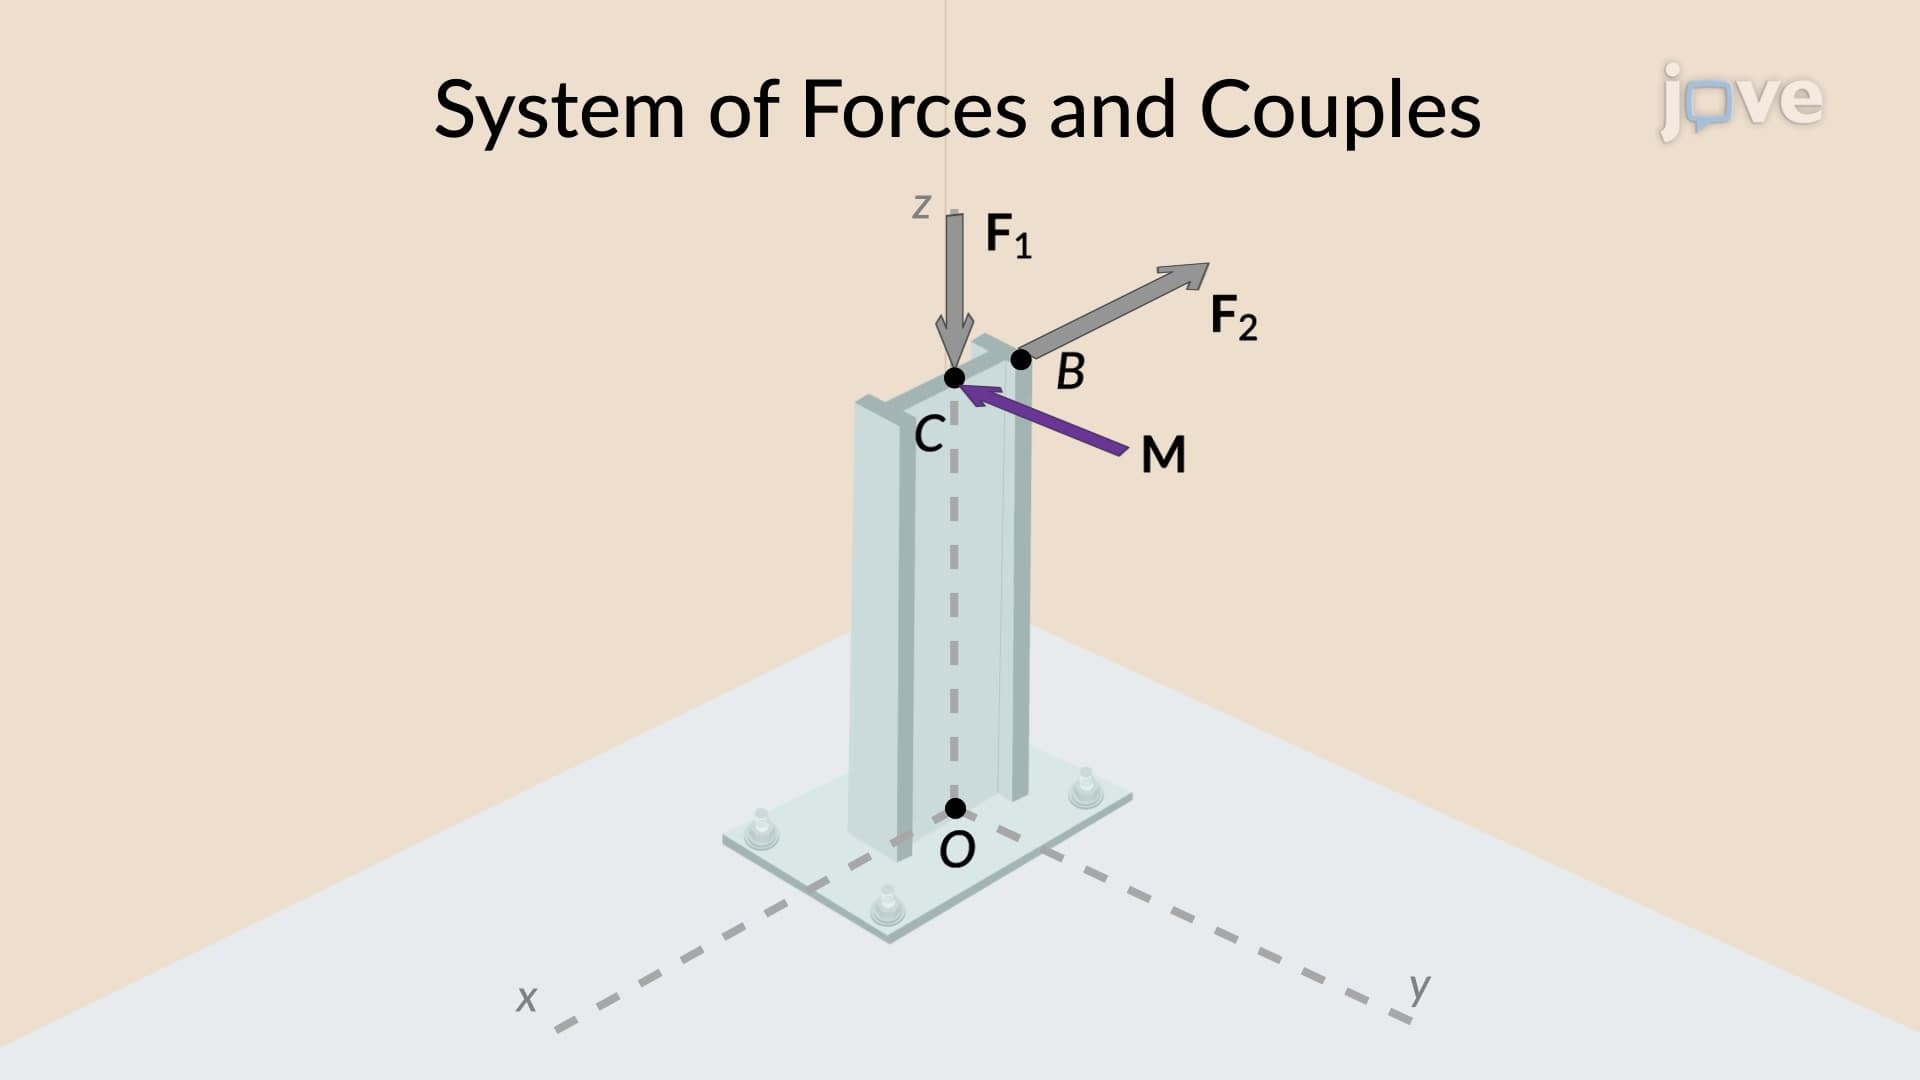
System of Forces and Couples
In the analysis of structural systems, it is common to encounter members subjected to various forces and couple moments. Simplifying these systems can make the analysis more manageable and easier to understand. One approach to achieve this simplification is by moving a force to a point O that does not lie on its line of action and adding a couple with a moment equal to the moment of the force about point O.
The principle of transmissibility plays a crucial role in this process. According to...
The principle of transmissibility plays a crucial role in this process. According to...
 01:27
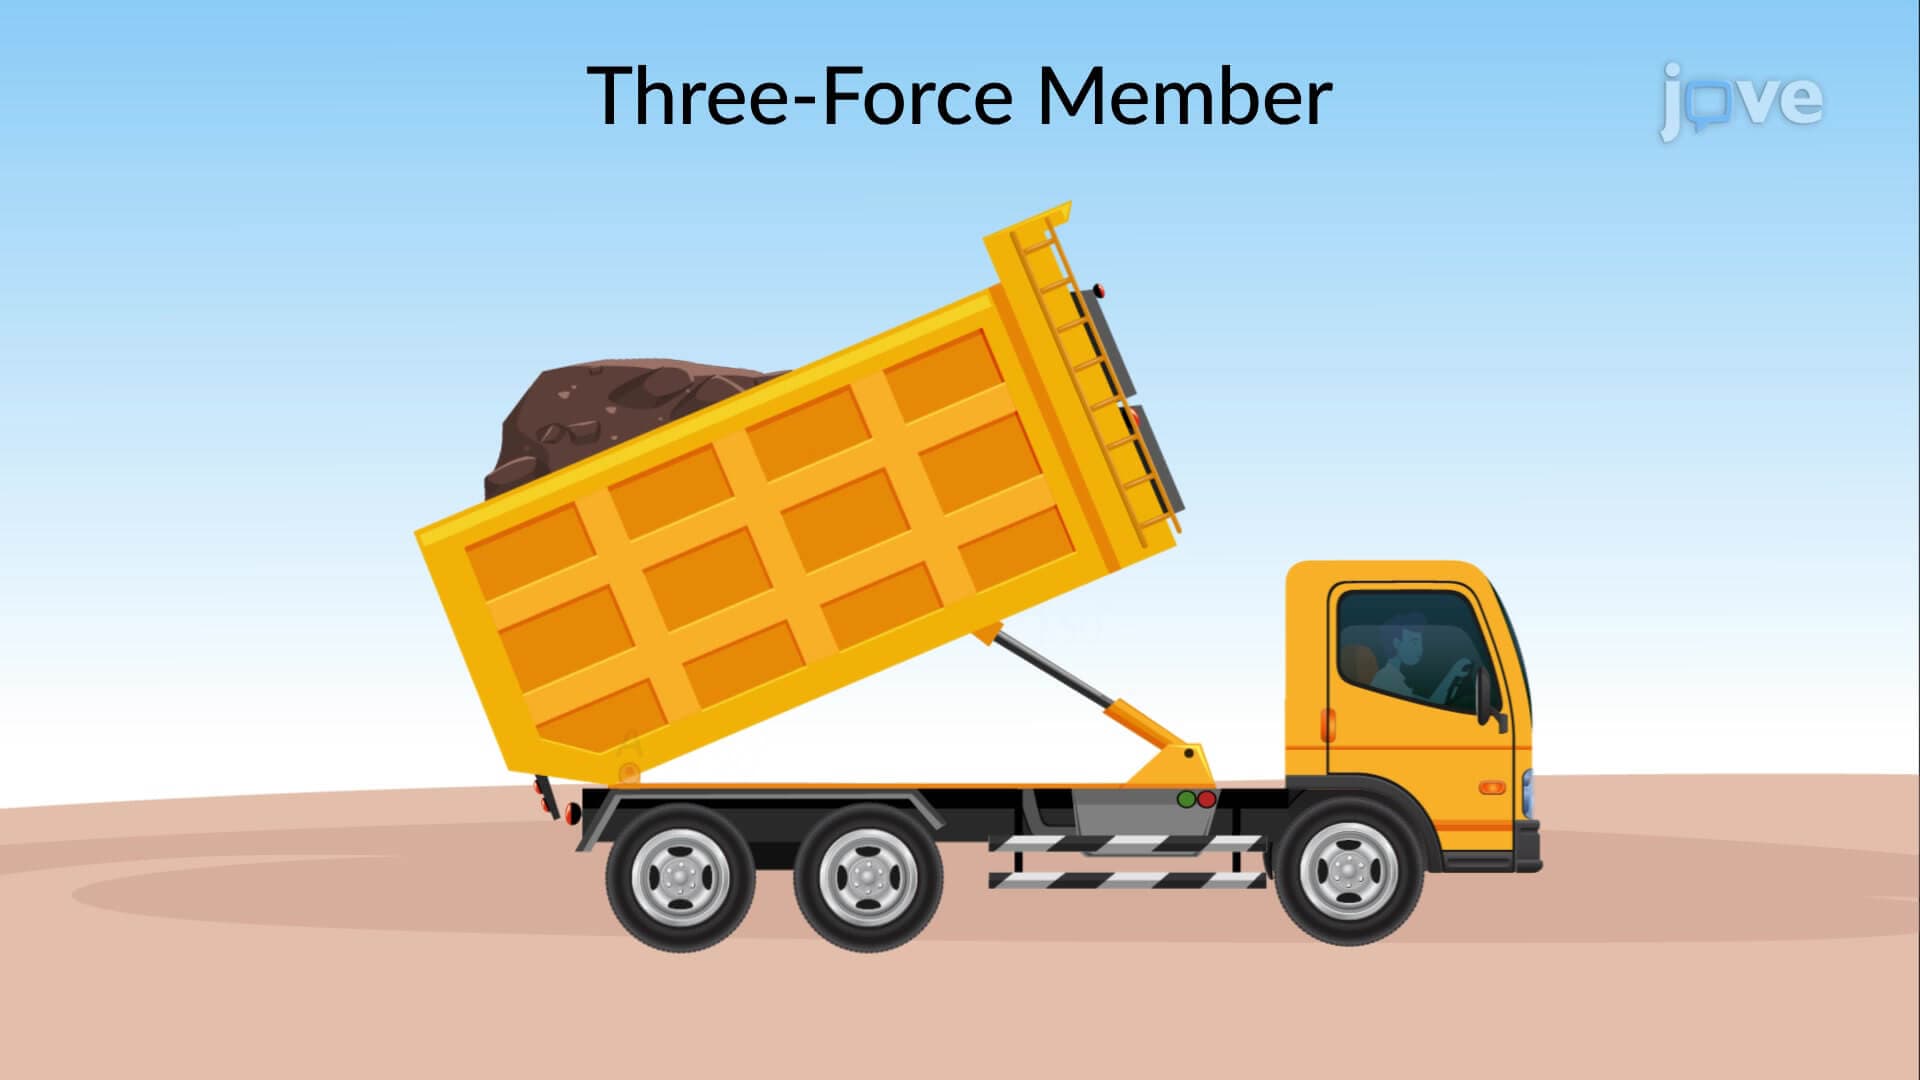
Three Force Member
A rigid body subjected to three forces acting at three points is known as a three-force member. These forces must have concurrent lines of action, except for parallel forces, where the lines of action are parallel.
For example, consider a dumpster connected to a pin support at point A and a pin attached to a hydraulic cylinder at point B.
For example, consider a dumpster connected to a pin support at point A and a pin attached to a hydraulic cylinder at point B.
 01:24
Pole and System Stability
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:07
Time-Domain Interpretation of PD Control
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
 01:30
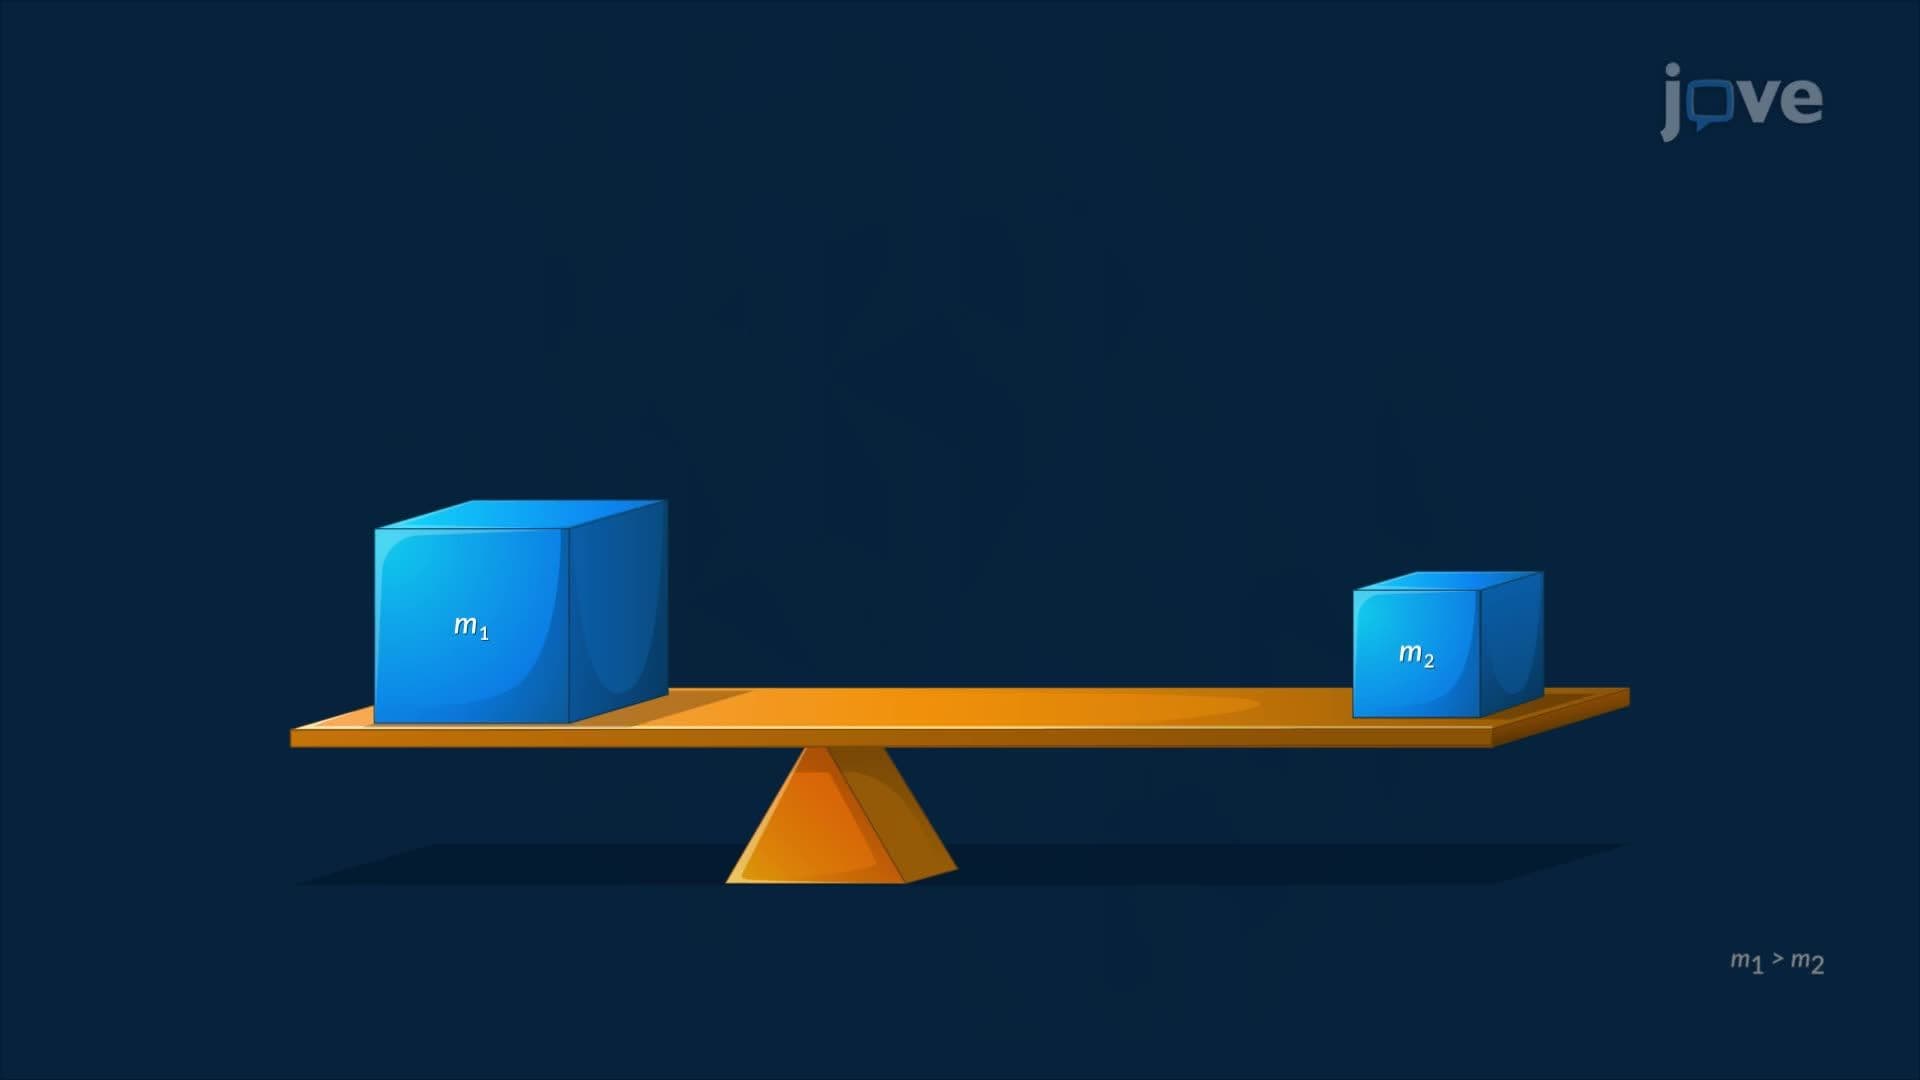
Applications of Integration to Find Centers of Mass
Rotational equilibrium provides a natural framework for defining the center of mass of a system. For a plank balanced on a pivot with two unequal masses, equilibrium is achieved when the net torque about the pivot is zero. Torque is defined as the product of a force and its perpendicular distance from the pivot. When the torques due to all forces cancel, the pivot coincides with the center of mass of the system.For a system composed of several discrete point masses, the center of mass lies at...