相关实验视频
Updated: May 28, 2025
10:41
Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
17.5K
基于外部扭矩估计的双边远程操作系统的P+减压控制
Baorui Jing1, Jing Na1, Hao Duan1
1Faculty of Mechanical & Electrical Engineering, Kunming University of Science & Technology, Kunming, 650500, China; Yunnan Key Laboratory of Intelligent Control and Application, Kunming University of Science & Technology, Kunming, 650500, China.
ISA transactions
|February 13, 2025

概括
本研究引入了双边远程操作系统的新控制方法,尽管时间延迟,但提高了运动同步和透明度. 它还推出了一种创新的扭矩估计器,可以降低硬件成本和传感器需求.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统工程 控制系统工程
- 机械电子学是什么意思 机械电子学
背景情况:
- 双边远程操作系统容易出现时间延迟,从而降低性能.
- 精确的扭矩传感对于远程操作至关重要,但增加了硬件复杂性和成本.
- 现有的控制方法在时间延迟的情况下努力保持同步和透明度.
研究的目的:
- 为双边远程操作系统制定强有力的控制策略,以减轻时间延迟的影响.
- 引入一种新的,具有成本效益的扭矩估计器,可以避免直接测量扭矩.
- 为了增强运动同步,位置/速度跟踪和接触任务期间的透明度.
主要方法:
- 实施了P + Damping控制策略与重力补偿相结合.
- 开发了一个基于未知系统动力学估计器 (USDE) 的扭矩估计器,以估计没有加速度测量的外部扭矩.
- 基于USDE的估计器与P + Damping控制器集成.
主要成果:
- 拟议的控制方法有效地解决了双边远程操作中的时间延迟问题.
- 基于USDE的扭矩估计器准确地以最小的调整估计外部扭矩.
- 模拟和实验验证了系统的提高透明度,同步性和稳定性.
结论:
- 集成的P + Damping控制和基于USDE的扭矩估计为双边远程操作提供了强大的解决方案.
- 这种方法提高了系统性能,降低了硬件成本,并简化了传感器要求.
- 这种方法对于涉及接触和时间延迟的远程操作任务是有效的.


相关概念视频
 01:07
Time-Domain Interpretation of PD Control
79
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
79
 01:26
PD Controller: Design
171
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
171
 01:20
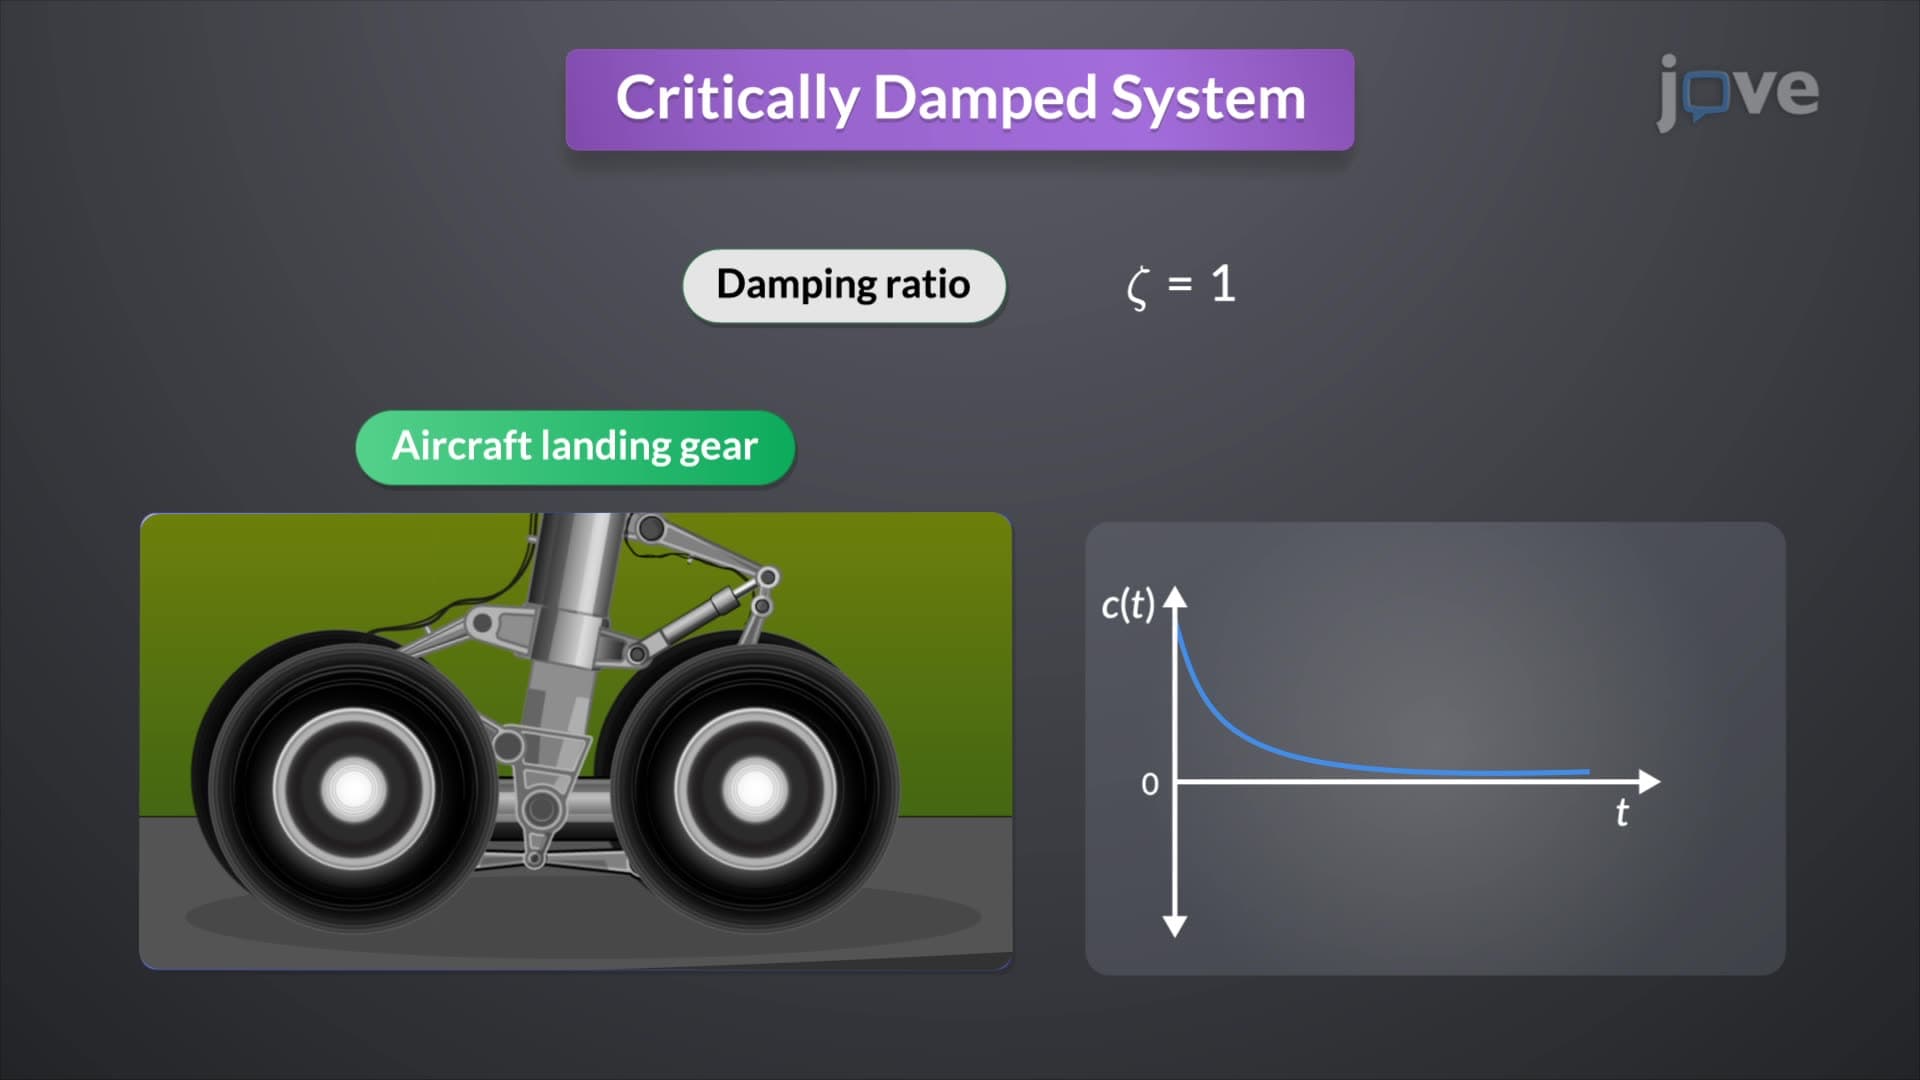
Second Order systems I
129
A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...
By reinterpreting the system, one can derive the closed-loop transfer function, which...
129
 01:19
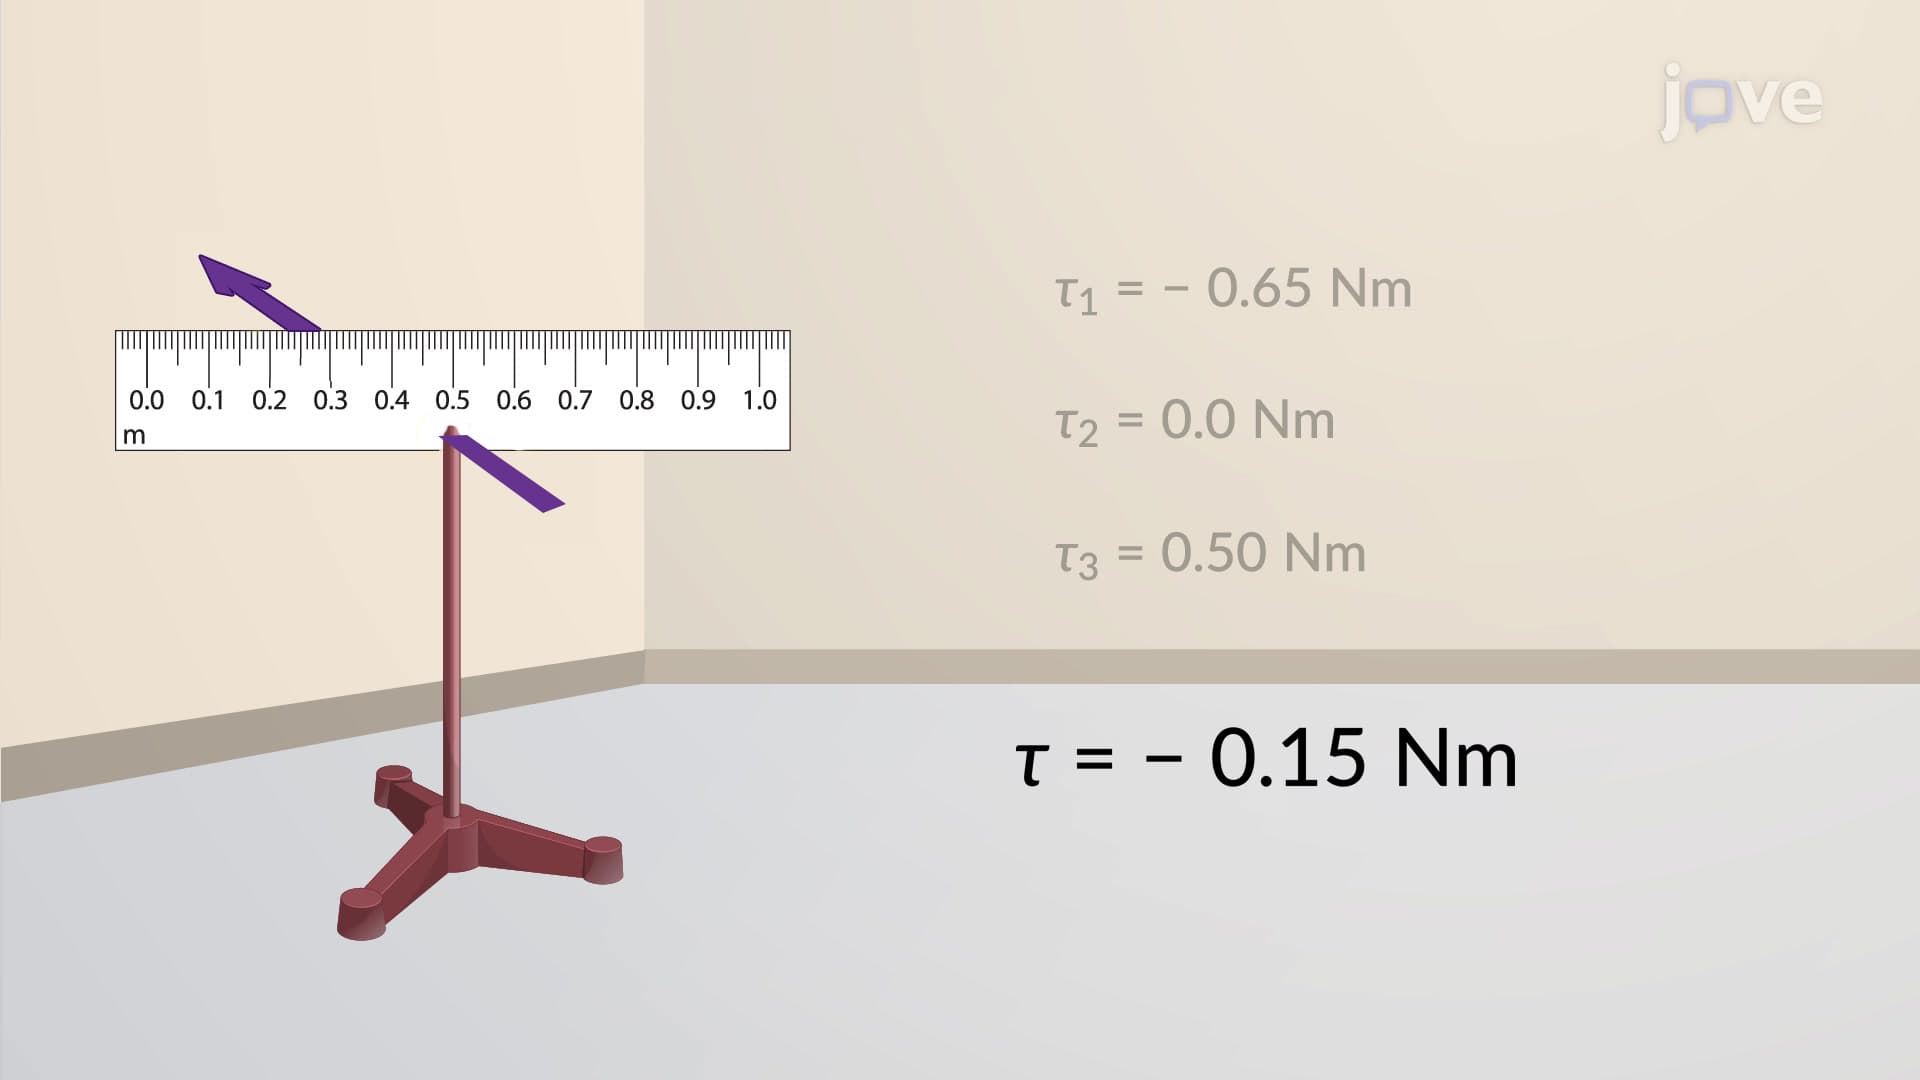
Net Torque Calculations
9.0K
When a mechanic tries to remove a hex nut with a wrench, it is easier if the force is applied at the farthest end of the wrench handle. The lever arm is the distance from the pivot point (the hex nut in this case) to the person’s hand. If this distance is large, the torque is higher. Only the component of the force perpendicular to the lever arm contributes to the torque. Therefore, pushing the wrench perpendicular to the lever arm is more advantageous. If multiple people apply force to...
9.0K
 01:18
Second Order systems II
84
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
84
 01:21
Linear Approximation in Time Domain
59
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
59