相关实验视频
Updated: May 24, 2025
06:48

The HoneyComb Paradigm for Research on Collective Human Behavior
Published on: January 19, 2019
9.3K
弹性时间变化的形成 - - 对抗混合攻击的多代理系统的跟踪与航天器形成的应用
IEEE transactions on cybernetics
|March 3, 2025

概括
本研究提出了针对混合攻击的多代理系统的弹性控制方案,以确保使用分布式估计器和事件触发协议的形成跟踪稳定性.
科学领域:
- 控制理论 控制理论
- 机器人技术 机器人技术 机器人技术
- 网络化系统 网络化系统
背景情况:
- 多代理系统面临着混合攻击的漏洞,包括拒绝服务 (DoS) 和执行攻击.
- 这些系统中的形成跟踪对于协调任务至关重要,但容易受到网络威胁.
- 现有的防御可能无法解决组合攻击载体的复杂性.
研究的目的:
- 开发一个强大的和可扩展的控制策略,用于在混合攻击下追踪多代理人阵营.
- 为了增强系统对通信 (DoS) 和控制输入 (激活) 攻击的弹性.
- 为了确保稳定的形成跟踪与可证明的错误界限.
主要方法:
- 使用相对邻近信息设计分布式状态估计器.
- 实现一个事件触发的协议与采样和拓恢复DoS弹性.
- 开发一种适应性输出反控制方案,以防止执行攻击.
- 数学证明统一的终极边界性用于追踪错误.
主要成果:
- 拟议的方案通过避免直接使用受损的共识输入来有效地防御执行攻击.
- 事件触发协议增强了对DoS攻击的弹性,具有分布式和拓独立的设计.
- 适应性控制确保追随者跟踪估计状态,并证明有边界的跟踪错误.
- 通过应用到航天器形成控制问题进行验证.
结论:
- 开发的层次控制方案为混合网络物理攻击下的多代理系统提供了强大的形成跟踪.
- 分布和事件触发的性质确保了复杂的网络环境中的可扩展性和弹性.
- 该方法在确保自主多代理操作方面取得了重大进展,特别是在太空飞船形成等关键应用中.

相关概念视频
 01:05
Collisions in Multiple Dimensions: Introduction
4.7K
It is far more common for collisions to occur in two dimensions; that is, the initial velocity vectors are neither parallel nor antiparallel to each other. Let's see what complications arise from this. The first idea is that momentum is a vector. Like all vectors, it can be expressed as a sum of perpendicular components (usually, though not always, an x-component and a y-component, and a z-component if necessary). Thus, when the statement of conservation of momentum is written for a...
4.7K
 01:06
Collisions in Multiple Dimensions: Problem Solving
3.5K
In multiple dimensions, the conservation of momentum applies in each direction independently. Hence, to solve collisions in multiple dimensions, we should write down the momentum conservation in each direction separately. To help understand collisions in multiple dimensions, consider an example.
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
3.5K
 01:15
Elastic Collisions: Case Study
13.3K
Elastic collision of a system demands conservation of both momentum and kinetic energy. To solve problems involving one-dimensional elastic collisions between two objects, the equations for conservation of momentum and conservation of internal kinetic energy can be used. For the two objects, the sum of momentum before the collision equals the total momentum after the collision. An elastic collision conserves internal kinetic energy, and so the sum of kinetic energies before the collision equals...
13.3K
 01:00
Elastic Collisions: Introduction
12.1K
An elastic collision is one that conserves both internal kinetic energy and momentum. Internal kinetic energy is the sum of the kinetic energies of the objects in a system. Truly elastic collisions can only be achieved with subatomic particles, such as electrons striking nuclei. Macroscopic collisions can be very nearly, but not quite, elastic, as some kinetic energy is always converted into other forms of energy such as heat transfer due to friction and sound. An example of a nearly...
12.1K
 01:13
Stability of Equilibrium Configuration: Problem Solving
566
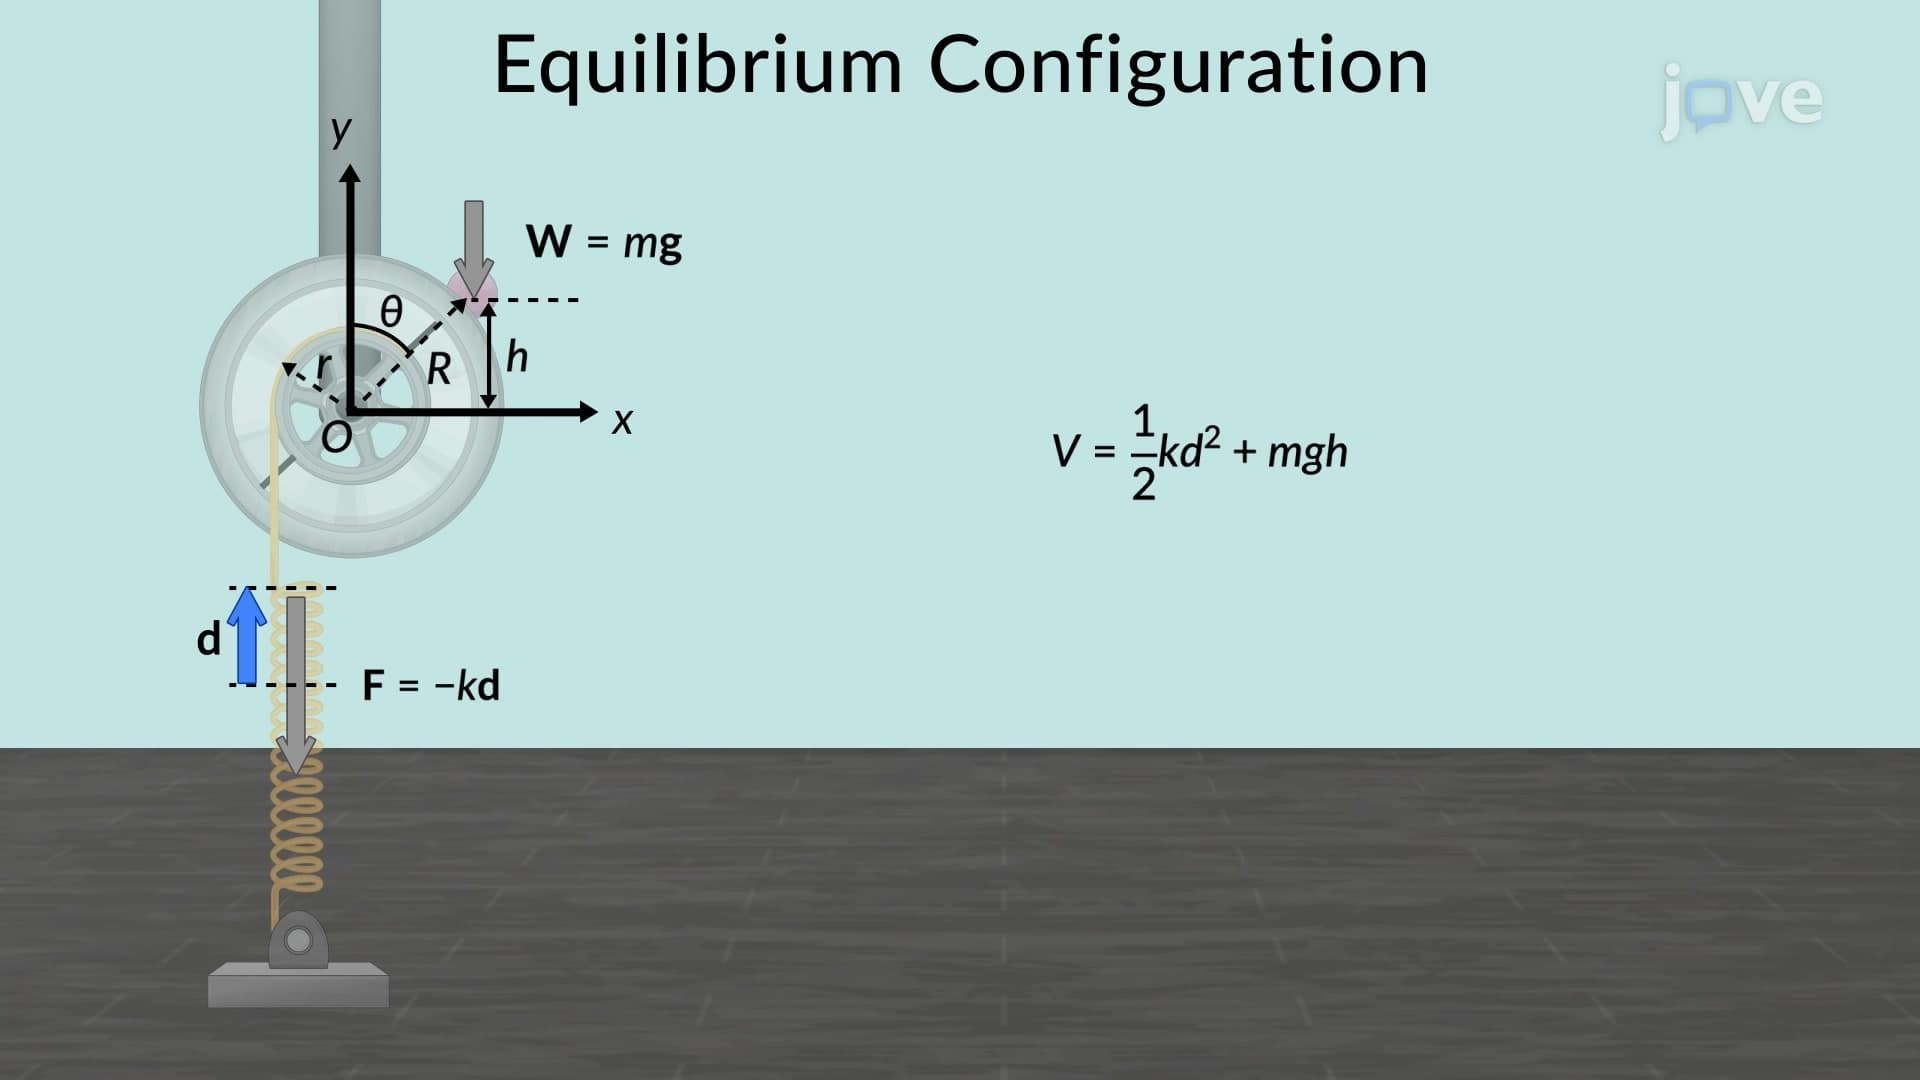
The stability of equilibrium configurations is an important concept in physics, engineering, and other related fields. In simple terms, it refers to the tendency of an object or system to return to its equilibrium position after being disturbed. The stability of an equilibrium configuration can be analyzed by considering the potential energy function of the system and examining its behavior near the equilibrium point.
Problem-solving in the context of the stability of equilibrium configuration...
Problem-solving in the context of the stability of equilibrium configuration...
566
 01:23
Stability of Equilibrium Configuration
417
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
417